NATION

PASSWORD

SDI Marine Systems Catalog [DO NOT POST]

A meeting place where national storefronts can tout their wares and discuss trade. [In character]
User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

SDI Marine Systems Catalog [DO NOT POST]

Postby The Technocratic Syndicalists » Sun Aug 28, 2016 11:50 am

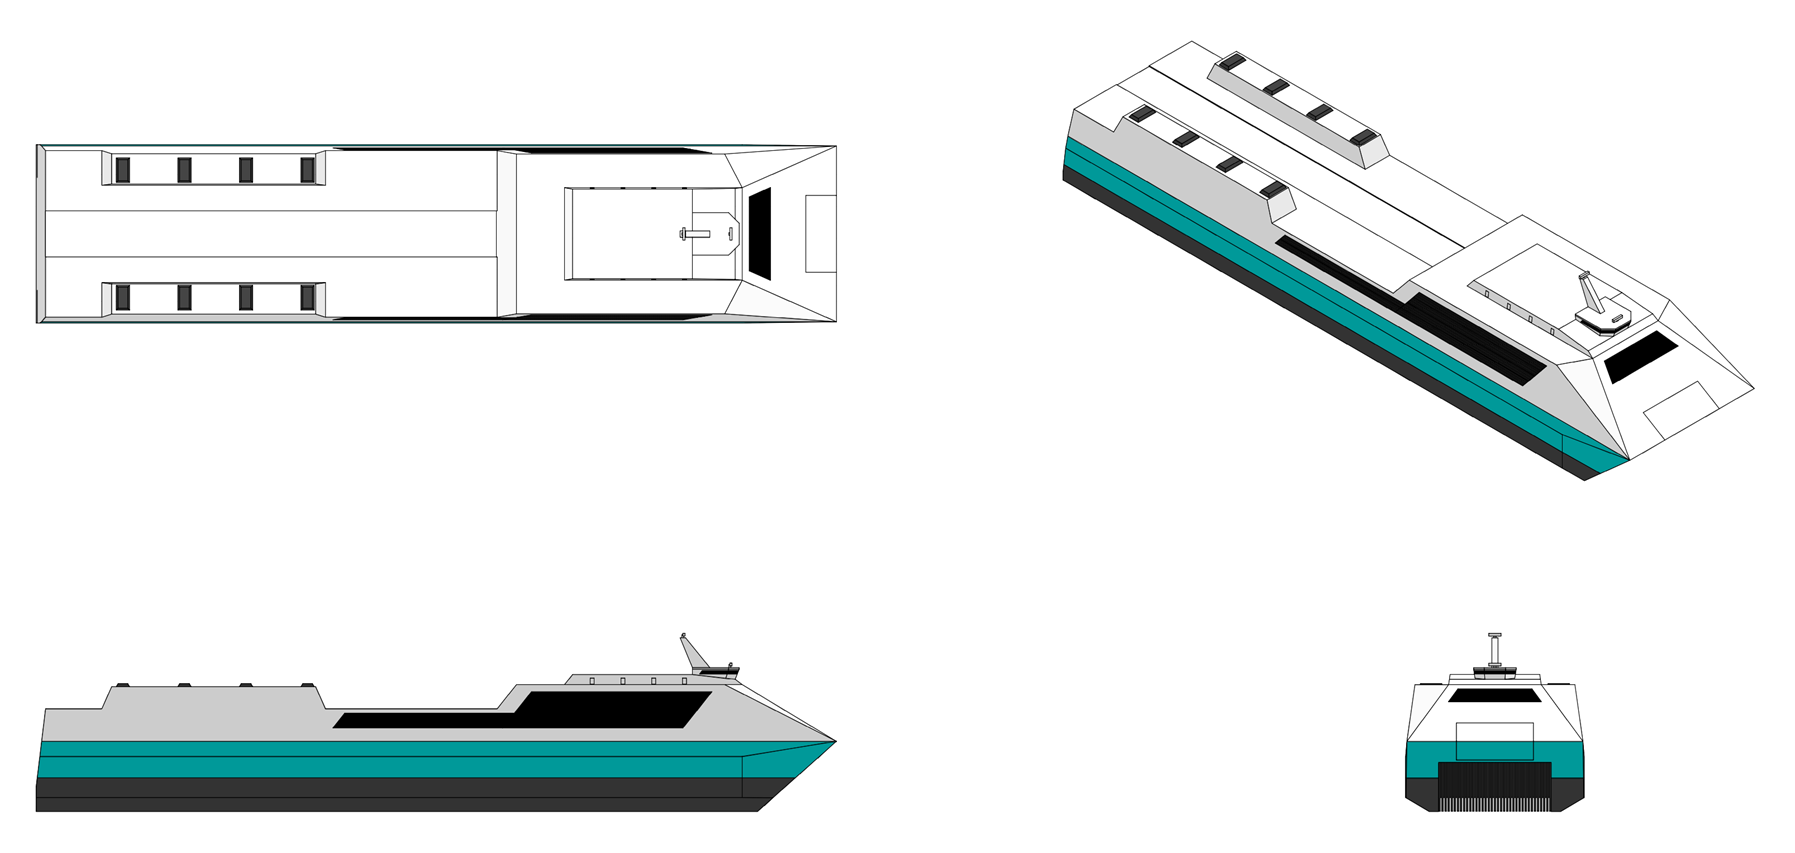
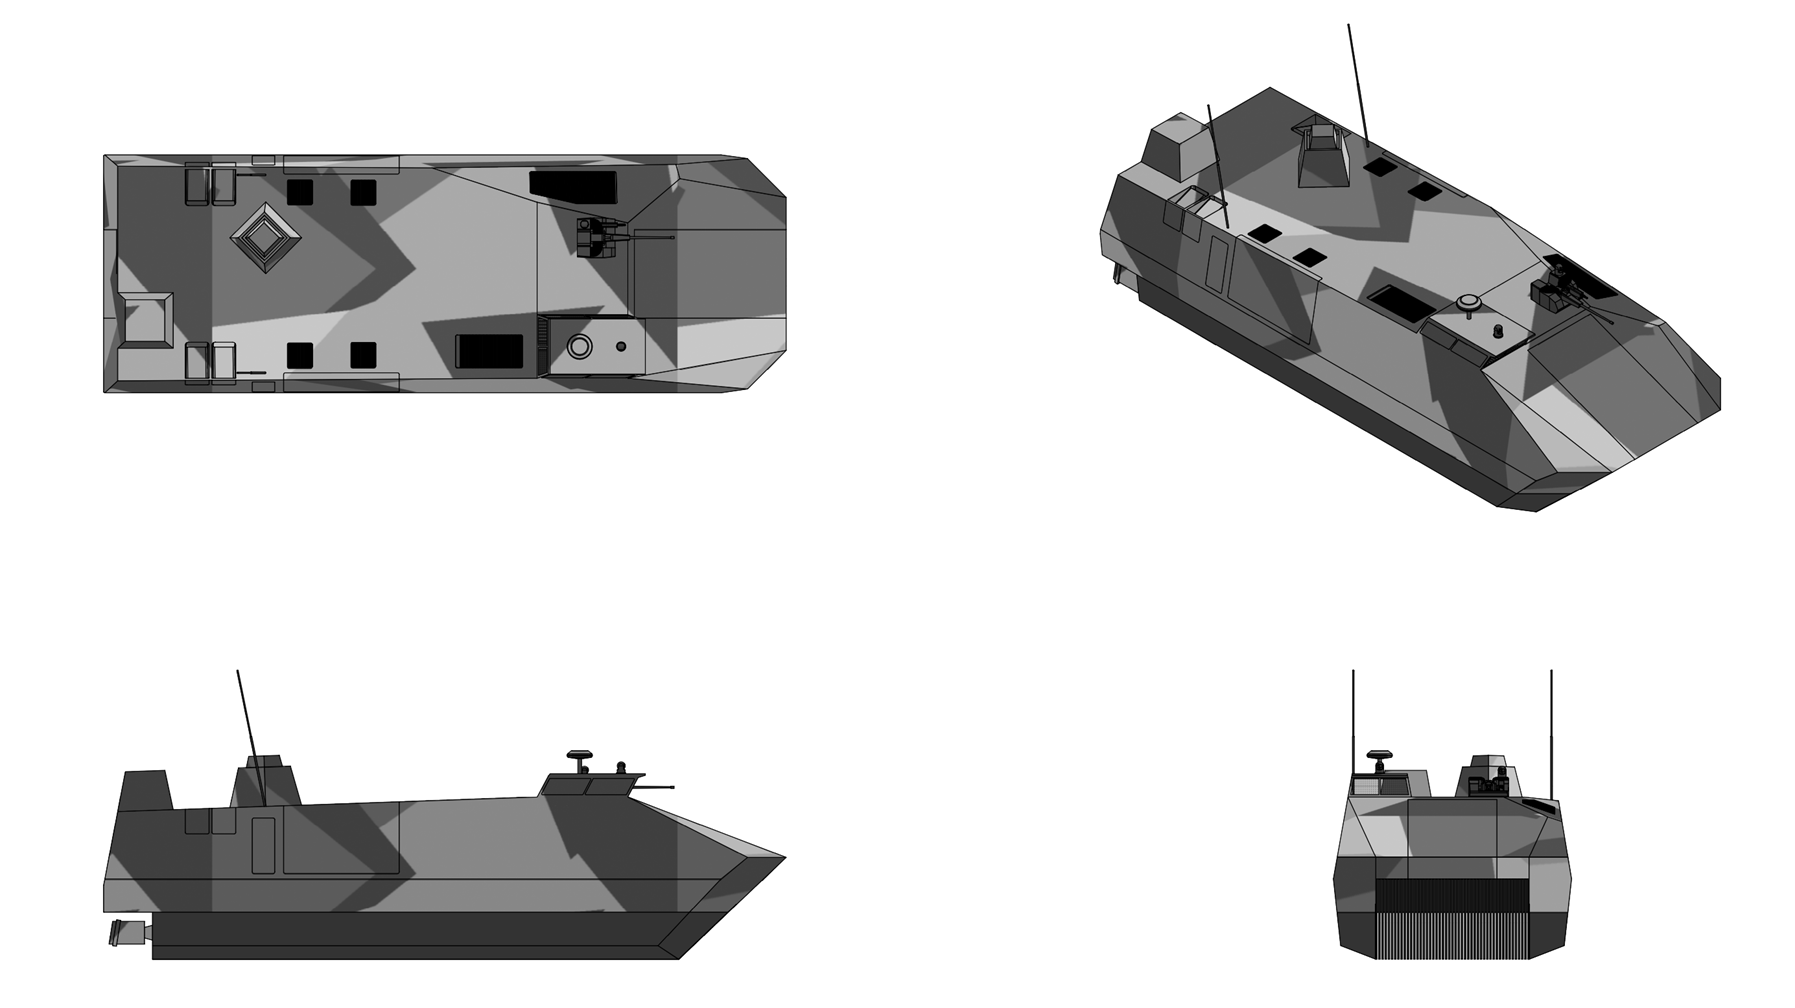
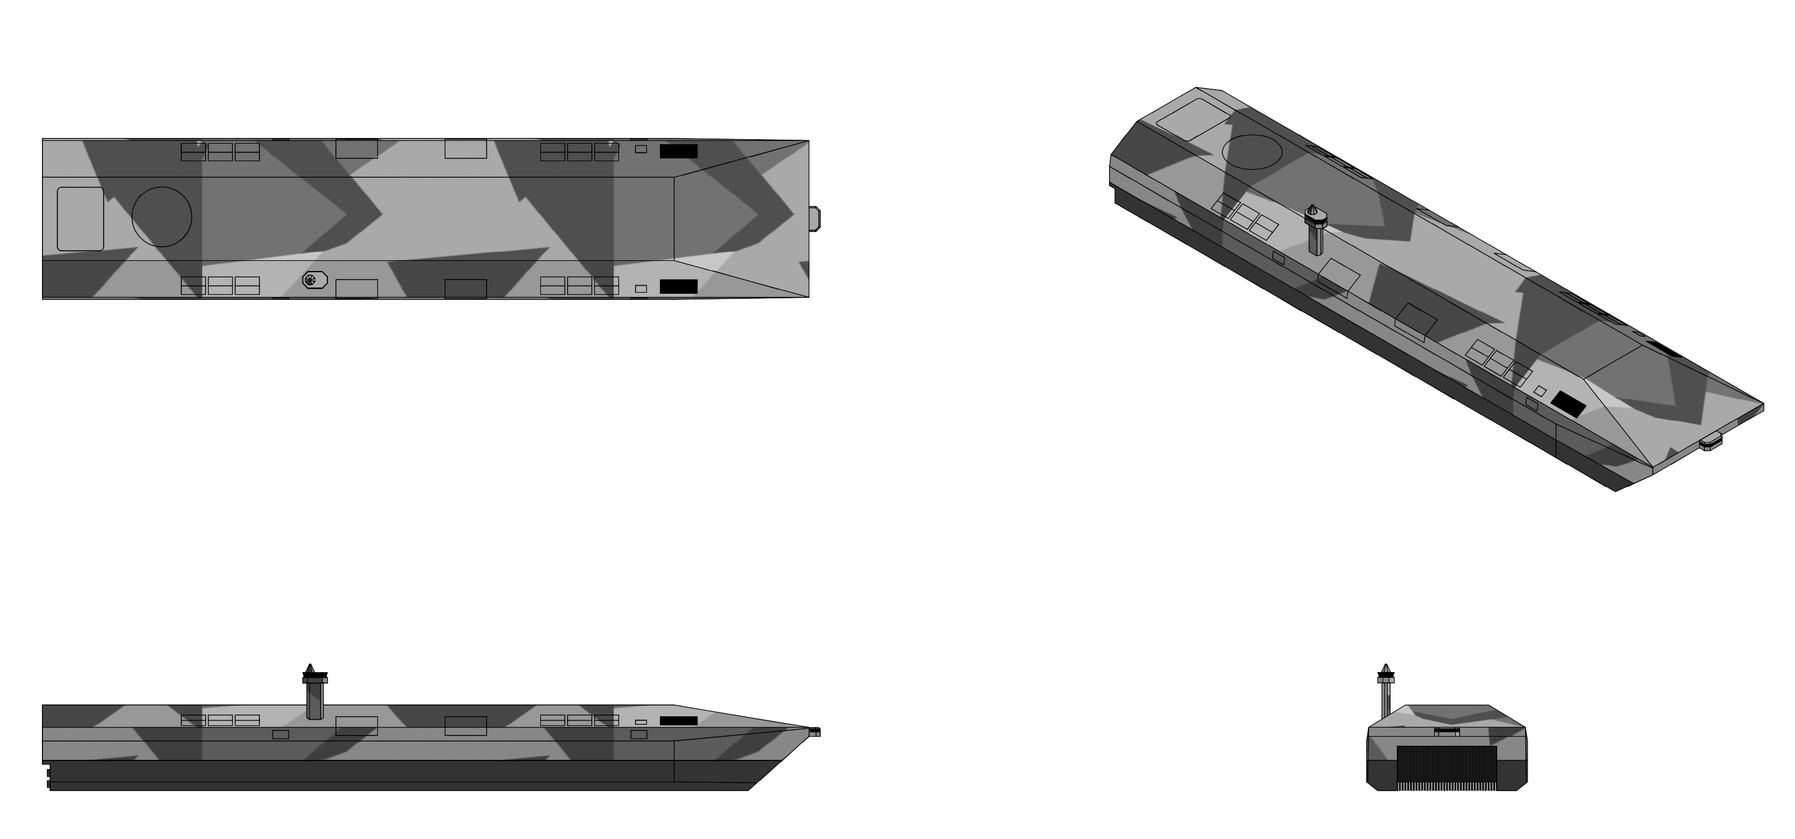
Image

Inflictor Class Carrier

Basic Information:
  • Role: Aircraft Carrier
  • Displacement:131,000 t (full load)
  • Complement: 2,000 crew + 2,400 air wing
  • Length: 390 m
  • Beam (flight deck): 90 m
  • Beam (waterline): 42 m
  • Draft: 12.5 m
Installed Power:
  • 2x SDI PWR 1175 pressurized water reactors (PWRs), 700 MWt each
  • 4x AMG 12V 17/19 M95 emergency diesel generators, 2,900 kW each
Propulsion:
  • 4x SDI high temperature superconducting (HTS) AC Motors, 50 MW each
  • 4x shafts, 4x 5 bladed fixed pitch propellers
Performance:
  • Top Speed: 31 knots
  • Range: crew endurance
Sensors & Processing Systems:
  • SDI Typhoon Combat System
  • SDI FMG 300 X band Multi-Function Radar (MFR)
  • SDI FMG 600 S band Volume-Search Radar (VSR)
  • SDI Integrated Bridge and Navigation System
  • SDI EOS 400 Staring Infrared Search & Track System
Electronic Warfare & Countermeasures:
  • SDI FMS 1800 Electronic Warfare System
  • SDI LWG 310 Naval Laser Warning System
  • SDI ZTKG 130 Trainable Decoy Launching System (TDLS)
  • SDI Sea Guardian Surface Ship Torpedo Countermeasure System
Armament:

Aircraft Carried:

Aviation Facilities
  • 4x electromagnetic catapults
  • 4x arresting cables
  • 4x deck edge lifts
  • below deck hangar


Overview:
The Inflictor is a class of large nuclear powered aircraft carriers designed by SDI Marine Systems.


Design & Construction:
The Inflictor class carriers have a length of 393 meters overall (377 meters at the waterline), a waterline beam of 42 meters, a design draft of 12.5 meters, and a full load displacement of 131,000 tonnes. The ship has very full hull form with a protruding bulbous bow to reduce wave-making resistance. The carrier is constructed from over 200 modular sections each weighing up to 900 tonnes which are assembled separately and then welded together on the dry dock to form the complete ship. The ship's hull is 18 decks tall and is constructed primarily from welded St 92 (900 MPa yield strength) high-strength structural shipbuiding steel. The ship's twin islands each weigh around 555 metric tons with the forward island containing the navigation bridge, flag bridge, and combat direction center and the aft island containing the ship's primary flight control flight, deck control and launch operations room, carrier air traffic control center.


Propulsion
The Inflictor class is powered by a two SDI PWR 175 pressurized water reactors each with a rated maximum power output of 700 megawatts of thermal energy (MWt). Each reactor is fueled using 97% highly enriched uranium (HEU) and is designed for a service life of over 40 years without refueling. The SDI PWR 180 reactor employs integral type circuit design with all primary circuit components including the steam generators are placed inside the reactor pressure vessel. The emergency core cooling system (ECCS) employs our separate systems including a gravity driven water injection system, pressure injection system, passive decay and heat removal system (PDHR), and a reactor protection system (RPS). The reactor core has an active length of 2.4 meters and contains 89 fuel assemblies containing binary U-Zr metallic nuclear fuel pellets consisting of 15% zirconium and 85% uranium enriched to a level of 97% U235 with a boron burnable poison coating which gives the reactor a design service life of 45 years before requiring refueling. Pumping for each reactor is provided by four horizontally mounted axial flow pumps attached to the outer shell of the reactor vessel which each provide a flow rate of 95,000 liters per minute (LPM) of cooling water through the reactor core. Each pump is powered by a 500 kW, 460 VAC 3 phase brushless AC motor driven by a variable a frequency drive (VFD). Steam from the reactors is used to drive a total of four turbogenerators each rated at 87.5 MW. Each of the four turbogenerators employs a double-ended turbine which drives a 120 Hz, 6 phase, 4160 VAC, 87.5 MW, 3600 rpm high-temperature superconducting (HTS) AC generator.

The 350 MWe of electrical power from the four turbogenerators is distributed throughout the ship using a DC zonal electrical distribution (ZEDS) which distributes DC electrical power to the ships propulsion plant, sensors, electromagnetic catapults, and hotel loads.. The 4160 VAC from the four turbogenerators is converted to to 6000 VDC with four power conversion modules (PCMs) attached to each generator. The PCMs then supply both port and starboard DC buses which supply power to 24 electrical zones which each include one DC/DC PCM per bus (two each per zone) which converts the 6000 VDC to 750-800 VDC or 650 VDC to supply DC loads in each zone. Both DC/DC PCMs in each zone also supply one or more DC/AC PCMs with 750-800 VDC which then converts the 750-800 VDC to 450 VAC at 60 Hz for AC loads. All electrical loads in each zone are connected to both port and starboard bus ensuring continued operation if either port or starboard bus becomes inoperable.

The warship's integral electric propulsion (IEP) system features four SDI designed 50 MW superconducting motors which directly drive the ship's four propellers. Each 50 MW superconducting motor is a three phase, six pole synchronous air-core AC motor with a brushless exciter which has a rated speed of 150 RPM at its design voltage of 7,200 VAC with a full-load efficiency of 97.5%. The complete motor with cryocooler assembly weighs 75 tonnes, approximately 80% less than a conventional AC induction motor of the same RPM and power output. The rotor employs yttrium-barium copper-oxide (YBCO) high temperature superconducting ceramic conductors and is cryogenically cooled to 77 degrees K using gaseous helium from cryocooler module containing single Stage GM cryocoolers located at the non-drive shaft end of the motor which feeds helium gas into the rotor through a rotating seal at the back end of the motor. The rotor housing is further enclosed in a vacuum-sealed cryostat to maintain cryogenic temperatures inside the rotor. The stator coils of the motor are made from copper Litz conductor and are cooled using a liquid dielectric coolant. Each motor employs a variable-frequency drive (VFD) with three separate 2,400 VAC three-phase power modules per drive which allows for efficient motor operation from 6 up to 150 rpm. Each 60 MW motor is used to directly drive a single 7.5 meter diameter, 5-bladed fixed pitch propeller weighing 27 metric tons through a hollow carbon fiber reinforced plastic (CRFP) alloy propeller shaft supported by a series of water lubricated bearings.

Steering is accomplished by two rudders which are 8.8 meters high, 5.7 meters long, and weigh 50 metric tons each. The rudders are placed directly behind the inboard propeller shafts and employ a twisted blade design to minimize cavitation effects. A 4-vane rotary vane steering gear with 3,690 kNm of peak torque is used to actuate each rudder with +/- 70° rudder deflection capability. Tactical diameter of the ship is 1,000 meters at a speed of 30 knots.


Sensors & Processing Systems:
SDI Typhoon Combat System: The SDI Typhoon Combat System (TCS) is a comprehensive open-architecture anti-aircraft warfare (AAW) combat management system designed by SDI Missiles & Fire Control Systems which provides fully automated detection, identification, and engagement of air targets. The primary components of the Typhoon Combat System are the Sensor Fusion Processor (SFP), Command and Decision System (C&DS), Typhoon Display System (TDS), Weapons Control System (WCS), and Integrated Ship Computing System (ISCS). The sensor fusion processor or SFP takes tracking data from the ship's radars, IFF system, distributed IRST sensors, and electronic warfare system and correlates them using a contact-to-track data correlation algorithm to provide a single integrated track of each detected target. With the contact-to-track algorithm detected contacts from each sensor (radar, IFF, IR, and ESM) are correlated with existing sensor tracks and merged using a smoothing filter to create a single track file of each correlated target. This allows (for example) the range data from the radar tracks of the dual band radars to be fused with the angle track data from the higher angular resolution IRST sensors, creating a fused 3D track which is more accurate than either the individual radar or IRST sensor tracks. Track data from the sensor fusion processor is fed into the Typhoon Command and Decision System (C&DS) which uses both IFF data and aided and automatic target recognition (Ai/ATR) algorithms to provide identification, threat classification, and weapon assignment of target data input from the sensor fusion processor. Information from the Command and Decision System (C&DS) processor is displayed via the Typhoon Display System (TDS) which uses large multi-function color displays inside the ship's CIC to display target tracks and other situational awareness data to the ship's crew and captain. The TDS consoles also features keyboards for data input which allows doctrinal IF/THEN instructions to be input to the system to the modify its behavior; such as instructing the system that IF any target is detected above a certain speed and altitude in a certain sector THEN it is to be automatically classified as hostile and engaged with a certain missile. The Weapons Control System (WCS) is responsible for launching missiles at targets identified as hostile by the Typhoon Command and Decision System (C&DS). Targets are matched to the ship's missiles by the C&DS which will then send a fire instruction to the weapon control system when the target has entered the engagement zone of the specific missile. The WCS then sends a a firing instruction to the ship's VLS to fire the specific missile and then uses the ship's radars and datalinks to provide midcourse guidance as necessary to guide the missile towards its intended target. The WCS is also responsible for providing Air Intercept Control (AIC) functionality and can be used to guide carrier or land based airborne interceptors towards a hostile target being tracked by the ship. Finally the Integrated Ship Computing System (ISCS) acts as the central processor of the Typhoon combat system and processes radar and and other sensor data and connects all the ships systems including weapons, countermeasures, and communications system together. The ISCS architecture is based on SDI's SPPC10D single-board computer, a ruggedized, shock hardened and conduction cooled computer which employs a 10nm gallium nitride (GaN) on silicon architecture, 48 core (384 thread) superscalar symmetric multiprocessor with a 4.0 GHz clock rate as well as 64 GB of DDR5 DRAM. The SPPC10D computers are each packaged into 16 Electronic Modular Enclosures (EMEs) which each include their own power, shock, vibration, and electromagnetic protection, and water cooling systems. Each EME is a self-contained server and carries 235 cabinets containing the SPPC10D single-board computers. The EMEs which run the ISCS software are interconnected to the rest of the sensors and electrical systems through fiber-optic cables and uses voice-over IP for internal communications between computer systems. The combined computing power of the ship's processors is 27,000 MIPS (million instructions per seconds) at 4.35 GHz with a combined 240 TB of data storage.

An additional ability of the Typhoon Combat System is Distributed Engagement Capability (DEC) which allow target tracking data from multiple sensors across multiple Typhoon equipped platforms in the battle group to be fused together to create a composite track of all air objects within the battle force area and to allow for hunter-killer functionality in the battle group by allowing unit in the battle force to engage a target being tracked by another unit even when the shooter is unable to see or track the target with its own sensors due to either jamming, battle damage, or line-of-sight restrictions. Distributed engagement capability on Typhoon equipped platforms s enabled by a data distribution system (DDS) and a track fusion algorithm (TFA). The data distribution system or DDS consists of four C band planar array antenna assemblies blended into the outer surface of the ship's superstructure which provide extremely high bandwidth line-of-sight communication capability with other sea and air platforms in the battle force. Each DDS antenna array consists of a liquid cooled digital beam forming (DBF) antenna with separate transmit and receive arrays employing gallium nitride (GaN) monolithic microwave integrated circuit (MMIC) transmit/receive (T/R) modules integrated into a common subarray line replacement units (LRUs) and high provides extremely jam resistant and high bandwidth line-of-sight data exchange with other DDS equipped platforms. The track fusion algorithm (TFA) uses the ships ISCP processors to take sensor data received by other units through the data distribution system and fuse it with data from the ships own sensors to create a single composite sensor picture. The main capability of the track fusion algorithm is the ability to network the measurements of radars and other sensors on different platforms tracking the same target and combine them with an intelligent averaging algorithm that creates a single composite track of the target which is more accurate than the track of any individual sensor. When a Typhoon equipped platform establishes a target track with one or more of its sensors a track alert is broadcast across the Typhoon network which then cues the other platforms in the battle force to point their sensors in the direction of the target track. When the other platforms begin tracking the target with their own sensors their sensor measurements are distributed back across the network to every other platform to form the composite track. This capability allows the battle force to maintain track of a target even if any one or even multiple of the battle force units loses the target track due to jamming, battle damage, or environmental effects. When used to fuse radar data from different platforms the track fusion algorithm also enables better radar observation of low observable targets by illuminating them simultaneously with many radars of different wavelengths and scan rates at once, allowing a composite track to be created even if none of the radars in the battle force are able to generate an individual track of the target for more than a few pulses.


FMG 300/600 Dual Band Radar (DBR): The SDI Dual Band Radar (DBR) system includes the ships FMG 300 X band Multi-Function Radar (MFR) and FMG 600 S band Volume-Search Radar (VSR). Each radar system consist of three phased-array antennas and associated receiver/exciter (REX) cabinets above -decks in the superstructure and a signal and data processor (SDP) system mounted below-decks inside the hull. Both arrays share a central controller and and a common array power system (CAPS) with power conversion units (PCUs) and power distribution units (PDUs) for each radar antenna. Both arrays are cooled using a closed loop, phase change based common array cooling system (CACS). The X band radar system features a larger operating bandwidth and better low-altitude performance and provides surface search, radar navigation, gun-fire targeting and splash spotting, periscope detection, mine detection, precision target tracking and discrimination, limited volume-search, high-bandwidth missile uplink, and terminal illumination of targets while the S band radar provides long range volume search and long-range target tracking capability. Both the The X band and S band radars can provide simultaneous sector search, environmental mapping, counter-fire/counter-battery tracking, missile tracking, electronic warfare, clutter detection, and in-flight missile guidance and communication. Each X band FMG 300 aperture has a 4-meter square antenna with 10,560 transmit and receive (T/R) modules which use gallium nitride complementary metal-oxide semiconductors (CMOS) on a diamond substrate. The S band FMG 600 antennas are significantly larger at 16 square meters and each use 42,240 full-duplex radio integrated circuit transmit and receive (T/R) modules. Each radar antenna features +/- 60° azimuth and +/- 60° degree beam-steering capability giving the system combined 360° azimuth coverage around the warship. Both radar systems employ wide-band digital receiver/exciter (DREX) units and feature digital beam-forming (DBF) capability, space-time adaptive processing (STAP), and multiple-input multiple-output (MIMO) waveform generation techniques. ECCM capabilities of the dual band radar system include frequency-modulated continuous-wave (FMCW) operating modes, ultra-low sidelobes, high processing gain, pulse-to-pulse frequency agility and ultra wide-band frequency hopping, staggered pulse repetition frequency (PRF) switching, randomized burst transmissions, and automatic jammer detection and tracking. Peak power consumption of the dual-band system is 12 MW and instrumented range is 1,000 km in air-surveillance mode and 2,000 km in ballistic missile tracking mode with the ability to simultaneously track up to 3,000 air targets in air surveillance mode or up to 30 ballistic missile targets in ballistic missile tracking mode.

EOS 400 Staring Infrared Search & Track System: The EOS 400 Staring Infrared Search & Track System is a distributed multi-aperture sensor system which consists of four identical dual field-of-view, electronically stabilized mercury cadmium telluride (HgCdTe) starring focal plane array (FPA) imaging infrared (IIR) sensor units mounted in a mast above the ship's island which provide combined 360°azimuth and -20° to +75° elevation situational awareness infrared search and track (SAIRST) capability against surface vessel, cruise missile, ballistic missile, and aircraft targets to supplement the active search and track capability of the ship's dual band radar system. The 4096 × 4096 pixel (16 MPA) HgCdTe sensor used by each sensor head operates in the MWIR (3–5 µm) band and features a 95 x 95° degree field of view. The image processing features of the EOS 400 system include automatic target recognition (ATR) using an on-board threat library, passive ranging algorithms, multi-target adaptive tracking, and clutter rejection techniques. The video feed from the sensor units can be stitched together and displayed on operator consoles in the ship's bridge and CIC to act as a navigational aid and to provide close in situational awareness for the ship's crew.

SDI Launch and Recovery Surveillance System: The Launch and Recovery Surveillance System or LARSS is a network of eight cameras placed around the ship's two islands which provide continuous 24/7 monitoring of launch, recovery, and flight deck operations. The system uses 2 megapixel (1920 x 1080 px) visible/SWIR (0.4 - 1.7 µm) cameras with InGaAs (indium gallium arsenide) FPAs with a 60 fps frame rate. Five of the eight cameras are mounted in a fixed panoramic mount on the starboard side of the forward island with feeds from the five cameras stitched together to provide a real-time panoramic video feed of the entire flight deck. The other other three cameras are mounted atop the aft island in individual mounts with pan/tilt capability and feature digital zoom to allow the operators to zoom in on any specific part of the flight deck or aircraft taking off and landing from the carrier. Four control console units (CCUs) for the LARSS system are mounted below the flight deck in the LARSS control room.

SDI Carrier Aircraft Tracking System (CATS): The SDI Carrier Aircraft Tracking System is a sensor system which is designed to provide continuous tracking of aircraft locations and orientations on the flight deck and inside the hangar and aids in the automation of flight deck operations by supplying flight deck personnel with a digital aircraft spotting board with real-time information on the position and status of each aircraft on the ship. The Carrier Aircraft Tracking System is fully automated and employs a 3D camera tracking system with a a total of 43 1920 x 1080 pixel visible/SWIR (0.4 - 1.7 µm) cameras with InGaAs (indium gallium arsenide) FPAs with a 60 fps frame rate which are combined with digitized video enhancement and machine vision algorithms to provide position tracking of each carrier aircraft on the ship in real time during the day and night and in all weather conditions. 12 of the 43 cameras are mounted in a fixed panoramic mount on the starboard side of the aft island and another 43 mounted on a fixed panoramic mount on the starboard side of the forward island with feeds from the 24 cameras stitched together to provide a real-time panoramic video feed of the entire flight deck. Another 16 cameras are mounted in the hangar, 8 in each hangar bay, with feeds from each set of 8 cameras stitched together to provide a real-time panoramic video feed of each hangar bay. The final three cameras are mounted atop the aft island in individual mounts with pan/tilt capability and feature 10x digital zoom capability and are used to track aircraft taking off and landing from the carrier and provide the capability to zoom in on any specific part of the flight deck. Parallax between the cameras on the forward and aft island is used to determine the position of objects on the flight deck with additional position accuracy provided by machine vision algorithms which pinpoint individual features on the objects on the flight deck and hangar in relation to fixed landmarks on the flight and hangar decks. Individual pixels in each fixed frame are referenced to fixed padeyes and deck lights on the flight and hangar decks which are then used to triangulate the position of the object being tracked. The cameras track the six orientation parameters (X, Y, and Z coordinates, along with yaw, pitch and roll) of each aircraft with <0.5 meter position accuracy and continuously update the system computer generated digital aircraft spotting board at a rate of sixty frames per second. The CATS storage includes digital storage of "interesting events" which includes launch and recovery events with the ability to filter events by tail number and by aircraft type. The CATS is also used to provide FOD detection, fouled deck detection, and ordnance inspection.


Electronic Warfare & Countermeasures:
FMS 1800 Electronic Warfare System: The primary electromagnetic countermeasure system of the ship is the FMS 1800 Electronic Warfare System, a comprehensive offensive and defensive electronic warfare (EW), electronic support measures (ESM), and electronic intelligence (ELINT) suite which combines passive radar warning receivers and phased array jammers for long range, over-the-horizon detection, identification, and targeting of threat emitters as well as automatic employment on-board RF countermeasures and support of passive over-the-horizon targeting capability for the ship's weapon systems. The passive radar warning system of the FMS 1800 consists of multiple single-quadrant, high-gain linear interferometer arrays blended into the sides of the vessel's island which are connected to a set of digital receivers and pulse processors inside the ship's superstructure which provide for 360 degree spherical broadband, all aspect detection, identification, and direction-finding of radar emissions with the capability for precise emitter location and threat identification capability against low probability of intercept waveforms and with additional over-the-horizon direction finding capability of MF, HF, VHF, and UHF band signals. The offensive electronic warfare capability of FMS 1800 system includes multiple low, mid, and high band electronically scanned gallium nitride (GaN) based Digital Radio Frequency Memory (DRFM) jammers blended into the superstructure which provide for the jamming of hostile RF sensors. The FMS 1800 is a fully cognitive and adaptive system; by using radar emission data collected from the FMS 1800 radar warning receivers the DRFM jammers can automatically adapt in real time to unknown waveform characteristics, dynamically synthesize countermeasures, and jam the waveform accordingly. The DRFM Jammers of the FMS 1800 also includes false target generation capability allowing the FMS 1800 to generate up to 32 simultaneous false surface and air targets at ranges up to 625 kilometers to spoof hostile radar systems. Designed to spoof wideband phased array radars with moving-target indicator (MTI) and inverse synthetic aperture radar (ISAR) capability, the false-target generation system of the FMS 1800 comprises a receiver system for producing a false signal that mimics an incident radar pulse, a phase sampling circuit is connected to the FMS 1800 radar warning receivers for sampling the signal and providing phase sample data, and an image synthesizer circuit is connected to the phase sampling circuit and arranged to receive the phase sample data from the circuit which processes the phase sample data to form a false target signal which is input to a signal transmitter system built into the FMS 1800 DRFM jammer array which is arranged to transmit the synthesized false target signal so that it can be received by the threat radar system.

SDI Sea Guardian Surface Ship Torpedo Countermeasures System: The ship is fitted with the SDI Sea Guardian Surface Ship Torpedo Countermeasure System which combines various soft-kill and hard-kill torpedo countermeasure systems. The Sea Guardian system consists of a towed array sonar designed specifically for torpedo detection, a towed acoustic decoy with a a single-drum winch, an interface to the ship's trainable decoy launchers, and a processing cabinet with two display consoles, and and four 4-round anti-torpedo torpedo launchers on either side of the ship. The towed array sonar used by the system is a combined active and passive array sonar optimized to detect the high frequency sound signature of torpedo screws and active sonar homing heads. The towed array is supported by two vibration isolated modules (VIMs) located on either side of the sonar with the array being connected on one end to the ship using a fiber-optic tow cable and connected on the other end to the towed decoy with an array tow cable. The towed decoy array is designed to emit simulated ship noise such as propulsor and engine noise to lure a passive-sonar homing torpedo to the decoy instead of the ship. The towed decoy can also receive sonar pings from the active homing head of a torpedo and amplifies and returns the "pings" to the torpedo, presenting a larger false target to the torpedo. The hardkill component of the Sea Guardian system comprises a series of four box launchers on either side of the vessel which each contain six SDI S2s Barracuda anti-torpedo torpedoes in individual all-up rounds (AUR) which contain the Barracuda torpedo and a self-contained compressed gas launch system. The Barracuda torpedo is 21 cm in diameter, 2.0 meters in length, weighs 110 kilograms, and contains a 20 kilogram aluminized PBX explosive warhead. The guidance and fusing system of the Barracuda is designed to explode it in front of the oncoming torpedo and create a pressure wave which crushes the nose section of the oncoming torpedo. The Barracuda has a maximum firing range of 10 kilometers and is propelled by an advanced stored chemical energy propulsion system (ADSCEPS) which can propel the Barracuda at speeds up to 60 knots at depths up to 1,000 meters. Although designed as an anti-torpedo the Barracuda can also be used to engage midget submarines, naval mines, and unmanned or autonomous underwater vehicles.

ZTKG 130 Trainable Decoy Launching System (TDLS): The ZTKG 130 Trainable Decoy Launching System (TDLS) is am aimable decoy launching system which can launch a variety of decoys designed to decoy away anti-ship missile and torpedo threats. The TDLS) system consists of multiple 12-round trainable countermeasures launchers controlled by a central command console inside the ship. Each 12-round launcher employs a rotating platform with 12 separate 130mm barrels which can each be individually trained in elevation. The ship is fitted with eight decoy launching systems, four on either side of the ship used for acoustic torpedo decoys (48 total) and another four launchers on each side used for chaff/flare rounds and missile seduction decoys (48 total).

AM5 dual chaff/IR seduction decoy: The primary chaff seduction round employed by the TDLS is the AM5 dual chaff/IR seduction decoy which is capable of defeating dual-seeker missiles equipped with both IR/EO and radar seekers. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.

AM79 Buzzard active missile decoy: For decoying away radar-guided anti-ship missiles the TDLS can deploy the AM79 Buzzard active missile decoy, an expendable electronic-warfare rotary-wing drone which is designed to seduce RF guided anti-ship missiles by simulating the radar return of a large surface vessel. The buzzard features a cylindrical shaped fuselage 130 mm in diameter and 0.9 meters tall with both top and bottom mounted 1.8 meter diameter three-bladed counter-rotating coaxial rotors powered by two brushless DC motors. The rotors unfold from the body of the decoy after launch and fly the decoy into a pre-programmed flight path away from the ship where the decoy then hovers in place while emitting electronic warfare signals uses its fuselage mounted Digital Radio Frequency Memory (DRFM) jammers which are designed to seduce oncoming anti-ship missiles into targeting the decoy and not the host vessel. The decoy is powered by a thermal battery mounted in the center of the fuselage which gives the decoy approximately 60 minutes of flight endurance after launch.

AM7 Lamprey acoustic decoy: The TDLS can also launch the AM7 Lamprey, a 130mm diameter, expendable acoustic decoy designed to counter torpedo threats. After a rocket-powered launch into ocean the Lamprey is programmed to hover vertically using a pressure-controlled motor driving a small, shrouded propeller in the tail of the decoy. The Lamprey is designed to hover at a pre-selected depth from 10-300 meters where it listens for torpedo transmissions. Active acoustic transmissions are detected and analyzed resulting in decoy selectivity and generation of the appropriate deception signal for transmission including target signature and target self noise. If no torpedo transmissions are detected the decoy is programmed to emit warship propulsor and engine noise to lure in passive homing torpedoes. Power for the motor and electronics of the Lamprey is provided by a thermal battery. The Lamprey is programmed to hover and emit noise until the battery dies where the decoy then sinks and all software onboard is erased.


Flight Deck & Aircraft Operations:
Flight deck: The Inflictor class carrier features a 23,250 m2 area angled flight deck for aircraft operations. The flight deck is located 18 meters above the designed waterline and has a maximum width of 90 meters. The flight deck is designed to operate using a "pit stop” concept of aircraft servicing which is designed to decrease the amount of time needed to re-fuel, re-arm, and service aircraft during cyclic operations. The pit-stop style of operations are enabled by the carrier's extremely large flight deck area which enables the pilots of the landing aircraft to maneuver their plane from the recovery runway to the servicing pit-stop area, shut down, be serviced, start up, and then taxi to one of the ship’s catapults for relaunch, all without the need of using aircraft towing tractors. The carrier has a total of 24 pit stops placed around the edge of flight deck each of which is adjacent to two flush deck servicing hatches, one containing electric power and electrical LAN cable reels while the other contains a fueling and de-fueling fuel line and valve. After landing and being arrested by the arresting gear on the flight deck aircraft are guided to the nearest available pitstop by combination of flight deck spotters and a signal lighting system placed on the flight deck where the aircraft are parked with their exhaust directed overboard and then shut down. Aircraft service operators at each pit stop then open the electrical servicing hatch and connects grounding cables to a receptacle on the aircraft before connecting the electrical and LAN cables. A mobile fueling cart then pulls up to the pit stop and parks next to the fueling service hatch where the driver then opens the hatch, attaches a fuel line to the appropriate valve, and then pulls a fuel hose off the vehicle and connects it to the fuel receptacle on the aircraft. The fuel pumps at each pit stop have a flow rate of 1400 liters per minute which allows aircraft to be fully refueled in 7.5 to 10 minutes. While the aircraft is being refueled it is simultaneously rearmed using weapons provided from one of four weapons carrier elevators placed around the flight deck which serviced from below by several deck transient weapon stowage centers located in the ship's sponsons between the hangar and the flight deck. With an air wing of 90 to 100 embarked aircraft the pit-stop style of operations supports a sustained sortie rate of 180 to 220 sorties per 12-hour flight day with a surge capability of up to 400 sorties in a day. The carrier contains a total of around 17,500 tonnes of jet fuel which enables the carrier to sustain air operations for 21 days.

Hangar: The ship's hangar measures 34 meters wide, 8 meters high, and 260 meters long and is subdivided into two
aircraft servicing bays separated by a hangar division door which are each serviced by two deck-edge aircraft elevators. Each hangar bay includes a high hat region with a overhead bridge crane and an additional 2 meters of overhead clearance to allow for the removal of aircraft components requiring an overhead removal path. The aft sidewalls of the aft hangar bay contain two cargo elevators for transferring replacement aircraft engines from below deck storage to a jet engine repair shop located at the stern of the ship. The aft end of the hangar bay also includes a composite material repair shop which is capable of containing a single aircraft for composite structure repair and replacement operations. For pier-side replenishment a cargo ramp located along the starboard aft hangar wall is used to provide pier-side access of forklift driven palletized cargo into and from the hangar from one of eight pallet storage elevators located along the starboard side of the hangar which are each capable of transferring up to six pallets of cargo at once. The aft sidewalls of the aft hangar bay contain two cargo elevators for transferring replacement aircraft engines from below deck storage to a jet engine repair shop located at the stern of the ship. Forward of the hangar is a 50 meter extension used for storage which is divided into two decks, a lower storage deck which acts a storage for aircraft servicing gear and acts as a access to the in-deck cargo and weapon elevators and an upper storage deck which stores up to 50 6.0 x 2.4 x 2.4 meter modular electronic equipment containers. The modular electronic equipment container consists of a shipping container modified with a removable top which leave behind a rafted deck to which is mounted various electronic equipment and operator workstations for the ship's various subsystems. The containers are lifted into the flight deck or onto one of the ship's elevators where they are moved to the the high hat region in the hangar maintenance bays. The overhead bridge crane in the high hat region is then used to remove the top from the container
where the raft is then moved on rails to the forward hangar extension. The raft is then hoisted up into the overhead portion of the forward hangar extension and secured where the electrical, cooling water, and LAN connections are made with the electronics on the raft.

Catapults: The flight deck of the Inflictor contains four SDI designed electromagnetic catapults or "electropults" for launching aircraft. Each electropult weighs 225,000 kg, is slightly over 100 meters long, and is capable of launching aircraft weighting up to 45,000 kg at speeds of up to 180 knots. The electropult employs a linear synchronous motor supplied with electrical power via a cycloconverter by a network of four compensated pulsed alternators (CPAs) which provide the pulsed power necessary to accelerate the aircraft down the catapult. The four 81.6 MW compensated pulsed alternators consist of an axial field permanent magnet motor (PMM) with four 35 MGOe (Mega Gauss Oersteds) neodymium iron boron (NdFeB) magnets and dual stators sandwiching a rotor disk which serves as the flywheel energy storage mechanism. During the 45 second charge period power from the ship's zonal DC distribution system is fed into the alternator and the permanent magnet motor is used to spin the rotor disk up to a speed of 6400 rpm which results in the rotor storing 121 MJ of kinetic energy. Each alternator is around 89% efficient and is liquid cooled using a 50/50 ethylene glycol and water (EGW) mixture with a coolant flow rate of 150 liters per minute for each alternator. For launch the 484 MJ of energy stored in the four alternators is released in a 2 second pulse through a cycloconverter circuit with a peak power output into the circuit of of 326.4 MW. The cycloconverter is required to dissipate up to 528 kW of thermal energy and employs a cold-plate liquid coolant system using 50/50 ethylene glycol and water (EGW) coolant with a flow rate of 1400 liters per minute. The launch motor is a linear synchronous motor 103 meters long with a trough in the flick deck containing twin vertical stators running the length of the trough and carriage acting as the rotor which contains 160 35 MGOe (Mega Gauss Oersteds) neodymium iron boron (NdFeB) magnets along with a shuttle attached to the carriage which protrudes above the trough and attaches to the aircraft to be launch. A series of rollers are welded to the carriage which contain the carriage's travel in the vertical and horizontal directions and allow the trough to flex and twist with ship motion while retaining a constant air gap between the carriage magnets and the linear stators. The end of the 103 meter trough contains a series of eddy current brakes consisting of shorter reverse wound stators which cause the carriage to rapidly brake when it reaches the end of the trough. A spray water cooling is used to cool the launch motor between launches which cools the linear motor stators down to 75°C from 150°C in the 45 second recharge period between launches. Each electropult including launch motor, compensated pulsed alternators, cycloconverter, and associated cooling and power conversion hardware is its own entirely self contained assembly which allows any of the four electropults to be serviced or replaced independently of the other three.

Arresting gear: The Inflictor employs a conventional hydraulic arresting gear mechanism designed to catch and decelerate aircraft which land on the carrier's flight deck. The flight deck contains four arrestor wires spaced 15 meters apart which are each connected to an arresting gear mechanism below the flight deck. The arresting gear system is a hydro-pneumatic mechanism comprising a hydraulic cylinder and ram assembly, a crosshead with fixed pulleys, control valve system, hydraulic accumulator system, pneumatic air flasks, and an arresting cable. When an aircraft lands on the carrier the aircraft's tailhook catches the arresting cable spanning the flight deck. The forward momentum from the aircraft is then transferred from the arresting wire through a series of pulley mechanisms to the hydraulic accumulator system below decks. Through a set of moving pulley mechanism two ends of the cable pull on a moving crosshead running parallel to the hydraulic accumulator mechanism which forces a ram into the hydraulic cylinder filled with pressurized ethylene glycol hydraulic fluid. The force of the ram entering the cylinder forces the hydraulic fluid out of the cylinder through a metered control valve into a hydraulic accumulator until the aircraft's momentum has been completely absorbed and the aircraft has come to a stop. After the aircraft's tailhook has been disengaged from the control cable a valve in the accumulator is opened and high pressure air from the system's pneumatic air flasks is used to push the hydraulic fluid back into the cylinder which in turn retracts the ram and crosshead mechanism and pulls the arresting cable back to its original position.

Aircraft Elevators: The flight deck of the Inflictor has four aircraft elevators, one on the port side and two on the starboard side, which move aircraft between the flight deck and hangar. Each aircraft elevator is 26 meters long, 15 meters wide, and weighs 110 metric tons. The elevators are hydraulically driven and have the capacity to lift 90,000 kg; enough to accommodate two fully fueled and armed strike fighters or naval bomber.


Automated Weapons Handling System:
The Inflictor has a a fully automated Mechanized Weapon Handling System (MWHS) which moves palletized munitions to and from the magazines, hangar, transient weapons storage areas, and the flight deck using an all-electric control system without the intervention of human crew members. The Mechanized Weapon Handling System significantly reduces manning requirements aboard the ship and is designed to enable "just-in-time" delivery of ordinance to aircraft awaiting re-arming on the flight deck in order to significantly improve aircraft turnaround times and sortie generation rates. The Mechanized Weapon Handling System can contain up to 4,800 tonnes of aircraft ordinance, sufficient for up to 21 days of continuous flight operations before the carrier must be replenished.

The Mechanized Weapon Handling System is designed to interface with weapons stored as all-up-rounds (AURs) in identical modular weapon containers which interface to the ship's Aircraft Weapons Management System (AWMS) which tracks the location and status of each weapon throughout the handling process. The Aircraft Weapons Management System (AWMS) is used to provide accurate and real-time aviation ammunition inventory management, manage ammunition storage and distribution, and provide real-time tracking of ammunition handling on the ship. Each modular weapon container measures 6.0 x 1.0 x 1.0 meters and can contain a single RBS 87, RBS 110, GB 1000, or DWS 1000 missile or munition, one AM70 mine, two Rb 100 missiles, two F3S torpedoes, two AM88 or AM105 mines, four Rb 80 missiles, or six RBS 90, RBS 93 or GB 100 munitions. Containerized weapons are first loaded through the cargo ramp on the starboard side of the ship to the hangar where they are then transferred down below using eight weapons transfer elevators into the ship's two four-story tall magazines which are located underneath the hangar bays along the centerline of the ship in between and forward of the ship's two nuclear propulsion plants. Expended weapons containers located in the magazine are also retrograded at the same time using the weapons transfer elevators. Each of the two magazines is divided longitudinally into two storage areas served by two magazine weapons shuttles. Each storage area has 800 weapon slots which can each store a single 6.0 x 1.0 x 1.0 meter modular weapon container, giving the ship the capability to store a total of 3,200 modular weapon containers. In order to prevent fires and blasts from spreading throughout the magazines the magazines and lifts are subdivided using a series of 36 blast-resistant mechanized doors, the largest of which are 3 meters wide, 6 meters tall, and weigh over 6 tonnes. When the ship's Aircraft Weapons Management System (AWMS) requests an ordinance delivery for an aircraft (including specified ordinance loadout and on-deck re-arming time) the shuttles in the magazines are used to extract the weapons from each container and transfer it to one of eight weapons transfer elevators which then move the individual weapons up through inclined elevator shafts to the mission weapons carrier gallery located beneath the hangar. Inside the mission weapons carrier gallery are a series of mission weapons carrier pallets which are then gather and transport all weapons needed needed for an aircraft mission as specified by the Aircraft Weapons Management System. Each mission weapons carrier pallet travels lengthwise along the mission weapons carrier gallery where it stops at the necessary weapons transfer elevators to acquire the specified mission weapons load for a particular aircraft and then travels laterally to one of four deck transient weapon stowage centers located in the ship's port side sponsons. In the deck transient weapon stowage centers the weapons from the weapons carrier pallet are loaded using robotic arms onto weapons handling robots which then travel up of four weapons carrier elevators up to the flight deck. On the flight deck the weapons handling robots then transport and load the weapons onto aircraft waiting on the flight deck to be armed or re-armed. De-arming of aircraft is accomplished by reversing the process, allowing ordinance from aircraft on the flight deck to be rapidly returned to the ship's magazines.

The 12 elevators including the 8 weapons transfer elevators and 4 weapons carrier elevators which are included in the Mechanized Weapon Handling System are electrically driven maglev-type cordless elevators which can each lift up to 10,000 kg of bombs, missiles, and other munitions at a rate of up to 50 meters per minute. The elevators are driven using linear motors attached to the four base corner points of each elevator platform, each gripping aligned magnetic levitation tracks which pull the elevators up the inclined elevator shafts inside the ship. The linear motors consist of an ironless long-stator linear synchronous motor consisting of coil units arranged in a double array configuration along the corners of the elevator shaft which are driven by compact, SiC IGBT based inverter units distributed along the elevator shafts. The linear motors are driven by a set of DC busbars in each elevator shaft which are supplied from the ship's zonal DC power distribution system. The position of each elevator is controlled using inductive influence sensors and each elevator includes two mechanical braking systems including an operation brake and an emergency brake. The elevators can move up and down and left to-right inside a series of inclined elevator shafts, significantly speeding up the entire weapons delivery process.


Passive Protection & Damage Control:
In addition to active protection systems and various electronic warfare and decoy systems the Inflictor class supercarrier features significant amounts of passive protection including several thousand tonnes of armor which are designed to increase the ship's resilience to missile, bomb, torpedo, and mine attacks. The ship is divided by 23 longitudinal bulkheads and has a triple bottom covering over 80% of the ship's length. Covering the ship's below-deck hangar, propulsion and machinery plants, steering gear, aviation fuel tanks, magazines are armored boxes made from 50 to 80 mm thick welded Ti-6211 titanium alloy plates backed by a spall liner consisting of composite panels made from S-2 glass fibers embedded into an epoxy resin matrix. The ship's side protection systems (SPS) covers approximately 80% of the ship's waterline length consist of four internal longitudinal bulkheads behind the outer hull plating. The outer two compartments are liquid loaded with jet fuel or seawater while the inner compartments are voids. The side protection system has a depth of 9.0 meters in the central portion of the ship. and is intended to resist the detonation of a 1,000 kg TNT charge. The side protection system also allows lists from flooding to be corrected by counterflooding empty void compartments and/or draining the liquid filled compartments.

Damage control on the Inflictor is largely automated due in parts to SDI Naval Systems developed Automated Ship Control System (ASCS). The ASCS is controlled by a centralized computer which amongst other functions provides real-time damage information to the crew through a graphical display located in the ship's damage control center. Additionally both the ship's bridge and CIC also also fitted with displays connected to the ASCS. The ACSC is designed to run automatically where after the ASCS detects damage to a compartment it will immediately isolate it and activate appropriate damage control measures. Alternatively the ASCS can be set to manual mode where the operator will have to specify the damage control measures after the system detects ship damage. The ASCS also controls and monitors the ship's engines and machinery and will alert engineers on watch duty through their assigned tablet computer when an engineering issue or machinery failure is detected and requires attention. This remove the need for time based maintenance, the system will simply alert the crew when a component or system requires maintenance. Each compartment and each piece of machinery on the ship are monitored using SDI's Two Wire Automatic Remote Sensing Evaluation System (TWARSES) which includes both visible CCD and infrared cameras located in each ship compartment. After damage is detected in a compartment the ASCS can respond in a variety of ways including isolating the damaged compartment by closing the electrically actuated watertight doors around the compartment. If the IR camera detects a fire the system will activate the compartment's overhead sprinklers and can also pump the compartment with aqueous film-forming foam (AFFF), high velocity fog, and/or carbon dioxide agents if necessary. After the fire is extinguished water and firefighter agents are removed using a bilge draining pump installed in each compartment. The ASCS will also reroute ventilation, electrical power, and water around the damaged area and activate additional pumps, generators and other devices if necessary. If the compartment has been breached and is in danger of flooding the system will flood the compartment with foam which rapidly solidifies and restores reserve buoyancy. This system however is only used as an absolute last resort as it renders the compartment unusable. The ASCS also controls the ship's CBRN protection system by passing air from the ventilation intakes through containment filters before it enters the ship. Air in the ship is maintained at 5.0 millibar above local atmospheric pressure to provide a positive pressure and prevent contaminated air from entering into the ship through a breach in the hull.

In addition to the ASCS system the ship's flight deck features its own separate aqueous film-forming foam (AFFF) washdown system to combat fires on the flight deck. The flight deck is divided into 24 firefighting zones with several hundred flush-deck and deck-edge nozzles mounted in the flight deck capable of delivering up to 4,000 liters of AFFF solution to each firefighting zone. Each of the carrier's four aircraft elevators also contains four nozzles capable of spraying up to 150 liters per minute of AFFF solution onto each elevator. The deck washdown system for each firefighting zone is activated manually through operator panels located in the primary flight control tower and the navigation bridge. The flight deck also contains 26 AFFF hose stations which also contain portable PKP and CO2 fire extinguishers.


Armament:
S70 Vertical Launch System The Inflictor class ship is fitted with 64 total S70 vertical launch cells located in eight 8-cell modules mounted in port sponsons located on the sides of the ship's twin island superstructures. The S70 is a cold-launch system which uses missiles encased in individual concentric launch cells as modular all-up rounds (AURs) each containing the missile, concentric launch tube, launch tube electronics, and missile ejection system. The launch cells are inclined at a 10 degree angle towards the ships centerline to prevent missiles with malfunctioning rocket motors from crashing back onto the deck after launch. Each launch cell is capable of accommodating either a single launch tube which can contain a missiles with a maximum length of 7.0 meters, diameter of 0.6 meters, and a weight of 2,500 kg. The missiles are ejected from each launch tube using a steam generator system which uses a small solid-propellant gas generator which exhausts through cooling water into the base of each launch cell, creating expanding high pressure steam which then forces the missile out of the launch tube. Safety and passive protection features of each VLS module include concentric anti-fragmentation shields placed around each launch cell tube to prevent in-cell missile fratricide and a deluge system which can flood each 8 cell module in the event of a missile catching fire in the launch tube. Launch tubes are connected to the launch cells through shock collar that is designed to absorb acceleration loads from an underwater detonation near the ship. The individual missile cells are connected to the ship's weapon control system via redundant port, central, and starboard fiber-optic Ethernet lines which transmits launch commands to the individual missiles and allows for missile status information before launch to be sent back to the weapon control system.
Last edited by The Technocratic Syndicalists on Sat Mar 28, 2026 8:20 pm, edited 74 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Sun Aug 28, 2016 12:06 pm

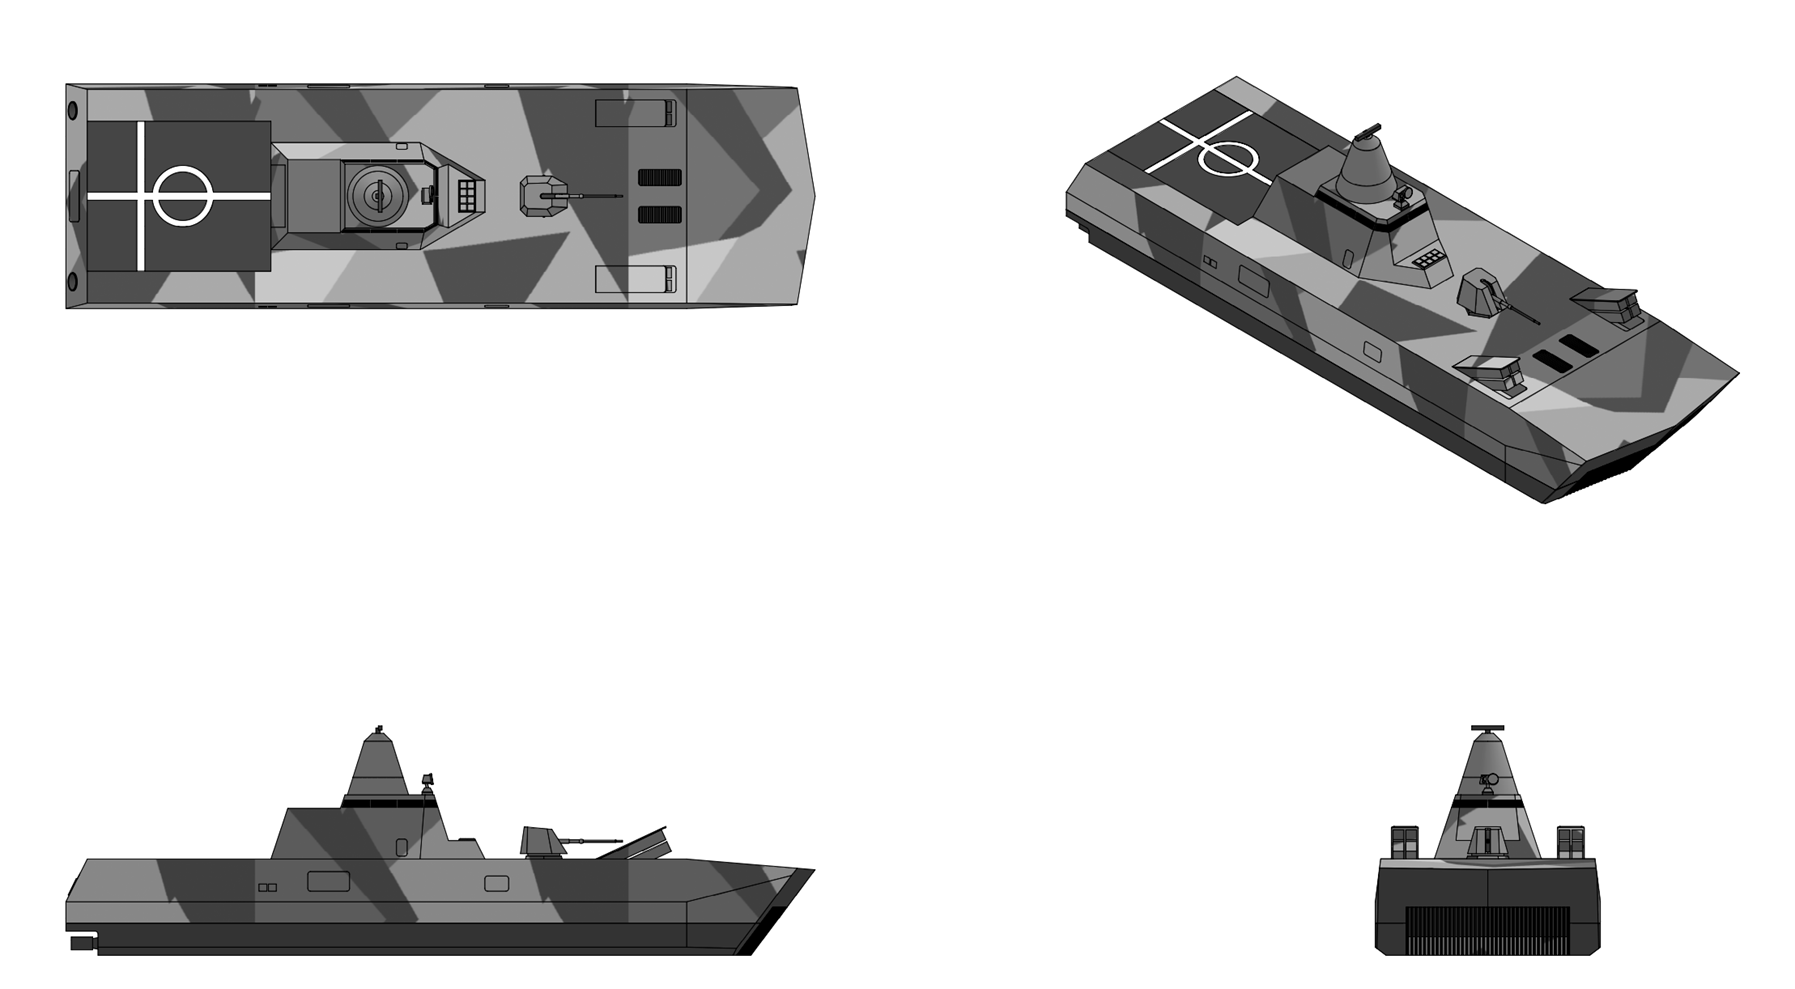
Image


Tempest Class Ballistic Missile Defense Cruiser

Basic Information:
  • Type: Guided missile cruiser
  • Displacement: 27,200 t (full load)
  • Complement: 300-450
  • Length: 250 m
  • Beam: 30.0 m
  • Draft: 9.0 m
Installed Power:
  • 1x SDI PWR 175 pressurized water reactor, 700 MWt
  • 2x AMG 16V 17/19 M64 diesel generators, 2,000 kWe each
Propulsion:
  • 2x SDI high temperature superconducting (HTS) AC Motors, 50 MW each
  • 2x shafts, 5 bladed fixed pitch propellers

Performance:
  • Top Speed: 33 knots
  • Range: crew endurance
Sensors and Processing Systems:
  • SDI Typhoon Combat System
  • SDI FMG 300E X band Multi-Function Radar (MFR)
  • SDI FMG 600E S band Volume-Search Radar (VSR)
  • SDI Integrated Bridge and Navigation System
  • SDI EOS 400 Staring Infrared Search & Track System
  • SDI FLG 200 Radar & Electro-Optical Fire Control System
  • SDI Sea Lance Undersea Combat System
  • SDI RMS 800 Hull-mounted mid-frequency sonar
  • SDI RMS 810 Hull-mounted high-frequency sonar
  • SDI VTS-830 Variable-depth sonar

Electronic Warfare and Countermeasures:
  • SDI FMS 1800 Electronic Warfare System
  • SDI LWG 310 Naval Laser Warning System
  • SDI ZTKG 130 Trainable Decoy Launching System (TDLS)
  • SDI Sea Guardian Surface Ship Torpedo Countermeasure System

Armament:Aircraft Carried:


Overview:
The Tempest class cruiser is a large nuclear powered guided missile cruiser designed by SDI Shipbuilding Systems. The Tempest are designed primarily to act as anti-aircraft warfare (AAW) and ballistic missile defense (BMD) ships with secondary anti-submarine warfare (ASW), naval gunfire support (NGFS), and anti-surface warfare (ASuW) capability.


Design & Construction:
The Tempest class features a distinctive wave-piercing tumblehome hullform which provides minimal hull RCS while remaining within acceptable stability margins and seakeeping performance qualities. The hull is 260 meters long and 30 meters wide at the waterline and is divided into twenty-two watertight compartments with a triple bottom for 80% of the length of the hull. The hull is constructed from St 92 (900 MPa yield strength) high-strength structural shipbuilding steel and features 100% welded construction. The ship's seven-level low-RCS trapezoidal shaped deckhouse superstructure measures 54 meters long by 24 meters wide by 20 meters tall and contains the aviation hangar, aviation control center, bridge, weapon and electrical shops, infrared and EW sensors, communications sensors, and the ship's dual band radar system which along with its associated cooling and power systems occupies the majority of the upper levels of the deckhouse. The deckhouse features a space-frame construction am internal load-bearing structure made from St 92 steel which is covered by large carbon fiber composite panels which form the outer low-RCS shell of the deckhouse. The composite panels employ a honeycomb sandwich design with 3D-woven carbon fiber reinforced vinyl ester skins 2-3mm thick formed with vacuum assisted resin transfer molding (VARTM) sandwiching a foam honeycomb core 50-80mm thick.


Propulsion:
The Tempest class is powered by a single SDI PWR 175 pressurized water reactor with a rated maximum power output of 700 megawatts of thermal energy (MWt).The reactor is fueled using 97% highly enriched uranium (HEU) and is designed for a service life of over 40 years without refueling. The SDI PWR 175 reactor employs integral type circuit design with all primary circuit components including the steam generators are placed inside the reactor pressure vessel. The emergency core cooling system (ECCS) employs our separate systems including a gravity driven water injection system, pressure injection system, passive decay and heat removal system (PDHR), and a reactor protection system (RPS). The reactor core has an active length of 2.4 meters and contains 89 fuel assemblies containing binary U-Zr metallic nuclear fuel pellets consisting of 15% zirconium and 85% uranium enriched to a level of 97% U235 with a boron burnable poison coating which gives the reactor a design service life of 45 years before requiring refueling. Pumping for each reactor is provided by four horizontally mounted axial flow pumps attached to the outer shell of the reactor vessel which each provide a flow rate of 95,000 liters per minute (LPM) of cooling water through the reactor core. Each pump is powered by a 500 kW, 460 VAC 3 phase brushless AC motor driven by a variable a frequency drive (VFD). Steam from the reactor is used to drive two turbogenerators which each employ a double-ended turbine which drives a 120 Hz, 6 phase, 4160 VAC, 87.5 MW, 3600 rpm high-temperature superconducting (HTS) AC generator. The 175 MWe of electrical power from the two turbogenerators is distributed throughout the ship using a DC zonal electrical distribution (ZEDS). The 4160 VAC from the four turbogenerators is converted to to 6000 VDC with four power conversion modules (PCMs) attached to each generator. The PCMs then supply both port and starboard DC buses which supply power to 16 electrical zones which each include one DC/DC PCM per bus (two each per zone) which converts the 6000 VDC to 750-800 VDC or 650 VDC to supply DC loads in each zone. Both DC/DC PCMs in each zone also supply one or more DC/AC PCMs with 750-800 VDC which then converts the 750-800 VDC to 450 VAC at 60 Hz for AC loads. All electrical loads in each zone are connected to both port and starboard bus ensuring continued operation if either port or starboard bus becomes inoperable.

The warship's integral electric propulsion (IEP) system includes two SDI designed 50 MW superconducting motors which directly drive the ship's two propellers. Each 50 MW superconducting motor is a three phase, six pole synchronous air-core AC motor with a brushless exciter which has a rated speed of 150 RPM at its design voltage of 7,200 VAC with a full-load efficiency of 97.5%. The complete motor with cryocooler assembly weighs 75 tonnes, approximately 80% less than a conventional AC induction motor of the same RPM and power output. The rotor employs yttrium-barium copper-oxide (YBCO) high temperature superconducting ceramic conductors and is cryogenically cooled to 77 degrees K using gaseous helium from cryocooler module containing single Stage GM cryocoolers located at the non-drive shaft end of the motor which feeds helium gas into the rotor through a rotating seal at the back end of the motor. The rotor housing is further enclosed in a vacuum-sealed cryostat to maintain cryogenic temperatures inside the rotor. The stator coils of the motor are made from copper litz conductor and are cooled using a liquid dielectric coolant. Each motor employs a variable-frequency drive (VFD) with three separate 2,400 VAC three-phase power modules per drive which allows for efficient motor operation from 6 up to 150 rpm. Each 50 MW motor is used to directly drive a single 7.5 meter diameter 5-bladed fixed pitch propeller (CPP) located at the end of a carbon fiber reinforced plastic (CRFP) alloy propeller shaft.


Sensors & Processing Systems:
SDI Typhoon Combat System: The SDI Typhoon Combat System (TCS) is a comprehensive open-architecture anti-aircraft warfare (AAW) combat management system designed by SDI Missiles & Fire Control Systems which provides fully automated detection, identification, and engagement of air targets. The primary components of the Typhoon Combat System are the Sensor Fusion Processor (SFP), Command and Decision System (C&DS), Typhoon Display System (TDS), Weapons Control System (WCS), and Integrated Ship Computing System (ISCS). The sensor fusion processor or SFP takes tracking data from the ship's radars, IFF system, distributed IRST sensors, and electronic warfare system and correlates them using a contact-to-track data correlation algorithm to provide a single integrated track of each detected target. With the contact-to-track algorithm detected contacts from each sensor (radar, IFF, IR, and ESM) are correlated with existing sensor tracks and merged using a smoothing filter to create a single track file of each correlated target. This allows (for example) the range data from the radar tracks of the dual band radars to be fused with the angle track data from the higher angular resolution IRST sensors, creating a fused 3D track which is more accurate than either the individual radar or IRST sensor tracks. Track data from the sensor fusion processor is fed into the Typhoon Command and Decision System (C&DS) which uses both IFF data and aided and automatic target recognition (Ai/ATR) algorithms to provide identification, threat classification, and weapon assignment of target data input from the sensor fusion processor. Information from the Command and Decision System (C&DS) processor is displayed via the Typhoon Display System (TDS) which uses large multi-function color displays inside the ship's CIC to display target tracks and other situational awareness data to the ship's crew and captain. The TDS consoles also features keyboards for data input which allows doctrinal IF/THEN instructions to be input to the system to the modify its behavior; such as instructing the system that IF any target is detected above a certain speed and altitude in a certain sector THEN it is to be automatically classified as hostile and engaged with a certain missile. The Weapons Control System (WCS) is responsible for launching missiles at targets identified as hostile by the Typhoon Command and Decision System (C&DS). Targets are matched to the ship's missiles by the C&DS which will then send a fire instruction to the weapon control system when the target has entered the engagement zone of the specific missile. The WCS then sends a a firing instruction to the ship's VLS to fire the specific missile and then uses the ship's radars and datalinks to provide midcourse guidance as necessary to guide the missile towards its intended target. The WCS is also responsible for providing Air Intercept Control (AIC) functionality and can be used to guide carrier or land based airborne interceptors towards a hostile target being tracked by the ship. Finally the Integrated Ship Computing System (ISCS) acts as the central processor of the Typhoon combat system and processes radar and and other sensor data and connects all the ships systems including weapons, countermeasures, and communications system together. The ISCS architecture is based on SDI's SPPC10D single-board computer, a ruggedized, shock hardened and conduction cooled computer which employs a 10nm gallium nitride (GaN) on silicon architecture, 48 core (384 thread) superscalar symmetric multiprocessor with a 4.0 GHz clock rate as well as 64 GB of DDR5 DRAM. The SPPC10D computers are each packaged into 16 Electronic Modular Enclosures (EMEs) which each include their own power, shock, vibration, and electromagnetic protection, and water cooling systems. Each EME is a self-contained server and carries 235 cabinets containing the SPPC10D single-board computers. The EMEs which run the ISCS software are interconnected to the rest of the sensors and electrical systems through fiber-optic cables and uses voice-over IP for internal communications between computer systems. The combined computing power of the ship's processors is 27,000 MIPS (million instructions per seconds) at 4.35 GHz with a combined 240 TB of data storage.

An additional ability of the Typhoon Combat System is Distributed Engagement Capability (DEC) which allow target tracking data from multiple sensors across multiple Typhoon equipped platforms in the battle group to be fused together to create a composite track of all air objects within the battle force area and to allow for hunter-killer functionality in the battle group by allowing unit in the battle force to engage a target being tracked by another unit even when the shooter is unable to see or track the target with its own sensors due to either jamming, battle damage, or line-of-sight restrictions. Distributed engagement capability on Typhoon equipped platforms s enabled by a data distribution system (DDS) and a track fusion algorithm (TFA). The data distribution system or DDS consists of four C band planar array antenna assemblies blended into the outer surface of the ship's superstructure which provide extremely high bandwidth line-of-sight communication capability with other sea and air platforms in the battle force. Each DDS antenna array consists of a liquid cooled digital beam forming (DBF) antenna with separate transmit and receive arrays employing gallium nitride (GaN) monolithic microwave integrated circuit (MMIC) transmit/receive (T/R) modules integrated into a common subarray line replacement units (LRUs) and high provides extremely jam resistant and high bandwidth line-of-sight data exchange with other DDS equipped platforms. The track fusion algorithm (TFA) uses the ships ISCP processors to take sensor data received by other units through the data distribution system and fuse it with data from the ships own sensors to create a single composite sensor picture. The main capability of the track fusion algorithm is the ability to network the measurements of radars and other sensors on different platforms tracking the same target and combine them with an intelligent averaging algorithm that creates a single composite track of the target which is more accurate than the track of any individual sensor. When a Typhoon equipped platform establishes a target track with one or more of its sensors a track alert is broadcast across the Typhoon network which then cues the other platforms in the battle force to point their sensors in the direction of the target track. When the other platforms begin tracking the target with their own sensors their sensor measurements are distributed back across the network to every other platform to form the composite track. This capability allows the battle force to maintain track of a target even if any one or even multiple of the battle force units loses the target track due to jamming, battle damage, or environmental effects. When used to fuse radar data from different platforms the track fusion algorithm also enables better radar observation of low observable targets by illuminating them simultaneously with many radars of different wavelengths and scan rates at once, allowing a composite track to be created even if none of the radars in the battle force are able to generate an individual track of the target for more than a few pulses.

FMG 300E/600E Dual Band Radar (DBR): The SDI Dual Band Radar (DBR) system includes the ships FMG 300E X band Multi-Function Radar (MFR) and FMG 600E L band Volume-Search Radar (VSR). The system is built on the same architecture as the base DBR system but with radar arrays 225% larger and with 250% more power than the base DBR system to better track ballistic missile targets at strategic ranges. Each radar system consist of three phased-array antennas and associated receiver/exciter (REX) cabinets above -decks in the superstructure and a signal and data processor (SDP) system mounted below-decks inside the hull. Both arrays share a central controller and and a common array power system (CAPS) with power conversion units (PCUs) and power distribution units (PDUs) for each radar antenna. Both arrays are cooled using a closed loop, phase change based common array cooling system (CACS). The X band radar system features a larger operating bandwidth and better low-altitude performance and provides surface search, radar navigation, gun-fire targeting and splash spotting, periscope detection, mine detection, precision target tracking and discrimination, limited volume-search, high-bandwidth missile uplink, and terminal illumination of targets while the S band radar provides long range volume search and long-range target tracking capability. Both the The X band and S band radars can provide simultaneous sector search, environmental mapping, counter-fire/counter-battery tracking, missile tracking, electronic warfare, clutter detection, and in-flight missile guidance and communication. Each X band FMG 300E aperture has a 9 meter square antenna with 26,400 transmit and receive (T/R) modules employing gallium nitride (GaN) complementary metal-oxide semiconductors (CMOS) on a diamond substrate. The S band FMG 600E antennas are placed below the X band arrays and are significantly larger at 36 square meters and each use 95,040 S band GaN-on-diamond transmit and receive (T/R) modules. Each radar antenna features +/- 60° azimuth and +/- 60° degree beam-steering capability giving the system combined 360° azimuth coverage around the warship. Both radar systems employ wide-band digital receiver/exciter (DREX) units and feature digital beam-forming (DBF) capability, space-time adaptive processing (STAP), and multiple-input multiple-output (MIMO) waveform generation techniques. ECCM capabilities of the dual band radar system include frequency-modulated continuous-wave (FMCW) operating modes, ultra-low sidelobes, high processing gain, pulse-to-pulse frequency agility and ultra wide-band frequency hopping, staggered pulse repetition frequency (PRF) switching, randomized burst transmissions, and automatic jammer detection and tracking. Peak power consumption of the dual-band system is 30 MW and instrumented range is 1,500 km in air-surveillance mode and 3,000 km in ballistic missile tracking mode with the ability to simultaneously track up to 6,000 air targets in air surveillance mode or up to 60 ballistic missile targets in ballistic missile tracking mode.

SDI EOS 400 Staring Infrared Search & Track System: The SDI EOS 400 Staring Infrared Search & Track System is a distributed multi-aperture sensor system which consists of five identical mercury cadmium telluride (HgCdTe) starring focal plane array (FPA) imaging infrared (IIR) sensor units placed around the ship's superstructure which provide combined 360°azimuth and -20° to +75° elevation situational awareness infrared search and track (SAIRST) capability against surface vessel, cruise missile, ballistic missile, and aircraft targets to supplement the active search and track capability of the ship's dual band radar system. The 4096 × 4096 pixel (16 MPA) HgCdTe sensor used by each sensor head operates in the MWIR (3–5 µm) band and features a 95 x 95 degree field of view. The image processing features of the SIRST system include automatic target recognition (ATR) using an on-board threat library, passive ranging algorithms, multi-target adaptive tracking, and clutter rejection techniques. The video feed from the sensor units can be stitched together and displayed on operator consoles in the ship's bridge and CIC to act as a navigational aid and to provide close in situational awareness for the ship's crew.

FLG 200 Radar & Electro-Optical Fire Control System: For short range surface target tracking and gunfire control the ship is equipped with an SDI FLG 200 combined radar and electro-optical fire control director mounted forward atop the superstructure. The FLG 200 contains both a Ku band (15.5 - 17.5 GHz) solid state radar and an electro-optical suite containing a thermal imager, television camera, and laser rangefinder which is intended to track both surface targets and subsonic and supersonic sea-skimming missiles in close proximity to the vessel and provides sector search capability, missile launch detection and tracking, and own ship gun fire projectile tracking and splash point detection. The Ku band monopulse radar employs a solid-state Cassegrain antenna connected to a digital receiver and signal processor and transmits with a peak power of 1.5 kW and has a maximum instrumented range of 36 kilometers. The radar is designed with a high level of ECCM features including extremely low sidelobes, high instantaneous bandwidth, and high frequency agility. The electro-optical suite consists of a 1280 x 1024 pixel Midwave IR (3–5 µm) thermal imager with 0.92° to 30.0°horizontal field-of-view and 30x continous optical zoom, 1920 x 1080 pixel CCD daylight television camera with 64x continuous optical zoom, and an Nd:YAG OPO-shifted 1.54 μm eye-safe laser rangefinder with 50m to 40 km range and <1 meter accuracy. The electro-optical system features automatic tracking of up to four simultaneous targets, automatic sector surveillance, simultaneous TV and IR tracking and sensor fusion, recording capability, and integral GPS interferometer system (GPSIS) for far target location (FTL) capability using the system's laser rangefinder to provide 10-digit grid geo-location of surface targets accurate to within 60 meters at ranges up to 40 kilometers. both radar and electro-optical systems are enclosed in a low-RCS triaxially stabilized mounting capable of elevating from -20 to +120° at a rate of 160 °/s and training a full 360° at a rate of 140 °/s.

SDI Sea Lance Undersea Combat System:The SDI Sea Lance Undersea Combat System is the primary undersea combat system fitted to all SDI surface combatants and is designed to detect, locate, track, and engage submersible targets. The Sea Lance system transmits and receives acoustic signals to provide target classification, time motion analysis, and control of anti-submarine and anti-torpedo weapon settings. The Sea Lance system provides multi-sensor track correlation, target track management control, and forwards data to the ship’s command and decision system. The Sea Lance system comprises the RMS 800 hull-mounted mid-frequency sonar; the RMS 800 hull-mounted high-frequency sonar; and the VTS 830 Variable depth sonar. The system provides surface warships with a seamlessly integrated undersea/anti-submarine warfare detection, localization, classification and targeting capability. The system presents an integrated picture of the acoustic tactical situation by receiving, combining and processing active and passive sonar sensor data from the systems twin hull arrays, towed array, and sonobuoys dropped by the ship's ASW helicopter aircraft.

RMS 800/810 Dual-Frequency Hull Array: The SDI Underwater Systems RMS 800/810 dual-frequency hull array assembly is mounted in the ship's bulbous bow and contains both a medium frequency active/passive sonar for submarine detection and a high-frequency mine avoidance sonar. The RMS 800 and RMS 810 sonars have separate transmit and receive arrays but share a common power supply unit and common transmission/reception cabinets, sonar processing unit, and operator consoles. The mid-frequency RMS 800 sonar is a long-range echo ranging sonar with an active frequency range of 6.0 to 9.0 kHz with hyperbolic frequency modulated (FM) and continuous wave (CW) pulse modes with pulse lengths of 60 ms to 4 s. Passive frequency range of the RMS 800 is 1.0 to 9.0 kHz and supports both LOFAR (Low-Frequency Analysis and Recording) and DEMON (Demodulation of Envelope Modulation On Noise) signal processing capability. The RMS 800 sonar features complete 360° detection performance and supports surface duct, bottom bounce, and convergence zone propagation with a maximum detection range out to the first convergence zone of 30-35 nm (55-65 km). The RMS 810 high frequency array is mounted conformally with the RMS -800 mid-frequency sonar and provides detection of moored mines, underwater obstacles, torpedoes, divers, and small underwater vehicles ahead of the ship. The RMS 810 features an active array with a frequency range of 70 to 100 kHz with hyperbolic frequency modulated (FM), linear frequency moduled (LFM), and continuous wave (CW) operating modes and can scan +/- 90° off the ship’s centerline with a maximum detection range of 2.6 kilometers. Both sonars employ a space-time adaptive processing (STAP) algorithm designed to enable adaptive beamforming capability to enable the array to create a virtual 3-dimensional image of sonar contacts in order to accurately separate targets from decoys and from clutter present in littoral waters while also minimizing sonar sidelobes and enabling adaptive angle estimation to more accurately determine target depth, bearing and speed.

VTS 830 Variable depth sonar: The SDI Underwater Systems VTS 830 is an active/passive low-frequency variable-depth sonar designed to detect submarines in both deep blue ocean and shallow littoral environments. The complete VTS 830 system consists of hydrodynamic towed body with active transmitter, passive receive array, towed array handling system with twin winches to deploy and tow the tow body and receive array, shipboard signal transmitter and receiver, and operator control system with four multifunction consoles. The VTS 830 supports low frequency active detection (0.9 to 2.1 kHz) and ultra-high, medium, and low-frequency (<0.1 to 100 kHz) passive detection and environmental monitoring. The sonar employs an omnidirectional transmitter with continuous wave (CW) and low-powered/hyperbolic frequency modulated (LPFM/HFM) pulse modes and multiple receivers including a very low frequency active line array receiver, medium frequency (MF) directional array, and four spherical ultra-high frequency (UHF) hydrophone arrays. The towed body is designed to be towed at depths up to 250 meters with a designed tow speed of 18 knots and a maximum tow speed of 30 knots. The variable-depth sonar can be used in up to sea state 6 and is designed to detect undersea targets out to the second sonar convergence zone (~130 km).


Electronic Warfare & Countermeasures:
FMS 1800 Electronic Warfare System The primary electromagnetic countermeasure system of the Tempest class cruiser is the FMS 1800 Electronic Warfare System, a comprehensive offensive and defensive electronic warfare (EW), electronic support measures (ESM), and electronic intelligence (ELINT) suite which combines passive radar warning receivers and phased array jammers for long range, over-the-horizon detection, identification, and targeting of threat emitters as well as automatic employment on-board RF countermeasures and support of passive over-the-horizon targeting capability for the ship's weapon systems. The passive radar warning system of the FMS 1800 consists of multiple single-quadrant, high-gain linear interferometer arrays smoothly blended into the superstructure of the vessel connected to a set of digital receivers and pulse processors inside the ship's superstructure which provide for 360° spherical broadband, all aspect detection, identification, and direction-finding of radar emissions in the 0.5 to 40 GHz range and communications in the 30 to 3,000 MHz range with the capability for <1° RMS direction finding and precise emitter location and threat identification capability against low probability of intercept waveforms and with additional over-the-horizon direction finding capability of HF, VHF, and UHF band signals. The offensive electronic warfare capability of FMS 1800 system includes multiple low, mid, and high band electronically scanned gallium nitride (GaN) based Digital Radio Frequency Memory (DRFM) jammers blended into the superstructure which provide for the jamming of hostile RF sensors in the 2 to 40 GHz range.

LWG 310 Naval Laser Warning System: For detecting laser sources including laser range finders, laser target designators, and laser beamriding missiles the ship's FMS 1800 system is augmented by an SDI LWG 310 Naval Laser Warning System. The vessel's LWG 310 installation consists of a central controller connected eight sensor heads, four on each side of the superstructure, providing combined 360° coverage around the vessel. Each individual sensor head features 110° azimuth and +/- , 70° elevation coverage and is capable of detecting up to eight simultaneous laser range finders laser target designator emissions in the 0.5 μm - 1.65 μm range and laser beamriders in the 0.8 μm - 1.1 μm range.

SDI Sea Guardian Surface Ship Torpedo Countermeasures System: The ship is fitted with the SDI Sea Guardian Surface Ship Torpedo Countermeasure System which combines various soft-kill and hard-kill torpedo countermeasure systems. The Sea Guardian system consists of a towed array sonar designed specifically for torpedo detection, a towed acoustic decoy with a a single-drum winch, an interface to the ship's trainable decoy launchers, and a processing cabinet with two display consoles, and and four 6-round anti-torpedo torpedo launchers on either side of the ship. The towed array sonar used by the system is a combined active and passive array sonar optimized to detect the high frequency sound signature of torpedo screws and active sonar homing heads. The towed array is supported by two vibration isolated modules (VIMs) located on either side of the sonar with the array being connected on one end to the ship using a fiber-optic tow cable and connected on the other end to the towed decoy with an array tow cable. The towed decoy array is designed to emit simulated ship noise such as propulsor and engine noise to lure a passive-sonar homing torpedo to the decoy instead of the ship. The towed decoy can also receive sonar pings from the active homing head of a torpedo and amplify and return the "pings" to the torpedo, presenting a larger false target to the torpedo. The hardkill component of the Sea Guardian system comprises a series of four box launchers on either side of the vessel which each contain six SDI S2s Barracuda anti-torpedo torpedoes in individual all-up rounds (AUR) which contain the Barracuda torpedo and a self-contained compressed gas launch system. The Barracuda torpedo is 21 cm in diameter, 2.0 meters in length, weighs 110 kilograms, and contains a 20 kilogram aluminized PBX explosive warhead. The guidance and fusing system of the Barracuda is designed to explode it in front of the oncoming torpedo and create a pressure wave which crushes the nose section of the oncoming torpedo. The Barracuda has a maximum firing range of 10 kilometers and is propelled by an advanced stored chemical energy propulsion system (ADSCEPS) which can propel the Barracuda at speeds up to 60 knots at depths up to 1,000 meters. Although designed as an anti-torpedo the Barracuda can also be used to engage midget submarines, naval mines, and unmanned or autonomous underwater vehicles.

ZTKG 130 Trainable Decoy Launching System (TDLS): The ZTKG 130 Trainable Decoy Launching System (TDLS) is an aimable decoy launcher which can launch a variety of decoys designed to decoy away anti-ship missile and torpedo threats. The ZTKG 130 system consists of multiple 12-round trainable countermeasures launchers controlled by a central command console inside the ship. Each 12-round launcher employs a rotating platform with 12 separate 130mm barrels which can each be individually trained in elevation. The ship is fitted with four decoy launching systems, two on either side of the ship used for acoustic torpedo decoys (24 total) and another two launcher on each side used for chaff/flare rounds and missile seduction decoys (24 total).

    AM5 dual chaff/IR seduction decoy:The primary chaff seduction round employed by the DLS is the AM5 dual chaff/IR seduction decoy which is capable of defeating dual-seeker missiles equipped with both IR/EO and radar seekers. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.

    AM79 Buzzard active missile decoy: For decoying away radar-guided anti-ship missiles the DLS can deploy the AM79 Buzzard active missile decoy, an expendable electronic-warfare rotary-wing drone which is designed to seduce RF guided anti-ship missiles by simulating the radar return of a large surface vessel. The buzzard features a cylindrical shaped fuselage 130 mm in diameter and 0.9 meters tall with both top and bottom mounted 1.8 meter diameter three-bladed counter-rotating coaxial rotors powered by two brushless DC motors. The rotors unfold from the body of the decoy after launch and fly the decoy into a pre-programmed flight path away from the ship where the decoy then hovers in place while emitting electronic warfare signals uses its fuselage mounted Digital Radio Frequency Memory (DRFM) jammers which are designed to seduce oncoming anti-ship missiles into targeting the decoy and not the host vessel. The decoy is powered by a thermal battery mounted in the center of the fuselage which gives the decoy approximately 60 minutes of flight endurance after launch.

    AM7 Lamprey acoustic decoy:The DLS can also launch the AM7 Lamprey, a 130mm diameter, expendable acoustic decoy designed to counter torpedo threats. After a rocket-powered launch into ocean the Lamprey is programmed to hover vertically using a pressure-controlled motor driving a small, shrouded propeller in the tail of the decoy. The Lamprey is designed to hover at a pre-selected depth from 10-300 meters where it listens for torpedo transmissions. Active acoustic transmissions are detected and analyzed resulting in decoy selectivity and generation of the appropriate deception signal for transmission including target signature and target self noise. If no torpedo transmissions are detected the decoy is programmed to emit warship propulsor and engine noise to lure in passive homing torpedoes. Power for the motor and electronics of the Lamprey is provided by a thermal battery. The Lamprey is programmed to hover and emit noise until the battery dies where the decoy then sinks and all software onboard is erased.


Signature Reduction:
the Tempest class features extensive radar and infrared signature reduction to reduce the ship's detectability to radar and infrared sensors. The hull and superstructure feature a faceted shape with an enclosed mast and sensors suite designed to eliminate corner reflectors and reduce the ship's detectability by radar systems. The composite superstructure of the vessel is fitted with SDI's S-RAM, a type of ballistic grade structural radar absorbing material consisting of 2 cm thick panels made from multiple layers of M5 fibers fibers containing a lossy filler backed by a carbon fiber laminate acting as a reflector. The panels are designed to survive extreme weather exposure and ballistic damage and provides an average -20 dB reflectivity across the 2-40 GHz frequency range (L through Ka bands). The rest of the steel hull is painted in a radar absorbing paint coating 1 to 5 millimeters thick consisting of lossy dielectric material embedded in a polymer resin which provides -20 dB reflectivity across the 9 -13 GHz range (X band).

The magnetic signature of the vessel is reduced by SDI's High Temperature Superconducting Degaussing System (HTSDS) which is designed to reduce the vessel's magnetic signature. The superconducting system provides an over 95% reduction in the ship's magnetic signature with a total weight 80% less than a conventional copper cable based system singicnalty reducing the vulnerability the ship to magnetic mine threats. The degaussing system components include a control unit, power modules, junction boxes, cryo coolers, accumulation tanks, high temperature degaussing cable assemblies, and cryogenic cold gas lines used to cool the degaussing cable assemblies. The system uses three separate loops of independently controlled degaussing coils arranged in three axes which are designed to counteract the ship's magnetic signature in the vertical, longitudinal and athwartship planes. Each coil loop is connected to an independent power module connected to the ship's zonal DC power distribution system which energizes the coil with up to 3,000 Amps of current at voltages of up to 138 kV. The cable assemblies consists of a hollow bismuth strontium calcium copper oxide (BSCCO) high temperature superconducting cable wrapped around a hollow support tube and supported by a flexible cyrostat consisting of a layer of inner corrugated stainless steel tubing, a layer of multi layer insulation (MLI), a polymer support layer, a vacuum space, an outer layer of corrugated stainless steel tubing, and an outer cable sheathing. The cooling loop for each cable includes a cryogenic refrigerator, a seawater heat exchanger, and a circulation pump which pumps gaseous helium through the cryostat and hollow support tube to maintains cable temperature at 55° K. The entire HTSDS is controlled from a central degaussing control unit (DCU) which receives magnetic field data either from both a shipboard triaxial magnetic probe system and from a magnetic geophysical model which takes data from the ship's navigation system and automatically calculates the required current for each degaussing coil to cancel out the ship's magnetic signature.


Passive Protection & Damage Control:
The Tempest class cruiser features features passive protection in the form of several hundred tonnes of composite armor panels made from M5 ballistic fiber laminated into cured thermoplastic panels which provide ballistic impact and spall protection to the superstructure and vital areas of the ship. The ship's S70 VLS modules and the magazine for the 20.3 cm gun are are also encased with welded Ti-6211 titanium alloy plates 50 to 80 mm thick backed by a spall liner consisting of M5 ballistics fibers embedded into an epoxy resin matrix. Th ship's blast hardened bulkheads are designed to deform plastically and maintain watertight integrity in the event of an explosion from a bomb or missile warhead inside the ship and feature double-spaced plate construction with an internal fragment resistant membrane designed to stop fragments from penetrating further into the ship. The automatic opening/closing watertight doors in the bulkheads likewise feature a blast hardened membranes structure design with approximately 10 times the blast force resistance of a conventional watertight door.

Damage control on the Tempest is largely automated due in parts to SDI Naval Systems developed Automated Ship Control System (ASCS). The ASCS is controlled by a centralized computer which amongst other functions provides real-time damage information to the crew through a graphical display located in the ship's damage control center. Additionally both the ship's bridge and CIC also also fitted with displays connected to the ASCS. The ACSC is designed to run automatically where after the ASCS detects damage to a compartment it will immediately isolate it and activate appropriate damage control measures. Alternatively the ASCS can be set to manual mode where the operator will have to specify the damage control measures after the system detects ship damage. The ASCS also controls and monitors the ship's engines and machinery and will alert engineers on watch duty through their assigned tablet computer when an engineering issue or machinery failure is detected and requires attention. This remove the need for time based maintenance, the system will simply alert the crew when a component or system requires maintenance. Each compartment and each piece of machinery on the ship are monitored using SDI's Two Wire Automatic Remote Sensing Evaluation System (TWARSES) which includes both visible CCD and infrared cameras located in each ship compartment. After damage is detected in a compartment the ASCS can respond in a variety of ways including isolating the damaged compartment by closing the electrically actuated watertight doors around the compartment. If the IR camera detects a fire the system will activate the compartment's overhead sprinklers and can also pump the compartment with aqueous film-forming foam , high velocity fog, and/or carbon dioxide agents if necessary. After the fire is extinguished water and firefighter agents are removed using a bilge draining pump installed in each compartment. The ASCS will also reroute ventilation, electrical power, and water around the damaged area and activate additional pumps, generators and other devices if necessary. If the compartment has been breached and is in danger of flooding the system will flood the compartment with foam which rapidly solidifies and restores reserve buoyancy. This system however is only used as an absolute last resort as it renders the compartment unusable. The ASCS also controls the ship's CBRN protection system by passing air from the ventilation intakes through containment filters before it enters the ship. Air in the ship is maintained at 5.0 millibars above local atmospheric pressure to provide a positive pressure and prevent contaminated air from entering into the ship through a breach in the hull.


Armament:
20.3 cm SK L/60 Naval Gun: The 20.3 cm SK L/60 is a fully automated and stabilized, single barrel naval artillery gun system designed for use against surface targets and as a long-range shore bombardment weapon. The gun system consists of three sub-assemblies, the SK L/60 gun assembly with its enclosed triaxial stabilized gun mount, automated ammunition supply system, and fire control support system and crew display with control consoles. The SK L/60 gun features a 60 caliber length monobloc barrel and features a semi-automatic vertically sliding breechblock which is automatically opened under the force of recoil. The breech is sealed with a mild steel case containing the propellant charge. The gun can fire either standard spin stabilized 110 kilogram 20.3 cm base-bleed (BB) projectiles including high explosive and cluster-HEAT with a muzzle velocity of 1,050 m/s out to a range of 60 kilometers or can fire a 180 kilogram rocket assisted, fin stabilized IRGM (infrared guided munition) projectile at a muzzle velocity of 825 m/s out to a range of 200 kilometers. The gun can be loaded any any angle of elevation and has a maximum sustained rate of fire of 12 rounds per minute. The gun is fed from an automated ammunition supply system consisting of a projectile and propellant charge hoist, automatic fuze setter, and a service drum located directly under the gun house which contains 75 projectiles and 75 propellant charges. An additional 400 rounds and 400 propellant charges are located in a two story magazine below the ready service drum including 80 IRGM projectiles. The mount is capable of training to +/- 165° on either side of the ships centerline at a rate of 30° per second and elevating from -10° to +70° at a rate of 20° per second. A shipboard fire control support system is used for control of the gun which plans fire support missions, determines firing solutions and shell trajectories, selects ammunition, and determines the best ship course for executing fire support missions.

SDI Obelisk Laser System: Each Tempest class ship is equipped with an SDI Obelisk Ship-mounted Fission-Activated Laser Weapon System. the Obelisk system uses fission fragment energy from a compact fast-spectrum nuclear reactor to directly pump a large-volume noble gas laser medium, producing continuous-wave or pulsed laser output at megawatt power levels across selectable wavelengths from the visible to the near-infrared spectrum. The direct nuclear pumping approach eliminates the multi-stage energy conversion losses inherent in conventional electric laser architectures, resulting in a self-powered, compact system with effectively unlimited magazine depth and no requirement for dedicated shipboard electrical generation capacity. The primary mission of Obelisk is terminal defense against supersonic and subsonic sea-skimming anti-ship cruise missiles and anti-ship ballistic missiles during their terminal phase. Secondary missions include counter-air operations against manned and unmanned aircraft, surface target engagement, anti-satellite operations in low Earth orbit, and high-resolution long-range active imaging and target discrimination. The Obelisk beam director is mounted ahead of the superstructure, with the beam director capable of training to +/- 135° on either side of the ships centerline. The laser module including the reactor is mounted below the waterline, connected to the beam director with a long beam transfer tube.

S70 Launch System: The Tempest class ship is fitted with a total of 320 S70 launch system cells comprising both ventral and peripheral launchers located fore and aft of the superstructure. The S70 is a cold-launch system which uses missiles encased in individual concentric launch cells as modular all-up rounds (AURs) each containing the missile, concentric launch tube, launch tube electronics, and missile ejection system. The S70 includes both 4-cell peripheral modules which contain 4 launch cells in-line designed to be mounted along the periphery of the ship between the inner and outer hulls and 8-cell central modules which contain 8 launch cells in a 4x2 arrangement that are intended to be mounted centrally in the hull. Both modules have the launch cells inclined at a 10° angle towards the ships centerline to prevent missiles with malfunctioning rocket motors from crashing back onto the deck after launch. Each launch cell is designed to accommodate a single all-up-round (AUR) launch canister which can contain missiles with a maximum length of 7.0 meters, diameter of 0.6 meters, and a weight of up to 2,500 kg. The missiles are ejected from each launch canister using a steam generator system which uses a small solid-propellant gas generator which exhausts through cooling water into the base of each launch canister, creating expanding high pressure steam which then forces the missile out of the launch canister. Safety and passive protection features of each VLS module include concentric anti-fragmentation shields placed around each launch cell to prevent in-cell missile fratricide and a deluge system which can flood each 4 or 8 cell module in the event of a missile catching fire in the launch tube. Launch canisters are connected to the launch cells through shock collar that is designed to absorb acceleration loads from an underwater detonation near the ship. The individual missile cells are connected to the ship's weapon control system via redundant port, central, and starboard fiber-optic Ethernet lines which transmits launch commands to the individual missiles and allows for missile status information before launch to be sent back to the weapon control system.

S120 Launch System: In addition to the 320 S70 launch cells the Tempest class is fitted with a total of 24 S120 launch cells forRBS 97 Arclight hypersonic boost-glide missiles, one 12-cell module forward of the superstructure and 12-cell module located aft near the fantail. Each module contains 12 launch cells in a 4x3 arrangement with launch cells angled 10° towards the ships centerline. Each launch cell is designed to accommodate a single RBS 97 all-up-round (AUR) launch canister containing a single RBS 97 hypersonic boost glide missile. Like with the smaller S70 launch canisters the RBS 97 missiles are ejected from each S120 launch canister using a steam generator system which uses a small solid-propellant gas generator which exhausts through cooling water into the base of each launch canister, creating expanding high pressure steam which then forces the missile out of the launch canister. Safety and passive protection features of each S120 VLS module include concentric anti-fragmentation shields placed around each launch cell to prevent in-cell missile fratricide and a deluge system which can flood each 12 cell module in the event of a missile catching fire in the launch tube. Launch canister are connected to the launch cells through shock collar that is designed to absorb acceleration loads from an underwater detonation near the ship. The individual missile cells are connected to the ship's weapon control system via redundant port, central, and starboard fiber-optic Ethernet lines which transmits launch commands to the individual missiles and allows for missile status information before launch to be sent back to the weapon control system.

Medium-Caliber Gun System (MCGS): For close in defense against small boats the ship is fitted with three SDI medium-caliber gun system (MCGS) turrets placed amidships on the top of the superstructure. Each MCGS mount contains an SDI 4.0 cm SK L/70 Flak cannon and an electro-optical targeting sensor with a forward looking infrared sensor, low light television camera, and a laser rangefinder. The 4.0 cm SK L/70 is an air-cooled, recoil operated automatic cannon which fires 40×365mmR ammunition at a rate of up to 300 rounds per minute. The 4.0 cm SK L/70 gun is housed in a triaxial stabilized low-RCS gunhouse constructed from fiberglass and is capable of traversing a full 360° at a speed of 130°/sec and is capable of elevating from -20° to +80° at 75°/sec. The gun includes an on-mount muzzle velocity radar and is designed to fire 0.975 kg programmable air-burst munition (PABM) projectiles at a muzzle velocity of 1,012 m/s. The 40mm PABM round contains 0.12 kg of HMX based polymer bonded explosive (PBX) surrounded by over 3,000 tungsten balls 3mm in diameter and features a multi-mode programmable fuze with six operating modes; proximity, gated proximity, gated proximity with impact priority, timed airburst, impact, and impact plus delay modes. The gun is fitted with a 72 round magazine which is automatically replenished by an additional 72 round magazine located inside the gun house. Total weight of the MGCS is 2,300 kg empty and 2,650 kg with a full load of ammunition.

40 cm Torpedo Launch System : For close-in anti-submarine the ship is equipped with two twin 40 cm Torpedo Launch Systems, one on each side of the hull for launching SDI F3s Viperfish anti-submarine torpedoes. The torpedo launchers are located in recesses below the flight deck near the aft of the ship which are covered by armored doors when not in use. Each Torpedo Launch System consists of twin fixed shock mounted 40 centimeter torpedo launch tubes, an air charging system, a 12 cell torpedo magazine, and a launcher control station which is connected to the ships' Sea Lance Undersea Combat System. Each F3S Viperfish torpedo is 40 cm diameter, 2.85 meters long lightweight anti-submarine torpedo powered by advanced stored chemical energy propulsion system (ADSCEPS) driven pumpjet propulsor. The torpedo has a maximum speed of 60 knots with a range of 15 km at 60 knots or 25 km at a lower speed of 40 knots. The F3S torpedo is equipped with a fully digital electronically steered 2D phased array active/passive sonar seeker combined with fiber-optic wire guidance. The torpedo is equipped with a 60 kilogram shaped charge warhead designed to penetrate the hulls of large double-hulled submarines.
Last edited by The Technocratic Syndicalists on Thu Jun 04, 2026 8:35 am, edited 114 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Wed Aug 31, 2016 8:38 pm

Image

Hydra Class Nuclear Cruise Missile Submarine

Basic Information:
  • Type: Cruise missile submarine
  • Displacement: 13,400 t surfaced, 17,200 t submerged
  • Complement: 110
  • Length: 143.5 m
  • Beam: 13.5 m
  • Draft: 10.8 m
Installed Power:
  • 1x SDI PWR 55 pressurized water reactor (PWR), 220 MWt
  • 2x AMG 16V 17/19 M64 diesel generators, 2,000 kWe each
Propulsion:
  • 1x 45 MW high-temperature superconducting (HTS) propulsion motor
  • 4x retractable auxiliary maneuvering thrusters, 625 kW each

Performance:
  • Speed:
    • Surfaced: 20 knots
    • Submerged (silent): 28 knots
    • Submerged (max): 35 knots
  • Diving depth:
    • Test: 600 m
    • Maximum: 1,000 m
  • Range: crew endurance (120 days supplies)
Sensors & Processing Systems:
  • SDI Submarine Tactical Combat System
  • SDI RMS 120 Conformal Acoustic Velocity Sonar (CAVES) Integrated Bow Array
  • SDI RMS 260 Conformal Acoustic Velocity Sonar (CAVES) Wide Aperture Flank Array
  • SDI SS 660 Fiber-optic thin-line towed-array sonar
  • SDI SS 670 Fiber-optic fat-line towed-array sonar
  • SDI FMG 600 Ultra-high frequency phased array antenna system
  • SDI EOS 770 Submarine Laser Communications receiver
  • SDI UKS-90 Multifunction towed communications buoy
  • SDI FMG 180 X band phased array surface search/navigation radar
  • SDI OKS 300 Multispectral photonics mast system
  • SDI Strategic Navigation System

Electronic Warfare & Countermeasures:
  • SDI FLG 130 Tactical ESM System
  • SDI RMS 350 acoustic interception and countermeasures system
  • SDI RMS 100 Own-noise monitoring system
  • SDI Sea Wraith electromagnetic signature suppression system
  • 10 cm internal countermeasure launchers
  • 21 cm external countermeasure launchers

Armament & Payload:


Overview:
The Hydra class SSGN is an advanced nuclear-powered hunter-killer submarine designed by SDI Naval Systems designed with the primary missions of hunting down and destroying both high performance, deep diving submarines and large surface warship groups. Secondary missions include land attack, undersea reconnaissance, mine warfare, and deployment of special operations forces.


Design & Construction:
The Hydra features a double hull design with an inner steel pressure hull and an outer composite light hull. The 12 meter diameter pressure hull is constructed from five modular hull sections (weapons module, habitability module, payload module, engine room module, and auxiliary machine room or AMR module) which are welded together to form the final pressure hull. The large internal decks in each hull module are fabricated and inserted into the hull as individual Modular Isolated Deck Sections (MIDS) onto cushioned and vibration isolated supports before the separate hull modules are welded together. The pressure hull of the Hydra is constructed from St 150 steel, a martensitic precipitation hardened low-carbon steel with a minimum yield strength of 150 kgf/mm2 . The individual pressure hull sections are formed using double vacuum melted (vacuum induction melted followed by vacuum arc remelting) St 150 steel which is forged into a cylindrical shape and then precision ground to tolerance. The pressure hull sections are then welded together under an argon atmosphere using gas shielded flux cored arc welding (FCAW-G) machines attached to servo-controlled laser guided robotic welding units. Additional forged St 150 longitudinal bulkheads are also welded inside the St 150 pressure hull to divide the hull into ten separate watertight components. The St 150 pressure hull gives the submarine a calculated crush depth of approximately 1,500 meters with a maximum safe operational depth of 1,000 meters.

The outer light hull of the submarine along with the pumpjet propulsor, machinery room supports, dive planes, rudders, sonar array fairings, and sail of the Hydra class are all constructed from a graphite and fiber reinforced epoxy composite formed using Vacuum Assisted Resin Transfer Molding (VARTM) processes. As opposed to traditional metal construction the use of composites saves significant amounts of weight as well as having lower manufacturing and maintenance costs. The outer light hull of the Hydra features a trapezoidal cross section with prominent bow and nose chines to deflect active sonar waves and consist of a 2mm thick vacuum assisted resin transfer molded shell 13.5 meters wide and 12 meters tall formed using carbon and S-2 glass fibers wound transversely using automated fiber placement (AFP) into an vinyl-ester resin epoxy matrix. The composite structure has the advantage of being acoustically transparent, has no magnetic signature, and has excellent vibration dampening properties.


Propulsion:
Reactor: Each Hydra class submarine is powered by a single SDI PWR 55 pressurized water reactor with a maximum power output of 220 megawatts of thermal energy. The PWR 55 is an advanced natural circulation based reactor which can operate at a signification fraction of its maximum power output (80 plus percent) without relying on reactor cooling pumps. Four small single-speed circulation pumps are employed in the primary coolant loop which are only used at high speeds in forced circulation mode. The fuel used in the reactor is 15% zirconium and 85% highly enriched uranium (HEU) enriched to 97% U235 and the reactor is expected to be capable of operating for 40 years without requiring a refueling. The S10S uses two cooling loops and includes two steam generators within its reactor core which provide high pressure, high temperature steam used to drive a single steam turbine. The steam turbine direct drives a single high temperature superconducting (HTS) AC generator which outputs a total of 55,000 kW of electric power which provides power to the ship's propulsion motor and other electrical systems. The entire PWR 55 reactor compartment is 12.5 m in diameter, 13 m long, and weighs 2,500 metric tons.

Motor & Pumjet: The Hydra class submarine is powered by a single shrouded pumpjet propulsor. The pumpjet propulsor employs a carbon/epoxy and glass/epoxy composite shroud and contains a rotor with eleven highly swept and skewed back nickel-aluminum bronze alloy blades and stator employing nine carbon fiber/epoxy blades which are molded into the composite shroud. Power is transmitted to the rotor using a carbon fiber reinforced plastic (CRFP) drive shaft connecting the rotor to the electric propulsion motor located inside the submarine's pressure hull. The motor used to drive the pumpjet is an SDI designed 45 MW three phase, six pole synchronous air-core AC superconducting motor. The rotor employs yttrium-barium copper-oxide (YBCO) high temperature superconducting ceramic conductors and is cryogenically cooled to 77 degrees K using gaseous helium from cryocooler module containing single stage GM cryocoolers located at the non-drive shaft end of the motor which feeds helium gas into the rotor through a rotating seal at the back end of the motor. The rotor housing is further enclosed in a vacuum-sealed cryostat to maintain cryogenic temperatures inside the rotor. The stator coils of the motor are made from copper Litz conductor and are cooled using a liquid dielectric coolant. The motor employs a variable-frequency drive (VFD) with three separate 2,400 VAC three-phase power modules per drive which allows for efficient motor operation from 6 up to 400 rpm.


Stealth
Designed to operate autonomously against the most capable submarine and surface threats the Hydra features a variety of stealth systems designed to drastically reduce the detectability of the Submarine to both acoustic and electromagnetic sensor systems. The acoustic signature of the Hydra is monitored in real time by the RMS 100 own-noise monitoring system (ONMS) which employs a series of self noise hydrophones (SNHs) mounted outside of the pressure along with hull and machinery mounted accelerators connected to a centralized processing system and a display/interface inside the submarine. The ONMS monitors both acoustic noise and vibration inside the submarine for radiated noise self-estimation and source localization as well as machinery and hull health monitoring. The OMNS can detect propulsor cavitation, flow induced structural resonation, and any odd noises emanating from the machinery or propulsion plants or due to loose objects inside of the submarine.

The SEA WRAITH electromagnetic Signature Suppression System is an active signature control system fitted to the Hydra designed to self-detect and reduce the submarine's magnetic and electrical signature. Included in the SEA WRAITH system is a fully distributed closed-loop degaussing (CLDG) system which provides real time measurement and cancellation of the submarine's magnetic signature. The CLDG system is built into the steel pressure hull and comprises a set of magnetic field sensors and degaussing coils wrapped around each compartment connected to bulkhead mounted power units which continuously monitor the vessel's magnetic signature and adjusts the degaussing coils as necessary to eliminate any magnetic signatures in real-time. The degaussing coils are arranged in three axes around the outside of the pressure hull in sections each carrying a submersible magnetometer array employing eight miniature fluxgate sensors positioned equally around the circumference of the pressure hull. The magnetic signature of the submarine is measured by the magnetometer arrays and modeled computationally using a centralized Degaussing Control Unit (DCU) which controls a series of amplifiers which then apply the appropriate degaussing currents to each coil section. The magnetometer array is capable of measuring nanoTesla variations in the submarine's magnetic field, allowing minute variations in the submarine's magnetic signature due to depth or heading changes to be corrected for in real time. Each coil section (one for each watertight compartment) is powered by a convection cooled Bi-Polar Amplifier Unit (BPAU) with an embedded microprocessor controller attached to the aft bulkhead inside the compartment and supplies DC power to the coil section using transformer that receives AC power from the ship's generators. The separate coil sections and BPAUs are interconnected, allowing the system to adapt to the failure of one or more BPAU units. The SEA WRAITH system additionally comprises a series of Underwater Electric Potential/Extremely Low Frequency Electric fields (UEP/ELFE) sensors distributed around the submarine's hull which are designed to measure the corrosion currents produced by the submarine's pressure hull and other metal parts in contact with seawater. The electric field measurements from the UEP/ELFE sensors are used to adjust the current through the Impressed Current Cathodic Protection (ICCP), itself used to suppress galvanic corrosion in the submarines metallic components which are exposed to seawater. The ICCP system consists of mixed metal oxide coated titanium anodes supplied with DC current from the submarine along with zinc reference electrodes which create an external current designed to counter-act the electrochemical action of galvanic corrosion. This current creates both UEP and Corrosion Related Magnetic (CRM) signatures which are monitored in real time using the UEP/ELFE sensors which forms a closed feedback loop with the ICCP system, the current through the ICCP anode continuity being adjusted in real time to minimize the vessel's electrical signature.

Both the inner pressure hull and outer light hull of the Hydra class submarine is fully coated in sound absorbing, pressure resistant anechoic tiles which are intended to reduce the submarine's acoustic signature. Each of the several ten thousand rectangular shaped tiles coating the hull is approximately 50 by 50 centimeters on each side and 10 centimeters thick and are constructed from multiple layers of viscoelastic polyurethane rubber embedded with inflated air filled polystyrene micro and macroscopic spheres of different diameters. The inner layer of tiled bonding to the outside of the submarine's pressure hill are optimized to absorb the frequencies of the submarine's own rotating machinery and vary in size and shape based on their location on the hull. The outer layer of tiles on the submarine's light hull are instead designed to absorb specific active medium and high frequency sonars including those used by active torpedo homing sonars and active ship and submarine ASW sonars with macroscopic cavities within which are sized to provide absorption of low frequency waves from towed low-frequency active towed sonars. The sail of the submarine as well as the dive planes and rear control surfaces additionally features a spray-on anechoic coating with microscopic voids designed to attenuate active sonar signals from medium and high frequency active sonar sources.

In addition to active acoustic coatings the Hydra features both passive and active vibration control of all machinery components to minimize the radiated acoustic energy from propulsion and machinery vibrations. The integrated motor/propulsor of the Hydra contains a resonance changer (RC) which electromagnetically dampens dynamic vibrations caused by forces from the spinning impeller blades acting on the submarine's hull. The resonance changer (RC) system is connected to the hydrodynamic thrust bearing in the submarine's tail cone attached to the inner stator of the motor/propulsor unit. The resonance changer (RC) uses active magnetic dampers which exert an axial force on the thrust bearing to actively cancel out vibrations in the bearing. A series of Hall sensors are placed around the hydrodynamic thrust bearing which measure the axial forces in the shaft. A series of stationary axially magnetized permanent magnets placed around the bearing are then energized to exert a Lorentz force exactly opposite to the force detected by the Hall sensors, canceling out the axial force in the shaft. A virtually identical electromagnetic resonance changer (RC) system is also used on the submarine's turbogenerators and backup diesel generators which both use electrodynamics thrust bearings which the RC dampening system is connected to. To prevent vibrations from being transmitted from the rotating machinery to the hull the various machinery onboard the Hydra including the reactor, turbines, diesel engines, pumps, etc is connected to the hull using a two-stage hybrid passive/active vibration isolation system which serves to both support the weight of the machinery and prevent vibrations from the machine from being transmitted to the hull. The two-stage passive vibration system consists of two sets of hydraulic dampeners and a heavy intermediate mass in between, the hydraulic dampeners each tuned to one of the major resonant frequencies of vibration generated by the machinery. This passive system however is only effective across a small range operating speeds and is thus supplemented by an active vibration dampening system which employs a series of piezoelectric actuators and voice-coil linear motors along with the hydraulic dampeners. For control of the active vibration isolation system a series of accelerators is mounted along the supports which measure the vibration of the machinery in all three dimensions. The actuators and linear motors are then used to generate counter-acting forces to cancel out the vibrations generated by machinery in real time. Although not as reliable as the passive system this allows vibrations to be suppressed across the entire operating range of the machinery and is more effective at suppressing low-frequency vibrations. The hybrid system thus uses the passive actuators to support the weight of the machinery and to act as a fail safe in case of active system failure.


Sensors & Processing Systems:
RMS 120 CAVES Integrated Bow Array: The primary undersea sensing system of the Hydra class SSGN is the SDI Underwater Systems RMS 120 Conformal Acoustic Velocity Sonar (CAVES) bow array which combines medium (0.3 to 12 kHz) and high frequency (36 to 72 KHz) transducers and low-frequency passive hydrophones in an array mounted conformally to the bow of the submarine. The curved array allows +/-120° horizontal and +/-30 ° vertical detection and transmission of sonar signals and replaces the spherical passive/active bow array and high frequency chin arrays used by previous generation submarines. The Bow array has multiple functions which including active detection and tracking of undersea contacts, mine detection and avoidance and under-ice navigation capability, and long ranged passive detection and tracking of both surface and subsurface contacts. The 11,880 individual TR 660 transducer elements that comprise the dual-frequency active/passive transducer array of the RMS 120 use SDI's proprietary piezolectric single crystal composite (SCC) architecture which consists of lead magnesium niobate-lead titanate solid solution (PMN-PT) single crystal piezoelectric rods embedded into an active polymer matrix to form a flexible 3-dimensional composite. The SCC architecture, which SDI Naval Systems developed specifically for use in high-performance sonar arrays, combines the extremely high piezoelectric and dielectric performance of single-crystal transducers with the water-like acoustic impedance, broader bandwidth, and flexibility of piezoelectric polymers. To shield the TR 660 transducer elements from vibrations each transducer element is self-contained within an individual vibration isolation module machined from a block of beryllium-copper alloy which is designed to isolate the transducer element from 99.5% or more of external vibrations. Located underneath and above the medium/high frequency transducer array is a low-frequency passive hydrophone array containing 290 SDI Naval Systems designed DT 585 wide band, omni-directional hydrophones. To compensate for cavitation effects on the face of the transducer and hydrophone elements at flank speeds each vibration-isolated TR 660 transducer and DT 585 hydrophone contains a 3-axis piezoelectric accelerometer attached to the back of the diaphragm which inputs the acceleration and velocity of the element to the driver amplifiers to actively cancel out the vibration of the element in real time. To eliminate the deleterious effect of self-noise on the CAVES array the entire array is attached to a an active noise-canceling composite layer connects the CAVES array to the hull of the submarine and consists of two layers of thin film polyvinylidine fluoride (PVF2) polymer transducers separated by a neoprene acoustic insulator layer connected to the submarine's hydrodynamic hull with a 25 mm thick layer of versathane adhesive. The detected acoustic signals from both the outer and inner PVF2 transducers are fed into an electronic control circuit which subtracts the signal of the inner sensor from the signal of the outer sensor to effectively cancel out the noise emanating from the array itself and from the submarine, allowing the primary TR 660 transducer and DT 585 hydrophone array to listen solely to sound external to the submarine. Medium/high frequency acoustic signals emitted by the CAVES transducer array are formed using a space-time adaptive processing (STAP) algorithm designed to enable adaptive beamforming capability to enable the array to create a virtual 3-dimensional image of sonar contacts in order to accurately separate targets from decoys and from clutter present in littoral waters while also minimizing sidelobes (LPI/LPD), and enable adaptive angle estimation to more accurately determine target depth, bearing and speed.

RMS 260 CAVES Wide Aperture Flank Arrayr: The SDI Underwater Systems RMS 260 Conformal Acoustic Velocity Sonar (CAVES) Wide Aperture Flank Array consists of two sets of three arrays mounted along either side of the submarine's hull (6 arrays total) which provides three-dimensional passive detection and ranging capability using Time Difference of Arrival (TDOA) techniques with each individual array to generate passive range, bearing, and speed estimates for a given target. The CAVES flank array requires an initial detection from either one of the towed arrays or the CAVES bow array to initiate the CAVES flank array detection processing. Once the flank array has been steered onto a target using the bearing provided by the towed or bowl array it will then attempt to detect and classify the contact. Each of the six flank arrays contains 640 SDI Underwater Systems designed DT 606 fiber laser hydrophones each consisting of multiple sub-millimeter thick silicon wafers attached together along with an erbium doped distributed feedback (DFB) fiber laser bonded into a beam-forming groove etched using potassium hydroxide (KOH) onto the upper silicon waver of the assembly. The DFB laser acts as a strain sensor and consists of an erbium doped fiber-optic core delimited by two fiber bragg gratings which outputs an infra-red laser with a wavelength which is adjustable between 1520 nm and 1560 nm. Strain on the hydrophone due to acoustic pressure causes the pitch of the bragg gratings to change which then alters the wavelength of the laser, the difference in wavelength being detected and converted into a strain measurement. The complete multiplexed array consists of 64 DFB lasers tuned to different wavelengths arranged linearly along a single fiber-optic cable and pumped by a single 1480 nm laser. Outputs from each laser are the carried back along the same fiber cable where the beam is split into its constituent wavelength and the intensity of each wavelength component measured by a series of photodectors connected to an interferometer which converts the wavelength fluctuations into an electrical signal representing the detected noise. The 64 lasers of each array are multiplexed with time and ten different laser wavelengths used which allows all 640 hydrophones in the array to be interlinked through two separate optical fiber cables which are both connected to the array's digital signal processing equipment inside the submarine. The complete fiber laser hydrophone array is sandwiched between two sheets of glass- fiber epoxy which provides structural rigidity for the array and protects it from external damage. The rigid array is in turn attached to an active noise-canceling composite layer consisting of thin film polyvinylidine fluoride (PVF2) separated by a neoprene acoustic insulator layer (virtually identical to the layer attached to the bow array) which is turn attached to the outer hydrodynamic hull of the submarine using 25 mm of versathane adhesive.

SS 660/670 Towed Array Sonars: the Hydra class SSGN is equipped with two towed arrays; the SS 660 thin-line towed array and the SS 670 thick-line towed array. The SS 660 consist of a fiber optic hydrophone array approximately 300 meters long and 76mm in diameter which is towed 1,800 meters behind the submarine. The SS 660 comprises a total of 96 fiber-optic hydrophones which use low-reflectivity fiber Bragg grating interferometers as well as internal stops to suppress buckling of the hydrophone mandrel from water pressure up to the array's designed operating depth. The fiber-optic hydrophones consist of a plastic mandrel wrapped with fiber-optic cables surrounded by a kevlar strengthened polypropylene hydrogel filled jacket. The individual hydrophones are passively multiplexed in both time and in wavelength to allow hundreds of channels to be carried over on just four fiber-optic cables. A Vibration Isolation Module (VIM) connects the hydrophone array to the tow cable and is designed to isolate the hydrophone array from axial vibrations and platform noise. The SS 670 fat-line towed sonar array is 89mm in diameter, 70 meters long, and is towed by a cable 300 meters long. The SS 670 has 480 acoustic channels (192 VHF channels, 192 UHF channels, and 96 EFH channels in an aperture center nested array). The SS 670 also features an array stiffness adjustment system using an electromagnetically driven ferrofluid inside the towing cable which is designed to keep the towing cable straight and stable at submarine flank speeds. To remove the effects of vibrational self-noise at high towing speeds both the SS 660 and SS 670 arrays feature an integral non-acoustic noise cancelling system which forms an adaptive interference reference end-fire beam with adaptive sidelobe canceling outside of the target frequency of interest while the array is being towed. The receives signal is used to samples the distortion in signal caused by vibrational interference, allowing the signal processing system to subtract the measured vibration from the received acoustic waves in the frequency of interest.

OKS 300 Multispectral Photonics Mast System: The OKS 300 Multispectral Photonics Mast System is a non hull-penetrating periscope system compositing two multispectral photonics mast containing visible light, infrared, and various ESM sensors. Each photonics mast can be extended up to 4 meters above the sail and feature a stabilized sensor head with provide 360 ° azimuth and -5° to +60° elevation coverage. The retractable mast features two mechanical stabilization systems; a course stabilization system which keeps the mast vertical under the influence of surface currents and a fine dual-axis stabilization system which stabilizes the line-of-sight to the target in pitch and yaw, roll being stabilized electronically. The head of the photonics mast is encased in a Low-RCS composite shroud with additional RAM coatings to minimize it's detectability to radar and contains a 1920 x 1080 pixel CCD color TV camera, third generation 1280 x 720 pixel MWIR (3–5 µm) uncooled mercury cadmium telluride (HgCdTe) thermal imager, a 1280 x 1024 pixel Indium gallium arsenide (InGas) SWIR (1–1.6 µm) imager, a 4320 x 2432 pixel Complementary metal–oxide–semiconductor (CMOS) color Low light level television (LLTV) camera, and an eye-safe 2.1 μm holmium laser rangefinder. Signals from the masts sensors are transmitted through fiber-optic data lines to the submarine's control center where the sensor feeds are processes and displayed on liquid-crystal displays in the command center. The BVS-3 processor system employs a multispectral image fusion system which combines the feed from the various mast-mounted electro-optical sensors and fuses the together, removing field of view (FOV) and spatial resolution differences between the different cameras and to correct bore-sighting inaccuracies. The fused data stream is output as a standard NTSC signal and is fed to the MDC consoles on the submarine's CIC for viewing by the crew. The top of the photonics mast also includes a frequency-selective enclosure which contains a GPS receiver as well as various antennas for the submerine's ESM system.

FMG 180 phased array surface search/navigation radar: The FMG 180 radar is a lightweight, compact X band (10 Mhz) active electronically scanned array (AESA) submarine radar designed to provide surface navigation capability, situational awareness, and surveillance of surface vessels, helicopters, and low flying aircraft. The FMG 180 radar is mounted to a electrically driven raise/rotate mast assembly which retracts into the sail when not in use. The FMG 180 features a horizontally polarized end fed slotted line array which is steered electronically in elevation (+/- 60° scan angle) and mechanically in azimuth with a rotation rate of 60 RPM. The FMG 180 has a low power output and low probability of intercept (LPI) capability and can track up to 100 targets simultaneously out to a maximum instrumented range of 60 kilometer and can detect low RCS targets in cluttered environments in all weather conditions. The FMG 180 operates with Electronic Chart Display and Information System (ECDIS) and Voyage Management System (VMS) for navigation as well as a 20-target Automatic Radar Plotting Aid (ARPA) capability for collision avoidance. Control and signal processing for the FMG 180 is via twin Electronic Modular Enclosures (EMEs) integrated into the Submarine's SDI Submarine Tactical Combat System.


Control & Communications:
SDI Sea Serpent Submarine Tactical Combat System:The SDI Sea Serpent Submarine Tactical Combat System is an advanced open-architecture combat system responsible for controlling all weapon and sensor subsystems of the Hydra class SSGN to include detecting, identification, and tracking threats and the settings and control of torpedo and missile weapons and mines.

EOS 770 Submarine Laser Communications Receiver: The sail of the Hydra class submarine contains an SDI EOS 770 Submarine Laser Communications System (SLCS) receiver designed to receive data from SDI Space System's designed Sealink submarine laser communications (SLC) satellites. The receiver is mounted in the sail and contains of an 80 cm diameter upward-looking optical aperture integrated into the top of the submarine’s sail. The aperture consists of a large-format sapphire window flush-mounted in a titanium frame that is contoured to match the sail’s hydrodynamic profile. The window surface is treated with a multi-layer anti-reflection coating optimized for blue-green wavelengths and a hydrophobic nanostructured surface coating that prevents marine organism attachment and minimizes scattering from surface contamination.
Behind the sapphire window, a wide-field-of-view optical assembly collects light from a cone of ±60°from the vertical and focuses it through a narrowband optical filter onto the detector array. The wide field of view ensures that the receiver captures the satellite signal regardless of the submarine’s heading, roll, or pitch attitude without requiring mechanical tracking. The receiver contains an ultra-narrowband optical bandpass filter that rejects ambient optical noise while passing the laser signal with minimal loss consisting of a thermally stabilized thin-film interference filter with a passband centered at 532.0 nm (or 486.0 nm for the blue laser mode) and a full-width half-maximum (FWHM) bandwidth of 0.1 nm (100 picometers). This extremely narrow passband rejects more than 99.999 percent of ambient optical noise while transmitting approximately 85 percent of the laser signal, providing an effective noise rejection ratio of approximately 50 dB relative to an unfiltered detector. The filter is temperature-stabilized to ±0.1°C using thermoelectric coolers to prevent thermally-induced passband drift. The core detection element is a 256 × 256 pixel array of silicon single-photon avalanche diode (SPAD) detectors that provides both spatial and temporal diversity for signal detection. Spatially the array resolves the angular distribution of incoming light, enabling discrimination between the highly directional (though scatter-broadened) laser signal and the isotropic ambient background. Temporally, each pixel incorporates a time-to-digital converter (TDC) with 50-picosecond resolution that timestamps each detected photon with respect to a GPS-disciplined rubidium clock, enabling precise time-gating that accepts photons only during the expected PPM slot windows and rejects photons arriving outside these windows as noise.

UKS 900 Multifunction Towed Communications Buoy: For communications while submerged the Hydra is equipped with an UKS 900 communications buoy deployed from the submarine's composite sail. The UKS 900 buoy features a wingless, lifting body design constructed from a glass fiber reinforced epoxy composite and is connected to the host submarine using an underwater fiber-optical tether six kilometers long which alloys the buoy to be towed behind the submarine at speeds of up to 30 knots at depths of up to 200 meters. The UKS 900 carries a multi-function mast antenna with a directionally stabilized phased array antenna which can be extended above the surface and which carries VLF, LF, and MF and receivers, HF, VHF, and UHF satellite transceivers, Automatic identification system (AIS) receivers, CIFF-SD Centralized IFF Interrogation System, and and a GPS spatial temporal antijam receiver (G-STAR) with differential GPS capability.

RMS 360 Underwater Telephone: The RMS 360 is a mid-frequency active (MFA) sonar based communications system consisting of a control station, receiver-transmitter, and sail mounted transducer array which can transmit voice, audio and low speed telegraph data in the 1.5 to 3.1 kHz and 8.3 to 11.1 kHz to and from surface ships, coastal-based shore stations, or other submarines.

SDI SirenLink Communications Buoy System: Using it's 10 cm submerged signal ejectors the Hydra class submarine is capable of launching SDI's SirenLink series of communications buoys which provide 1 way and 2-way acoustic and RF communication. The SirenLink buoys include the SirenLink 1WRF (1-way RF), SirenLink 2WRF (2-way RF), and SirenLink 2WA (2 way acoustic) buoys. All buoys are 10 cm in diameter and 1 meter in length with a mass of ~6 kg and are launched from within the submarine using the forward and aft 10 cm submerged signal ejectors (SSEs). The SirenLink 1WRF is an expandable one way communications buoy which is designed to transmit a prerecorded message from the submarine. The buoy also carries an emergency position-indicating radiobeacon (EPIRB) which can be used to transmit distress signals. Following SSE ejection the buoy ascends to the surface and then deploys an inflatable floatation device to remain on the surface while transmitting the prerecorded message using a UHF band satellite link. Alternatively the buoy can be set to a delayed release, rising to a parking depth of 20 meters where the buoy can hover for up to an hour before ascending to the surface. Following transmission the buoy then automatically scuttles itself to prevent retrieval. SirenLink 1WRF buoys can be deployed at depths up to 1,000 meters at speeds up to 20 knots. The SirenLink 2WRF is a fiber optic-tethered expendable buoy which is designed to provide two-way UHF SATCOM communications using a 20 kilometer long fiber optic cable between the buoy and submarine. Following SSE ejection the buoy splits into a towed and surfacing section where a high strength fiber optical fiber tether unspools from the rear of the surfacing section as it ascends to the surface. When the buoy reaches the surface the forward inflatable floatation and wings are then released, keeping in on the surface while the UHF antenna then establishes a communications link between the submarine and an orbiting satellite, sending a pre-set message to alert the base station that the submarine wishes to begin transmission. SirenLink 2WRF buoys have a maximum endurance of 6 hours and can be deployed at depths up to 600 meters at speeds up to 10 knots. The SirenLink 2WA is a two-way acoustic gateway which allows data to be acoustically transmitted from the submarine and then relayed via satellite and vice versa. Following ejection the buoy floats to the surface (with an optional delayed release) and broaches the surface, deploying its floatation device and establishing satellite connection with its UHF SATCOM antenna, sending a pre-set message to alert the base station as with the SirenLink 2WRF buoy. As this happens the buoy also deploys its low frequency acoustic transducer to the preset depth set as a function of local thermal layers and acoustic propagation characteristics which then establishes an acoustic communications link with the submarine through its RMS 360 underwater telephone. The SirenLink 2WA buoy can be deployed at depths up to 1,000 meters at speeds up to 20 knots and can maintain communications with the submarine at distances of up to 90 kilometers depending on local acoustic propagation characteristics. The buoy has a maximum endurance of three days and contains a thermal battery enabling two hours of satellite transmission time and one hour of full-power acoustic transmission time.

SDI Strategic Navigation System: The navigation system of the Hydra class consists of an SDI Strategic Navigation System, a type of gravity aided inertial navigation system (GAINS) which combines an SDI TNS 110 strategic grade 6 axis inertial measurement unit with a gravimeter and three gradiometer sensors which uses gravity field measurements correlated with gravity map data to produce absolute position references to correct IMU drift without reliance on GPS. The strategic grade TNS 110 IMU employs a 35 centimeter diameter spherical gimbal system with twin nested spherical gimbals which provides complete vibrational and thermal isolation to the system's inertial sensors. The inner sphere in the gimbal contains three interferometric fiber-optic gyros (IFOGs) and three micromachined quartz electromagnetic accelerometers mounted flush with the sphere's surface which is itself nested inside a second spherical shell separated by a small, uniform gap in turn contained inside a third sphere separated by a similar gap. The gimbal set employs a continuously rotating autocompensation mechanization (CRAM) actuated with brushless DC motors and fiber optic slip rings which along with the inter-sphere gaps provides conduction control and convection isolation to the inertial sensors with <0.05 °C temperature variation across the inner sphere surface during operation. The TNS 110 further decouples the earth's angular rotation rate using latitude-dependent small amplitude harmonics corrections which decouples earth rate rotation and the rotation rate of the gyros. The TNS 110 IMU provides <0.00002°/√hr gyro angle random walk and < 0.00001 °/hr bias stability performance and provides < 0.01 ° RMS roll & pitch accuracy and 1 NM/720h position drift rate per hour navigation performance. The gravity sensor used with the system to augment the TNS 110 IMU consists of a gravimeter which measures gravity anomalies relative to a nominal earth model and three gradiometers which measures gravity gradient changes in three dimensions. The gravimeter consists of an accelerometer used to determine the gravitational force at sea level by measuring the gravitational acceleration at the submarine's depth and applying corrections for the Eötvös effect, submarine depth below mean sea level, and accelerations from the submarine's current depth change rate which is then subtracted from the earth gravitational model gravity to generate a gravity anomaly value. The gravity gradiometers each consists of an array of four accelerometers mounted at 90° intervals to a rotating wheel to provide measurements of gravity gradients along the baselines of accelerometer pairs, three accelerometer wheels of which are orthogonally mounted to generate inputs for a full nine element (3x3) gradient tensor measurement. The passive navigation algorithm used with the system t combines inertial measurement unit and gravity sensor data which is processed by a Kalman filter to generate IMU error estimates used to correct the IMU sensor. The algorithm uses gravimeter and gravity gradiometer measurements to determine the submarine's position on a stored gravity field anomaly maps, providing an absolute position reference which is used to correct the drift of the IMU. The system can also detect the gravity field variations caused by local terrain, allowing the submarine to generate surrounding terrain estimates which are continuously updated based on Kalman filter IMU position error estimate, providing the navigation system with terrain following and terrain avoidance modes for navigation along the sea floor.


Electronic Warfare & Countermeasures:

FLG 130 Tactical Electronic Support Measures System:The Sail of the Hydra class SSGN carries the FLG 130 Tactical Electronic Support Measures (ESM) System which provides automatic detection, classification, localization, and identification of emissions from both radar and communications systems to provide situation awareness for the submarine and intelligence-gathering capability in support of surface battle groups. The FLG 130 system additionally includes passive bistatic radar detection and tracking ability and an Integrated Vulnerability Management (IVM) system designed to provide real-time counter-detection vulnerability assessment of submarine electromagnetic emissions. The receivers of the FLG 130 are integrated into the OKS 300 photonic mast system and include a 2 to 2,000 MHz HF/VHF/UHF omnidirectional Ultra Wideband (UWB) biconical radio direction finding (RDF) antenna, 0.5 to 18 GHz fast-scanning superheterodyne radar warning receivers, 0.2 to 40 GHz omnidirectional Generic Area Limitation Environment (GALE) SIGINT antenna, and a 0.05-3 GHz Communications Acquisition Direction Finding (CADF) antenna encased in a frequency-selective low RCS omnidirectional radome. Each antenna is capable of simultaneously receiving over 500 signals and measuring frequency, modulation, PRF, pulse width, amplitude and scan interval, and direction and of arrival with 2 degrees rms direction finding accuracy. The passive radar capability of the FLG 130 radiofrequency (RF) uses energy emitted by FM radio stations, analog and digital televisions transmitters, and other broadband communications signals which are scattered off targets and collected by the BLQ-13's omnidirctional antennas. Scattered waves collected by the FLG 130 are compared using Digital Beam Forming (DBF) techniques to the signal directly emanating from the emitters which is then used to accurately determine the location and velocity of the target in three-dimensions. The passive radar capability of the FLG 130 allows up to 100 simultaneous targets including ships, aircraft, missiles, and vehicles to be passively detected and tracked at ranges up to 300 kilometers 360 degrees in azimuth and 60 degrees in elevation with +/-1,000 meters of location accuracy and +/2 meters per second of velocity accuracy for each target. The Integrated Vulnerability Management (IVM) system is built into the FLG 130 and consists of software algorithms designed to assess the counterdetection vulnerability of the submarine based on the current signal environment and antenna exposure parameters. The threat assessment capability of the IVM is designed to determine potential local counter-detection threats which are stored in an onboard threat library. Information from the IVM is displayed using an integrated graphical user interface (GUI) onto one of the BSY-3 terminals located in the CIC to a system operator who can then quickly view and analyze threat capabilities.

RMS 350 Acoustic interception and countermeasures system: For countering torpedo threats the Hydra class SSGN is equipped with the RMS 350 Acoustic interception and countermeasures system which comprises a series of passive receivers and signal processing systems designed to detect, identify, and track threat torpedoes and sonar emissions and cue appropriate countermeasures. The RMS 350 employs a total of ten sparsely populated volumetric array (SPVA) sensors distributed across the outer hydrodynamic hull and sail of the Hydra which combined provide 360 degree coverage around the submarine. Each SPVA consists of eighteen polyvinylidene fluoride (PVDF) polymer piezoelectric transducer elements embedded into a polyurethane matrix which has the same acoustic impedance as seawater. The SPVA array is controlled through fiber-optic telemetry an provides both radius-of-curvature estimation and multipath ranging of torpedo threats with fractional degree angular accuracy while also providing broadband and narrowband detection and identification of threat sonar emissions in real time. Threat information from the SPVA sensors is input into the control subsystem of the RMS 350 which has launch management capability for the submarine's external and internal countermeasure launchers and will atomically deploy appropriate countermeasures once an oncoming threat has been detected and identified.

Countermeasures tubes: For launching carious countermeasures the Hydra class SSGN is fitted with both 10 cm internal and 21 cm external countermeasure launchers. The 10 cm internal launchers, which also function as submerged signal ejectors (SSEs), look and function like miniature torpedo tubes and are used to launch mobile acoustic countermeasures along with bathythermographs and expendable communications buoys. The submarine carries two signal ejectors, one in the torpedo room and another located aft in the engineering spaces. The 10 cm SSE's are used to launch the SDI AM6 acoustic torpedo decoy, a fully programmable mobile acoustic jammer equipped with a high powered acoustic noise generator employing piezolectric single crystal composite (SCC) full-duplex transducers designed to barrage oncoming torpedoes with acoustic noise across the torpedo seeker's entire operating frequency. The AM6 features an embedded single board computer and a threat torpedo classifier designed to detect, identify, and prioritize incoming torpedo threats by comparing their acoustic signature and emissions data against a pre-programmed library of pulse repetition rate (PRR) and wavelength information of common torpedo threats. PRR and wavelength formation for friendly torpedoes and anti-torpedo torpedoes is also included in the database to prevent the decoy from inadvertent jamming a weapon launched by the host submarine. Against torpedoes using active sonar homing the AM6 will attempt to actively cancel out their signals by taking the incident sonar pulse, inverting it, and re-transmitting it electronically using its single crystal composite (SCC) transducer back to the oncoming torpedo. Should no active sonar pings be detected, indicating a passive sonar homing torpedo, the AM6 will instead emit simulated submarine noise such as propulsion and engine noise to lure the passive torpedo towards the decoy. The decoy's full-duplex transducer also functions as an underwater acoustic datalink to allow multiple AM6 decoys to communicate tactical information between themselves and the host submarine in order to share and prioritize targets. Propulsion is via an electric motor driving a shrouded propeller in the tail of the decoy which allows it hover at a pre-selected depth set prior to launch. Power for the propulsion and electrical system is by a lithium anode (LAN) thermal battery which gives the decoy an endurance of 10 minutes before it scuttles to the seafloor.

In additional to the internal 10 cm launchers the Hydra carries two sets of twelve 21 cm external countermeasures located in the bow and in the tail. Each external countermeasure launcher (ECL) comprises a self-contained pneumatic launcher with an electrical firing circuit. When the launcher is fired the gas generator system releases high pressure gases which act on a metal ram plate to force the countermeasure out of the launcher. The metal ram plate also acts as a watertight seal, preventing gases from escaping into the ocean. A series of bleed valves in the walls of the launcher are then opened to let the gasses slowly drain from the launcher. The external 21cm launchers are used to launch the AM40 Mobile acoustic decoy, an active mobile decoy designed to simulate the signature and movement of the submarine. The AM40 is 21 cm in diameter, 2.0 meters long, weighs 60 kilograms, has an operational depth of 3-1,000 meters, and is powered by an electric motor driving a shrouded shrouded pumpjet at the rear of the decoy which can propel the decoy at speeds up to 25 knots. A 3500 Wh magnesium/silver chloride seawater-activated battery pack provides power for the motor and electrical systems and gives the EMAD a maximum endurance of 1 hour at 25 knots or 15 hours at 4 knots. The AM40 features body mounted hydrophones and single crystal composite (SCC) transducers as well as a towed array containing additional hydrophones and SCC transducers which provide both passive and active signature simulation capability. In passive mode the decoy uses it traducers to emit simulating noise matching the acoustic signature of the submarine in a broad-frequency range across a wide variety of speeds and operating conditions which are pre-programmed before launch. The AM40 can also function actively where it receives sonar pings and then amplifies them a before using an echo repeater to retransmit them back to the source. An additional retraceable magnetic antenna is mounted in the tail of the decoy and is designed to alloy the decoy simulate the magnetic signatures of the host submarine.

The 21 cm external launchers are also capable of launching the SDI Underwater Systems S2s Barracuda anti-torpedo torpedo, a miniature torpedo designed to intercept and destroy oncoming torpedoes. The Barracuda is 21 cm in diameter, 2.0 meters in length, weighs 110 kilograms, and contains a 20 kilogram aluminized PBX explosive warhead triggered by a lightweight, compact micro-electro-mechanical systems (MEMS) fuse with both contact, acoustic, and water pressure sensors. The guidance and fusing system of the Barracuda is designed to explode it in front of the oncoming torpedo, creating a blast wave which crushes the nose section of the oncoming torpedo. The Barracuda has a maximum range of 10 kilometers and is powered by a stored chemical energy propulsion system (SCEMPS) which sprays sulfur hexafluoride gas from a small tank over a block of solid lithium which generates enormous quantities of heat to generate steam for a closed cycle rankine engine which drives a waterjet propulsor which can propel the Barracuda at speeds up to 60 knots at depths up to 1,000 meters. Although designed as an anti-torpedo the Barracuda can also be used to engage other submarines, naval mines, and unmanned/autonomous underwater vehicles.


Armament:

Torpedo tubes: The Hydra class SSGN carries a total of eight 60 cm torpedo tubes which can be used to launch torpedoes, missiles, mines, and various remotely operated or autonomous underwater vehicles. The eight torpedo tubes are connected to a double-deck torpedo room which can store up to 60 full-length weapons. he torpedo tubes can also be used to deploy and recover SDI's Anglerfish mine reconnaissance UUVs. Reloading of all tubes is fully automated via a series of electromechanical winches and overhead cranes along with linear motor rammer attached to each torpedo tube which results in a reload time between torpedo salvos of around five to six minutes. Each of the eight 60 cm torpedo tubes is equipped with a superconducting electromagnetic firing system designed do have virtually noiseless operation in comparison to traditional compressed air or water ram systems. The system consists of the 60 cm launch tube, an impulse tank with a magnetohydrodynamic pump contained in a cryogenic dewar, and a supply tube with an open seawater interface containing silver chloride seawater electrodes. The MHD pump is made from Niobium-titanium (NbTi) superconducting electromagnets cooled to 10° K using liquid helium and serves to produce a magnetic field which interacts with the electric field created by the seawater electrodes. This interaction creates a lorentz force which forces the seawater from the supply tube into the launch tube, forcing the torpedo out of the tube. The only moving parts in the system are the muzzle and breech doors of the torpedo tubes and the associated vents and drains, no parts of the system move during firing which makes the process largely noiseless.

Modular Payload Tubes: Behind the sail of the Hydra is the 32 meter long Hydra Payload Module (HPM) hull section which contains twelve 2.2-meter-wide modular payload tubes (two rows of six) which can accommodate two different types of interchangeable multiple all-up round canister (MAC); one containing seven RBS 95 or RBS 93 all-up rounds (AURs) or another containing three RBS 97 all-up rounds. The multiple all-up round canisters also provide a seal between itself and launch tube and between itself and the individual missile canisters to prevent water from leaking past the multiple all-up round canisters when the payload tube doors are opened underwater. Each all-up round consists of the missile in a sealed launch tube containing a steam generator system which uses a small solid-propellant gas generator which exhausts through cooling water into the base of each launch cell, creating expanding high pressure steam which then forces the missile out of the launch tube. The AURs are attached to the MACS using upper and lower shock collars which are designed with the ability to absorb acceleration loads from underwater explosions near the submarine.

Modular Ocean Interface: In addition to its torpedo and missile tubes the Hydra class SSGN is equipped with a large modular ocean interface, a specialized floodable underwater hangar designed to launch and recover ROVs, UUVs, and other large underwater vehicles which is located behind the Hydra Payload Module on the upper aft surface of the hull. The ocean interface by default accommodates two SDI Manta Extra Large Autonomous Underwater Vehicle (XLAUVs) and associated launch and recovery equipment. Below the ocean interface is a 14 meter long payload bay within the pressure hull which provides dry access to the XLUAVS for maintenance and payload installation and is designed to accommodate up to 12 payload packages, each measuring 2.0 x 2.0 x 4.0 m, for loading into the XLAUVs.
Last edited by The Technocratic Syndicalists on Mon Jun 22, 2026 12:59 pm, edited 134 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Sat Sep 10, 2016 7:48 pm

Image

Retaliator Class

Basic Information:
  • Role: Amphibious Assault Carrier
  • Displacement: 72,500 t (full load)
  • Complement: 1,000 crew + 1,800 marines
  • Length: 292 m
  • Beam (flight deck): 72 m
  • Beam (waterline): 42 m
  • Draft: 9.5 m
Installed Power:
  • 1x SDI PWR 175 pressurized water reactor, 700 MWt
  • 2x AMG 16V 17/19 M64 diesel generators, 2,000 kWe each
Propulsion:
  • 2x SDI high temperature superconducting (HTS) AC Motors, 50 MW each
  • 2x shafts, 5 bladed fixed pitch propellers

Performance:
  • Top Speed: 28 knots
  • Range: Unlimited
Sensors:
  • SDI Typhoon Combat System
  • SDI FMG 300 X band Multi-Function Radar (MFR)
  • SDI FMG 600 S band Volume-Search Radar (VSR)
  • SDI Integrated Bridge and Navigation System
  • SDI EOS 400 Staring Infrared Search & Track (SIRST) System
  • SDI Integrated Launch and Recovery Surveillance System

Countermeasures:
  • SDI FMS 1800 Electronic Warfare System
  • SDI LWG 620 Naval Laser Warning System
  • SDI ZTKG 130 Trainable Decoy Launching System (TDLS)
  • SDI Surface Ship Torpedo Countermeasure (SSTC) System
[Armament:

Boats & landing craft carried:
Aircraft Carried:
  • 40 aircraft and helicopters

Aviation Facilities
  • 2x deck edge lifts
  • below deck aircraft hangar


Overview:
The Retaliator is a class of large amphibious assault carriers designed by SDI Marine Systems.


Design & Construction:
The Retaliator class carrier has an overall length of 292 meters overall (277 meters at the waterline), a beam of 42 meters at the waterline, a designed draft of 9.5 meters, and a full load displacement of 68,000 tonnes. The hull is constructed primarily from welded St 92 (900 MPa yield strength) high-strength structural shipbuiding steel. The hull includes a triple bottom with a depth of 2.4 meters for approximately 80% of the length of the hull.

The bow incorporates a bulbous bow optimized for the 24 to 28-knot speed range, reducing wave making resistance by an estimated 8 to 12 percent compared to a conventional bow. The bow section above the waterline transitions into the ski jump ramp at the forward end of the flight deck which is inclined at 12 degrees and extends forward of the flight deck leading edge. The ramp structure is integral with the hull, transmitting launch loads directly into the forward hull girder. The stern features a transom stern with an integrated well deck opening with a hinged stern gate that lowers to the waterline to permit ingress and egress of landing craft. The hull lines aft are faired to minimize flow separation at the propellers which are positioned in twin skegs that provide both structural support and flow conditioning.

The hull is divided into 22 main watertight compartments by transverse watertight, blast hardened bulkheads extending from the keel to the main deck. The reactor compartments are positioned amidships and flanked by longitudinal and transverse bulkheads that provide both structural redundancy and biological shielding. The well deck occupies the stern section of the ship with the well deck floor set at the second platform level to provide freeboard for landing craft operations. Survivability features include a double hull extending over the full length of the hull with a minimum depth of 3,0 meters to provide underwater explosion protection which extends from the keel to the first platform throughout the ship's length. Side protection systems incorporate a triple compartment void-liquid-void layering system outboard of the central machinery and magazine spaces. The warship features a central island with two superstructures which house the ship's dual-band radar system, IRST sensors, EW/ESM systems, communications sensors, and the ship's primary flight control, navigation bridge, flag bridge, flight deck control and launch operations room, and carrier air traffic control center combat direction center. The forward island houses the navigation bridge, primary flight control, and the ship's combat direction center (CDC). The aft island houses the secondary flight control station, the main exhaust uptakes for the emergency diesel generators. Both islands are constructed from composite radar absorbing structure (RAS) panels over a steel spaceframe framewore with faceted surfaces designed to reduce radar cross section.


Propulsion
The vessel is powered by a single SDI PWR 175 pressurized water reactor with a rated maximum power output of 700 megawatts of thermal energy (MWt). The reactor is located amidships enclosed within a welded steel primary containment vessel surrounded by a biological shield constructed from laminated lead, polyethylene, and high density concrete. The reactor compartment flanked by forward and aft auxiliary machinery rooms housing ship service generators, air conditioning plants, distilling plants, and auxiliary seawater systems. The forward and aft main turbine generator rooms are positioned between the reactor compartments and the auxiliary machinery rooms, each housing a main turbine generator set.The reactor is fueled using 97% highly enriched uranium (HEU) and is designed for a service life of over 40 years without refueling. The SDI PWR 175 reactor employs integral type circuit design with all primary circuit components including the steam generators are placed inside the reactor pressure vessel. The emergency core cooling system (ECCS) employs our separate systems including a gravity driven water injection system, pressure injection system, passive decay and heat removal system (PDHR), and a reactor protection system (RPS). The reactor core has an active length of 2.4 meters and contains 89 fuel assemblies containing binary U-Zr metallic nuclear fuel pellets consisting of 15% zirconium and 85% uranium enriched to a level of 97% U235 with a boron burnable poison coating which gives the reactor a design service life of 45 years before requiring refueling. Pumping for each reactor is provided by four horizontally mounted axial flow pumps attached to the outer shell of the reactor vessel which each provide a flow rate of 95,000 liters per minute (LPM) of cooling water through the reactor core. Each pump is powered by a 500 kW, 460 VAC 3 phase brushless AC motor driven by a variable a frequency drive (VFD). Steam from the reactor is used to drive two turbogenerators which each employ a double-ended turbine which drives a 120 Hz, 6 phase, 4160 VAC, 87.5 MW, 3600 rpm high-temperature superconducting (HTS) AC generator. The 175 MWe of electrical power from the two turbogenerators is distributed throughout the ship using a DC zonal electrical distribution (ZEDS). The 4160 VAC from the four turbogenerators is converted to to 6000 VDC with four power conversion modules (PCMs) attached to each generator. The PCMs then supply both port and starboard DC buses which supply power to 16 electrical zones which each include one DC/DC PCM per bus (two each per zone) which converts the 6000 VDC to 750-800 VDC or 650 VDC to supply DC loads in each zone. Both DC/DC PCMs in each zone also supply one or more DC/AC PCMs with 750-800 VDC which then converts the 750-800 VDC to 450 VAC at 60 Hz for AC loads. All electrical loads in each zone are connected to both port and starboard bus ensuring continued operation if either port or starboard bus becomes inoperable.

The warship's integral electric propulsion (IEP) system includes two SDI designed 50 MW superconducting motors which directly drive the ship's two propellers. Each 50 MW superconducting motor is a three phase, six pole synchronous air-core AC motor with a brushless exciter which has a rated speed of 150 RPM at its design voltage of 7,200 VAC with a full-load efficiency of 97.5%. The complete motor with cryocooler assembly weighs 75 tonnes, approximately 80% less than a conventional AC induction motor of the same RPM and power output. The rotor employs yttrium-barium copper-oxide (YBCO) high temperature superconducting ceramic conductors and is cryogenically cooled to 77 degrees K using gaseous helium from cryocooler module containing single Stage GM cryocoolers located at the non-drive shaft end of the motor which feeds helium gas into the rotor through a rotating seal at the back end of the motor. The rotor housing is further enclosed in a vacuum-sealed cryostat to maintain cryogenic temperatures inside the rotor. The stator coils of the motor are made from copper litz conductor and are cooled using a liquid dielectric coolant. Each motor employs a variable-frequency drive (VFD) with three separate 2,400 VAC three-phase power modules per drive which allows for efficient motor operation from 6 up to 150 rpm. Each 50 MW motor is used to directly drive a single 7.5 meter diameter 5-bladed fixed pitch propeller (CPP) located at the end of a carbon fiber reinforced plastic (CRFP) alloy propeller shaft. Each propeller employs five cast copper-nickel-aluminium alloy blades. The ship has two independent rudders place behind each propeller which are each driven by a 3-vane rotary vane steering gear mechanism with 1845 kNm of torque which allows rudder angles of +/- 45° off centerline. Both rudders feature a twisted rudder design which is designed to equalize pressure distribution on the rudder blade and minimize cavitation effects. For stability the ship also has four retractable stabilizers each with a 11.5m2 fin area mounted in pars forward and aft along the sides of the hull below the waterline which reduce the ship's rolling moment up to 80% at speeds up to 20 Knots.


Sensors & Processing Systems:
FMG 1000/2000 Dual Band Radar (DBR): The SDI Dual Band Radar (DBR) system includes the ships FMG 1000 band Multi-Function Radar (MFR) and FMG 2000 L band Volume-Search Radar (VSR). Each radar system consists of four phased-array antennas and associated receiver/exciter (REX) cabinets above -decks in the superstructure and a signal and data processor (SDP) system mounted below-decks inside the hull. Both arrays share a central controller and and a common array power system (CAPS) with power conversion units (PCUs) and power distribution units (PDUs) for each radar antenna. Both arrays are cooled using a closed loop, phase change based common array cooling system (CACS). The X-band radar system features a larger operating bandwidth and better low-altitude performance and provides surface search, radar navigation, gun-fire targeting and splash spotting, periscope detection, mine detection, precision target tracking and discrimination, limited volume-search, high-bandwidth missile uplink, and terminal illumination of targets while the L band radar provides long range volume search and long-range target tracking capability. Both the The X-band and L-band radars can provide simultaneous sector search, environmental mapping, counter-fire/counter-battery tracking, missile tracking, electronic warfare, clutter detection, and in-flight missile guidance and communication. Each X band FMG 1000 aperture has a 4-meter square antenna with 10,560 full-duplex radio integrated circuit transmit and receive (T/R) modules which use gallium nitride complementary metal-oxide semiconductors (CMOS) on a diamond substrate integrated into 10-bit field-programmable gate array circuits for extremely high throughout processing and high-bandwidth data transferring. The L band FMG 2000 antennas are significantly larger at 16 square meters and each use 42,240 full-duplex radio integrated circuit transmit and receive (T/R) modules. Each radar antenna features +/- 60° azimuth and +/- 60° degree beam-steering capability giving the system combined 360° azimuth coverage around the warship. Both radar systems employ wide-band digital receiver/exciter (DREX) units and feature digital beam-forming (DBF) capability, space-time adaptive processing (STAP), and multiple-input multiple-output (MIMO) waveform generation techniques. ECCM capabilities of the radar system include frequency-modulated continuous-wave (FMCW) operating modes, ultra-low sidelobes, high processing gain, pulse-to-pulse frequency agility and ultra wide-band frequency hopping, staggered pulse repetition frequency (PRF) switching, randomized burst transmissions, and automatic jammer detection and tracking. Peak power consumption of the dual-band system is 12 MW and instrumented range is 1,000 km in air-surveillance mode and 2,000 km in ballistic missile tracking mode with the ability to simultaneously track up to 3,000 air targets in air surveillance mode or up to 30 ballistic missile targets in ballistic missile tracking mode.

SDI EOS 400 Staring Infrared Search & Track (SIRST) System:The SDI EOS 400 Staring Infrared Search & Track (SIRST) System is a distributed multi-aperture sensor system which consists of four identical dual field-of-view, electronically stabilized mercury cadmium telluride (HgCdTe) starring focal plane array (FPA) imaging infrared (IIR) sensor units mounted in a mast above the ship's forward island which provide combined 360°azimuth and -20° to +75° elevation situational awareness infrared search and track (SAIRST) capability against surface vessel, cruise missile, ballistic missile, and aircraft targets to supplement the active search and track capability of the ship's dual band radar system. The 4096 × 4096 pixel (16 MPA) HgCdTe sensor used by each sensor head operates in the MWIR (3–5 µm) band and features a 95 x 95° degree field of view. The image processing features of the EOS 400 system include automatic target recognition (ATR) using an on-board threat library, passive ranging algorithms, multi-target adaptive tracking, and clutter rejection techniques. The video feed from the sensor units can be stitched together and displayed on operator consoles in the ship's bridge and CIC to act as a navigational aid and to provide close in situational awareness for the ship's crew.

Launch and Recovery Surveillance System: The Launch and Recovery Surveillance System or LARSS is a network of eight cameras placed around the ship's two islands which provide continuous 24/7 monitoring of launch, recovery, and flight deck operations. The system uses 2 megapixel (1920 x 1080 px) visible/SWIR (0.4 - 1.7 µm) cameras with InGaAs (indium gallium arsenide) FPAs with a 60 fps frame rate. Five of the eight cameras are mounted in a fixed panoramic mount on the starboard side of the island with feeds from the five cameras stitched together to provide a real-time panoramic video feed of the entire flight deck. The other other three cameras are mounted atop the forward island in individual mounts with pan/tilt capability and feature digital zoom to allow the operators to zoom in on any specific part of the flight deck or aircraft taking off and landing from the carrier. Four control console units (CCUs) for the LARSS system are mounted below the flight deck in the LARSS control room.


Battle Management & Communications:
SDI Typhoon Combat System: The SDI Typhoon Combat System (TCS) is a comprehensive open-architecture anti-aircraft warfare (AAW) combat management system designed by SDI Missiles & Fire Control Systems which provides fully automated detection, identification, and engagement of air targets. The primary components of the Typhoon Combat System are the Sensor Fusion Processor (SFP), Command and Decision System (C&DS), Typhoon Display System (TDS), Weapons Control System (WCS), and Integrated Ship Computing System (ISCS). The sensor fusion processor or SFP takes tracking data from the ship's radars, IFF system,distributed IRST sensors, andelectronic warfare system and correlates them using a contact-to-track data correlation algorithm to provide a single integrated track of each detected target. With the contact-to-track algorithm detected contacts from each sensor (radar, IFF, IR, and ESM) are correlated with existing sensor tracks and merged using a smoothing filter to create a single track file of each correlated target. This allows (for example) the range data from the radar tracks of the ship's dual band radars to be fused with the angle track data from the higher angular resolution IRST sensors, creating a fused 3D track which is more accurate than either the individual radar or IRST sensor tracks. Track data from the sensor fusion processor is fed into the Typhoon Command and Decision System (C&DS) which uses both IFF data and aided and automatic target recognition (Ai/ATR) algorithms to provide identification, threat classification, and weapon assignment of target data input from the sensor fusion processor. Information from the Command and Decision System (C&DS) processor is displayed via the Typhoon Display System (TDS) which uses large multi-function color displays inside the ship's CIC to display target tracks and other situational awareness data to the ship's crew and captain. The TDS consoles also features keyboards for data input which allows doctrinal IF/THEN instructions to be input to the system to the modify its behavior; such as instructing the system that IF any target is detected above a certain speed and altitude in a certain sector THEN it is to be automatically classified as hostile and engaged with a certain missile. The Weapons Control System (WCS) is responsible for launching missiles at targets identified as hostile by the Typhoon Command and Decision System (C&DS). Targets are matched to the ship's missiles by the C&DS which will then send a fire instruction to the weapon control system when the target has entered the engagement zone of the specific missile. The WCS then sends a a firing instruction to the ship's VLS to fire the specific missile and then uses the ship's radars and datalinks to provide midcourse guidance as necessary to guide the missile towards its intended target. The WCS is also responsible for providing Air Intercept Control (AIC) functionality and can be used to guide carrier or land based airborne interceptors towards a hostile target being tracked by the ship. Finally the Integrated Ship Computing System (ISCS) acts as the central processor of the Typhoon combat system and processes radar and and other sensor data and connects all the ships systems including weapons, countermeasures, and communications system together. The ISCS architecture is based on SDI's SPPC10D single-board computer, a ruggedized, shock hardened and conduction cooled computer which employs a 10nm gallium nitride (GaN) on silicon architecture, 48 core (384 thread) superscalar symmetric multiprocessor with a 4.0 GHz clock rate as well as 64 GB of DDR5 DRAM. The SPPC10D computers are each packaged into 16 Electronic Modular Enclosures (EMEs) which each include their own power, shock, vibration, and electromagnetic protection, and water cooling systems. Each EME is a self-contained server and carries 235 cabinets containing the SPPC10D single-board computers. The EMEs which run the ISCS software are interconnected to the rest of the sensors and electrical systems through fiber-optic cables and uses voice-over IP for internal communications between computer systems. The combined computing power of the ship's processors is 27,000 MIPS (million instructions per seconds) at 4.35 GHz with a combined 240 TB of data storage.

An additional ability of the Typhoon Combat System is Distributed Engagement Capability (DEC) which allow target tracking data from multiple sensors across multiple Typhoon equipped platforms in the battle group to be fused together to create a composite track of all air objects within the battle force area and to allow for hunter-killer functionality in the battle group by allowing unit in the battle force to engage a target being tracked by another unit even when the shooter is unable to see or track the target with its own sensors due to either jamming, battle damage, or line-of-sight restrictions. Distributed engagement capability on Typhoon equipped platforms s enabled by a data distribution system (DDS) and a track fusion algorithm (TFA). The data distribution system or DDS consists of four C band planar array antenna assemblies blended into the outer surface of the ship's superstructure which provide extremely high bandwidth line-of-sight communication capability with other sea and air platforms in the battle force. Each DDS antenna array consists of a liquid cooled digital beam forming (DBF) antenna with separate transmit and receive arrays employing gallium nitride (GaN) monolithic microwave integrated circuit (MMIC) transmit/receive (T/R) modules integrated into a common subarray line replacement units (LRUs) and high provides extremely jam resistant and high bandwidth line-of-sight data exchange with other DDS equipped platforms. The track fusion algorithm (TFA) uses the ships ISCP processors to take sensor data received by other units through the data distribution system and fuse it with data from the ships own sensors to create a single composite sensor picture. The main capability of the track fusion algorithm is the ability to network the measurements of radars and other sensors on different platforms tracking the same target and combine them with an intelligent averaging algorithm that creates a single composite track of the target which is more accurate than the track of any individual sensor. When a Typhoon equipped platform establishes a target track with one or more of its sensors a track alert is broadcast across the Typhoon network which then cues the other platforms in the battle force to point their sensors in the direction of the target track. When the other platforms begin tracking the target with their own sensors their sensor measurements are distributed back across the network to every other platform to form the composite track. This capability allows the battle force to maintain track of a target even if any one or even multiple of the battle force units loses the target track due to jamming, battle damage, or environmental effects. When used to fuse radar data from different platforms the track fusion algorithm also enables better radar observation of low observable targets by illuminating them simultaneously with many radars of different wavelengths and scan rates at once, allowing a composite track to be created even if none of the radars in the battle force are able to generate an individual track of the target for more than a few pulses.

SDI FG 710 Shipboard Digital Radio (SDR): The SDI FG 710 Shipboard Digital Radio (SDR) is a shipboard software defined radio designed by SDI Mission Systems which provides centralized control of all shipboard radio communication systems operating in the 100 MHz to 2 GHz frequency bands. The SDR can transmit on up to 128 simultaneous channels with programmable waveforms supported by the SDR including 225-400 MHz anti-jam UHF military aircraft radio, low (25-54 MHz), mid (2-76 MHz), and high-band (136-175 MHz) VHF/UHF-FM Land Mobile Radio (LMR), 960-1215 MHz TACAN, 420-450 MHz Enhanced Position Location Reporting System (EPLRS), 108-137 MHz VHF-AM civilian Air Traffic Control, 156 MHz marine VHF-FM radio, 1030 & 1090 MHz IFF, 1350-1850 MHz Digital Wideband Transmission System (DWTS), and others. Encryption options including High Assurance Internet Protocol Encryptor (HAIPE), Advanced Narrowband Digital Voice Terminal (ANDVT), and others as required. Communications through the USC-71 radio are managed by automated digital network system (ADNS) which provides automated LAN/WAN management and integrated network management (INM) of RF signal traffic, automated routing and switching (R&S) of RF transmission circuits, and channel access protocols (CAP) management.

The antennas for the SDR system are located in the MERS (Multifunction Electromagnetic Radiation Structure), a low-RCS hexagonal pyramid structure located on top of the ship's forward superstructure which encloses various communications, datalink, and IFF antennas. The base of the MERS pyramid contains the ship's IFF array which consists of a 360° electronically steerable circular antenna with two rows of 32 elements each (64 total) fed from a central beamforming network which can support both omnidirectional and pencil-beam transmission modes. Above the IFF array are a ring of six 1.0 meter diameter vertically polarized cavity backed UHF spiral antennas with 100W CW of transmit power each in the 225-400 MHz frequency range. The UHF line-of-sight antennas operate in 25 kHz wide transmission bands and allow communication with other surface ships out to 50 kilometers, helicopters out to 200 kilometers, and aircraft out to 600 kilometers. A ring of six L band datalink and TACAN (tactical air navigation system) antennas 25 cm in diameter are placed above the UHF antennas and cover the 960-1215 MHz frequency range with 2kW peak and 400W continuous transmission power. The MERS antennas are embedded into the composite sandwich panels of the mast structure which consist of a fiberglass-epoxy laminate with embedded frequency selective surface (FSS) layers which permits passage of the ship's sensor frequencies while rejecting all others.

Integrated Terminal System (ITS): The ship's SATCOM capability is enabled by the SDI Integrated Terminal System or ITS which provides centralized control of all ship satellite communication systems. For satellite communications capability the superstructure of the ship contains four active phased array SATCOM antennas mounted atop the forward island in a low-observable multi-function stack which combines the four phased array SATCOM antennas and a exhaust suppresser in a low-observable composite structure. Each SATCOM antenna assembly contains a central dual-frequency UHF (244 to 318 MHz) and L band (1525 to 1650 MHz) transmit/receive (Tx/Rx) array and two peripheral arrays including an EHF (43.5 to 45.5 GHz) Uplink Tx array and a SHF (20.2 to 21.2) Downlink Rx array providing combined 360° azimuth and -0° to +80° elevation coverage in the UHF, L, EHF, and SHF bands.

SDI FG 410 High Frequency Radio System (HFRS): The SDI FG 410 High Frequency Radio System (HFRS) is a digital solid-state high frequency (HF) communication system supporting interrupted continuous wave (ICW), voice, and digital data communications which provides over-the-horizon ship-to-ship, ship-to-submarine, ship-to-aircraft, and ship-to-shore radio connectivity independent of the SDI Shipboard Digital Radio or ITS SATCOM systems. Operating modes supported by HFRS include lower sideband (LSB), upper sideband (USB), independent sideband (ISB), frequency shift keying (FSK), continuous wave (CW), and amplitude modulation equivalent (AME). The HFRS consists of a transmitter subsystem, receiver subsystem, and a remote control/ monitor subsystem (RCMS). The transmitter subsystem supports 4,8, and 12 kW transmit power and operates in the 2 Mhz to 30 Mhz frequency range in 10 Hz increments with the ability to shift transmit frequency in less than 100 milliseconds and transmits through two 10 meter whip antennas located forward and aft on top of the superstructure. The receiver subsystem operates in the 14 Khz to 1.619 Mhz and 2 Mhz to 30 Mhz range and uses three smaller whip antennas mounted on the superstrucutre, two for the receiver system only and one which is shared with the ship's Ship Signal Exploitation Equipment (SSEE) system. The remote control/ monitor subsystem (RCMS) is primarily a manual backup system which used to provide control over the HFRS if the ship's SACCs (Ship Automated Communications Control System) becomes inoperable.

SDI FG 620 High Frequency Management System (HFMS): The SDI FG 620 High Frequency Management System or HFMS is a complimentary system to the SN/URC-141 High Frequency Radio System and uses an oblique incidence sweep-frequency ionospheric chirpsounder to determine the best HF transmission frequencies based on current ionospheric propagation measurements conducted by the chirpsounder. The chirpsounder sweeps upwards from 2 to 30 MHz in 4 minute intervals and can be synchronized with up to three separate HF transmitters which when synchronized allow them to transmit as much radio energy to a receiver as is possible under current ionospheric propagation conditions.

SDI FG 320 Tactical High-Bandwidth Datalink (THBD): The SDI FG 320 Tactical High-Bandwidth Datalink (THBD) is a full-duplex RF data link system operating in the Ka (14.4 GHz - 15.5 GHz) and X (9.7 GHz - 10.5 GHz) bands and is designed primarily to allow signal and imagery intelligence from airborne reconnaissance platforms to be streamed to ships in real time at distances up to 200 km. The system supports selectable 10.71,137, or 274 Mbps downlink rates with binary phase-shift keying (BPSK) downlink modulation and an uplink rate of 200 Kbps with offset quadrature phase-shift keying (OQPSK) modulation. The THBD system is coupled with a shipboard imagery exploitation system which has the the capability to receive, process, store, exploit, and disseminate Imagery Intelligence (IMINT) reports based on imagery received through the THBD system.

Global Position System (GPS): The ship employs GPS for precision navigation capability and has four 18 cm diameter GPS antennas covering the L1 (1.575GHz) and L2 (1.227GHz) frequencies blended into the upper corners of the forward and aft islands which provide 360° azimuth and -0° to +80° elevation coverage.


Electronic Warfare & Countermeasures:
FMS 1800 Advanced Electronic Warfare System: The primary electromagnetic countermeasure system of the ship is the FMS 1800 Electronic Warfare System, a comprehensive offensive and defensive electronic warfare (EW), electronic support measures (ESM), and electronic intelligence (ELINT) suite which combines passive radar warning receivers and phased array jammers for long range, over-the-horizon detection, identification, and targeting of threat emitters as well as automatic employment on-board RF countermeasures and support of passive over-the-horizon targeting capability for the ship's weapon systems. The passive radar warning system of the FMS 1800 consists of multiple single-quadrant, high-gain linear interferometer arrays blended into the sides of the vessel's island which are connected to a set of digital receivers and pulse processors inside the ship's superstructure which provide for 360 degree spherical broadband, all aspect detection, identification, and direction-finding of radar emissions with the capability for precise emitter location and threat identification capability against low probability of intercept waveforms and with additional over-the-horizon direction finding capability of MF, HF, VHF, and UHF band signals. The offensive electronic warfare capability of FMS 1800 system includes multiple low, mid, and high band electronically scanned gallium nitride (GaN) based Digital Radio Frequency Memory (DRFM) jammers blended into the superstructure which provide for the jamming of hostile RF sensors. The FMS 1800 is a fully cognitive and adaptive system; by using radar emission data collected from the FMS 1800 radar warning recievers the DRFM jammers can automatically adapt in real time to unknown waveform characteristics, dynamically synthesize countermeasures, and jam the waveform accordingly. The DRFM Jammers of the FMS 1800 also includes false target generation capability allowing the FMS 1800 to generate up to 32 simultaneous false surface and air targets at ranges up to 625 kilometers to spoof hostile radar systems. Designed to spoof wideband phased array radars with moving-target indicator (MTI) and inverse synethic aperture radar (ISAR) capability, the false-target generation system of the FMS 1800 comprises a receiver system for producing a false signal that mimics an incident radar pulse, a phase sampling circuit is connected to the FMS 1800 radar warning receivers for sampling the signal and providing phase sample data, and an image synthesizer circuit is connected to the phase sampling circuit and arranged to receive the phase sample data from the circuit which processes the phase sample data to form a false target signal which is input to a signal transmitter system built into the FMS 1800 DRFM jammer array which is arranged to transmit the synthesized false target signal so that it can be received by the threat radar system.

LWG 310 Naval Laser Warning System: For detecting laser sources including laser range finders, laser target designators, and laser beamriding missiles the ship's electronic warfare system is augmented by an SDI LWG 310 Naval Laser Warning System. The vessel's LWG 310 installation consists of a central controller connected eight sensor heads, four on each side of the superstructure, providing combined 360° coverage around the vessel. Each individual sensor head features 110° azimuth and +/- , 70° elevation coverage and is capable of detecting laser range finders laser target designator emissions in the 0.5 μm - 1.65 μm range and laser beamriders in the 0.8 μm - 1.1 μm range.

SDI Sea Guardian Surface Ship Torpedo Countermeasures System: The ship is fitted with the SDI Sea Guardian Surface Ship Torpedo Countermeasure System which combines various soft-kill and hard-kill torpedo countermeasure systems. The Sea Guardian system consists of a towed array sonar designed specifically for torpedo detection, a towed acoustic decoy with a a single-drum winch, an interface to the ship's trainable decoy launchers, and a processing cabinet with two display consoles, and and four 4-round anti-torpedo torpedo launchers on either side of the ship. The towed array sonar used by the system is a combined active and passive array sonar optimized to detect the high frequency sound signature of torpedo screws and active sonar homing heads. The towed array is supported by two vibration isolated modules (VIMs) located on either side of the sonar with the array being connected on one end to the ship using a fiber-optic tow cable and connected on the other end to the towed decoy with an array tow cable. The towed decoy array is designed to emit simulated ship noise such as propulsor and engine noise to lure a passive-sonar homing torpedo to the decoy instead of the ship. The towed decoy can also receive sonar pings from the active homing head of a torpedo and amplifies and returns the "pings" to the torpedo, presenting a larger false target to the torpedo. The hardkill component of the Sea Guardian system comprises a series of four box launchers on either side of the vessel which each contain six SDI S2s Barracuda anti-torpedo torpedoes in individual all-up rounds (AUR) which contain the Barracuda torpedo and a self-contained compressed gas launch system. The Barracuda torpedo is 21 cm in diameter, 2.0 meters in length, weighs 110 kilograms, and contains a 20 kilogram aluminized PBX explosive warhead. The guidance and fusing system of the Barracuda is designed to explode it in front of the oncoming torpedo and create a pressure wave which crushes the nose section of the oncoming torpedo. The Barracuda has a maximum firing range of 10 kilometers and is propelled by an advanced stored chemical energy propulsion system (ADSCEPS) which can propel the Barracuda at speeds up to 60 knots at depths up to 1,000 meters. Although designed as an anti-torpedo the Barracuda can also be used to engage midget submarines, naval mines, and unmanned or autonomous underwater vehicles.

ZTKG 130 Trainable Decoy Launching System (TDLS): The ZTKG 130 Trainable Decoy Launching System (TDLS) is an aimable decoy launcher which can launch a variety of decoys designed to decoy away anti-ship missile and torpedo threats. The ZTKG 130 system consists of multiple 12-round trainable countermeasures launchers controlled by a central command console inside the ship. Each 12-round launcher employs a rotating platform with 12 separate 130mm barrels which can each be individually trained in elevation. The ship is fitted with four decoy launching systems, two on either side of the ship used for acoustic torpedo decoys (24 total) and another two launcher on each side used for chaff/flare rounds and missile seduction decoys (24 total).

AM5 dual chaff/IR seduction decoy: The primary chaff seduction round employed by the DLS is the AM5 dual chaff/IR seduction decoy which is capable of defeating dual-seeker missiles equipped with both IR/EO and radar seekers. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.

AM79 Buzzard active missile decoy: For decoying away radar-guided anti-ship missiles the DLS can deploy the AM79 Buzzard active missile decoy, an expendable electronic-warfare rotary-wing drone which is designed to seduce RF guided anti-ship missiles by simulating the radar return of a large surface vessel. The buzzard features a cylindrical shaped fuselage 130 mm in diameter and 0.9 meters tall with both top and bottom mounted 1.8 meter diameter three-bladed counter-rotating coaxial rotors powered by two brushless DC motors. The rotors unfold from the body of the decoy after launch and fly the decoy into a pre-programmed flight path away from the ship where the decoy then hovers in place while emitting electronic warfare signals uses its fuselage mounted Digital Radio Frequency Memory (DRFM) jammers which are designed to seduce oncoming anti-ship missiles into targeting the decoy and not the host vessel. The decoy is powered by a thermal battery mounted in the center of the fuselage which gives the decoy approximately 60 minutes of flight endurance after launch.

AM7 Lamprey acoustic decoy: The DLS can also launch the AM7 Lamprey, a 130mm diameter, expendable acoustic decoy designed to counter torpedo threats. After a rocket-powered launch into ocean the Lamprey is programmed to hover vertically using a pressure-controlled motor driving a small, shrouded propeller in the tail of the decoy. The Lamprey is designed to hover at a pre-selected depth from 10-300 meters where it listens for torpedo transmissions. Active acoustic transmissions are detected and analyzed resulting in decoy selectivity and generation of the appropriate deception signal for transmission including target signature and target self noise. If no torpedo transmissions are detected the decoy is programmed to emit warship propulsor and engine noise to lure in passive homing torpedoes. Power for the motor and electronics of the Lamprey is provided by a thermal battery. The Lamprey is programmed to hover and emit noise until the battery dies where the decoy then sinks and all software onboard is erased.


Flight Deck, Well Deck, & Aircraft/Vehicle Facilities:
Flight deck & Hangar: The Retaliator features a flight deck with a length of 275 meters and a maximum width of 72 meters over the elevators. The flight deck is divided in half by the ship's two islands with the starboard side having a 140 meter length runway with a ski-jump ramp on the end for STOVL aircraft operations and the port side of the flight deck having 6 helipads for for helicopter operations. The flight deck has two deck-edge elevators located one each on the port and starboard side which each measure 15 by 15 meters and with a capacity of 45,000 kg which transfer aircraft between the flight deck and hangar. The hangar is located underneath the rear portion of flight deck and measures 92 meters long, 36 meters wide, and 7.2 meters tall and is divided into two hangar bays by an articulating fire door. Each hangar bay includes a 10-tonne capacity overhead travelling cranes for maintenance operations. The sides of the hangar are bordered by seven avionics repair shops, three machine shops, three composites repair shops, three engine repair shops, and an engine test cell located behind the hangar. The flight deck and hangar can accommodate up to 40 fixed wing STOVL aircraft and helicopters and the ship carries carries 4,800 tonnes of aviation fuel to support aviation operations. In front of the aircraft hangar is the ship's vehicle garage which has two stories connected by a 4 meter wide internal ramp with a total floor area of 2,700 m2 and 4,600 m3 of cargo volume which can accommodate heavy vehicles including main battle tanks and other armored vehicles weighing up to 80 tonnes. Adjacent to the vehicle hangar is the ship's fully equipped hospital with a floor area of 770 m2 which includes six operating rooms, a radiology room, a dentist’s office, and patient rooms capable of hosting up to 72 seriously injured patients. Behind the first story of the vehicle garage and below the aircraft hangar is the ship's well deck which measures 92 meters long by 36 meters wide and can accommodate up to four url=https://forum.nationstates.net/viewtopic.php?p=31883768#p31883768]LCU 40[/url] landing craft.


Passive Protection & Damage Control:
The Retaliator class features significant amounts of passive protection including over 3,000 tonnes of armor which is designed to increase the ship's resilience to missile and bomb hits. The ship's two propulsion and machinery plants, steering gear compartments, aviation magazines, and VLS modules are encased within armored box girders made from welded Ti-6211 titanium alloy plates 50-80 mm thick backed by a spall liner consisting of composite panels made from S-2 glass fibers embedded into an epoxy resin matrix. The ship also features an armored flight deck made from HSLA-115 steel which is 80 mm thick over the hangar and 50mm thick elsewhere. The hangar is protected by 80 mm thick sides, a 50 mm thick hangar deck, and two armored transverse bulkheads 100mm thick (all HSLA-115 steel) which along with the 80mm flight deck form an armored box which completely encloses the ship's hangar.

Damage control on the Retaliator is largely automated due in parts to SDI Naval Systems developed Automated Ship Control System (ASCS). The ASCS is controlled by a centralized computer which amongst other functions provides real-time damage information to the crew through a graphical display located in the ship's damage control center. Additionally both the ship's bridge and CIC also also fitted with displays connected to the ASCS. The ACSC is designed to run automatically where after the ASCS detects damage to a compartment it will immediately isolate it and activate appropriate damage control measures. Alternatively the ASCS can be set to manual mode where the operator will have to specify the damage control measures after the system detects ship damage. The ASCS also controls and monitors the ship's engines and machinery and will alert engineers on watch duty through their assigned tablet computer when an engineering issue or machinery failure is detected and requires attention. This remove the need for time based maintenance, the system will simply alert the crew when a component or system requires maintenance. Each compartment and each piece of machinery on the ship are monitored using SDI's Two Wire Automatic Remote Sensing Evaluation System (TWARSES) which includes both visible CCD and infrared cameras located in each ship compartment. After damage is detected in a compartment the ASCS can respond in a variety of ways including isolating the damaged compartment by closing the electrically actuated watertight doors around the compartment. If the IR camera detects a fire the system will activate the compartment's overhead sprinklers and can also pump the compartment with aqueous film-forming foam , high velocity fog, and/or carbon dioxide agents if necessary. After the fire is extinguished water and firefighter agents are removed using a bilge draining pump installed in each compartment. The ASCS will also reroute ventilation, electrical power, and water around the damaged area and activate additional pumps, generators and other devices if necessary. If the compartment has been breached and is in danger of flooding the system will flood the compartment with foam which rapidly solidifies and restores reserve buoyancy. This system however is only used as an absolute last resort as it renders the compartment unusable. The ASCS also controls the ship's CBRN protection system by passing air from the ventilation intakes through containment filters before it enters the ship. Air in the ship is maintained at 5.0 millibars above local atmospheric pressure to provide a positive pressure and prevent contaminated air from entering into the ship through a breach in the hull.


Armament:
S70 Modular Launch System: The Retaliator class ship is fitted with 32 total S70 cells located in four 8-cell modules mounted fore and aft of the ship's twin island superstructures. The S70 is a cold-launch system which uses missiles encased in individual concentric launch cells as modular all-up rounds (AURs) each containing the missile, concentric launch tube, launch tube electronics, and missile ejection system. The launch cells are inclined at a 10 degree angle towards the ships centerline to prevent missiles with malfunctioning rocket motors from crashing back onto the deck after launch. Each launch cell is capable of accommodating either a single launch tube which can contain a missiles with a maximum length of 7.0 meters, diameter of 0.6 meters, and a weight of 2,500 kg or can be quad-packed with four smaller launch tubes for Rb 73 surface-to-air missiles. The missiles are ejected from each launch tube using a steam generator system which uses a small solid-propellant gas generator which exhausts through cooling water into the base of each launch cell, creating expanding high pressure steam which then forces the missile out of the launch tube. Safety and passive protection features of each VLS module include concentric anti-fragmentation shields placed around each launch cell tube to prevent in-cell missile fratricide and a deluge system which can flood each 8 cell module in the event of a missile catching fire in the launch tube. Launch tubes are connected to the launch cells through shock collar that is designed to absorb acceleration loads from an underwater detonation near the ship. The individual missile cells are connected to the ship's weapon control system via redundant port, central, and starboard fiber-optic Ethernet lines which transmits launch commands to the individual missiles and allows for missile status information before launch to be sent back to the weapon control system.
Last edited by The Technocratic Syndicalists on Thu Aug 27, 2026 8:51 am, edited 32 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Sat Oct 15, 2016 6:57 pm

Image


Sovereign Class Destroyer

Basic Information:
  • Type: Guided missile destroyer
  • Displacement: 17,200 tonnes
  • Complement: 150
  • Length: 215 m
  • Beam: 24.0 m
  • Draft: 9.0 m
Installed Power:
  • 2x SDI PWR 50 pressurized water reactors (PWRs), 200 MWt each
  • 2x AMG 16V 17/19 M64 diesel generators, 2,000 kWe each
Propulsion:
  • 2x SDI High temperature superconducting (HTS) AC Motors, 37.5 MW each
  • 2x shafts, 5 bladed controllable pitch propellers

Performance:
  • Top Speed: 31 knots
  • Range: crew endurance
Sensors and Processing Systems:
  • SDI Typhoon Combat System
  • SDI FMG 300 X band Multi-Function Radar (MFR)
  • SDI FMG 600 S band Volume-Search Radar (VSR)
  • SDI Integrated Bridge and Navigation System
  • SDI EOS 400 Staring Infrared Search & Track System
  • SDI FLG 200 Radar & Electro-Optical Fire Control Director
  • SDI Sea Lance Undersea Combat System
  • SDI RMS 800 Hull-mounted mid-frequency sonar
  • SDI RMS 810 Hull-mounted high-frequency sonar
  • SDI VTS 830 Variable-depth sonar

Electronic Warfare and Countermeasures:
  • SDI FMS 1800 Electronic Warfare System
  • SDI LWG 310 Naval Laser Warning System
  • SDI ZTKG 130 Trainable Decoy Launching System (TDLS)
  • SDI Sea Guardian Surface Ship Torpedo Countermeasure System

Armament:Aircraft Carried:


Overview:
The Sovereign class cruiser is a large nuclear powered guided missile destroyer designed by SDI Shipbuilding Systems. The Sovereign class are designed to act as long range, multirole escorts with the capability to perform anti-aircraft warfare (AAW), ballistic missile defense (BMD), anti-submarine warfare (ASW), naval gunfire support (NGFS), and anti-surface warfare (ASuW) missions


Propulsion:
The Tempest class is powered by two SDI PWR 50 pressurized water reactors (PWRs) with a rated maximum power output of 200 megawatts of thermal energy (MWt).The reactor is fueled using 97% highly enriched uranium (HEU) and is designed for a service life of over 40 years without refueling. The SDI PWR 50 reactor employs integral type circuit design with all primary circuit components including the steam generators are placed inside the reactor pressure vessel. The emergency core cooling system (ECCS) employs our separate systems including a gravity driven water injection system, pressure injection system, passive decay and heat removal system (PDHR), and a reactor protection system (RPS). The reactor core contains 89 fuel assemblies containing binary U-Zr metallic nuclear fuel pellets consisting of 15% zirconium and 85% uranium enriched to a level of 97% U235 with a boron burnable poison coating which gives the reactor a design service life of 45 years before requiring refueling. Pumping for each reactor is provided by four horizontally mounted axial flow pumps attached to the outer shell of the reactor vessel which each provide a flow rate of 95,000 liters per minute (LPM) of cooling water through the reactor core. Each pump is powered by a 500 kW, 460 VAC 3 phase brushless AC motor driven by a variable a frequency drive (VFD). Steam from the two reactors is used to drive four turbogenerators which each employs a double-ended turbine which drives a 120 Hz, 6 phase, 4160 VAC, 25 MW, 3600 rpm high-temperature superconducting (HTS) AC generator. The 100 MWe of electrical power from the four turbogenerators is distributed throughout the ship using a DC zonal electrical distribution (ZEDS). The 4160 VAC from the four turbogenerators is converted to to 6000 VDC with four power conversion modules (PCMs) attached to each generator. The PCMs then supply both port and starboard DC buses which supply power to 16 electrical zones which each include one DC/DC PCM per bus (two each per zone) which converts the 6000 VDC to 750-800 VDC or 650 VDC to supply DC loads in each zone. Both DC/DC PCMs in each zone also supply one or more DC/AC PCMs with 750-800 VDC which then converts the 750-800 VDC to 450 VAC at 60 Hz for AC loads. All electrical loads in each zone are connected to both port and starboard bus ensuring continued operation if either port or starboard bus becomes inoperable.

The warship's integral electric propulsion (IEP) system includes two SDI designed 37.5 MW superconducting motors which directly drive the ship's two propellers. Each 37.5 MW superconducting motor is a three phase, six pole synchronous air-core AC motor with a brushless exciter which has a rated speed of 150 RPM at its design voltage of 7,200 VAC with a full-load efficiency of 97.5%. The complete motor with cryocooler assembly weighs 50 tonnes, approximately 80% less than a conventional AC induction motor of the same RPM and power output. The rotor employs yttrium-barium copper-oxide (YBCO) high temperature superconducting ceramic conductors and is cryogenically cooled to 77 degrees K using gaseous helium from cryocooler module containing single Stage GM cryocoolers located at the non-drive shaft end of the motor which feeds helium gas into the rotor through a rotating seal at the back end of the motor. The rotor housing is further enclosed in a vacuum-sealed cryostat to maintain cryogenic temperatures inside the rotor. The stator coils of the motor are made from copper Litz conductor and are cooled using a liquid dielectric coolant. Each motor employs a variable-frequency drive (VFD) with three separate 2,400 VAC three-phase power modules per drive which allows for efficient motor operation from 6 up to 150 rpm. Each 37.5 MW motor is used to directly drive a single 5.5 meter diameter 5-bladed fixed pitch propeller (CPP) located at the end of a carbon fiber reinforced plastic (CRFP) alloy propeller shaft.


Sensors & Processing Systems:
FMG 300/600 Dual Band Radar (DBR): The SDI Dual Band Radar (DBR) system includes the ships FMG 300 X band Multi-Function Radar (MFR) and FMG 600 S band Volume-Search Radar (VSR). Each radar system consist of three phased-array antennas and associated receiver/exciter (REX) cabinets above -decks in the superstructure and a signal and data processor (SDP) system mounted below-decks inside the hull. Both arrays share a central controller and and a common array power system (CAPS) with power conversion units (PCUs) and power distribution units (PDUs) for each radar antenna. Both arrays are cooled using a closed loop, phase change based common array cooling system (CACS). The X band radar system features a larger operating bandwidth and better low-altitude performance and provides surface search, radar navigation, gun-fire targeting and splash spotting, periscope detection, mine detection, precision target tracking and discrimination, limited volume-search, high-bandwidth missile uplink, and terminal illumination of targets while the S band radar provides long range volume search and long-range target tracking capability. Both the The X band and S band radars can provide simultaneous sector search, environmental mapping, counter-fire/counter-battery tracking, missile tracking, electronic warfare, clutter detection, and in-flight missile guidance and communication. Each X band FMG 300 aperture has a 4-meter square antenna with 10,560 transmit and receive (T/R) modules which use gallium nitride complementary metal-oxide semiconductors (CMOS) on a diamond substrate. The S band FMG 600 antennas are significantly larger at 16 square meters and each use 42,240 full-duplex radio integrated circuit transmit and receive (T/R) modules. Each radar antenna features +/- 60° azimuth and +/- 60° degree beam-steering capability giving the system combined 360° azimuth coverage around the warship. Both radar systems employ wide-band digital receiver/exciter (DREX) units and feature digital beam-forming (DBF) capability, space-time adaptive processing (STAP), and multiple-input multiple-output (MIMO) waveform generation techniques. ECCM capabilities of the dual band radar system include frequency-modulated continuous-wave (FMCW) operating modes, ultra-low sidelobes, high processing gain, pulse-to-pulse frequency agility and ultra wide-band frequency hopping, staggered pulse repetition frequency (PRF) switching, randomized burst transmissions, and automatic jammer detection and tracking. Peak power consumption of the dual-band system is 12 MW and instrumented range is 1,000 km in air-surveillance mode and 2,000 km in ballistic missile tracking mode with the ability to simultaneously track up to 3,000 air targets in air surveillance mode or up to 30 ballistic missile targets in ballistic missile tracking mode.

SDI EOS 400 Staring Infrared Search & Track System: The SDI EOS 400 Staring Infrared Search & Track System is a distributed multi-aperture sensor system which consists of five identical mercury cadmium telluride (HgCdTe) starring focal plane array (FPA) imaging infrared (IIR) sensor units placed around the ship's superstructure which provide combined 360°azimuth and -20° to +75° elevation situational awareness infrared search and track (SAIRST) capability against surface vessel, cruise missile, ballistic missile, and aircraft targets to supplement the active search and track capability of the ship's dual band radar system. The 4096 × 4096 pixel (16 MPA) HgCdTe sensor used by each sensor head operates in the MWIR (3–5 µm) band and features a 95 x 95 degree field of view. The image processing features of the SIRST system include automatic target recognition (ATR) using an on-board threat library, passive ranging algorithms, multi-target adaptive tracking, and clutter rejection techniques. The video feed from the sensor units can be stitched together and displayed on operator consoles in the ship's bridge and CIC to act as a navigational aid and to provide close in situational awareness for the ship's crew.

FLG 200 Radar & Electro-Optical Fire Control System: For short range surface target tracking and gunfire control the ship is equipped with two SDI FLG 200 combined radar and electro-optical fire control directors mounted on either end atop the superstructure. The FLG 200 contains both a Ku band (15.5 - 17.5 GHz) solid state radar and an electro-optical suite containing a thermal imager, television camera, and laser rangefinder which is intended to track both surface targets and subsonic and supersonic sea-skimming missiles in close proximity to the vessel and provides sector search capability, missile launch detection and tracking, and own ship gun fire projectile tracking and splash point detection. The Ku band monopulse radar employs a solid-state Cassegrain antenna connected to a digital receiver and signal processor and transmits with a peak power of 1.5 kW and has a maximum instrumented range of 36 kilometers. The radar is designed with a high level of ECCM features including extremely low sidelobes, high instantaneous bandwidth, and high frequency agility. The electro-optical suite consists of a 1280 x 1024 pixel Midwave IR (3–5 µm) thermal imager with 0.92° to 30.0°horizontal field-of-view and 30x continous optical zoom, 1920 x 1080 pixel CCD daylight television camera with 64x continuous optical zoom, and an Nd:YAG OPO-shifted 1.54 μm eye-safe laser rangefinder with 50m to 40 km range and <1 meter accuracy. The electro-optical system features automatic tracking of up to four simultaneous targets, automatic sector surveillance, simultaneous TV and IR tracking and sensor fusion, recording capability, and integral GPS interferometer system (GPSIS) for far target location (FTL) capability using the system's laser rangefinder to provide 10-digit grid geo-location of surface targets accurate to within 60 meters at ranges up to 40 kilometers. both radar and electro-optical systems are enclosed in a low-RCS triaxially stabilized mounting capable of elevating from -20 to +120° at a rate of 160 °/s and training a full 360° at a rate of 140 °/s.

SDI Sea Lance Undersea Combat System:The SDI Sea Lance Undersea Combat System is the primary undersea combat system fitted to all SDI surface combatants and is designed to detect, locate, track, and engage submersible targets. The Sea Lance system transmits and receives acoustic signals to provide target classification, time motion analysis, and control of anti-submarine and anti-torpedo weapon settings. The Sea Lance system provides multi-sensor track correlation, target track management control, and forwards data to the ship’s command and decision system. The Sea Lance system comprises the RMS 800 hull-mounted mid-frequency sonar; the RMS 800 hull-mounted high-frequency sonar; and the VTS 830 Variable depth sonar. The system provides surface warships with a seamlessly integrated undersea/anti-submarine warfare detection, localization, classification and targeting capability. The system presents an integrated picture of the acoustic tactical situation by receiving, combining and processing active and passive sonar sensor data from the systems twin hull arrays, towed array, and sonobuoys dropped by the ship's ASW helicopter aircraft.

RMS 800/810 Dual-Frequency Hull Array: The SDI Underwater Systems RMS 800/810 dual-frequency hull array assembly is mounted in the ship's bulbous bow and contains both a medium frequency active/passive sonar for submarine detection and a high-frequency mine avoidance sonar. The RMS 800 and RMS 810 sonars have separate transmit and receive arrays but share a common power supply unit and common transmission/reception cabinets, sonar processing unit, and operator consoles. The mid-frequency RMS 800 sonar is a long-range echo ranging sonar with an active frequency range of 6.0 to 9.0 kHz with hyperbolic frequency modulated (FM) and continuous wave (CW) pulse modes with pulse lengths of 60 ms to 4 s. Passive frequency range of the RMS 800 is 1.0 to 9.0 kHz and supports both LOFAR (Low-Frequency Analysis and Recording) and DEMON (Demodulation of Envelope Modulation On Noise) signal processing capability. The RMS 800 sonar features complete 360° detection performance and supports surface duct, bottom bounce, and convergence zone propagation with a maximum detection range out to the first convergence zone of 30-35 nm (55-65 km). The RMS 810 high frequency array is mounted conformally with the RMS -800 mid-frequency sonar and provides detection of moored mines, underwater obstacles, torpedoes, divers, and small underwater vehicles ahead of the ship. The RMS 810 features an active array with a frequency range of 70 to 100 kHz with hyperbolic frequency modulated (FM), linear frequency moduled (LFM), and continuous wave (CW) operating modes and can scan +/- 90° off the ship’s centerline with a maximum detection range of 2.6 kilometers. Both sonars employ a space-time adaptive processing (STAP) algorithm designed to enable adaptive beamforming capability to enable the array to create a virtual 3-dimensional image of sonar contacts in order to accurately separate targets from decoys and from clutter present in littoral waters while also minimizing sonar sidelobes and enabling adaptive angle estimation to more accurately determine target depth, bearing and speed.

VTS 830 Variable depth sonar: The SDI Underwater Systems VTS 830 is an active/passive low-frequency variable-depth sonar designed to detect submarines in both deep blue ocean and shallow littoral environments. The complete VTS 830 system consists of hydrodynamic towed body with active transmitter, passive receive array, towed array handling system with twin winches to deploy and tow the tow body and receive array, shipboard signal transmitter and receiver, and operator control system with four multifunction consoles. The VTS 830 supports low frequency active detection (0.9 to 2.1 kHz) and ultra-high, medium, and low-frequency (<0.1 to 100 kHz) passive detection and environmental monitoring. The sonar employs an omnidirectional transmitter with continuous wave (CW) and low-powered/hyperbolic frequency modulated (LPFM/HFM) pulse modes and multiple receivers including a very low frequency active line array receiver, medium frequency (MF) directional array, and four spherical ultra-high frequency (UHF) hydrophone arrays. The towed body is designed to be towed at depths up to 250 meters with a designed tow speed of 18 knots and a maximum tow speed of 30 knots. The variable-depth sonar can be used in up to sea state 6 and is designed to detect undersea targets out to the second sonar convergence zone (~130 km).


Battle Management & Communications:
SDI Typhoon Combat System: The SDI Typhoon Combat System (TCS) is a comprehensive open-architecture anti-aircraft warfare (AAW) combat management system designed by SDI Missiles & Fire Control Systems which provides fully automated detection, identification, and engagement of air targets. The primary components of the Typhoon Combat System are the Sensor Fusion Processor (SFP), Command and Decision System (C&DS), Typhoon Display System (TDS), Weapons Control System (WCS), and Integrated Ship Computing System (ISCS). The sensor fusion processor or SFP takes tracking data from the ship's radars, IFF system, distributed IRST sensors, and electronic warfare system and correlates them using a contact-to-track data correlation algorithm to provide a single integrated track of each detected target. With the contact-to-track algorithm detected contacts from each sensor (radar, IFF, IR, and ESM) are correlated with existing sensor tracks and merged using a smoothing filter to create a single track file of each correlated target. This allows (for example) the range data from the radar tracks of the dual band radars to be fused with the angle track data from the higher angular resolution IRST sensors, creating a fused 3D track which is more accurate than either the individual radar or IRST sensor tracks. Track data from the sensor fusion processor is fed into the Typhoon Command and Decision System (C&DS) which uses both IFF data and aided and automatic target recognition (Ai/ATR) algorithms to provide identification, threat classification, and weapon assignment of target data input from the sensor fusion processor. Information from the Command and Decision System (C&DS) processor is displayed via the Typhoon Display System (TDS) which uses large multi-function color displays inside the ship's CIC to display target tracks and other situational awareness data to the ship's crew and captain. The TDS consoles also features keyboards for data input which allows doctrinal IF/THEN instructions to be input to the system to the modify its behavior; such as instructing the system that IF any target is detected above a certain speed and altitude in a certain sector THEN it is to be automatically classified as hostile and engaged with a certain missile. The Weapons Control System (WCS) is responsible for launching missiles at targets identified as hostile by the Typhoon Command and Decision System (C&DS). Targets are matched to the ship's missiles by the C&DS which will then send a fire instruction to the weapon control system when the target has entered the engagement zone of the specific missile. The WCS then sends a a firing instruction to the ship's VLS to fire the specific missile and then uses the ship's radars and datalinks to provide midcourse guidance as necessary to guide the missile towards its intended target. The WCS is also responsible for providing Air Intercept Control (AIC) functionality and can be used to guide carrier or land based airborne interceptors towards a hostile target being tracked by the ship. Finally the Integrated Ship Computing System (ISCS) acts as the central processor of the Typhoon combat system and processes radar and and other sensor data and connects all the ships systems including weapons, countermeasures, and communications system together. The ISCS architecture is based on SDI's SPPC10D single-board computer, a ruggedized, shock hardened and conduction cooled computer which employs a 10nm gallium nitride (GaN) on silicon architecture, 48 core (384 thread) superscalar symmetric multiprocessor with a 4.0 GHz clock rate as well as 64 GB of DDR5 DRAM. The SPPC10D computers are each packaged into 16 Electronic Modular Enclosures (EMEs) which each include their own power, shock, vibration, and electromagnetic protection, and water cooling systems. Each EME is a self-contained server and carries 235 cabinets containing the SPPC10D single-board computers. The EMEs which run the ISCS software are interconnected to the rest of the sensors and electrical systems through fiber-optic cables and uses voice-over IP for internal communications between computer systems. The combined computing power of the ship's processors is 27,000 MIPS (million instructions per seconds) at 4.35 GHz with a combined 240 TB of data storage.

An additional ability of the Typhoon Combat System is Distributed Engagement Capability (DEC) which allow target tracking data from multiple sensors across multiple Typhoon equipped platforms in the battle group to be fused together to create a composite track of all air objects within the battle force area and to allow for hunter-killer functionality in the battle group by allowing unit in the battle force to engage a target being tracked by another unit even when the shooter is unable to see or track the target with its own sensors due to either jamming, battle damage, or line-of-sight restrictions. Distributed engagement capability on Typhoon equipped platforms s enabled by a data distribution system (DDS) and a track fusion algorithm (TFA). The data distribution system or DDS consists of four C band planar array antenna assemblies blended into the outer surface of the ship's superstructure which provide extremely high bandwidth line-of-sight communication capability with other sea and air platforms in the battle force. Each DDS antenna array consists of a liquid cooled digital beam forming (DBF) antenna with separate transmit and receive arrays employing gallium nitride (GaN) monolithic microwave integrated circuit (MMIC) transmit/receive (T/R) modules integrated into a common subarray line replacement units (LRUs) and high provides extremely jam resistant and high bandwidth line-of-sight data exchange with other DDS equipped platforms. The track fusion algorithm (TFA) uses the ships ISCP processors to take sensor data received by other units through the data distribution system and fuse it with data from the ships own sensors to create a single composite sensor picture. The main capability of the track fusion algorithm is the ability to network the measurements of radars and other sensors on different platforms tracking the same target and combine them with an intelligent averaging algorithm that creates a single composite track of the target which is more accurate than the track of any individual sensor. When a Typhoon equipped platform establishes a target track with one or more of its sensors a track alert is broadcast across the Typhoon network which then cues the other platforms in the battle force to point their sensors in the direction of the target track. When the other platforms begin tracking the target with their own sensors their sensor measurements are distributed back across the network to every other platform to form the composite track. This capability allows the battle force to maintain track of a target even if any one or even multiple of the battle force units loses the target track due to jamming, battle damage, or environmental effects. When used to fuse radar data from different platforms the track fusion algorithm also enables better radar observation of low observable targets by illuminating them simultaneously with many radars of different wavelengths and scan rates at once, allowing a composite track to be created even if none of the radars in the battle force are able to generate an individual track of the target for more than a few pulses.

SDI FG 710 Shipboard Digital Radio System (SDRS): The SDI FG 710 Shipboard Digital Radio System (SDRS) is a shipboard software defined radio designed by SDI Mission Systems which provides centralized control of all shipboard radio communication systems operating in the 100 MHz to 2 GHz frequency bands. The SDRS can transmit on up to 128 simultaneous channels with programmable waveforms supported by the SDR including 225-400 MHz anti-jam UHF military aircraft radio, low (25-54 MHz), mid (2-76 MHz), and high-band (136-175 MHz) VHF/UHF-FM Land Mobile Radio (LMR), 960-1215 MHz TACAN, 420-450 MHz Enhanced Position Location Reporting System (EPLRS), 108-137 MHz VHF-AM civilian Air Traffic Control, 156 MHz marine VHF-FM radio, 1030 & 1090 MHz IFF, 1350-1850 MHz Digital Wideband Transmission System (DWTS), and others. Encryption options including High Assurance Internet Protocol Encryptor (HAIPE), Advanced Narrowband Digital Voice Terminal (ANDVT), and others as required. Communications through the SDRS are managed by automated digital network system (ADNS) which provides automated LAN/WAN management and integrated network management (INM) of RF signal traffic, automated routing and switching (R&S) of RF transmission circuits, and channel access protocols (CAP) management. The antennas for the SDRS are located in the MERS (Multifunction Electromagnetic Radiation Structure), a low-RCS hexagonal pyramid structure located on top of the ship's superstructure which encloses various communications, datalink, and IFF antennas. The base of the MERS pyramid contains the ship's IFF array which consists of a 360° electronically steerable circular antenna with two rows of 32 elements each (64 total) fed from a central beamforming network which can support both omnidirectional and pencil-beam transmission modes. Above the IFF array are a ring of six 1.0 meter diameter vertically polarized cavity backed UHF spiral antennas with 100W CW of transmit power each in the 225-400 MHz frequency range. The UHF line-of-sight antennas operate in 25 kHz wide transmission bands and allow communication with other surface ships out to 50 kilometers, helicopters out to 200 kilometers, and aircraft out to 600 kilometers. A ring of six L band datalink and TACAN (tactical air navigation system) antennas 25 cm in diameter are placed above the UHF antennas and cover the 960-1215 MHz frequency range with 2kW peak and 400W continuous transmission power. The MERS antennas are embedded into the composite sandwich panels of the mast structure which consist of a fiberglass-epoxy laminate with embedded frequency selective surface (FSS) layers which permits passage of the ship's sensor frequencies while rejecting all others.

Integrated Terminal System (ITS): The ship's SATCOM capability is enabled by the SDI Integrated Terminal System or ITS which provides centralized control of all ship satellite communication systems. For satellite communications capability the superstructure of the ship contains four active phased array SATCOM antenna assemblies embedded into the front, sides, and rear of the superstructure. Each SATCOM antenna assembly contains a central dual-frequency UHF (244 to 318 MHz) and L band (1525 to 1650 MHz) transmit/receive (Tx/Rx) array and two peripheral arrays including an EHF (43.5 to 45.5 GHz) Uplink Tx array and a SHF (20.2 to 21.2) Downlink Rx array providing combined 360° azimuth and -0° to +80° elevation coverage in the UHF, L, EHF, and SHF bands.

SDI FG 410 High Frequency Radio System (HFRS): The SDI FG 410 High Frequency Radio System (HFRS) is a digital solid-state high frequency (HF) communication system supporting interrupted continuous wave (ICW), voice, and digital data communications which provides over-the-horizon ship-to-ship, ship-to-submarine, ship-to-aircraft, and ship-to-shore radio connectivity independent of the SN/USC-71 Shipboard Digital Radio or ITS SATCOM systems. Operating modes supported by HFRS include lower sideband (LSB), upper sideband (USB), independent sideband (ISB), frequency shift keying (FSK), continuous wave (CW), and amplitude modulation equivalent (AME). The HFRS consists of a transmitter subsystem, receiver subsystem, and a remote control/ monitor subsystem (RCMS). The transmitter subsystem supports 4,8, and 12 kW transmit power and operates in the 2 Mhz to 30 Mhz frequency range in 10 Hz increments with the ability to shift transmit frequency in less than 100 milliseconds and transmits through two 10 meter whip antennas located forward and aft on top of the superstructure. The receiver subsystem operates in the 14 Khz to 1.619 Mhz and 2 Mhz to 30 Mhz range and uses three smaller whip antennas mounted on the superstrucutre, two for the receiver system only and one which is shared with the ship's Ship Signal Exploitation Equipment (SSEE) system. The remote control/ monitor subsystem (RCMS) is primarily a manual backup system which used to provide control over the HFRS if the ship's SACCs (Ship Automated Communications Control System) becomes inoperable.

SDI FG 620 High Frequency Management System (HFMS): The SDI High Frequency Management System or HFMS is a complimentary system to the SDI High Frequency Radio System and uses an oblique incidence sweep-frequency ionospheric chirpsounder to determine the best HF transmission frequencies based on current ionospheric propagation measurements conducted by the chirpsounder. The chirpsounder sweeps upwards from 2 to 30 MHz in 4 minute intervals and can be synchronized with up to three separate HF transmitters which when synchronized allow them to transmit as much radio energy to a receiver as is possible under current ionospheric propagation conditions.

SDI FG 320 Tactical High-Bandwidth Datalink (THBD): The SDI Tactical High-Bandwidth Datalink (THBD) is a full-duplex RF data link system operating in the Ka (14.4 GHz - 15.5 GHz) and X (9.7 GHz - 10.5 GHz) bands and is designed primarily to allow signal and imagery intelligence from airborne reconnaissance platforms to be streamed to ships in real time at distances up to 300 km. The system supports selectable 10.71,137, or 274 Mbps downlink rates with binary phase-shift keying (BPSK) downlink modulation and an uplink rate of 200 Kbps with offset quadrature phase-shift keying (OQPSK) modulation. The THBD system is coupled with a shipboard imagery exploitation system which has the the capability to receive, process, store, exploit, and disseminate Imagery Intelligence (IMINT) reports based on imagery received through the SN/USQ-123 datalink.

Global Position System (GPS): The ship employs GPS for precision navigation capability and has four 18 cm diameter GPS antennas covering the L1 (1.575GHz) and L2 (1.227GHz) frequencies blended into the upper corners of the deckhouse which provide 360° azimuth and -0° to +80° elevation coverage.


Electronic Warfare & Countermeasures:
FMS 1800 Electronic Warfare System The primary electromagnetic countermeasure system of the Tempest class cruiser is the FMS 1800 Electronic Warfare System, a comprehensive offensive and defensive electronic warfare (EW), electronic support measures (ESM), and electronic intelligence (ELINT) suite which combines passive radar warning receivers and phased array jammers for long range, over-the-horizon detection, identification, and targeting of threat emitters as well as automatic employment on-board RF countermeasures and support of passive over-the-horizon targeting capability for the ship's weapon systems. The passive radar warning system of the FMS 1800 consists of multiple single-quadrant, high-gain linear interferometer arrays smoothly blended into the superstructure of the vessel connected to a set of digital receivers and pulse processors inside the ship's superstructure which provide for 360 degree spherical broadband, all aspect detection, identification, and direction-finding of radar emissions with the capability for precise emitter location and threat identification capability against low probability of intercept waveforms and with additional over-the-horizon direction finding capability of MF, HF, VHF, and UHF band signals. The offensive electronic warfare capability of FMS 1800 system includes multiple low, mid, and high band electronically scanned gallium nitride (GaN) based Digital Radio Frequency Memory (DRFM) jammers blended into the superstructure which provide for the jamming of hostile RF sensors. The SES-1800 is a fully cognitive and adaptive system; by using radar emission data collected from the FMS 1800s radar warning the DRFM jammers can automatically adapt in real time to unknown waveform characteristics, dynamically synthesize countermeasures, and jam the waveform accordingly. The DRFM Jammers of the SES-1800 also includes false target generation capability allowing the FMS 1800 to generate up to 32 simultaneous false surface and air targets at ranges up to 625 kilometers to spoof hostile radar systems. Designed to spoof wideband phased array radars with moving-target indicator (MTI) and inverse synethic aperture radar (ISAR) capability, the false-target generation system of the FMS 1800 comprises a receiver system for producing a false signal that mimics an incident radar pulse, a phase sampling circuit is connected to the FMS 1800 radar warning receivers for sampling the signal and providing phase sample data, and an image synthesizer circuit is connected to the phase sampling circuit and arranged to receive the phase sample data from the circuit which processes the phase sample data to form a false target signal which is input to a signal transmitter system built into the FMS 1800s DRFM jammer array which is arranged to transmit the synthesized false target signal so that it can be received by the threat radar system.

LWG 310 Naval Laser Warning System: For detecting laser sources including laser range finders, laser target designators, and laser beamriding missiles the ship's FMS 1800 system is augmented by an SDI LWG 310 Naval Laser Warning System. The vessel's LWG 310 installation consists of a central controller connected eight sensor heads, four on each side of the superstructure, providing combined 360° coverage around the vessel. Each individual sensor head features 110° azimuth and +/- , 70° elevation coverage and is capable of detecting up to eight simultaneous laser range finders laser target designator emissions in the 0.5 μm - 1.65 μm range and laser beamriders in the 0.8 μm - 1.1 μm range.

SDI Sea Guardian Surface Ship Torpedo Countermeasures System: The Sovereign class is fitted with the SDI Sea Guardian Surface Ship Torpedo Countermeasure System which combines various soft-kill and hard-kill torpedo countermeasure systems. The Sea Guardian system consists of a towed array sonar designed specifically for torpedo detection, a towed acoustic decoy with a a single-drum winch, an interface to the ship's trainable decoy launchers, and a processing cabinet with two display consoles, and and four 4-round anti-torpedo torpedo launchers on either side of the ship. The towed array sonar used by the system is a combined active and passive array sonar optimized to detect the high frequency sound signature of torpedo screws and active sonar homing heads. The towed array is supported by two vibration isolated modules (VIMs) located on either side of the sonar with the array being connected on one end to the ship using a fiber-optic tow cable and connected on the other end to the towed decoy with an array tow cable. The towed decoy array is designed to emit simulated ship noise such as propulsor and engine noise to lure a passive-sonar homing torpedo to the decoy instead of the ship. The towed decoy can also receive sonar pings from the active homing head of a torpedo and amplifies and returns the "pings" to the torpedo, presenting a larger false target to the torpedo. The hardkill component of the Sea Guardian system comprises a series of four box launchers on either side of the vessel which each contain six SDI S2s Barracuda anti-torpedo torpedoes in individual all-up rounds (AUR) which contain the Barracuda torpedo and a self-contained compressed gas launch system. The Barracuda torpedo is 21 cm in diameter, 2.0 meters in length, weighs 110 kilograms, and contains a 20 kilogram aluminized PBX explosive warhead. The guidance and fusing system of the Barracuda is designed to explode it in front of the oncoming torpedo and create a pressure wave which crushes the nose section of the oncoming torpedo. The Barracuda has a maximum firing range of 10 kilometers and is propelled by an advanced stored chemical energy propulsion system (ADSCEPS) which can propel the Barracuda at speeds up to 60 knots at depths up to 1,000 meters. Although designed as an anti-torpedo the Barracuda can also be used to engage midget submarines, naval mines, and unmanned or autonomous underwater vehicles.

ZTKG 130 Trainable Decoy Launching System (TDLS): The ZTKG 130 Trainable Decoy Launching System (TDLS) is an aimable decoy launcher which can launch a variety of decoys designed to decoy away anti-ship missile and torpedo threats. The ZTKG 130 system consists of multiple 12-round trainable countermeasures launchers controlled by a central command console inside the ship. Each 12-round launcher employs a rotating platform with 12 separate 130mm barrels which can each be individually trained in elevation. The ship is fitted with four decoy launching systems, two on either side of the ship used for acoustic torpedo decoys (24 total) and another two launcher on each side used for chaff/flare rounds and missile seduction decoys (24 total).

[list]AM5 dual chaff/IR seduction decoy: The primary chaff seduction round employed by the DLS is the AM5 dual chaff/IR seduction decoy which is capable of defeating dual-seeker missiles equipped with both IR/EO and radar seekers. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.

AM79 Buzzard active missile decoy: For decoying away radar-guided anti-ship missiles the DLS can deploy the AM79 Buzzard active missile decoy, an expendable electronic-warfare rotary-wing drone which is designed to seduce RF guided anti-ship missiles by simulating the radar return of a large surface vessel. The buzzard features a cylindrical shaped fuselage 130 mm in diameter and 0.9 meters tall with both top and bottom mounted 1.8 meter diameter three-bladed counter-rotating coaxial rotors powered by two brushless DC motors. The rotors unfold from the body of the decoy after launch and fly the decoy into a pre-programmed flight path away from the ship where the decoy then hovers in place while emitting electronic warfare signals uses its fuselage mounted Digital Radio Frequency Memory (DRFM) jammers which are designed to seduce oncoming anti-ship missiles into targeting the decoy and not the host vessel. The decoy is powered by a thermal battery mounted in the center of the fuselage which gives the decoy approximately 60 minutes of flight endurance after launch.

AM7 Lamprey acoustic decoy:The DLS can also launch the AM7 Lamprey, a 130mm diameter, expendable acoustic decoy designed to counter torpedo threats. After a rocket-powered launch into ocean the Lamprey is programmed to hover vertically using a pressure-controlled motor driving a small, shrouded propeller in the tail of the decoy. The Lamprey is designed to hover at a pre-selected depth from 10-300 meters where it listens for torpedo transmissions. Active acoustic transmissions are detected and analyzed resulting in decoy selectivity and generation of the appropriate deception signal for transmission including target signature and target self noise. If no torpedo transmissions are detected the decoy is programmed to emit warship propulsor and engine noise to lure in passive homing torpedoes. Power for the motor and electronics of the Lamprey is provided by a thermal battery. The Lamprey is programmed to hover and emit noise until the battery dies where the decoy then sinks and all software onboard is erased.


Passive Protection & Damage Control:
Sovereign class cruiser features significant amounts of passive protection designed to increase the ship's resilience to missile and torpedo or mine impacts. The ship's propulsion and machinery plants, steering gear, gun magazines, and VLS modules are encased within armored box girders made from welded Ti-6211 titanium alloy plates 50-80 mm thick. The titanium armor is backed by a spall liner consisting of composite panels made from S-2 glass fibers embedded into an epoxy resin matrix .

Damage control on the Sovereign class is largely automated due in parts to SDI Naval Systems developed Automated Ship Control System (ASCS). The ASCS is controlled by a centralized computer which amongst other functions provides real-time damage information to the crew through a graphical display located in the ship's damage control center. Additionally both the ship's bridge and CIC also also fitted with displays connected to the ASCS. The ACSC is designed to run automatically where after the ASCS detects damage to a compartment it will immediately isolate it and activate appropriate damage control measures. Alternatively the ASCS can be set to manual mode where the operator will have to specify the damage control measures after the system detects ship damage. The ASCS also controls and monitors the ship's engines and machinery and will alert engineers on watch duty through their assigned tablet computer when an engineering issue or machinery failure is detected and requires attention. This remove the need for time based maintenance, the system will simply alert the crew when a component or system requires maintenance. Each compartment and each piece of machinery on the ship are monitored using SDI's Two Wire Automatic Remote Sensing Evaluation System (TWARSES) which includes both visible CCD and infrared cameras located in each ship compartment. After damage is detected in a compartment the ASCS can respond in a variety of ways including isolating the damaged compartment by closing the electrically actuated watertight doors around the compartment. If the IR camera detects a fire the system will activate the compartment's overhead sprinklers and can also pump the compartment with aqueous film-forming foam , high velocity fog, and/or carbon dioxide agents if necessary. After the fire is extinguished water and firefighter agents are removed using a bilge draining pump installed in each compartment. The ASCS will also reroute ventilation, electrical power, and water around the damaged area and activate additional pumps, generators and other devices if necessary. If the compartment has been breached and is in danger of flooding the system will flood the compartment with foam which rapidly solidifies and restores reserve buoyancy. This system however is only used as an absolute last resort as it renders the compartment unusable. The ASCS also controls the ship's CBRN protection system by passing air from the ventilation intakes through containment filters before it enters the ship. Air in the ship is maintained at 5.0 millibars above local atmospheric pressure to provide a positive pressure and prevent contaminated air from entering into the ship through a breach in the hull.


Armament:
20.3 cm SK L/60 Naval Gun: The 20.3 cm SK L/60 is a fully automated and stabilized, single barrel naval artillery gun system designed for use against surface targets and as a long-range shore bombardment weapon. The gun system consists of three sub-assemblies, the SK L/60 gun assembly with its enclosed triaxial stabilized gun mount, automated ammunition supply system, and fire control support system and crew display with control consoles. The SK L/60 gun features a 60 caliber length monobloc barrel and features a semi-automatic vertically sliding breechblock which is automatically opened under the force of recoil. The breech is sealed with a mild steel case containing the propellant charge. The gun can fire either standard spin stabilized 110 kilogram 20.3 cm base-bleed (BB) projectiles including high explosive and cluster-HEAT with a muzzle velocity of 1,050 m/s out to a range of 60 kilometers or can fire a 180 kilogram rocket assisted, fin stabilized IRGM (infrared guided munition) projectile at a muzzle velocity of 825 m/s out to a range of 200 kilometers. The gun can be loaded any any angle of elevation and has a maximum sustained rate of fire of 12 rounds per minute. The gun is fed from an automated ammunition supply system consisting of a projectile and propellant charge hoist, automatic fuze setter, and a service drum located directly under the gun house which contains 75 projectiles and 75 propellant charges. An additional 400 rounds and 400 propellant charges are located in a two story magazine below the ready service drum including 80 IRGM projectiles. The mount is capable of training to +/- 165° on either side of the ships centerline at a rate of 30° per second and elevating from -10° to +70° at a rate of 20° per second. A shipboard fire control support system is used for control of the gun which plans fire support missions, determines firing solutions and shell trajectories, selects ammunition, and determines the best ship course for executing fire support missions.

Medium-Caliber Gun System (MCGS): For close in defense against small boats the ship is fitted with two SDI medium-caliber gun system (MCGS) turrets placed amidships on the top of the superstructure. Each MCGS mount contains an SDI 4.0 cm SK L/70 Flak cannon and an electro-optical targeting sensor with a forward looking infrared sensor, low light television camera, and a laser rangefinder. The 4.0 cm SK L/70 is an air-cooled, recoil operated automatic cannon which fires 40×365mmR ammunition at a rate of up to 300 rounds per minute. The 4.0 cm SK L/70 gun is housed in a triaxial stabilized low-RCS gunhouse constructed from fiberglass and is capable of traversing a full 360° at a speed of 130°/sec and is capable of elevating from -20° to +80° at 75°/sec. The gun includes an on-mount muzzle velocity radar and is designed to fire 0.975 kg programmable air-burst munition (PABM) projectiles at a muzzle velocity of 1,012 m/s. The 40mm PABM round contains 0.12 kg of HMX based polymer bonded explosive (PBX) surrounded by over 3,000 tungsten balls 3mm in diameter and features a multi-mode programmable fuze with six operating modes; proximity, gated proximity, gated proximity with impact priority, timed airburst, impact, and impact plus delay modes. The gun is fitted with a 72 round magazine which is automatically replenished by an additional 72 round magazine located inside the gun house. Total weight of the MGCS is 2,300 kg empty and 2,650 kg with a full load of ammunition.

SDI Obelisk Laser System: Each Sovereign class destroyer is equipped with an SDI Obelisk Ship-mounted Fission-Activated Laser Weapon System. the Obelisk system uses fission fragment energy from a compact fast-spectrum nuclear reactor to directly pump a large-volume noble gas laser medium, producing continuous-wave or pulsed laser output at megawatt power levels across selectable wavelengths from the visible to the near-infrared spectrum. The direct nuclear pumping approach eliminates the multi-stage energy conversion losses inherent in conventional electric laser architectures, resulting in a self-powered, compact system with effectively unlimited magazine depth and no requirement for dedicated shipboard electrical generation capacity. The primary mission of Obelisk is terminal defense against supersonic and subsonic sea-skimming anti-ship cruise missiles and anti-ship ballistic missiles during their terminal phase. Secondary missions include counter-air operations against manned and unmanned aircraft, surface target engagement, anti-satellite operations in low Earth orbit, and high-resolution long-range active imaging and target discrimination. The Obelisk beam director is mounted ahead of the superstructure, with the beam director capable of training to +/- 135° on either side of the ships centerline. The laser module including the reactor is mounted below the waterline, connected to the beam director with a long beam transfer tube.

S70 Launch System: The Sovereign class ship is fitted with a total of 192 S70 launch system cells located in three 64 cell modules forward and aft of the superstrucutre along the ship's centerline. The S70 is a cold-launch system which uses missiles encased in individual concentric launch cells as modular all-up rounds (AURs) each containing the missile, concentric launch tube, launch tube electronics, and missile ejection system. The launch cells are inclined at a 10° angle towards the ships centerline to prevent missiles with malfunctioning rocket motors from crashing back onto the deck after launch. Each launch cell is designed to accommodate a single all-up-round (AUR) launch canister which can contain missiles with a maximum length of 7.0 meters, diameter of 0.6 meters, and a weight of up to 2,500 kg. The missiles are ejected from each launch canister using a steam generator system which uses a small solid-propellant gas generator which exhausts through cooling water into the base of each launch canister, creating expanding high pressure steam which then forces the missile out of the launch canister. Safety and passive protection features of each VLS module include concentric anti-fragmentation shields placed around each launch cell to prevent in-cell missile fratricide and a deluge system which can flood each 4 or 8 cell module in the event of a missile catching fire in the launch tube. Launch canisters are connected to the launch cells through shock collar that is designed to absorb acceleration loads from an underwater detonation near the ship. The individual missile cells are connected to the ship's weapon control system via redundant port, central, and starboard fiber-optic Ethernet lines which transmits launch commands to the individual missiles and allows for missile status information before launch to be sent back to the weapon control system.
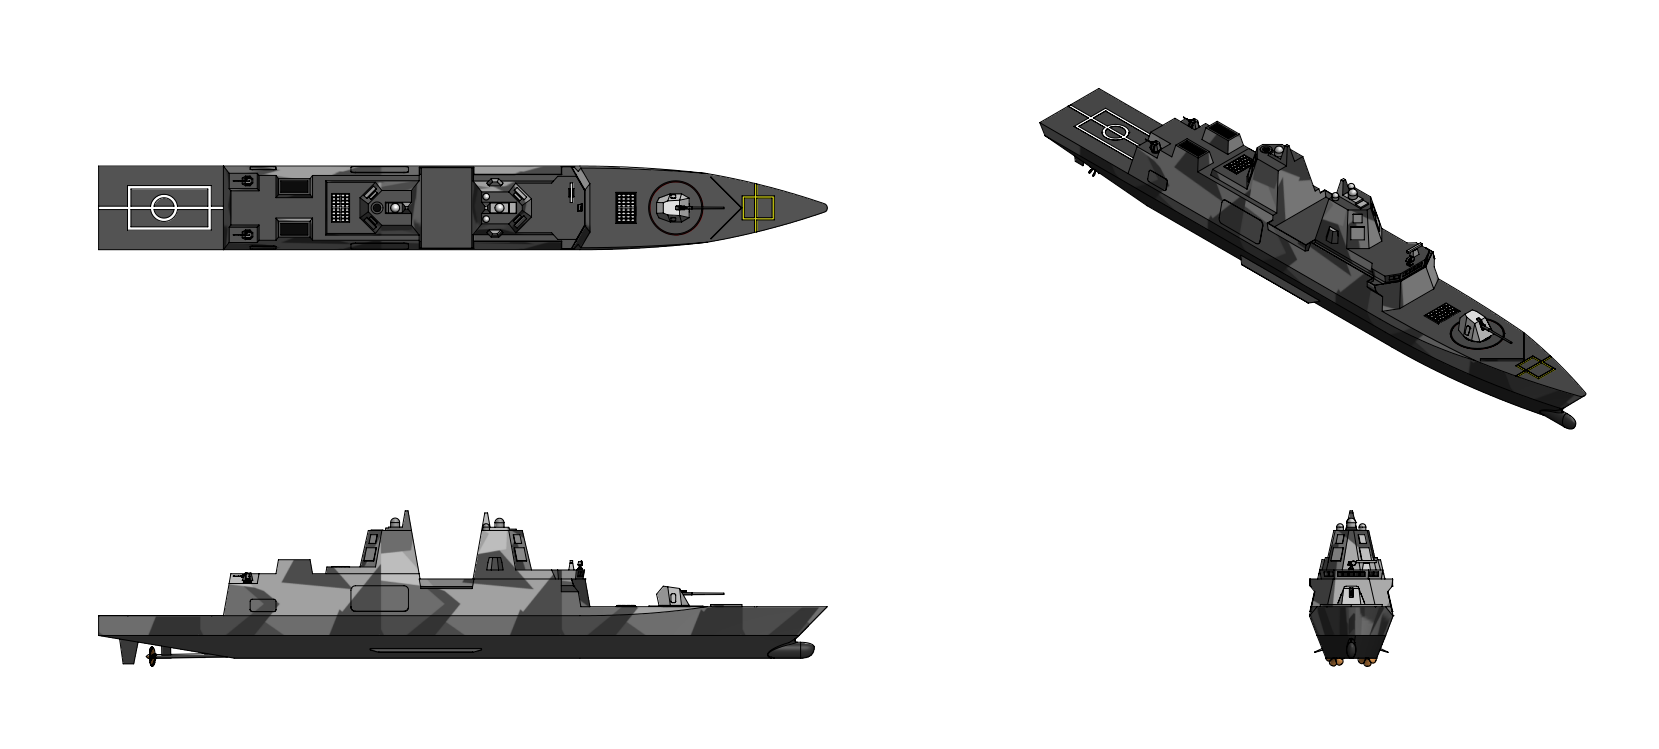
S120 Launch System: In addition to the 192 S70 launch cells the Sovereign class is fitted with a total of 12 S120 launch cells forRBS 97 Arclight hypersonic boost-glide missiles in one forward 12-cell module containing 12 launch cells in a 4x3 arrangement with launch cells angled 10° towards the ships centerline. Each launch cell is designed to accommodate a single RBS 97 all-up-round (AUR) launch canister containing a single RBS 97 hypersonic boost glide missile. Like with the smaller S70 launch canisters the RBS 97 missiles are ejected from each S120 launch canister using a steam generator system which uses a small solid-propellant gas generator which exhausts through cooling water into the base of each launch canister, creating expanding high pressure steam which then forces the missile out of the launch canister. Safety and passive protection features of each S120 VLS module include concentric anti-fragmentation shields placed around each launch cell to prevent in-cell missile fratricide and a deluge system which can flood each 12 cell module in the event of a missile catching fire in the launch tube. Launch canister are connected to the launch cells through shock collar that is designed to absorb acceleration loads from an underwater detonation near the ship. The individual missile cells are connected to the ship's weapon control system via redundant port, central, and starboard fiber-optic Ethernet lines which transmits launch commands to the individual missiles and allows for missile status information before launch to be sent back to the weapon control system.

40 cm Torpedo Launch System : For close-in anti-submarine the ship is equipped with two twin 40 cm Torpedo Launch Systems, one on each side of the hull for launching SDI F3s Viperfish anti-submarine torpedoes. The torpedo launchers are located in recesses below the flight deck near the aft of the ship which are covered by armored doors when not in use. Each Torpedo Launch System consists of twin fixed shock mounted 40 centimeter torpedo launch tubes, an air charging system, a 12 cell torpedo magazine, and a launcher control station which is connected to the ships' Sea Lance Undersea Combat System. Each F3S Viperfish torpedo is 40 cm diameter, 2.85 meters long lightweight anti-submarine torpedo powered by advanced stored chemical energy propulsion system (ADSCEPS) driven pumpjet propulsor. The torpedo has a maximum speed of 60 knots with a range of 15 km at 60 knots or 25 km at a lower speed of 40 knots. The F3S torpedo is equipped with a fully digital electronically steered 2D phased array active/passive sonar seeker combined with fiber-optic wire guidance. The torpedo is equipped with a 60 kilogram shaped charge warhead designed to penetrate the hulls of large double-hulled submarines.
Last edited by The Technocratic Syndicalists on Wed May 06, 2026 10:11 am, edited 71 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Tue May 30, 2017 10:35 pm

Image


Dragon Class Frigate

Basic Information:
  • Type: Frigate
  • Displacement: 10,400 tonnes (full load)
  • Complement: 150-200
  • Length: 166 m
  • Beam: 22 m
  • Draft: 6.0 m

Propulsion: CODLAG
  • 1x SDI5000 Gas Turbine, 54 MW
  • 4x AMG 20V 17/21 M95 High-speed diesel generators, 4.1 MW each
  • 2x 5.0 MW electric motors
  • 2x shafts, 5 bladed controllable pitch propellers
  • 1x 1 MW bow thruster

Performance:
  • Top speed: 32 knots
  • Range: 15,000 km at 20 knots
Sensors:
  • SDI FMG 300 X band Multi-Function Radar (MFR)
  • SDI FMG 400 C band Volume Search Radar (VSR)
  • SDI Integrated Bridge and Navigation System
  • SDI EOS 400 Staring Infrared Search & Track System
  • SDI FLG 200 Radar & Electro-Optical Fire Control Director
  • SDI Sea Lance Undersea Combat System
  • SDI RMS 800 Hull-mounted mid-frequency sonar
  • SDI RMS 810 Hull-mounted high-frequency sonar
  • SDI VTS 830 Variable-depth sonar
  • SDI Deployable Acoustic System

Countermeasures:
  • SDI FMS 1800 Electronic Warfare System
  • SDI LWG 310 Naval Laser Warning System
  • SDI ZTKG 130 Trainable Decoy Launching System (TDLS)
  • SDI Sea Guardian Surface Ship Torpedo Countermeasure System

Armament:

Aircraft Carried:


Overview:
The Dragon class frigate is a class of large multirole frigates designed by SDI Shipbuilding Systems. The Dragon class are designed to act as long range escorts for conventional powered aircraft carrier and amphibious assault groups and combine extensive anti-submarine warfare (ASW) systems with anti-aircraft warfare (AAW), naval gunfire support (NGFS), and anti-surface warfare (ASuW) capability.


Design & Construction:
The Dragon class features a fine entry, transom stern, flared bow monohull designed to balance seakeeping and low resistance. The bow features a pronounced flare and a deep forefoot with an integrated bulbous bow. The hull transitions to a broad, flat bottom midship section that maximizes internal volume for machinery and magazine spaces while providing a stable platform for helicopter operations in high sea states. The transom stern is shaped to minimize stern wave interaction at sprint speed and to provide a clean wake for towed array sonar deployment. The large bilge radius in conjunction with a pair of passive anti-roll fins and an active stabilization system to achieve a natural roll period that avoids resonance with typical wave spectra. The hull lines aft are shaped to accommodate a twin haft arrangement with adequate propeller hull clearance to minimize cavitation induced hull vibration and radiated noise. The hull is constructed from St 92 (900 MPa yield strength) high-strength structural shipbuilding steel and features 100% welded construction The hull is a double hull design with the outer hull providing fragmentation and blast protection and the inner hull serving as the primary watertight boundary. The transverse bulkheads are double layer blast resistant designed designed to withstand the overpressure and fragmentation effects of a bomb or missile warhead detonating in an adjacent compartment. The superstructure is designed as an integrated deckhouse enclosure that merges smoothly with the hull topsides, eliminating the traditional breakpoints and angular features that generate strong radar returns. All exterior surfaces are composed of large, flat panels arranged at controlled inclination angles to deflect incident radar energy. Deck edge details, equipment housings, weapon mounts, and antenna pedestals are either concealed within the deckhouse volume or enclosed in radar transparent fairings.


Propulsion
SDI5000 Gas Turbine
  • Type:Aeroderivative gas-turbine
  • Length: 8.7 m
  • Width: 3.6 m
  • Height: 4.5 m
  • Weight: 16,800 kg
  • Compressor: 5 stage LPC, 9 stage HPC
  • Compression ratio: 52:1
  • Combustor: annular combustor
  • Turbine: 2 stage HPT, 3 stage LPT, 5 stage LPT
  • Thermal efficiency: 52%
  • Specific fuel consumption: 175 g/kW-hr
  • Output: 54,000 kW
  • Fuel: J9

AMG 20V 17/21 M95
  • Type:diesel generator
  • Length: 6.35 m
  • Width: 1.88 m
  • Height: 2.41 m
  • Dry Weight: 19,350 kg
  • Type: 4 stroke
  • Arrangement: 20V
  • Cylinder bore: 170 mm
  • Piston stroke: 210 mm
  • Displacement: 96.4
  • Speed: 1500 rpm
  • Aspiration: sequential turbocharging
  • Rotation: Counterclockwise flywheel
  • Specific fuel consumption: 190 g/kW-hr
  • Output: 3,000 kW
  • Generator: 4 pole three-phase synchronous generator
  • Fuel system: Modular common rail (MCRS)
The Dragon class frigate employs a combined Diesel Electric and Gas Turbine (CODLAG) propulsion system which uses a diesel electric drive for low speed operations and a geared gas turbine for high speed operations. The geared gas turbine drive employs an SDI5000 gas turbine which drives the ship's two propeller shafts through a synchro-self-shifting (SSS) clutch attached to a cross-connecting gearbox in turn connected to two main drive gearboxes which drive the two propeller shafts. The electric drive consists of two 5.0 MW permanent magnet AC motors which are mounted to the main gearboxes aft of the propeller shafts. Two multi-disc clutches in each main gearbox are used to engage and disengage the electric motors and gas turbine from the propeller shafts. Electricity for the motors and for the ships hotel loads are supplied by four 3.25 MW diesel generator sets. In electric drive mode the gas turbine gearbox is clutched out and the ship's propeller shafts are driven by the electric motors at speeds up to 20 knots. For higher speeds the gas turbine is clutched in to drive the ship up to speeds of 32 knots. The cross connecting gearbox incorporates self synchronising clutch units that allow the gas turbine to be connected to or disconnected from the drive train without interrupting propeller rotation, enabling seamless transitions between operating modes.

The SDI5000 is an aeroderivative gas turbine designed by SDI Power Systems and is used as the high-speed prime mover for the ship's CODLAG propulsion system. The SDI5000 is an intercooled, recuperated marine gas turbine in the 50 MW class built around a two-spool aeroderivative gas generator core derived from the latest generation of SDI civil high-bypass turbofan technology, coupled with a free power turbine for output shaft power extraction. The SDI5000 employs an intercooled, recuperated two-spool gas generator with free power turbine cycle architecture. Ambient air enters through the engine inlet system and is compressed sequentially through the low-pressure compressor (LPC) and high-pressure compressor (HPC), driven by the low-pressure turbine (LPT) and high-pressure turbine (HPT),respectively. After compression, the air passes through the recuperator heat exchanger where it is preheated by hot exhaust gas recovered from downstream of the power turbine, before entering the combustor where fuel is injected and burned. The hot combustion products expand through the HPT and LPT and then through the free power turbine (FPT). After the power turbine, the exhaust gas passes through the hot side of the recuperator, transferring a portion of its residual thermal energy to the incoming compressed air, before being discharged through the exhaust system. The turbine is housed in a modular, acoustically treated enclosure within the central aft machinery compartment. The enclosure incorporates intake and exhaust silencing, fire suppression systems, and a full suite of health monitoring sensors. The SDI5000 is designed for oncondition maintenance supported by a comprehensive engine health monitoring system that continuously tracks over 300 parameters including vibration spectra, gas-path temperatures, oil debris content, and compressor efficiency. The engine is designed for removal and replacement as a complete module through a dedicated hatch in the upper deck, enabling an engine change in less than 48 hours alongside. For operation in diesel-electric mode the ship employs twin 5.0 MW permanent magnet motors to drive the propeller shafts. The motors are axial flux permanent magnet AC motors employing a neodymium-iron-boron permanent magnet rotor with a segmented, fractional slot stator winding that minimizes torque ripple and cogging torque. The motors are liquid cooled using a closed loop freshwater system to maintain stable operating temperatures and eliminate the acoustic contribution of forced air cooling fans. Motor speed control is provided by advanced silicon carbide (SiC) insulated gate bipolar transistor (IGBT) variable frequency drives (VFDs) that convert the MVDC bus power to the variable frequency AC required by the motors. Each motor is connected to a double helical gear reduction gearbox mounted to each main drive gearbox which is used to reduce the motor speed from 1900 to 270 RPM where it then connects to the end of the propeller shaft through a flexible shaft coupling attached to a multi-disc clutch used to engage and disengage the motor from the propeller shaft. Each motor is mounted to the main reduction gearbox through a flexible coupling that accommodates misalignment and provides of vibration isolation and are supported on resilient mounts that decouple their vibration from the ship's hull.

Two main reduction gearbox units, one per shaft, are located in the aft machinery compartment. Each gearbox accepts power inputs from both the gas turbine via the cross-connecting gearbox and an electric motor, combining the inputs to drive the propeller shaft. The gearboxes are locked-train, double-helical, epicyclic designs that provides high torque capacity in a compact package with low noise and vibration. Gear tooth profiles are ground to AGMA Grade 14 accuracy and are specially optimized for minimum transmission error. The cross-connecting gearbox is located forward of the main reduction gearbox units and distributes the gas turbine output to both shafts and incorporates two self-synchronising, controlled-slipping clutch (SSS) units that engage automatically when the gas turbine output shaft speed exceeds the driven shaft speed and disengage cleanly when the gas turbine is shut down. The propeller shafts are manufactured from carbon fiber reinforced epoxy with a quasi-isotropic stacking sequence in the central portion of the tube, transitioning to a ±15° angle-ply at the metallic end fittings to maximize torque transfer at the bond line. Bond lines use a structural epoxy adhesive co-cured with the laminate supplemented by tapered titanium pins through both the tube and the end fitting for failsafe redundancy. Each shaft runs in hydrodynamic, water lubricated polymer bearings in the shaft brackets and stern tube. The stern tube seals are air-backed lip-seal types with integrated condition monitoring sensors. The shafts are supported by two intermediate bearings each mounted on resilient mounts to minimize structure borne noise transmission. Each shaft terminates in a large diameter highly skewed controllable-pitch propeller (CPP). The propellers are five bladed with a diameter of approximately 4.8 meters and a disc area ratio optimized for maximum cavitation inception speed. The blade profiles are designed to provide a uniform pressure distribution minimizing tip vortex cavitation and sheet cavitation at operationally significant speeds. The blade pitch is continuously variable over the full range from full ahead to full astern, controlled by a hydraulic actuator within the propeller hub. The pitch control system is integrated with the propulsion control system and supports automated pitch scheduling that optimizes blade angle for the current speed, power, and sea state conditions. In ASW patrol mode the pitch schedule is constrained to a cavitation free envelop, ensuring that the propellers do not cavitate at patrol speeds under any anticipated sea state conditions.

Electrical power is provided by four AMG 20V 17/21 M95 high speed diesel generator sets each providing 4,100 kWe of 50 Hz AC power. The AMG 20V 17/21 M95 is a 4-stroke V20 fuel-injected turbocharged marine diesel engine with a 17 centimeter bore, 21 centimeter stroke, and 96.4 liter displacement and has a maximum mechanical power output of 4,300 kWm at 1,500 rpm. The engine employs sequential turbocharging with twin water-cooled turbochargers with an engine coolant temperature-controlled intercooler. The engine is used to drive a brushless three-phase four-pole synchronous AC generator which outputs a maximum of 4,100 KWe of 50 Hz AC power. The four generator sets are arranged in two pairs, with one pair located in the forward machinery compartment and one pair in the aft machinery compartment Each generator is mounted on an advanced double stage vibration-isolating raft system that provides greater than 40 dB of vibration isolation at blade passing frequency and above. The rafted mounting systems are suspended from the ship's structure by elastomeric isolators with a natural frequency below 5 Hz, ensuring that diesel generator vibration does not couple into the hull structure and degrade sonar performance. All four generators are mounted above the waterline on the second deck level, ensuring accessibility for maintenance and reducing the risk of flooding induced power loss. Power from the generators and from the drive motors (in generator mode) is used to power the ships zonal Medium Voltage Direct Current (MVDC) electrical system operating at a nominal bus voltage of 12 kV DC. The MVDC architecture is used for its significant advantages over traditional AC distribution in terms of power density, fault-current limitation, ease of integrating diverse power sources and loads, and inherent compatibility with directed energy weapons and other high power, pulsed load systems. The distribution system is organized into electrical zones corresponding to the ship's damage control zones. Each zone contains a local power-conversion and distribution node that draws power from the main MVDC bus and converts it to the voltages and frequencies required by local loads, 440 V AC at 60 Hz for legacy equipment and motors, 115 V AC at 400 Hz for avionics and sensitive electronics, and 24/48 V DC for control and communications systems. The zone distribution nodes incorporate solid-state power converters with automatic fault isolation, load shedding, and power quality management functions. The main MVDC bus is configured as a ring with port and starboard runs connected at the forward and aft ends, providing two independent power paths to every zone distribution node. Solid-state bus-tie switches at each zone boundary enable rapid automatic reconfiguration of the bus in response to damage, fault conditions, or load-management requirements. The bus can sustain the loss of any single segment and continue to deliver power to all zones through the remaining intact path and can sustain the loss of any two non adjacent segments while maintaining power to the remaining zones. Four lithium-ion battery energy storage modules (BESMs) are distributed throughout the ship, two per electrical bus. Each module has a rated capacity of approximately 1.5 MWh and a peak discharge rate of 2.0 MW providing a total installed energy storage capacity of 6.0 MWh. The battery modules absorb transient load fluctuations and peak demands that would otherwise require additional generator sets to be run at low load, enabling the generators to operate at their most fuel-efficient loading. During combat operations they provide pulse power for directed energy weapon systems and serve as an uninterruptible power supply for critical combat system loads during generator load transfers or brief power interruptions. The battery modules employ a lithium iron phosphate (LiFePO4) cell chemistry used for its superior thermal stability and safety characteristics in a naval environment. Each module is housed in a dedicated battery room with independent ventilation, thermal management, fire suppression, and gas detection systems. The battery management system continuously monitors cell voltage, temperature, and state of charge, and is integrated with the ship platform management system and the MVDC distribution controller to enable automated energy management across all four modules.


Sensors & Processing Systems:
FMG 300/400 Multi-Function Radar (MFR) The SDI FMG 300/400 dual band radar system includes the ships FMG 300 X band Multi-Function Radar (MFR) and FMG 400 C band Volume-Search Radar (VSR). Each radar system consist of four phased-array antennas and associated receiver/exciter (REX) cabinets above deck in the superstructure and a signal and data processor (SDP) system mounted below-decks inside the hull. Both arrays share a central controller and and a common array power system (CAPS) with power conversion units (PCUs) and power distribution units (PDUs) for each radar antenna. Both arrays are cooled using a closed loop, phase change based common array cooling system (CACS). The X band radar system features a larger operating bandwidth and better low-altitude performance and provides surface search, radar navigation, gun-fire targeting and splash spotting, periscope detection, mine detection, precision target tracking and discrimination, limited volume-search, high-bandwidth missile uplink, and terminal illumination of targets while the C band radar provides long range volume search and long-range target tracking capability. Both the The X band and C band radars can provide simultaneous sector search, environmental mapping, counter-fire/counter-battery tracking, missile tracking, electronic warfare, clutter detection, and in-flight missile guidance and communication. Each X band FMG 300 aperture has a 4-meter square antenna with 10,560 transmit and receive (T/R) modules which use gallium nitride complementary metal-oxide semiconductors (CMOS) on a diamond substrate. The C band FMG 400 antennas are significantly larger at 9 square meters and each use 17,680 full-duplex radio integrated circuit transmit and receive (T/R) modules. Each radar antenna features +/- 60° azimuth and +/- 60° degree beam-steering capability giving the system combined 360° azimuth and -2° to + 70°elevation coverage around the warship. Both radar systems employ wide-band digital receiver/exciter (DREX) units and feature digital beam-forming (DBF) capability, space-time adaptive processing (STAP), and multiple-input multiple-output (MIMO) waveform generation techniques. ECCM capabilities of the dual band radar system include frequency-modulated continuous-wave (FMCW) operating modes, ultra-low sidelobes, high processing gain, pulse-to-pulse frequency agility and ultra wide-band frequency hopping, staggered pulse repetition frequency (PRF) switching, randomized burst transmissions, and automatic jammer detection and tracking. The system has am instrumented range of 500 kilometers in air search modes and 80 kilometers in surface search modes and is capable of tracking up to 1,500 simultaneous air and surface targets.

The EOS 400 Staring Infrared Search & Track System:The SDI EOS 400 Staring Infrared Search & Track System is a distributed multi-aperture sensor system which consists of four identical dual field-of-view, electronically stabilized mercury cadmium telluride (HgCdTe) starring focal plane array (FPA) imaging infrared (IIR) sensor units placed in a mast atop the ship's superstructure which provides combined 360°azimuth and -20° to +75° elevation situational awareness infrared search and track (SAIRST) capability against surface vessel, cruise missile, ballistic missile, and aircraft targets to supplement the active search and track capability of the ship's dual band radar system. The 4096 × 4096 pixel (16 MPA) HgCdTe sensor used by each sensor head operates in the MWIR (3–5 µm) band and features a 95 x 95 degree field of view. The image processing features of the EOS 400 system include automatic target recognition (ATR) using an on-board threat library, passive ranging algorithms, multi-target adaptive tracking, and clutter rejection techniques. The video feed from the sensor units can be stitched together and displayed on operator consoles in the ship's bridge and CIC to act as a navigational aid and to provide close in situational awareness for the ship's crew.

FLG 300 Radar & Electro-Optical Fire Control System: For short range surface target tracking and gunfire control the ship is equipped with an SDI FLG 300 combined radar and electro-optical fire control director mounted forward atop the superstructure. The FLG 300 contains both a Ku-band (15.5 - 17.5 GHz) solid state radar and an electro-optical suite containing a thermal imager, television camera, and laser rangefinder which is intended to track both surface targets and subsonic and supersonic sea-skimming missiles in close proximity to the vessel and provides sector search capability, missile launch detection and tracking, and own ship gun fire projectile tracking and splash point detection. The Ku-band monopulse radar employs a solid-state Cassegrain antenna connected to a digital receiver and signal processor and transmits with a peak power of 1.5 kW and has a maximum instrumented range of 36 kilometers. The radar is designed with a high level of ECCM features including extremely low sidelobes, high instantaneous bandwidth, and high frequency agility. The electro-optical suite consists of a 1280 x 1024 pixel Midwave IR (3–5 µm) thermal imager with 0.92° to 30.0°horizontal field-of-view and 30x continous optical zoom, 1920 x 1080 pixel CCD daylight television camera with 64x continuous optical zoom, and an Nd:YAG OPO-shifted 1.54 μm eye-safe laser rangefinder with 50m to 40 km range and <1 meter accuracy. The electro-optical system features automatic tracking of up to four simultaneous targets, automatic sector surveillance, simultaneous TV and IR tracking and sensor fusion, recording capability, and integral GPS interferometer system (GPSIS) for far target location (FTL) capability using the system's laser rangefinder to provide 10-digit grid geo-location of surface targets accurate to within 60 meters at ranges up to 40 kilometers. both radar and electro-optical systems are enclosed in a low-RCS triaxially stabilized mounting capable of elevating from -20 to +120° at a rate of 160 °/s and training a full 360° at a rate of 140 °/s.

SDI Sea Lance Undersea Combat System: The SDI Sea Lance Undersea Combat System is the primary undersea combat system fitted to all SDI surface combatants and is designed to detect, locate, track, and engage submersible targets. The Sea Lance system transmits and receives acoustic signals to provide target classification, time motion analysis, and control of anti-submarine and anti-torpedo weapon settings. The Sea Lance system provides multi-sensor track correlation, target track management control, and forwards data to the ship’s command and decision system. The Sea Lance system comprises the RMS 800 hull-mounted mid-frequency sonar; the RMS 810 hull-mounted high-frequency sonar; and the VTS 830 Variable depth sonar. The system provides surface warships with a seamlessly integrated undersea/anti-submarine warfare detection, localization, classification and targeting capability. The system presents an integrated picture of the acoustic tactical situation by receiving, combining and processing active and passive sonar sensor data from the systems twin hull arrays, towed array, and sonobuoys dropped by the ship's ASW helicopter aircraft.

RMS 800/810 Dual-Frequency Hull Array: The SDI Underwater Systems RMS 800/810 dual-frequency hull array assembly is mounted in the ship's bulbous bow and contains both a medium frequency active/passive sonar for submarine detection and a high-frequency mine avoidance sonar. The RMS 800 and RMS 810 sonars have separate transmit and receive arrays but share a common power supply unit and common transmission/reception cabinets, sonar processing unit, and operator consoles. The mid-frequency RMS 800 sonar is a long-range echo ranging sonar with an active frequency range of 6.0 to 9.0 kHz with hyperbolic frequency modulated (FM) and continuous wave (CW) pulse modes with pulse lengths of 60 ms to 4 s. Passive frequency range of the RMS 800 is 1.0 to 9.0 kHz and supports both LOFAR (Low-Frequency Analysis and Recording) and DEMON (Demodulation of Envelope Modulation On Noise) signal processing capability. The RMS 800 sonar features complete 360° detection performance and supports surface duct, bottom bounce, and convergence zone propagation with a maximum detection range out to the first convergence zone of 30-35 nm (55-65 km). The RMS 810 high frequency array is mounted conformally with the RMS -800 mid-frequency sonar and provides detection of moored mines, underwater obstacles, torpedoes, divers, and small underwater vehicles ahead of the ship. The RMS 810 features an active array with a frequency range of 70 to 100 kHz with hyperbolic frequency modulated (FM), linear frequency moduled (LFM), and continuous wave (CW) operating modes and can scan +/- 90° off the ship’s centerline with a maximum detection range of 2.6 kilometers. Both sonars employ a space-time adaptive processing (STAP) algorithm designed to enable adaptive beamforming capability to enable the array to create a virtual 3-dimensional image of sonar contacts in order to accurately separate targets from decoys and from clutter present in littoral waters while also minimizing sonar sidelobes and enabling adaptive angle estimation to more accurately determine target depth, bearing and speed.

VTS 830 Variable depth sonar: The SDI Underwater Systems VTS 830 is an active/passive low-frequency variable-depth sonar designed to detect submarines in both deep blue ocean and shallow littoral environments. The complete VTS 830 system consists of hydrodynamic towed body with active transmitter, passive receive array, towed array handling system with twin winches to deploy and tow the tow body and receive array, shipboard signal transmitter and receiver, and operator control system with four multifunction consoles. The VTS 830 supports low frequency active detection (0.9 to 2.1 kHz) and ultra-high, medium, and low-frequency (<0.1 to 100 kHz) passive detection and environmental monitoring. The sonar employs an omnidirectional transmitter with continuous wave (CW) and low-powered/hyperbolic frequency modulated (LPFM/HFM) pulse modes and multiple receivers including a very low frequency active line array receiver, medium frequency (MF) directional array, and four spherical ultra-high frequency (UHF) hydrophone arrays. The towed body is designed to be towed at depths up to 250 meters with a designed tow speed of 18 knots and a maximum tow speed of 30 knots. The variable-depth sonar can be used in up to sea state 6 and is designed to detect undersea targets out to the second sonar convergence zone (~130 km).


Electronic Warfare & Countermeasures:
FMS 1800 Advanced Integrated Electronic Warfare System (AIEWS): The primary electromagnetic countermeasure system ship is the FMS 1800 Advanced Integrated Electronic Warfare System (AIEWS),a comprehensive offensive and defensive electronic warfare (EW), electronic support measures (ESM), and electronic intelligence (ELINT) suite which combines passive radar warning receivers and phased array jammers for long range, over-the-horizon detection, identification, and targeting of threat emitters as well as automatic employment on-board RF countermeasures and support of passive over-the-horizon targeting capability for the ship's weapon systems. The passive radar warning system of the FMS 1800 consists of multiple single-quadrant, high-gain linear interferometer arrays smoothly blended into the superstructure of the vessel connected to a set of digital receivers and pulse processors inside the ship's superstructure which provide for 360° spherical broadband, all aspect detection, identification, and direction-finding of radar emissions with the capability for precise emitter location and threat identification capability against low probability of intercept waveforms and with additional over-the-horizon direction finding capability of MF, HF, VHF, and UHF band signals. The offensive electronic warfare capability of FMS 1800 system includes multiple low, mid, and high band electronically scanned gallium nitride (GaN) based Digital Radio Frequency Memory (DRFM) jammers blended into the superstructure which provide for the jamming of hostile RF sensors. The FMS 1800 is a fully cognitive and adaptive system; by using radar emission data collected from the FMS 1800s radar warning the DRFM jammers can automatically adapt in real time to unknown waveform characteristics, dynamically synthesize countermeasures, and jam the waveform accordingly.

LWG 310 Naval Laser Warning System: For detecting laser sources including laser range finders, laser target designators, and laser beamriding missiles the ship's electronic warfare system is augmented by an SDI LWG 310 Naval Laser Warning System. The vessel's LWG 310 installation consists of a central controller connected eight sensor heads, four on each side of the superstructure, providing combined 360° coverage around the vessel. Each individual sensor head features 110° azimuth and +/- , 70° elevation coverage and is capable of detecting up to eight simultaneous laser range finders laser target designator emissions in the 0.5 μm - 1.65 μm range and laser beamriders in the 0.8 μm - 1.1 μm range.

SDI Sea Guardian Surface Ship Torpedo Countermeasures System: The ship is fitted with the SDI Sea Guardian Surface Ship Torpedo Countermeasure System which combines various soft-kill and hard-kill torpedo countermeasure systems. The Sea Guardian system consists of a towed array sonar designed specifically for torpedo detection, a towed acoustic decoy with a a single-drum winch, an interface to the ship's trainable decoy launchers, and a processing cabinet with two display consoles, and and four 4-round anti-torpedo torpedo launchers on either side of the ship. The towed array sonar used by the system is a combined active and passive array sonar optimized to detect the high frequency sound signature of torpedo screws and active sonar homing heads. The towed array is supported by two vibration isolated modules (VIMs) located on either side of the sonar with the array being connected on one end to the ship using a fiber-optic tow cable and connected on the other end to the towed decoy with an array tow cable. The towed decoy array is designed to emit simulated ship noise such as propulsor and engine noise to lure a passive-sonar homing torpedo to the decoy instead of the ship. The towed decoy can also receive sonar pings from the active homing head of a torpedo and amplifies and returns the "pings" to the torpedo, presenting a larger false target to the torpedo. The hardkill component of the Sea Guardian system comprises a series of four box launchers on either side of the vessel which each contain six SDI S2s Barracuda anti-torpedo torpedoes in individual all-up rounds (AUR) which contain the Barracuda torpedo and a self-contained compressed gas launch system. The Barracuda torpedo is 21 cm in diameter, 2.0 meters in length, weighs 110 kilograms, and contains a 20 kilogram aluminized PBX explosive warhead. The guidance and fusing system of the Barracuda is designed to explode it in front of the oncoming torpedo and create a pressure wave which crushes the nose section of the oncoming torpedo. The Barracuda has a maximum firing range of 10 kilometers and is propelled by an advanced stored chemical energy propulsion system (ADSCEPS) which can propel the Barracuda at speeds up to 60 knots at depths up to 1,000 meters. Although designed as an anti-torpedo the Barracuda can also be used to engage midget submarines, naval mines, and unmanned or autonomous underwater vehicles.

ZTKG 130 Trainable Decoy Launching System (TDLS): The ZTKG 130 Trainable Decoy Launching System (TDLS) is an aimable decoy launcher which can launch a variety of decoys designed to decoy away anti-ship missile and torpedo threats. The ZTKG 130 system consists of multiple 12-round trainable countermeasures launchers controlled by a central command console inside the ship. Each 12-round launcher employs a rotating platform with 12 separate 130mm barrels which can each be individually trained in elevation. The ship is fitted with four decoy launching systems, two on either side of the ship used for acoustic torpedo decoys (24 total) and another two launcher on each side used for chaff/flare rounds and missile seduction decoys (24 total).

AM5 dual chaff/IR seduction decoy: The primary chaff seduction round employed by the TDLS is the AM5 dual chaff/IR seduction decoy which is capable of defeating dual-seeker missiles equipped with both IR/EO and radar seekers. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.

AM79 Buzzard active missile decoy: For decoying away radar-guided anti-ship missiles the TDLS can deploy the AM79 Buzzard active missile decoy, an expendable electronic-warfare rotary-wing drone which is designed to seduce RF guided anti-ship missiles by simulating the radar return of a large surface vessel. The buzzard features a cylindrical shaped fuselage 130 mm in diameter and 0.9 meters tall with both top and bottom mounted 1.8 meter diameter three-bladed counter-rotating coaxial rotors powered by two brushless DC motors. The rotors unfold from the body of the decoy after launch and fly the decoy into a pre-programmed flight path away from the ship where the decoy then hovers in place while emitting electronic warfare signals uses its fuselage mounted Digital Radio Frequency Memory (DRFM) jammers which are designed to seduce oncoming anti-ship missiles into targeting the decoy and not the host vessel. The decoy is powered by a thermal battery mounted in the center of the fuselage which gives the decoy approximately 60 minutes of flight endurance after launch.

AM7 Lamprey acoustic decoy: The TDLS can also launch the AM7 Lamprey, a 130mm diameter, expendable acoustic decoy designed to counter torpedo threats. After a rocket-powered launch into ocean the Lamprey is programmed to hover vertically using a pressure-controlled motor driving a small, shrouded propeller in the tail of the decoy. The Lamprey is designed to hover at a pre-selected depth from 10-300 meters where it listens for torpedo transmissions. Active acoustic transmissions are detected and analyzed resulting in decoy selectivity and generation of the appropriate deception signal for transmission including target signature and target self noise. If no torpedo transmissions are detected the decoy is programmed to emit warship propulsor and engine noise to lure in passive homing torpedoes. Power for the motor and electronics of the Lamprey is provided by a thermal battery. The Lamprey is programmed to hover and emit noise until the battery dies where the decoy then sinks and all software onboard is erased.


Signature Reduction:
Like other SDI Marine Systems surface combatant warships the Dragon class features extensive radar and infrared signature reduction to reduce the ship's detectability and vulnerability to anti-ship missile threats. The hull and superstructure feature a faceted shape with an enclosed mast and sensors suite designed to eliminate corner reflectors and reduce the ship's detectability by radar systems. The forward and side superstructure of the vessel is fitted with SDI's S-RAM, a type of ballistic grade structural radar absorbing material consisting of 2 cm thick panels made from multiple layers of M5 fibers fibers containing a lossy filler backed by a carbon fiber laminate acting as a reflector. The panels are designed to survive extreme weather exposure and ballistic damage and provides an average -20 dB reflectivity across the 2-40 GHz frequency range (L through Ka bands). The rest of the hull and superstructure is painted in a radar absorbing paint coating 1 to 5 millimeters thick consisting of lossy dielectric material embedded in a polymer resin which provides -20 dB reflectivity across the 9 -13 GHz range (X band). The infrared signature from the ship's engines is suppressed using an infrared signature suppression system built into the exhaust uptakes. The system consists of a film cooled stainless steel outer duct surrounding a conductively and film cooled stainless steel centerbody and a film cooled stainless steel diffuser which blocks any line of sight view of the heated metal surfaces and reduces uptake metal temperatures to less than 25°C above ambient using ambient air draw into the uptake through a multi-lobed ejector nozzle at the base of the diffuser. The diffuser also contains multiple rings of atomizing nozzles which inject a a fine mist of seawater into the exhaust stream, cooling the exhaust stream to a plume temperature of under 150°C. Seawater injection is controlled by an on board signature management system which interfaces with the ship's propulsion machinery control system and controls the flow of water as a function of engine power.

The magnetic signature of the vessel is reduced by SDI's High Temperature Superconducting Degaussing System (HTSDS) which is designed to reduce the vessel's magnetic signature. The superconducting system provides an over 95% reduction in the ship's magnetic signature with a total weight 80% less than a conventional copper cable based system singicnalty reducing the vulnerability the ship to magnetic mine threats. The degaussing system components include a control unit, power modules, junction boxes, cryo coolers, accumulation tanks, high temperature degaussing cable assemblies, and cryogenic cold gas lines used to cool the degaussing cable assemblies. The system uses three separate loops of independently controlled degaussing coils arranged in three axes which are designed to counteract the ship's magnetic signature in the vertical, longitudinal and athwartship planes. Each coil loop is connected to an independent power module connected to the ship's zonal DC power distribution system which energizes the coil with up to 3,000 Amps of current at voltages of up to 138 kV. The cable assemblies consists of a hollow bismuth strontium calcium copper oxide (BSCCO) high temperature superconducting cable wrapped around a hollow support tube and supported by a flexible cyrostat consisting of a layer of inner corrugated stainless steel tubing, a layer of multi layer insulation (MLI), a polymer support layer, a vacuum space, an outer layer of corrugated stainless steel tubing, and an outer cable sheathing. The cooling loop for each cable includes a cryogenic refrigerator, a seawater heat exchanger, and a circulation pump which pumps gaseous helium through the cryostat and hollow support tube to maintains cable temperature at 55° K. The entire HTSDS is controlled from a central degaussing control unit (DCU) which receives magnetic field data either from both a shipboard triaxial magnetic probe system and from a magnetic geophysical model which takes data from the ship's navigation system and automatically calculates the required current for each degaussing coil to cancel out the ship's magnetic signature.


Passive Protection & Damage Control:
The [i]Dragon/i] class features passive armor protection in the form of several hundred tonnes of composite armor panels made from M5 ballistic fiber laminated into cured thermoplastic panels which provide ballistic impact and spall protection to the superstructure and vital areas of the ship. The ship's blast hardened bulkheads are designed to deform plastically and maintain watertight integrity in the event of an explosion from a bomb or missile warhead inside the ship and feature double-spaced plate construction with an internal fragment resistant membrane designed to stop fragments from penetrating further into the ship. The automatic opening/closing watertight doors in the bulkheads likewise feature a blast hardened membranes structure design with approximately 10 times the blast force resistance of a conventional watertight door.

Damage control is assisted by an SDI Marine Systems developed Automated Ship Control System (ASCS). The ASCS is controlled by a centralized computer which amongst other functions provides real-time damage information to the crew through a graphical display located in the ship's damage control center. Additionally both the ship's bridge and CIC also also fitted with displays connected to the ASCS. The ACSC is designed to run automatically where after the ASCS detects damage to a compartment it will immediately isolate it and activate appropriate damage control measures. Alternatively the ASCS can be set to manual mode where the operator will have to specify the damage control measures after the system detects ship damage. The ASCS also controls and monitors the ship's engines and machinery and will alert engineers on watch duty through their assigned tablet computer when an engineering issue or machinery failure is detected and requires attention. This remove the need for time based maintenance, the system will simply alert the crew when a component or system requires maintenance. Each compartment and each piece of machinery on the ship are monitored using SDI's Two Wire Automatic Remote Sensing Evaluation System (TWARSES) which includes both visible CCD and infrared cameras located in each ship compartment. After damage is detected in a compartment the ASCS can respond in a variety of ways including isolating the damaged compartment by closing the electrically actuated watertight doors around the compartment. If the IR camera detects a fire the system will activate the compartment's overhead sprinklers and can also pump the compartment with aqueous film-forming foam , high velocity fog, and/or carbon dioxide agents if necessary. After the fire is extinguished water and firefighter agents are removed using a bilge draining pump installed in each compartment. The ASCS will also reroute ventilation, electrical power, and water around the damaged area and activate additional pumps, generators and other devices if necessary. If the compartment has been breached and is in danger of flooding the system will flood the compartment with foam which rapidly solidifies and restores reserve buoyancy. This system however is only used as an absolute last resort as it renders the compartment unusable. The ASCS also controls the ship's CBRN protection system by passing air from the ventilation intakes through containment filters before it enters the ship. Air in the ship is maintained at 5.0 millibars above local atmospheric pressure to provide a positive pressure and prevent contaminated air from entering into the ship through a breach in the hull.


Armament:
20.3 cm SK L/60 Naval Gun: The 20.3 cm SK L/60 is a fully automated and stabilized, single barrel naval artillery gun system designed for use against surface targets and as a long-range shore bombardment weapon. The gun system consists of three sub-assemblies, the SK L/60 gun assembly with its enclosed triaxial stabilized gun mount, automated ammunition supply system, and fire control support system and crew display with control consoles. The SK L/60 gun features a 60 caliber length monobloc barrel and features a semi-automatic vertically sliding breechblock which is automatically opened under the force of recoil. The breech is sealed with a mild steel case containing the propellant charge. The gun can fire either standard spin stabilized 110 kilogram 20.3 cm base-bleed (BB) projectiles including high explosive and cluster-HEAT with a muzzle velocity of 995 m/s out to a range of 60 kilometers or can fire a 180 kilogram rocket assisted, fin stabilized IRGM (infrared guided munition) projectile at a muzzle velocity of 825 m/s out to a range of 190 kilometers. The gun can be loaded any any angle of elevation and has a maximum sustained rate of fire of 12 rounds per minute. The gun is fed from an automated ammunition supply system consisting of a projectile and propellant charge hoist, automatic fuze setter, and a service drum located directly under the gun house which contains 75 projectiles and 75 propellant charges. An additional 400 rounds and 400 propellant charges are located in a two story magazine below the ready service drum including 80 IRGM projectiles. The mount is capable of training to +/- 165 degrees on either side of the ships centerline at a rate of 30 degrees per second and elevating from -10 to +70 degrees at a rate of 20 degrees per second. A shipboard fire control support system is used for control of the gun which plans fire support missions, determines firing solutions and shell trajectories, selects ammunition, and determines the best ship course for executing fire support missions.

Medium-Caliber Gun System (MCGS): For close in defense against small boats the ship is fitted with two SDI medium-caliber gun system (MCGS) turrets placed amidships on either side of the superstructure. Each MCGS mount contains an SDI 4.0 cm SK L/70 Flak cannon and an electro-optical targeting sensor with a forward looking infrared sensor, low light television camera, and a laser rangefinder. The 4.0 cm SK L/70 is an air-cooled, recoil operated automatic cannon which fires 40×365mmR ammunition at a rate of up to 300 rounds per minute. The 4.0 cm SK L/70 gun is housed in a triaxial stabilized low-RCS gunhouse constructed from fiberglass and is capable of traversing a full 360° at a speed of 130°/sec and is capable of elevating from -20° to +80° at 75°/sec. The gun includes an on-mount muzzle velocity radar and is designed to fire 0.975 kg programmable air-burst munition (PABM) projectiles at a muzzle velocity of 1,012 m/s. The 40mm PABM round contains 0.12 kg of HMX based polymer bonded explosive (PBX) surrounded by over 3,000 tungsten balls 3mm in diameter and features a multi-mode programmable fuze with six operating modes; proximity, gated proximity, gated proximity with impact priority, timed airburst, impact, and impact plus delay modes. The gun is fitted with a 72 round magazine which is automatically replenished by an additional 72 round magazine located inside the gun house. Total weight of the MGCS is 2,300 kg empty and 2,650 kg with a full load of ammunition.

S70 Vertical Launch System: The ship is fitted with a total of 64 S70 vertical launch cells divided into eight 8-cell modules, four modules (32 cells) located on the bow and another four modules in the ship's superstructure. The S70 is a cold-launch system which uses missiles encased in individual concentric launch cells as modular all-up rounds (AURs) each containing the missile, concentric launch tube, launch tube electronics, and missile ejection system. The S70 8-cell central modules contain 8 launch cells in a 4x2 arrangement with the launch cells inclined at a 10 degree angle towards the ships centerline to prevent missiles with malfunctioning rocket motors from crashing back onto the deck after launch. Each launch cell is capable of accommodating either a single launch tube which can contains missiles with a maximum length of 7.0 meters, diameter of 0.6 meters, and a weight of 2,500 kg. The missiles are ejected from each launch tube using a steam generator system which uses a small solid-propellant gas generator which exhausts through cooling water into the base of each launch cell, creating expanding high pressure steam which then forces the missile out of the launch tube. Safety and passive protection features of each VLS module include concentric anti-fragmentation shields placed around each launch cell tube to prevent in-cell missile fratricide and a deluge system which can flood each 4 or 8 cell module in the event of a missile catching fire in the launch tube. Launch tubes are connected to the launch cells through shock collar that is designed to absorb acceleration loads from an underwater detonation near the ship. The individual missile cells are connected to the ship's weapon control system via redundant port, central, and starboard fiber-optic Ethernet lines which transmits launch commands to the individual missiles and allows for missile status information before launch to be sent back to the weapon control system.

40 cm Torpedo Launch System : For close-in anti-submarine the ship is equipped with two twin 40 cm Torpedo Launch Systems, one on each side of the hull for launching SDI F3s Viperfish anti-submarine torpedoes. The torpedo launchers are located in recesses below the flight deck near the aft of the ship which are covered by armored doors when not in use. Each Torpedo Launch System consists of twin fixed shock mounted 40 centimeter torpedo launch tubes, an air charging system, a 12 cell torpedo magazine, and a launcher control station which is connected to the ships' Sea Lance Undersea Combat System. Each F3S Viperfish torpedo is 40 cm diameter, 2.85 meters long lightweight anti-submarine torpedo powered by advanced stored chemical energy propulsion system (ADSCEPS) driven pumpjet propulsor. The torpedo has a maximum speed of 60 knots with a range of 15 km at 60 knots or 25 km at a lower speed of 40 knots. The F3S torpedo is equipped with a fully digital electronically steered 2D phased array active/passive sonar seeker combined with fiber-optic wire guidance. The torpedo is equipped with a 60 kilogram shaped charge warhead designed to penetrate the hulls of large double-hulled submarines.
Last edited by The Technocratic Syndicalists on Wed Sep 09, 2026 11:52 am, edited 52 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Thu Jun 01, 2017 7:38 pm

Image

Fervent class

Basic Information:
  • Type: Dock Landing Ship
  • Displacement: 29,500 tonnes (full load)
  • Complement: 300 crew + 800 marines
  • Length: 215 m
  • Beam: 32.5 m
  • Draft: 7.8 m
Propulsion:
  • 4x AMG 20V 32/44 M708 diesel engines, 12.0 MW each
  • 4x AMG 20V 17/21 M95 diesel generators, 3.25 MWe each
  • 2x shafts, 5 bladed controllable pitch propellers
  • 2x bow thrusters, 1.0 MW each

Performance:
  • Top Speed: 25 knots
  • Range: 19,000 km at 20 knots
Sensors and Processing Systems:
  • SDI FMG 300 X band Multi-Function Radar (MFR)
  • SDI FMG 400 C band Volume Search Radar (VSR)
  • SDI Integrated Bridge and Navigation System
  • SDI EOS 400 Staring Infrared Search & Track System
  • SDI FLG 200 Radar & Electro-Optical Fire Control Director

Electronic Warfare and Countermeasures:
  • SDI FMS 1800 Electronic Warfare System
  • SDI LWG 310 Naval Laser Warning System
  • SDI ZTKG 130 Trainable Decoy Launching System (TDLS)
  • SDI Sea Guardian Surface Ship Torpedo Countermeasure System

Armament:Boats & landing craft carried:
Aircraft Carried:


Overview:
The Fervent is a class of dock landing ship (LPD) designed by SDI Marine Systems. Designed to transport and land marines and their vehicles and equipment using embarked landing craft and amphibious assault vehicles the Fervent class is intended primarily for amphibious assault, special operations, and expeditionary warfare missions. The Fervent class includes relatively heavy armament for an an amphibious ship in the form of a 21 cm deck gun and 32 cell VLS and can provide offensive anti-surface and strike capability, defend against itself against air and surface threats, and provide naval gun fire support to forces ashore.


Design & Construction:
The Fervent class vessels have a length of 215 meters, maximum beam of 32.5 meters, and a draft of 7.0 meters at full load. The hull is constructed primarily from welded St 92 (900 MPa yield strength) high-strength structural shipbuilding steel and is divided longitudinally into 15 watertight compartments through shock resistant, blast hardened bulkheads intended to maintain structural integrity in the event of a large internal explosion inside the vessel. The ship features an advanced double hull construction with an inner hull and outer hull connected by web girders to form a highly compartmentalized cellular structure similar to a corrugated box with the void spaces along the bottom of the double hull used to store diesel and jet fuel while the side voids are left empty and dedicated to counterflooding in order to allow the ship to recover from significant lists in the event of severe flooding. For amphibious operations the rear of the ship includes a 90 by 15 meter well deck which is designed to accommodate two LCU 40 class landing craft. The ship also has four davits on each side of the flight deck for launching LCA 16 class landing craft. Vehicle storage capability includes 2,300 square meters of roll-on/roll-off (Ro-Ro) space spread across three vehicle decks with an additional 730 square meters of ammunition storage in two magazines and 1,000 square meters of additional cargo storage capacity. Fuel storage capability includes 7,700 cubic meters of diesel fuel oil and 1,000 cubic meters of aviation fuel storage which is mainly stored in the voids inside the ship's double bottom hull. The ship's hangar is designed to house two TH 90 transport helicopters with a flight deck capable of landing two TH 90 helicopters.


Propulsion
AMG 20V 32/44 M708
  • Type: Marine diesel engine
  • Length: 9.86 m
  • Width: 3.10 m
  • Height: 4.26 m
  • Dry Weight: 104,000 kg
  • Type: 4 stroke
  • Arrangement: 20V
  • Cylinder bore: 320 mm
  • Piston stroke: 440 mm
  • Displacement, cylinder: 35.4 l
  • Displacement, total: 708 l
  • Speed: 750 rpm
  • Aspiration: sequential turbocharging
  • Rotation: Counterclockwise flywheel
  • Specific fuel consumption: 170 g/kW-hr
  • Output: 12,000 kW
  • Fuel system: Modular common rail (MCRS)
The Fervent class features a Combined Diesel-Electric And Diesel (CODELAD) arrangement with four diesel engines and two electric motors driving two shafts with 5-bladed controllable pitch propellers through a pair of double input-single output single reversing reduction gears units. The AMG 20V 32/44 engine is a 20 cylinder, 4-stroke medium speed turbocharged marine diesel engine with a 32 cm bore, a 44 cm stroke, ad a total displacement of 708 liters. The engine has a dry mass of 104 tonnes and provides 12,000 kW of power at its maximum rated speed of 750 RPM. The 20V 32/44 is designed for minimal specific fuel consumption and NOx emissions and features an electronic common rail injection system, a high efficiency constant pressure A axial-flow turbocharger, variable injection timing (VIT) system, and water cooling system with separate high and low temperature cooling water loops. The four 20V 32/44 engines are connected with hydraulically actuated clutches in pairs to two single reversing reduction gears units which drive 5-bladed controllable pitch propeller with hydraulically actuated blade pitch. Each gear reduction unit also includes secondary power take-off (PTO) and combined power take-off/ power take-in (PTO/PTI) connected to a variable speed permanent magnet electric motor/generator connected which in PTO mode acts as a shaft alternator and in PTI mode acts as an electric motor for amphibious operations at speeds below 10 knots. Each reduction gear units drives a propeller shaft with a 5 bladed controllable pitch propeller with hydraulically actuated blade pitch. The twin five bladed controllable pitch propellers (CPP) are each approximately 5.0 m in diameter and constructed from nickel aluminium bronze (NAB). The CPPs are designed for low cavitation inception speeds and reduced radiated noise with skewed and raked blade profile. Controllable pitch allows the shaft speed to remain constant across a wide range of ship speeds, enabling the propulsion diesels to operate at their most fuel efficient rpm and reducing the complexity of the reduction gearbox. Shaft lines are supported by oil lubricated journal bearings within the hull and water lubricated polymer stern tube bearings.

Electrical power is provided by four AMG 20V 17/21 M95 high speed diesel generator sets each providing 3,250 kWe of 50 Hz AC power which is fed into a battery buffered DC grid. The AMG 20V 17/21 M95 is a 4-stroke V20 fuel-injected turbocharged marine diesel engine with a 17 centimeter bore, 21 centimeter stroke, and 96.4 liter displacement and has a maximum mechanical power output of 3,500 kWm at 1,500 rpm. The engine employs sequential turbocharging with twin water-cooled turbochargers with an engine coolant temperature-controlled intercooler. The engine is used to drive a brushless three-phase four-pole synchronous AC generator which outputs a maximum of 3,250 KWe of 50 Hz AC power which provides electrical power to the ships zonal DC electrical system. The AC power from the four generators is converted to to 6000 VDC with power conversion modules (PCMs) attached to each generator which then supply both port and starboard DC buses which in turn supply power to 15 independent zones (one for each watertight compartment) which each include one DC/DC PCM per bus (two each per zone) which converts the 6000 VDC to 750-800 VDC or 650 VDC to supply DC loads in each zone. Both DC/DC PCMs in each zone also supply one or more DC/AC PCMs with 750-800 VDC which then converts the 750-800 VDC to 450 VAC at 60 Hz for AC loads. All electrical loads in each zone are connected to both port and starboard bus ensuring continued operation if either port or starboard bus becomes inoperable. Under normal cruising conditions two generator sets supply the full hotel and combat system load with 100% redundancy. A third generator set is brought online for combat or well deck ballasting operations and the fourth serves as a maintenance reserve. Energy buffering and backup emergency power is provided by twin lithium iron phosphate (LiFePO₄ / LFP) battery modules, one connected to each electrical bus. Each battery module provides approximately 4,000 kWh of usable energy storage at a peak discharge rate of 4,500 kW. The battery modules can instantaneously absorb or supply load transients (allowing the number of running generator sets to be reduced) ,lower fuel consumption, engine operating hours, and acoustic signature during routine operations, provide ride through power during generator set changeovers and automatic bus transfers ensuring zero power interruption to critical combat and navigation systems, absorb peak electrical loads such as well deck gate operation, crane lifts, or combat system pulse loads that would otherwise require an additional generator set online, smoothing the load profile and reducing fuel consumption, and provides emergency power to sustain critical systems including steering, fire main, communications, damage control while other power sources are restored. Each battery module is housed in a dedicated, ventilated compartment with independent cooling, gas detection, fire suppression, and thermal runaway containment systems.


Sensors & Processing Systems:
FMG 300/400 Multi-Function Radar (MFR) The SDI FMG 300/400 dual band radar system includes the ships FMG 300 X band Multi-Function Radar (MFR) and FMG 400 C band Volume-Search Radar (VSR). Each radar system consist of four phased-array antennas and associated receiver/exciter (REX) cabinets above deck in the superstructure and a signal and data processor (SDP) system mounted below-decks inside the hull. Both arrays share a central controller and and a common array power system (CAPS) with power conversion units (PCUs) and power distribution units (PDUs) for each radar antenna. Both arrays are cooled using a closed loop, phase change based common array cooling system (CACS). The X band radar system features a larger operating bandwidth and better low-altitude performance and provides surface search, radar navigation, gun-fire targeting and splash spotting, periscope detection, mine detection, precision target tracking and discrimination, limited volume-search, high-bandwidth missile uplink, and terminal illumination of targets while the C band radar provides long range volume search and long-range target tracking capability. Both the The X band and C band radars can provide simultaneous sector search, environmental mapping, counter-fire/counter-battery tracking, missile tracking, electronic warfare, clutter detection, and in-flight missile guidance and communication. Each X band FMG 300 aperture has a 4-meter square antenna with 10,560 transmit and receive (T/R) modules which use gallium nitride complementary metal-oxide semiconductors (CMOS) on a diamond substrate. The C band FMG 400 antennas are significantly larger at 9 square meters and each use 17,680 full-duplex radio integrated circuit transmit and receive (T/R) modules. Each radar antenna features +/- 60° azimuth and +/- 60° degree beam-steering capability giving the system combined 360° azimuth and -2° to + 70°elevation coverage around the warship. Both radar systems employ wide-band digital receiver/exciter (DREX) units and feature digital beam-forming (DBF) capability, space-time adaptive processing (STAP), and multiple-input multiple-output (MIMO) waveform generation techniques. ECCM capabilities of the dual band radar system include frequency-modulated continuous-wave (FMCW) operating modes, ultra-low sidelobes, high processing gain, pulse-to-pulse frequency agility and ultra wide-band frequency hopping, staggered pulse repetition frequency (PRF) switching, randomized burst transmissions, and automatic jammer detection and tracking. The system has am instrumented range of 500 kilometers in air search modes and 80 kilometers in surface search modes and is capable of tracking up to 1,500 simultaneous air and surface targets.

The EOS 400 Staring Infrared Search & Track System:The SDI EOS 400 Staring Infrared Search & Track System is a distributed multi-aperture sensor system which consists of four identical dual field-of-view, electronically stabilized mercury cadmium telluride (HgCdTe) starring focal plane array (FPA) imaging infrared (IIR) sensor units placed in a mast atop the ship's superstructure which provides combined 360°azimuth and -20° to +75° elevation situational awareness infrared search and track (SAIRST) capability against surface vessel, cruise missile, ballistic missile, and aircraft targets to supplement the active search and track capability of the ship's dual band radar system. The 4096 × 4096 pixel (16 MPA) HgCdTe sensor used by each sensor head operates in the MWIR (3–5 µm) band and features a 95 x 95 degree field of view. The image processing features of the EOS 400 system include automatic target recognition (ATR) using an on-board threat library, passive ranging algorithms, multi-target adaptive tracking, and clutter rejection techniques. The video feed from the sensor units can be stitched together and displayed on operator consoles in the ship's bridge and CIC to act as a navigational aid and to provide close in situational awareness for the ship's crew.

FLG 300 Radar & Electro-Optical Fire Control System: For short range surface target tracking and gunfire control the ship is equipped with an SDI FLG 300 combined radar and electro-optical fire control director mounted forward atop the superstructure. The FLG 300 contains both a Ku-band (15.5 - 17.5 GHz) solid state radar and an electro-optical suite containing a thermal imager, television camera, and laser rangefinder which is intended to track both surface targets and subsonic and supersonic sea-skimming missiles in close proximity to the vessel and provides sector search capability, missile launch detection and tracking, and own ship gun fire projectile tracking and splash point detection. The Ku-band monopulse radar employs a solid-state Cassegrain antenna connected to a digital receiver and signal processor and transmits with a peak power of 1.5 kW and has a maximum instrumented range of 36 kilometers. The radar is designed with a high level of ECCM features including extremely low sidelobes, high instantaneous bandwidth, and high frequency agility. The electro-optical suite consists of a 1280 x 1024 pixel Midwave IR (3–5 µm) thermal imager with 0.92° to 30.0°horizontal field-of-view and 30x continuous optical zoom, 1920 x 1080 pixel CCD daylight television camera with 64x continuous optical zoom, and an Nd:YAG OPO-shifted 1.54 μm eye-safe laser rangefinder with 50m to 40 km range and <1 meter accuracy. The electro-optical system features automatic tracking of up to four simultaneous targets, automatic sector surveillance, simultaneous TV and IR tracking and sensor fusion, recording capability, and integral GPS interferometer system (GPSIS) for far target location (FTL) capability using the system's laser rangefinder to provide 10-digit grid geo-location of surface targets accurate to within 60 meters at ranges up to 40 kilometers. both radar and electro-optical systems are enclosed in a low-RCS triaxially stabilized mounting capable of elevating from -20 to +120° at a rate of 160 °/s and training a full 360° at a rate of 140 °/s.


Battle Management & Communications:
SDI Typhoon Combat System: The SDI Typhoon Combat System (TCS) is a comprehensive open-architecture anti-aircraft warfare (AAW) combat management system designed by SDI Missiles & Fire Control Systems which provides fully automated detection, identification, and engagement of air targets. The primary components of the Typhoon Combat System are the Sensor Fusion Processor (SFP), Command and Decision System (C&DS), Typhoon Display System (TDS), Weapons Control System (WCS), and Integrated Ship Computing System (ISCS). The sensor fusion processor or SFP takes tracking data from the ship's radars, IFF system, distributed IRST sensors, and electronic warfare system and correlates them using a contact-to-track data correlation algorithm to provide a single integrated track of each detected target. With the contact-to-track algorithm detected contacts from each sensor (radar, IFF, IR, and ESM) are correlated with existing sensor tracks and merged using a smoothing filter to create a single track file of each correlated target. This allows (for example) the range data from the radar tracks of the dual band radars to be fused with the angle track data from the higher angular resolution IRST sensors, creating a fused 3D track which is more accurate than either the individual radar or IRST sensor tracks. Track data from the sensor fusion processor is fed into the Typhoon Command and Decision System (C&DS) which uses both IFF data and aided and automatic target recognition (Ai/ATR) algorithms to provide identification, threat classification, and weapon assignment of target data input from the sensor fusion processor. Information from the Command and Decision System (C&DS) processor is displayed via the Typhoon Display System (TDS) which uses large multi-function color displays inside the ship's CIC to display target tracks and other situational awareness data to the ship's crew and captain. The TDS consoles also features keyboards for data input which allows doctrinal IF/THEN instructions to be input to the system to the modify its behavior; such as instructing the system that IF any target is detected above a certain speed and altitude in a certain sector THEN it is to be automatically classified as hostile and engaged with a certain missile. The Weapons Control System (WCS) is responsible for launching missiles at targets identified as hostile by the Typhoon Command and Decision System (C&DS). Targets are matched to the ship's missiles by the C&DS which will then send a fire instruction to the weapon control system when the target has entered the engagement zone of the specific missile. The WCS then sends a a firing instruction to the ship's VLS to fire the specific missile and then uses the ship's radars and datalinks to provide midcourse guidance as necessary to guide the missile towards its intended target. The WCS is also responsible for providing Air Intercept Control (AIC) functionality and can be used to guide carrier or land based airborne interceptors towards a hostile target being tracked by the ship. Finally the Integrated Ship Computing System (ISCS) acts as the central processor of the Typhoon combat system and processes radar and and other sensor data and connects all the ships systems including weapons, countermeasures, and communications system together. The ISCS architecture is based on SDI's SPPC10D single-board computer, a ruggedized, shock hardened and conduction cooled computer which employs a 10nm gallium nitride (GaN) on silicon architecture, 48 core (384 thread) superscalar symmetric multiprocessor with a 4.0 GHz clock rate as well as 64 GB of DDR5 DRAM. The SPPC10D computers are each packaged into 16 Electronic Modular Enclosures (EMEs) which each include their own power, shock, vibration, and electromagnetic protection, and water cooling systems. Each EME is a self-contained server and carries 235 cabinets containing the SPPC10D single-board computers. The EMEs which run the ISCS software are interconnected to the rest of the sensors and electrical systems through fiber-optic cables and uses voice-over IP for internal communications between computer systems. The combined computing power of the ship's processors is 27,000 MIPS (million instructions per seconds) at 4.35 GHz with a combined 240 TB of data storage.

An additional ability of the Typhoon Combat System is Distributed Engagement Capability (DEC) which allow target tracking data from multiple sensors across multiple Typhoon equipped platforms in the battle group to be fused together to create a composite track of all air objects within the battle force area and to allow for hunter-killer functionality in the battle group by allowing unit in the battle force to engage a target being tracked by another unit even when the shooter is unable to see or track the target with its own sensors due to either jamming, battle damage, or line-of-sight restrictions. Distributed engagement capability on Typhoon equipped platforms s enabled by a data distribution system (DDS) and a track fusion algorithm (TFA). The data distribution system or DDS consists of four C band planar array antenna assemblies blended into the outer surface of the ship's superstructure which provide extremely high bandwidth line-of-sight communication capability with other sea and air platforms in the battle force. Each DDS antenna array consists of a liquid cooled digital beam forming (DBF) antenna with separate transmit and receive arrays employing gallium nitride (GaN) monolithic microwave integrated circuit (MMIC) transmit/receive (T/R) modules integrated into a common subarray line replacement units (LRUs) and high provides extremely jam resistant and high bandwidth line-of-sight data exchange with other DDS equipped platforms. The track fusion algorithm (TFA) uses the ships ISCP processors to take sensor data received by other units through the data distribution system and fuse it with data from the ships own sensors to create a single composite sensor picture. The main capability of the track fusion algorithm is the ability to network the measurements of radars and other sensors on different platforms tracking the same target and combine them with an intelligent averaging algorithm that creates a single composite track of the target which is more accurate than the track of any individual sensor. When a Typhoon equipped platform establishes a target track with one or more of its sensors a track alert is broadcast across the Typhoon network which then cues the other platforms in the battle force to point their sensors in the direction of the target track. When the other platforms begin tracking the target with their own sensors their sensor measurements are distributed back across the network to every other platform to form the composite track. This capability allows the battle force to maintain track of a target even if any one or even multiple of the battle force units loses the target track due to jamming, battle damage, or environmental effects. When used to fuse radar data from different platforms the track fusion algorithm also enables better radar observation of low observable targets by illuminating them simultaneously with many radars of different wavelengths and scan rates at once, allowing a composite track to be created even if none of the radars in the battle force are able to generate an individual track of the target for more than a few pulses.

SDI FG 710 Shipboard Digital Radio System (SDRS): The SDI FG 710 Shipboard Digital Radio System (SDRS) is a shipboard software defined radio designed by SDI Mission Systems which provides centralized control of all shipboard radio communication systems operating in the 100 MHz to 2 GHz frequency bands. The SDRS can transmit on up to 128 simultaneous channels with programmable waveforms supported by the SDR including 225-400 MHz anti-jam UHF military aircraft radio, low (25-54 MHz), mid (2-76 MHz), and high-band (136-175 MHz) VHF/UHF-FM Land Mobile Radio (LMR), 960-1215 MHz TACAN, 420-450 MHz Enhanced Position Location Reporting System (EPLRS), 108-137 MHz VHF-AM civilian Air Traffic Control, 156 MHz marine VHF-FM radio, 1030 & 1090 MHz IFF, 1350-1850 MHz Digital Wideband Transmission System (DWTS), and others. Encryption options including High Assurance Internet Protocol Encryptor (HAIPE), Advanced Narrowband Digital Voice Terminal (ANDVT), and others as required. Communications through the SDRS are managed by automated digital network system which provides automated LAN/WAN management and integrated network management of RF signal traffic, automated routing and switching of RF transmission circuits, and channel access protocols management. The antennas for the SDRS are located in the MERS (Multifunction Electromagnetic Radiation Structure), a low-RCS hexagonal pyramid structure located on top of the ship's forward superstructure which encloses various communications, datalink, and IFF antennas. The base of the MERS pyramid contains the ship's IFF array which consists of a 360° electronically steerable circular antenna with two rows of 32 elements each (64 total) fed from a central beamforming network which can support both omnidirectional and pencil-beam transmission modes. Above the IFF array are a ring of six 1.0 meter diameter vertically polarized cavity backed UHF spiral antennas with 100W CW of transmit power each in the 225-400 MHz frequency range. The UHF line-of-sight antennas operate in 25 kHz wide transmission bands and allow communication with other surface ships out to 50 kilometers, helicopters out to 200 kilometers, and aircraft out to 600 kilometers. A ring of six L band datalink and TACAN (tactical air navigation system) antennas 25 cm in diameter are placed above the UHF antennas and cover the 960-1215 MHz frequency range with 2kW peak and 400W continuous transmission power. The MERS antennas are embedded into the composite sandwich panels of the mast structure which consist of a fiberglass-epoxy laminate with embedded frequency selective surface (FSS) layers which permits passage of the ship's sensor frequencies while rejecting all others.

Integrated Terminal System (ITS): The ship's SATCOM capability is enabled by the SDI Integrated Terminal System or ITS which provides centralized control of all ship satellite communication systems. For satellite communications capability the superstructure of the ship contains four active phased array SATCOM antenna assemblies embedded into the front, sides, and rear of the forward and aft superstructures. Each SATCOM antenna assembly contains a central dual-frequency UHF (244 to 318 MHz) and L band (1525 to 1650 MHz) transmit/receive (Tx/Rx) array and two peripheral arrays including an X band (7.9- 8.4 GHz uplink, 7.25 - 7.75 GHz downlink) (Tx/Rx) array array and a Ka band band uplink (43.5 to 45.5 GHz) and separate Ka band downlink (20.2 to 21.2) Rx array providing combined 360° azimuth and -0° to +80° elevation coverage in the UHF, L, X, and Ka Bands.

SDI FG 410 High Frequency Radio System (HFRS): The SDI FG 410 High Frequency Radio System (HFRS) is a digital solid-state high frequency (HF) communication system supporting interrupted continuous wave (ICW), voice, and digital data communications which provides over-the-horizon ship-to-ship, ship-to-submarine, ship-to-aircraft, and ship-to-shore radio connectivity independent of the shipboard digital radio or ITS SATCOM systems. Operating modes supported by HFRS include lower sideband (LSB), upper sideband (USB), independent sideband (ISB), frequency shift keying (FSK), continuous wave (CW), and amplitude modulation equivalent (AME). The HFRS consists of a transmitter subsystem, receiver subsystem, and a remote control/ monitor subsystem (RCMS). The transmitter subsystem supports 4,8, and 12 kW transmit power and operates in the 2 Mhz to 30 Mhz frequency range in 10 Hz increments with the ability to shift transmit frequency in less than 100 milliseconds and transmits through two 10 meter whip antennas located forward and aft on top of the superstructure. The receiver subsystem operates in the 14 Khz to 1.619 Mhz and 2 Mhz to 30 Mhz range and uses three smaller whip antennas mounted on the superstructure, two for the receiver system only and one which is shared with the ship's signal exploitation equipment (SSEE) system. The remote control/ monitor subsystem (RCMS) is primarily a manual backup system which used to provide control over the HFRS if the ship's SACCs (Ship Automated Communications Control System) becomes inoperable. The FG 410 radio system us coupled with an SDI FG 620 High Frequency Management System (HFMS), a complimentary system to the SDI High Frequency Radio System which uses an oblique incidence sweep-frequency ionospheric chirpsounder to determine the best HF transmission frequencies based on current ionospheric propagation measurements conducted by the chirpsounder. The chirpsounder sweeps upwards from 2 to 30 MHz in 4 minute intervals and can be synchronized with up to three separate HF transmitters which when synchronized allow them to transmit as much radio energy to a receiver as is possible under current ionospheric propagation conditions.

SDI FG 320 Tactical High-Bandwidth Datalink (THBD): The SDI FG 320 Tactical High-Bandwidth Datalink (THBD) is a full-duplex RF data link system operating in the Ka (14.4 GHz - 15.5 GHz) and X (9.7 GHz - 10.5 GHz) bands and is designed primarily to allow signal and imagery intelligence from airborne reconnaissance platforms to be streamed to ships in real time at distances up to 300 km. The system supports selectable 10.71,137, or 274 Mbps downlink rates with binary phase-shift keying (BPSK) downlink modulation and an uplink rate of 200 Kbps with offset quadrature phase-shift keying (OQPSK) modulation. The THBD system is coupled with a shipboard imagery exploitation system which has the the capability to receive, process, store, exploit, and disseminate Imagery Intelligence (IMINT) reports based on imagery received through the FG 320 datalink

TNS 150 Navigation System: The TNS 150 is a shipboard inertial navigation system (INS) which senses ship motion and computes the ship's position, velocity, attitude, and heading. The INS system consists of two independent, self-contained INS cabinets each containing a shock hardened 6-axis fiber-optic gyro inertial measurement unit (IMU) which provides < 0.01° RMS heading and < 0.01° RMS roll and pitch accuracy and 1 NM/72 hour position drift rate per hour navigation performance. For additional precession the INS is augmented by a GPS system with four 18 cm diameter GPS antennas covering the L1 (1.575GHz) and L2 (1.227GHz) frequencies blended into the upper corners of the deckhouse providing 360° azimuth and -0° to +80° elevation coverage which provides <4m spherical error probable (SEP) position and <0.008 m/sec velocity accuracy to the ship's navigation system.


Electronic Warfare & Countermeasures:
FMS 1800 Electronic Warfare System: The primary electromagnetic countermeasure system of the Tempest class cruiser is the FMS 1800 Electronic Warfare System, a comprehensive offensive and defensive electronic warfare (EW), electronic support measures (ESM), and electronic intelligence (ELINT) suite which combines passive radar warning receivers and phased array jammers for long range, over-the-horizon detection, identification, and targeting of threat emitters as well as automatic employment on-board RF countermeasures and support of passive over-the-horizon targeting capability for the ship's weapon systems. The passive radar warning system of the FMS 1800 consists of multiple single-quadrant, high-gain linear interferometer arrays smoothly blended into the superstructure of the vessel connected to a set of digital receivers and pulse processors inside the ship's superstructure which provide for 360° spherical broadband, all aspect detection, identification, and direction-finding of radar emissions in the 0.5 to 40 GHz range and communications in the 30 to 3,000 MHz range with the capability for <1° RMS direction finding and precise emitter location and threat identification capability against low probability of intercept waveforms and with additional over-the-horizon direction finding capability of HF, VHF, and UHF band signals. The offensive electronic warfare capability of FMS 1800 system includes multiple low, mid, and high band electronically scanned gallium nitride (GaN) based Digital Radio Frequency Memory (DRFM) jammers blended into the superstructure which provide for the jamming of hostile RF sensors in the 2 to 40 GHz range.

LWG 310 Naval Laser Warning System: For detecting laser sources including laser range finders, laser target designators, and laser beamriding missiles the ship's electronic warfare system is augmented by an SDI LWG 310 Naval Laser Warning System. The vessel's LWG 310 installation consists of a central controller connected eight sensor heads, four on each side of the superstructure, providing combined 360° coverage around the vessel. Each individual sensor head features 110° azimuth and +/- , 70° elevation coverage and is capable of detecting up to eight simultaneous laser range finders laser target designator emissions in the 0.5 μm - 1.65 μm range and laser beamriders in the 0.8 μm - 1.1 μm range.

SDI Sea Guardian Surface Ship Torpedo Countermeasures System: For defense against submarine launched torpedoes the Fervent class is fitted with the SDI Sea Guardian Surface Ship Torpedo Countermeasure System which combines various soft-kill and hard-kill torpedo countermeasure systems. The Sea Guardian system consists of a towed array sonar designed specifically for torpedo detection, a towed acoustic decoy with a a single-drum winch, an interface to the ship's trainable decoy launchers, and a processing cabinet with two display consoles, and and four 4-round anti-torpedo torpedo launchers on either side of the ship. The towed array sonar used by the system is a combined active and passive array sonar optimized to detect the high frequency sound signature of torpedo screws and active sonar homing heads. The towed array is supported by two vibration isolated modules (VIMs) located on either side of the sonar with the array being connected on one end to the ship using a fiber-optic tow cable and connected on the other end to the towed decoy with an array tow cable. The towed decoy array is designed to emit simulated ship noise such as propulsor and engine noise to lure a passive-sonar homing torpedo to the decoy instead of the ship. The towed decoy can also receive sonar pings from the active homing head of a torpedo and amplifies and returns the "pings" to the torpedo, presenting a larger false target to the torpedo. The hardkill component of the Sea Guardian system comprises a series of four box launchers on either side of the vessel which each contain six SDI S2s Barracuda anti-torpedo torpedoes in individual all-up rounds (AUR) which contain the Barracuda torpedo and a self-contained compressed gas launch system. The Barracuda torpedo is 21 cm in diameter, 2.0 meters in length, weighs 110 kilograms, and contains a 20 kilogram aluminized PBX explosive warhead. The guidance and fusing system of the Barracuda is designed to explode it in front of the oncoming torpedo and create a pressure wave which crushes the nose section of the oncoming torpedo. The Barracuda has a maximum firing range of 10 kilometers and is propelled by an advanced stored chemical energy propulsion system (ADSCEPS) which can propel the Barracuda at speeds up to 60 knots at depths up to 1,000 meters. Although designed as an anti-torpedo the Barracuda can also be used to engage midget submarines, naval mines, and unmanned or autonomous underwater vehicles.

ZTKG 130 Trainable Decoy Launching System (TDLS): The ZTKG 130 Trainable Decoy Launching System (TDLS) is an aimable decoy launcher which can launch a variety of decoys designed to decoy away anti-ship missile and torpedo threats. The ZTKG 130 system consists of multiple 12-round trainable countermeasures launchers controlled by a central command console inside the ship. Each 12-round launcher employs a rotating platform with 12 separate 130mm barrels which can each be individually trained in elevation. The ship is fitted with four decoy launching systems, two on either side of the ship used for acoustic torpedo decoys (24 total) and another two launcher on each side used for chaff/flare rounds and missile seduction decoys (24 total).

AM5 dual chaff/IR seduction decoy: The primary chaff seduction round employed by the TDLS is the AM5 dual chaff/IR seduction decoy which is capable of defeating dual-seeker missiles equipped with both IR/EO and radar seekers. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.

AM79 Buzzard active missile decoy: For decoying away radar-guided anti-ship missiles the TDLS can deploy the AM79 Buzzard active missile decoy, an expendable electronic-warfare rotary-wing drone which is designed to seduce RF guided anti-ship missiles by simulating the radar return of a large surface vessel. The buzzard features a cylindrical shaped fuselage 130 mm in diameter and 0.9 meters tall with both top and bottom mounted 1.8 meter diameter three-bladed counter-rotating coaxial rotors powered by two brushless DC motors. The rotors unfold from the body of the decoy after launch and fly the decoy into a pre-programmed flight path away from the ship where the decoy then hovers in place while emitting electronic warfare signals uses its fuselage mounted Digital Radio Frequency Memory (DRFM) jammers which are designed to seduce oncoming anti-ship missiles into targeting the decoy and not the host vessel. The decoy is powered by a thermal battery mounted in the center of the fuselage which gives the decoy approximately 60 minutes of flight endurance after launch.

AM7 Lamprey acoustic decoy: The TDLS can also launch the AM7 Lamprey, a 130mm diameter, expendable acoustic decoy designed to counter torpedo threats. After a rocket-powered launch into ocean the Lamprey is programmed to hover vertically using a pressure-controlled motor driving a small, shrouded propeller in the tail of the decoy. The Lamprey is designed to hover at a pre-selected depth from 10-300 meters where it listens for torpedo transmissions. Active acoustic transmissions are detected and analyzed resulting in decoy selectivity and generation of the appropriate deception signal for transmission including target signature and target self noise. If no torpedo transmissions are detected the decoy is programmed to emit warship propulsor and engine noise to lure in passive homing torpedoes. Power for the motor and electronics of the Lamprey is provided by a thermal battery. The Lamprey is programmed to hover and emit noise until the battery dies where the decoy then sinks and all software onboard is erased.


Signature Reduction:
Like other SDI Marine Systems surface combatant warships the Fervent class features extensive radar and infrared signature reduction to reduce the ship's detectability and vulnerability to anti-ship missile threats. The hull and superstructure feature a faceted shape with an enclosed mast and sensors suite designed to eliminate corner reflectors and reduce the ship's detectability by radar systems. The forward and side superstructure of the vessel is fitted with SDI's S-RAM, a type of ballistic grade structural radar absorbing material consisting of 2 cm thick panels made from multiple layers of M5 fibers fibers containing a lossy filler backed by a carbon fiber laminate acting as a reflector. The panels are designed to survive extreme weather exposure and ballistic damage and provides an average -20 dB reflectivity across the 2-40 GHz frequency range (L through Ka bands). The rest of the hull and superstructure is painted in a radar absorbing paint coating 1 to 5 millimeters thick consisting of lossy dielectric material embedded in a polymer resin which provides -20 dB reflectivity across the 9 -13 GHz range (X band). The infrared signature from the ship's engines is suppressed using an infrared signature suppression system built into the exhaust uptakes. The system consists of a film cooled stainless steel outer duct surrounding a conductively and film cooled stainless steel centerbody and a film cooled stainless steel diffuser which blocks any line of sight view of the heated metal surfaces and reduces uptake metal temperatures to less than 25°C above ambient using ambient air draw into the uptake through a multi-lobed ejector nozzle at the base of the diffuser. The diffuser also contains multiple rings of atomizing nozzles which inject a a fine mist of seawater into the exhaust stream, cooling the exhaust stream to a plume temperature of under 150°C. Seawater injection is controlled by an on board signature management system which interfaces with the ship's propulsion machinery control system and controls the flow of water as a function of the engine power.

The magnetic signature of the vessel is reduced by SDI's High Temperature Superconducting Degaussing System (HTSDS) which is designed to reduce the vessel's magnetic signature. The superconducting system provides an over 95% reduction in the ship's magnetic signature with a total weight 80% less than a conventional copper cable based system singicnalty reducing the vulnerability the ship to magnetic mine threats. The degaussing system components include a control unit, power modules, junction boxes, cryo coolers, accumulation tanks, high temperature degaussing cable assemblies, and cryogenic cold gas lines used to cool the degaussing cable assemblies. The system uses three separate loops of independently controlled degaussing coils arranged in three axes which are designed to counteract the ship's magnetic signature in the vertical, longitudinal and athwartship planes. Each coil loop is connected to an independent power module connected to the ship's zonal DC power distribution system which energizes the coil with up to 3,000 Amps of current at voltages of up to 138 kV. The cable assemblies consists of a hollow bismuth strontium calcium copper oxide (BSCCO) high temperature superconducting cable wrapped around a hollow support tube and supported by a flexible cyrostat consisting of a layer of inner corrugated stainless steel tubing, a layer of multi layer insulation (MLI), a polymer support layer, a vacuum space, an outer layer of corrugated stainless steel tubing, and an outer cable sheathing. The cooling loop for each cable includes a cryogenic refrigerator, a seawater heat exchanger, and a circulation pump which pumps gaseous helium through the cryostat and hollow support tube to maintains cable temperature at 55° K. The entire HTSDS is controlled from a central degaussing control unit (DCU) which receives magnetic field data either from both a shipboard triaxial magnetic probe system and from a magnetic geophysical model which takes data from the ship's navigation system and automatically calculates the required current for each degaussing coil to cancel out the ship's magnetic signature.


Passive Protection & Damage Control:
The Fervent class features passive armor protection in the form of several hundred tonnes of composite armor panels made from M5 ballistic fiber laminated into cured thermoplastic panels which provide ballistic impact and spall protection to the superstructure and vital areas of the ship. The ship's blast hardened bulkheads are designed to deform plastically and maintain watertight integrity in the event of an explosion from a bomb or missile warhead inside the ship and feature double-spaced plate construction with an internal fragment resistant membrane designed to stop fragments from penetrating further into the ship. The automatic opening/closing watertight doors in the bulkheads likewise feature a blast hardened membranes structure design with approximately 10 times the blast force resistance of a conventional watertight door.

Damage control is assisted by an SDI Marine Systems developed Automated Ship Control System (ASCS). The ASCS is controlled by a centralized computer which amongst other functions provides real-time damage information to the crew through a graphical display located in the ship's damage control center. Additionally both the ship's bridge and CIC also also fitted with displays connected to the ASCS. The ACSC is designed to run automatically where after the ASCS detects damage to a compartment it will immediately isolate it and activate appropriate damage control measures. Alternatively the ASCS can be set to manual mode where the operator will have to specify the damage control measures after the system detects ship damage. The ASCS also controls and monitors the ship's engines and machinery and will alert engineers on watch duty through their assigned tablet computer when an engineering issue or machinery failure is detected and requires attention. This remove the need for time based maintenance, the system will simply alert the crew when a component or system requires maintenance. Each compartment and each piece of machinery on the ship are monitored using SDI's Two Wire Automatic Remote Sensing Evaluation System (TWARSES) which includes both visible CCD and infrared cameras located in each ship compartment. After damage is detected in a compartment the ASCS can respond in a variety of ways including isolating the damaged compartment by closing the electrically actuated watertight doors around the compartment. If the IR camera detects a fire the system will activate the compartment's overhead sprinklers and can also pump the compartment with aqueous film-forming foam , high velocity fog, and/or carbon dioxide agents if necessary. After the fire is extinguished water and firefighter agents are removed using a bilge draining pump installed in each compartment. The ASCS will also reroute ventilation, electrical power, and water around the damaged area and activate additional pumps, generators and other devices if necessary. If the compartment has been breached and is in danger of flooding the system will flood the compartment with foam which rapidly solidifies and restores reserve buoyancy. This system however is only used as an absolute last resort as it renders the compartment unusable. The ASCS also controls the ship's CBRN protection system by passing air from the ventilation intakes through containment filters before it enters the ship. Air in the ship is maintained at 5.0 millibars above local atmospheric pressure to provide a positive pressure and prevent contaminated air from entering into the ship through a breach in the hull.


Armament:
20.3 cm SK L/60 Naval Gun: The 20.3 cm SK L/60 is a fully automated and stabilized, single barrel naval artillery gun system designed for use against surface targets and as a long-range shore bombardment weapon. The gun system consists of three sub-assemblies, the SK L/60 gun assembly with its enclosed triaxial stabilized gun mount, automated ammunition supply system, and fire control support system and crew display with control consoles. The SK L/60 gun features a 60 caliber length monobloc barrel and features a semi-automatic vertically sliding breechblock which is automatically opened under the force of recoil. The breech is sealed with a mild steel case containing the propellant charge. The gun can fire either standard spin stabilized 110 kilogram 20.3 cm base-bleed (BB) projectiles including high explosive and cluster-HEAT with a muzzle velocity of 995 m/s out to a range of 60 kilometers or can fire a 180 kilogram rocket assisted, fin stabilized IRGM (infrared guided munition) projectile at a muzzle velocity of 825 m/s out to a range of 200 kilometers. The gun can be loaded any any angle of elevation and has a maximum sustained rate of fire of 12 rounds per minute. The gun is fed from an automated ammunition supply system consisting of a projectile and propellant charge hoist, automatic fuze setter, and a service drum located directly under the gun house which contains 75 projectiles and 75 propellant charges. An additional 400 rounds and 400 propellant charges are located in a two story magazine below the ready service drum including 80 IRGM projectiles. The mount is capable of training to +/- 165° on either side of the ships centerline at a rate of 30°/s and elevating from -10° to +70° at a rate of 20°/s. A shipboard fire control support system is used for control of the gun which plans fire support missions, determines firing solutions and shell trajectories, selects ammunition, and determines the best ship course for executing fire support missions.

Medium-Caliber Gun System (MCGS): For close in defense against small boats the ship is fitted with two SDI medium-caliber gun system (MCGS) turrets placed atop the superstrucutre on either side of the aft hangar Each MCGS mount contains an SDI 4.0 cm SK L/70 Flak cannon and an electro-optical targeting sensor with a forward looking infrared sensor, low light television camera, and a laser rangefinder. The 4.0 cm SK L/70 is an air-cooled, recoil operated automatic cannon which fires 40×365mmR ammunition at a rate of up to 300 rounds per minute. The 4.0 cm SK L/70 gun is housed in a triaxial stabilized low-RCS gunhouse constructed from fiberglass and is capable of traversing a full 360° at a speed of 130°/sec and is capable of elevating from -20° to +80° at 75°/sec. The gun includes an on-mount muzzle velocity radar and is designed to fire 0.975 kg programmable air-burst munition (PABM) projectiles at a muzzle velocity of 1,012 m/s. The 40mm PABM round contains 0.12 kg of HMX based polymer bonded explosive (PBX) surrounded by over 3,000 tungsten balls 3mm in diameter and features a multi-mode programmable fuze with six operating modes; proximity, gated proximity, gated proximity with impact priority, timed airburst, impact, and impact plus delay modes. The gun is fitted with a 72 round magazine which is automatically replenished by an additional 72 round magazine located inside the gun house. Total weight of the MGCS is 2,300 kg empty and 2,650 kg with a full load of ammunition.

S70 Vertical Launch System: The Fervent class is fitted with a total of 32 S70 vertical launch cells placed in a 32 cell module in the ship's bow. The S70 is a cold-launch system which uses missiles encased in individual concentric launch cells as modular all-up rounds (AURs) each containing the missile, concentric launch tube, launch tube electronics, and missile ejection system. The S70 8-cell central modules contain 8 launch cells in a 4x2 arrangement with the launch cells inclined at a 10 degree angle towards the ships centerline to prevent missiles with malfunctioning rocket motors from crashing back onto the deck after launch. Each launch cell is capable of accommodating either a single launch tube which can contains missiles with a maximum length of 7.0 meters, diameter of 0.6 meters, and a weight of 2,500 kg or can be quad-packed with four smaller launch tubes which can accommodate missiles with a maximum diameter of 0.3 meters, and a weight of up to 500 kg. The missiles are ejected from each launch tube using a steam generator system which uses a small solid-propellant gas generator which exhausts through cooling water into the base of each launch cell, creating expanding high pressure steam which then forces the missile out of the launch tube. Safety and passive protection features of each VLS module include concentric anti-fragmentation shields placed around each launch cell tube to prevent in-cell missile fratricide and a deluge system which can flood each 4 or 8 cell module in the event of a missile catching fire in the launch tube. Launch tubes are connected to the launch cells through shock collar that is designed to absorb acceleration loads from an underwater detonation near the ship. The individual missile cells are connected to the ship's weapon control system via redundant port, central, and starboard fiber-optic Ethernet lines which transmits launch commands to the individual missiles and allows for missile status information before launch to be sent back to the weapon control system.
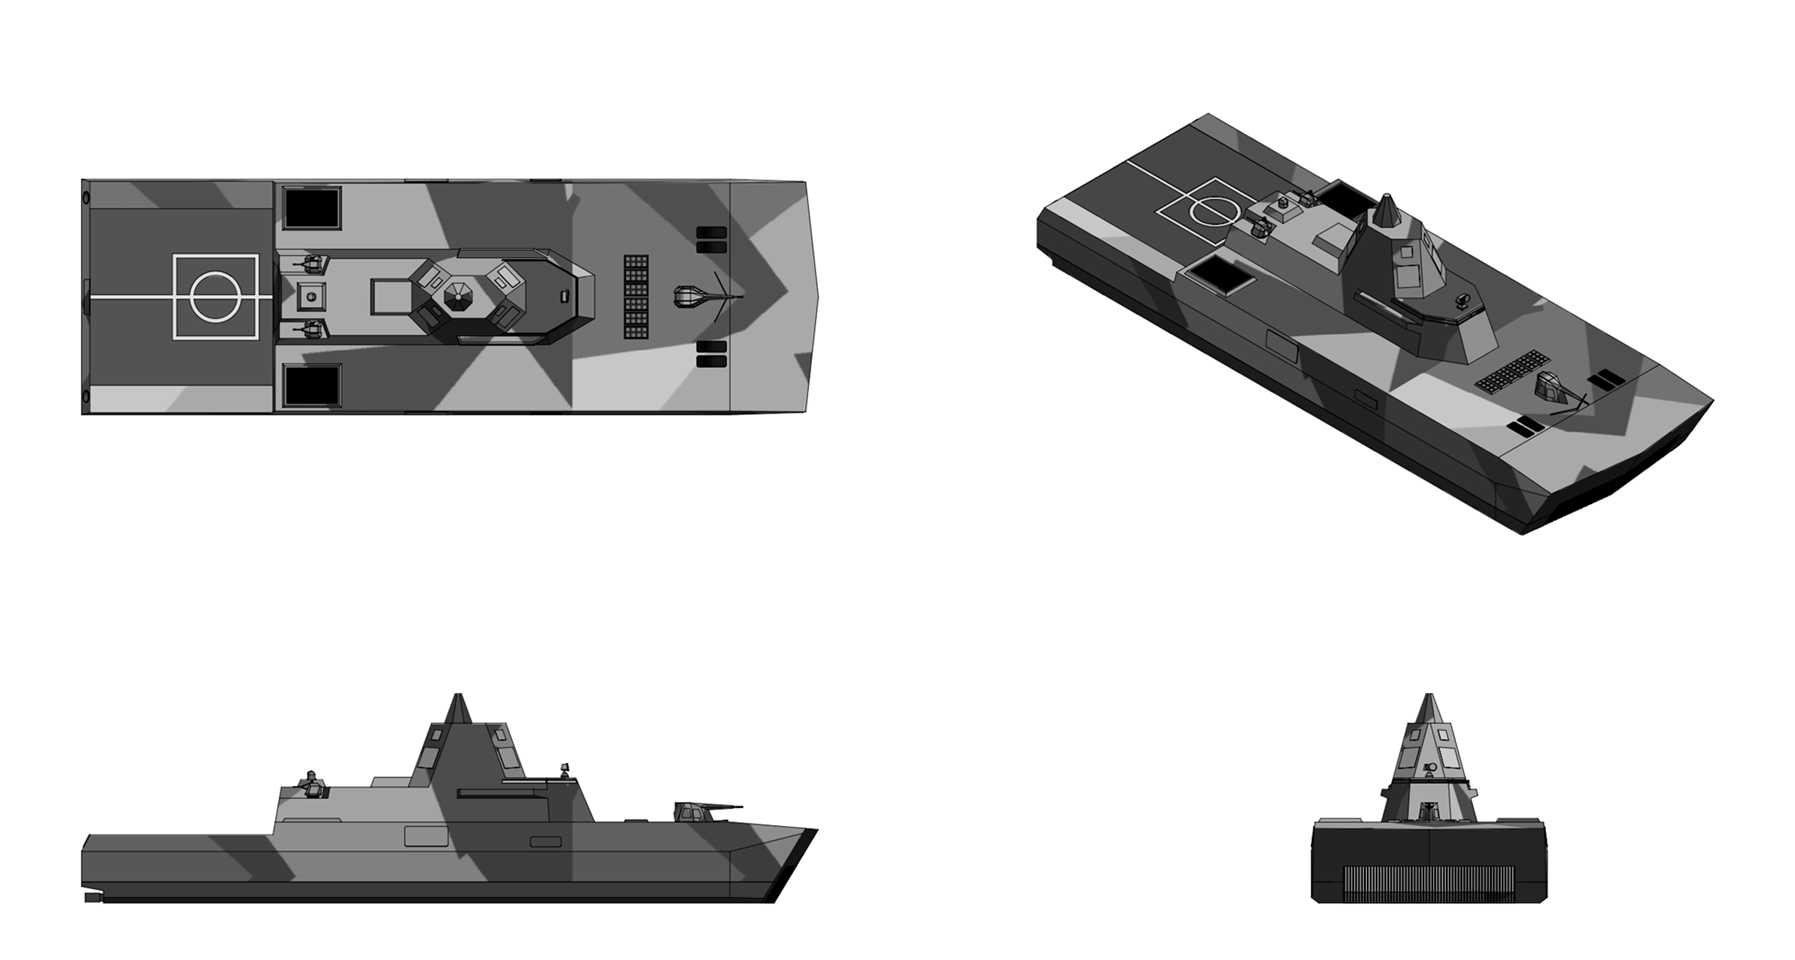
Last edited by The Technocratic Syndicalists on Wed Sep 09, 2026 8:44 am, edited 27 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Tue Jun 06, 2017 12:18 am

Image

LCU 40

Basic Information:
  • Type: Hydroplaning landing craft
  • Displacement (light):240 tonnes
  • Displacement (full): 490 tonnes
  • Complement: 8-14
  • Length: 40.7 m
  • Beam: 13.0 m
  • Draft: 2.5 m
Propulsion:
  • 4x AMG 20V 17/19 M86 diesel engines, 3.9 MW each
  • 4x shafts, 4x SDI waterjets

Performance:
  • Top Speed : 40 knots light, 30 knots loaded
  • Range: 1,500 km at 30 knots
Sensors:
  • SDI FMG 830 X band navigation radar
Cargo Capacity:

Armament:
  • 2x MG 45E machine guns


Overview:
The LCU 40 is a class of large, high speed landing craft designed by SDI Marine Systems. The LCU 40 is designed to operate from the well decks of amphibious assault ships and is a roll on/roll off (RORO) configuration landing craft with hydraulically operated bow and stern ramps that allow vehicles and other heavy cargo to be loaded onto the vessel and then unloaded onto a beach or pier. With a with a unique planing hull the LCU 40 is designed significantly exceed the performance of conventional landing and can transport up to three main battle tanks as payload while traveling at speeds higher than 30 knots. With a long cruising range of over 800 nautical miles the LCU 40 enables over-the-horizon amphibious operations and can also be used as a shore-to-shore connector for the reposition and resupply of amphibious forces over a wide operating area.


Design & Construction:
The LCU 40 features a flat bottom, hydroplaning hull with port and starboard chines and a large transom stern. The upper hull includes a large deck with a 260 square of meters which can accommodate up to 240 tonnes of payload including three PzKpfw 151 main battle tanks, six AKpfw 903 infantry carriers, or six KfZ 310 all-terrain carriers. The hull and superstructure is constructed from welded St 92 (900 MPa yield strength) high-strength structural shipbuilding steel divided into 11 longitudinal watertight compartments. The superstructure is designed to accommodate a crew of 8 sailors with berthing for up to 14 personnel and includes two control stations, a primary one located on the starboard side of the vessel and and a smaller aft facing control station located located on the port side.


Propulsion:
SDI 20V 17/19 M86
  • Type:Diesel engine
  • Length: 4.015 m
  • Width: 1.47 m
  • Height: 2.44 m
  • Dry Weight: 12,080 kg
  • Type: 4 stroke
  • Arrangement: 20V
  • Cylinder bore: 170 mm
  • Piston stroke: 190 mm
  • Displacement: 86.2
  • Speed: 2100 rpm
  • Aspiration: sequential turbocharging
  • Rotation: Counterclockwise flywheel
  • Specific fuel consumption: 210 g/kW-hr
  • Output: 3,900 kW
  • Fuel system: Modular common rail (MCRS)
The LCU 40 is powered by a total of four SDI 20V 17/19 M86 diesel engines driving four SDI Marine Systems SS63 waterjet thrusters through four engine mounted AZF 400 gear reduction units. The SDI 20V 17/19 M86 is a 4-stroke V20 fuel-injected turbocharged marine diesel engine with a 17 centimeter bore, 19 centimeter stroke, and 86.2 liter displacement and has a maximum mechanical power output of 3,900 kW at its maximum rated speed of 2,100 rpm. The engine employs sequential turbocharging with twin water-cooled turbochargers with an engine coolant temperature-controlled intercooler. The diesel engines are coupled to four engine mounted gear reduction units which drive four SDI Marine Systems SS63 axial-flow thrust-vectoring and reversing waterjet propulsors which give the vessel a maximum speed of 40 knots unloaded or 30 knots with a full payload. Maximum fuel capacity of the vessel is 65,000 liters of diesel fuel which gives the vessel a range of over 800 nautical miles at a speed of 30 knots. Electrical power is provided by two 100 kw diesel generators which provide 230 VAC, 50 Hz power to the ship's electrical system.
Last edited by The Technocratic Syndicalists on Sun Apr 02, 2023 12:22 pm, edited 13 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Tue Oct 06, 2020 6:02 pm

Image


Centaur Class Frigate

Basic Information:
  • Role: Missile frigate
  • Displacement: 4,000 tonnes
  • Crew: 75-100
  • Length: 111.5 m
  • Beam: 32.0 m
  • Draft: 1.5 m (cushion), 6.0 m (off cushion)
Propulsion:
  • 2 xSDI/AEG AGR1500 nuclear gas turbine generators, 150 MWe each
  • 4x AEG high temperature superconducting (HTS) AC drive motors, 50 MW each
  • 6x AEG high temperature superconducting (HTS) AC lift fan motors, 7.5 MW each
  • 6x Variable-geometry lift fans
  • 4x SDI SS150 waterjets

Performance:
  • Top speed: 100 knots (cushion), 25 knots (off cushion)
  • Range: unlimited
Sensors:
  • SDI FMG 300 X band Multi-Function Radar (MFR)
  • SDI FMG 400 C band Volume Search Radar (VSR)
  • SDI EOS 400 Staring Infrared Search & Track System
  • SDI FLG 200 Radar & Electro-Optical Fire Control System
  • SDI RMS 230 Hull-Mounted Sonar
  • SDI VTS 980 High-Speed Towed Sonar

Electronic Warfare and Countermeasures:
  • SDI FMB 300 Electronic Support Measures System
  • SDI LWG 310 Naval Laser Warning System:
  • SDI ZTKG 130 Trainable Decoy Launching System (TDLS)
  • SDI Sea Guardian Surface Ship Torpedo Countermeasure System

Armament:


Overview:
The Centaur is a class of high speed stealth missile frigates designed by SDI Shipbuilding Systems. The Prowler class is intended to act as a high speed patrol boat for operations in coastal and littoral waters and combined extremely high speed and low radar cross section with anti-surface and anti-submarine sensor and weapon systems.


Design & Construction:
The Centaur class has an overall length of 111.5 meters, beam of 32 meters, and a full load displacement of 4,000 tonnes. The Centaur class is a type of surface effect ship (SES) or sidewall hovercraft which consists of a catamaran hull with twin side hulls and a central air cushion between the side hulls which can be pressurized to generate lift and reduce the ship's draft and lower drag resistance. The ships can can operate either in on-cushion mode for cruising at high speeds or can operate in off-cushion mode like a conventional catamaran for operating at low speeds. In both modes the wide beam of the ship results in excellent stability characteristics relative to a conventional monohull and is designed to safely operate in up to sea state 6 (9 meter wave height) and in hurricane conditions. The catamaran hull is sized to provide sufficient buoyancy in the off-cushion mode to maintain the weather deck at the desired height above the water and is constructed primarily from welded Ti-5111 (Ti-5Al-1Sn-1Zr-1V-0.8Mo) marine grade titanium alloy, used for it's superior strength-to-weight ratio compared to conventional shipbuilding steels and aluminum alloys and it's excellent corrosion performance being essentially immune to seawater corrosion, eliminating the need for the extensive cathodic protection systems, anti-corrosion coatings, and periodic inspections. The hull has a a twin-sidehull catamaran configuration with a bridging wet deck, transverse web frames, and longitudinal stiffened-plate construction. The hull has an angular, faceted shape designed to minimize both aero-hydrodynamic drag and radar cross section and includes both hard chines and spray rails to to minimize wave spray at high speeds. Each sidehull is a watertight, longitudinally framed structure extending the full length of the ship. The sidehull shell plating ranges from 6 mm at the upper works to 12 mm at the keel, with longitudinal T-stiffeners at 200 mm spacing and transverse web frames at 750 mm spacing. The interior walls of each sidehull are flat to accommodate the planing-seal operating envelope. Full keel-length fences, 1.0 m deep, are integral with the lower sidehull to reduce cushion venting and waterjet inlet air ingestion. The wet deck spans between the sidehulls and forms the upper boundary of the cushion volume. It is a flat-panel stiffened structure designed to withstand the slam pressures associated with wave impacts during on-cushion operation. Panel thicknesses range from 8 to 14 mm depending on location, with closer stiffener spacing in the forward sections where slam loads are most severe. The wet deck between the catamaran side hulls includes a complete double bottom, ensuring penetrations of the wet deck will not result in flooding of any operational space. The transverse structure bridging the sidehulls at the main deck level and above carries the global bending and torsional loads. Major machinery foundations including for the as turbines, waterjet propulsors, lift-fan drive trains, and diesel generators are fabricated from Ti-5111 plate and forging with bolted connections to facilitate machinery removal and replacement. Vibration isolation mounts are incorporated at all major machinery interfaces. The central superstructure includes a hangar and a pilothouse with unobstructed viewing around the ship and is constructed from carbon-fiber-reinforced polymer (CFRP) composite using a quasi-isotropic layup of intermediate-modulus (IM7) carbon fiber in a toughened epoxy matrix. This material system provides a specific compressive strength approximately 3.5 times that of conventional shipbuilding aluminum alloys, enabling superstructure weight savings on the order of 35 to 40 percent. The superstructure is fabricated as a series of large, co-cured panel assemblies joined by bolted titanium splice plates at the interface with the titanium hull structure. This bolted connection eliminates the galvanic corrosion concerns inherent in direct bonding of carbon fiber to titanium and provides a defined load path that can be inspected throughout the ship’s life. A non-conductive fiberglass cloth barrier layer is interleaved at all CFRP-to-metal interfaces. The external surfaces incorporate tumblehome geometry with planar faceting to redirect radar returns away from threat emitter locations. The composite layup includes frequency-selective surface (FSS) layers and resistive-card radar-absorbing material (RAM) plies integral to the laminate, reducing the broadband radar cross-section of the superstructure by an estimated 15–20 dB relative to an equivalent metallic structure. All external fittings, sensor apertures, and access panels are designed with edge treatments and impedance-matching to preserve the low-observable profile.


Propulsion
AGT1500 Nuclear Gas Turbine
  • Type:Nuclear gas-turbine
  • Length: 9.6 m
  • Width: 3.5 m
  • Height: 4.25 m
  • Weight: 265,000 kg
  • Compressor: 5 stage LPC, 5 stage HPC
  • Compression ratio: 3.2:1
  • Core: Right circular cylinder
  • Moderator: Nuclear-grade graphite (IG-110)
  • Turbine: 2 stage HPT, 2 stage LPT
  • Thermal efficiency: 36.5%
  • Output: 150,000 kWe @ 3,600 RPM
  • Fuel: TRISO-coated HEU UCO,97% U235 (HEU)
The Centaur is a surface effect ship (SES) which uses a fan-driven air cushion between the ship's two catamaran-type hulls to augment the ship's buoyancy. The air cushion is 26 meters wide, 75 meters long, and 5.5 meters deep and supports over 80% of the ship's weight to allows the vessel to achieve significant higher speeds with the same engine power as a ship with a conventional hull. In addition to extremely high speed the SES design provides the ship with excellent seakeeping and maneuverability characteristics and gives the ship a shallow draft for navigating in coastal or littoral waters. The propulsion plant features a turbo-electric integrated electric propulsion (IEP) system with a total of two AEG AGT1500 nuclear gas turbine generators producing electricity which powers superconducting motors driving the ships waterjet thrusters and lift fans and providing electrical power to the ship's zonal MVDC electrical system. Each AGT1500 is a helium-cooled, TRISO-fueled, graphite-moderated reactors operating at 1,040°C outlet temperature in a closed Brayton cycle with recuperation and intercooling. Fuel is TRISIO coated UCO fuel particles dispersed in graphite fuel elements. Each module produces 100 MW of shaft power from a free-power turbine which drives an HTS generator directly at 3,600 rpm. The reactor core is a right circular cylinder approximately 1.2 m in diameter and 1.0 m in active length constructed from hexagonal fuel elements with seven axial cooling channels each. The core is surrounded by a beryllium radial reflector containing rotating control drums with boron carbide sectors. The beryllium radial reflector assembly contains 12 rotating control drums, each consisting of a beryllium cylinder with a 120° sector replaced by stainless-steel tubes filled with B₄C absorber material. The drums rotate through 180° to transition from full absorption (absorber facing core) to full reflection (beryllium facing core). The control drums are driven by electric actuators mounted on the pressure-vessel dome through splined quill shafts. The reactor operates with helium coolant at an outlet temperature of 1,040°C and a system pressure of 10.5 MPa. Core thermal power is approximately 435 MWth per reactor, yielding 150 MW of output shaft power at an overall cycle efficiency of approximately 38%. The reactor incorporates multiple layers of safety: the TRISIO fuel particles themselves provide the primary fission-product containment barrier within each microscopic fuel kernel which incorporates incorporate a five-layer coating system: porous carbon buffer, inner pyrolytic carbon (IPyC), silicon carbide (SiC), outer pyrolytic carbon (OPyC), and an additional zirconium carbide (ZrC) overcoat that provides enhanced fission-product retention at temperatures up to 1,800°C. The helium coolant is inert and non-corrosive eliminating coolant-fuel chemical interactions, the graphite moderator has an enormous thermal inertia and a strongly negative temperature coefficient of reactivity, providing inherent passive shutdown capability, and the entire primary system is enclosed within a thick-walled Inconel 718 containment vessel with provisions for positive metal-to-metal shaft sealing in the event of sinking. Each AGT1500 employs a closed Brayton cycle power conversion system with recuperation and one stage of intercooling, using helium as the working fluid. The turbomachinery/heat-exchanger module integrates the high-pressure and low-pressure compressors, gas-generator turbine, free-power turbine, recuperator, precooler, and intercooler into a single compact package within the containment vessel. Heat rejection from the precoolers and intercoolers is to an intermediate closed-loop freshwater system, which in turn rejects heat to seawater through titanium plate-frame heat exchangers. Emergency decay-heat removal is provided by a passive natural-circulation cooling system that requires no external power, transferring heat to ambient air through dedicated heat exchangers. The free-power turbine drives an output shaft through an internal epicyclic reduction gear, providing 150 MW of mechanical shaft power at 3,600 rpm which drives an integral 150 MW HTS synchronous generator. The generator employs a rotating-field architecture with REBCO (Rare-Earth Barium Copper Oxide) HTS field coils cooled to approximately 40 K by Gifford-McMahon cryocoolers. The HTS field winding produces magnetic flux densities of 5 T in the air gap, enabling a machine of approximately 3.0 m diameter and 3.5 m length to produce 150 MW at 3,600 rpm with a weight of approximately 30 tonnes. Each AEG AGT1500 module is a complete, self-contained nuclear powerplant consisting of a helium-cooled, graphite-moderated, HEU TRISO-fueled reactor core, a closed Brayton cycle power-conversion system, an in integral 150 MWe REBCO HTS synchronous generator with SiC AFE converter, radiation shielding (internal tungsten plus plug shield, external borated ZrH₂ + borated water), Inconel 718 alloy pressure vessel and thick-walled containment vessel with sinking safe shaft seal, passive decay-heat removal system (natural circulation based, no external power required), helium purification system, and emergency cooling system and all auxiliary systems, Each module weighs approximately 265 tonnes The two modules are installed one per sidehull in shielded reactor compartments. The modules are oriented with their output shafts facing aft, aligned with the HTS generator outputs feeding the MVDC bus. A minimum 1.0 m void space surrounds the shaped external shield on all sides serving as both radiation-attenuation buffer and shock isolation clearance. The void spaces are normally dry but can be flooded for emergency ballast. Each AGT1500 module is mounted on a six-degree-of-freedom shock isolation system consisting of multi-axis wire-rope isolators at eight mounting point. The isolators are designed for the SES on cushion dynamic environment (±0.3 g vertical, ±0.1 g lateral continuous) superimposed with the shock-event transients. A dedicated hull access opening in the sidehull upper structure sealed by a bolted Ti-5111 closure plate permits reactor module removal and replacement by a heavy lift crane at a shore facility. The module removal sequence from disconnecting electrical, cooling-water, and control cables, unbolting the shock mounts, and extracting the module horizontally through the access opening is designed for completion in approximately 24 hours. The two reactor compartments are located in opposite sidehulls, separated by the full cushion beam. This separation ensures that a single weapon hit, flooding event, or fire cannot disable both reactors simultaneously. The AC power from the two HTS turbogenerators is converted to to 6000 VDC with an active-front-end (AFE) power conversion module (PCMs) that rectifies the generator’s 3-phase AC output to ±6 kVDC for the MVDC bus. The AFE employs silicon-carbide (SiC) MOSFET switching devices operating at 20 kHz, providing near-unity power factor, low harmonic distortion (≤1% THD), and active fault-current limiting. Each AFE is rated for 150 MW continuous throughput with 99.5% conversion efficiency. The 6000 VDC power is then routed to both port and starboard DC buses which in turn supply power to sixteen electrical zones (eight per sidehull) cross connected by automated bus-tie breakers with one DC/DC PCM per bus (two each per zone) which converts the 6000 VDC to 750-800 VDC or 650 VDC to supply DC loads in each zone. Both DC/DC PCMs in each zone also supply one or more DC/AC PCMs with 750-800 VDC which then converts the 750-800 VDC to 450 VAC at 60 Hz for AC loads. All electrical loads in each zone are connected to both port and starboard bus ensuring continued operation if either port or starboard bus becomes inoperable.

Each side hull has twin side-by-side mounted SS180 waterjet propulsors driven by four REBCO HTS permanent-magnet synchronous motors. Each motor is designed for 50 MW of continuous power. Each superconducting motor is a three phase, six pole synchronous air-core AC motor with a brushless exciter which has a rated speed of 600 RPM at its design voltage of 7,200 VAC with a full-load efficiency of 97.5%. The rotor employs yttrium-barium copper-oxide (YBCO) high temperature superconducting ceramic conductors and is cryogenically cooled to 77 degrees K using gaseous helium from cryocooler module containing single Stage GM cryocoolers located at the non-drive shaft end of the motor which feeds helium gas into the rotor through a rotating seal at the back end of the motor. The rotor housing is further enclosed in a vacuum-sealed cryostat to maintain cryogenic temperatures inside the rotor. The stator coils of the motor are made from copper Litz conductor and are cooled using a liquid dielectric coolant. Each motor with its integral cryocooler weighs approximately 10.0 tonnes compared to approximately 70 tonnes for a conventional motor of equivalent power. The motors are driven by a SiC MOSFET variable-frequency drive (VFD) drawing power from the ±6 kVDC MVDC bus. The VFD provides fully variable speed from 0 to 600 rpm with torque mode and speed mode control, enabling the propulsion control system to command any thrust level from zero to maximum in any combination across the four pumpjets for maneuvering, thrust vectoring, and differential-thrust heading control. The SDI Marine Systems SS150 is a two-stage, 150 cm diameter waterjet propulsor rated at up to 50 MW input ower and consists of a low-speed axial-flow inducer provides sufficient head rise to suppress cavitation at the entry to the main impeller across the full speed range and a mixed-flow impeller operating at higher rotational speed provides the primary head rise and thrust generation. The impeller is manufactured from cast Ti-6Al-4V titanium alloy for maximum cavitation erosion resistance and fatigue life. The inducer is driven at a speed ratio of approximately 0.45:1 relative to the main impeller via a concentric, coaxial epicyclic gear reduction unit. Each pair of waterjet propulsors (inboard and outboard) in each sidehull is fed from a single semi-flush seawater inlet with a variable-geometry ramp roof. The ramp-roof position is continuously modulated as a function of ship speed, pump speed, and sea state to maintain optimal inlet pressure recovery and to suppress cavitation across the full operating envelope. Inlet side plates combined with the full keel-length sidehull fences prevent cushion air ingestion that could degrade propulsor performance. An active broach-detection system using differential-pressure sensors at the inlet lips closes a servo loop on propulsion engine output-shaft speed to prevent overspeed events. Each waterjet propulsor discharges through a single fixed-area nozzle, a flexible transom seal, and a hydraulically actuated steering sleeve. The propulsors additionally incorporate thrust-reverser buckets for deceleration and low-speed maneuvering. Steering is accomplished through the use of thrust vectoring and differential thrust with the ship having a turning radius of 3,000 meters at a speed of 80 knots and 1,000 meters at 40 knots. With thrust reversal on all four waterjets the ship can come to a complete stop within 1,000 meters from full speed and by using reverse thrust on one side of waterjet thrusters can turn within a diameter of 600 meters at speeds below 20 knots.

The ship's lift system consists of two sets of lift machinery, one in each side hull, along with the lift and ride control system electronics. Each set of lift machinery consists of three in line variable geometry lift fans connected by flexible couplings, ducting, and ride control valves. Each fan is 2.2 meters in diameter and rated at 7,500 kW of power and consists of a carbon fiber reinforced composite housing with a double axial inlet, variable inlet guide vanes, airfoil-shaped carbon fiber reinforced composite radial fan blades, constant-velocity volute housings, and a single annular discharge nozzle. Lift fans are driven by integral 7.5 MW HTS motors similar in design to the propulsion motors, operating at maximum speed of 1,200 RPM with a motor mass of 1.2 tonnes each. The lift fans employ incorporate Ti-6Al-4V titanium-alloy impellers, double axial inlets, airfoil-shaped radial blades, and constant-velocity volute housings with a single circular discharge. The variable-geometry capability is the primary means of active ride control: by modulating the IGV positions differentially across the six fans, the ride-control system can independently vary the airflow and pressure to the bow seal, cushion plenum, and stern seal to counteract wave-induced heave, pitch, and roll excitations. The lift fans draw in air through intakes located at the front of the weather deck which flows into separate port and starboard air distribution ducts. Air from the forward two lift fans supplies air to the forward seal, air from the central lift fans supplies the central air cushion, and air from the aft two lift fans supplies the aft seal. The lift system uses planning bow and stern seals constructed from glass-reinforced polymer (GRP) designed to have low drag and sustained high-speed water impact resistance. Both bow and stern seals are fully retractable to reduce drag and are pressurized 10-15% higher than the air cushion. The ships' Active Ride Control System (ARCS) integrates the variable-geometry fan drives, vent valves, and their associated servo-hydraulic actuators with a sensor suite comprising two six-axis inertial measurement units, two radar altimeters, a bow-mounted wave-profiling LIDAR, and cushion-pressure transducers. The control algorithm is a model-predictive controller (MPC) that anticipates upcoming wave encounters using the forward-looking LIDAR data and pre-positions the fan and valve states to minimize heave accelerations before the wave energy arrives at the cushion while also actuating the vent valves and fan variable inlet guide vanes to regulate the air flow and pressure through the air cushion and seals to dampen ship heave accelerations from waves and provide enhanced ride quality at high speeds. The predictive model-predictive ride-control system reduces on-cushion heave accelerations at the crew’s center of gravity to levels less than 0.1 g RMS for four hour exposures and less than 0.2 g RMS for 30 minute exposures, across the one-third-octave band from 0.1 to 5.0 Hz. ARCS operation is not required in head seas with significant wave heights up to 1.5 m.

Auxiliary ship systems powered by the zonal DC grid include two 400-Hz AC powered air-conditioning (A/C) plants and two 400-Hz AC powered, centrifugal, packaged refrigeration plants (one each per side hull), an open-loop fire main system capable of 6,000 liters per minute at 900 kPa pressure, aqueous film-forming foam , high velocity fog, and carbon dioxide agent foam fire suppression systems, and closed loop 21 MPa hydraulic system capable of delivering up to 1,000 liters per minute of hydraulic oil flow to the ship's various hydraulic systems.


Sensors & Processing Systems:
FMG 300/400 Multi-Function Radar (MFR): The SDI FMG 300/400 dual band radar system includes the ships FMG 300 X band Multi-Function Radar (MFR) and FMG 400 C band Volume-Search Radar (VSR). Each radar system consist of four phased-array antennas and associated receiver/exciter (REX) cabinets above deck in the superstructure and a signal and data processor (SDP) system mounted below-decks inside the hull. Both arrays share a central controller and and a common array power system (CAPS) with power conversion units (PCUs) and power distribution units (PDUs) for each radar antenna. Both arrays are cooled using a closed loop, phase change based common array cooling system (CACS). The X band radar system features a larger operating bandwidth and better low-altitude performance and provides surface search, radar navigation, gun-fire targeting and splash spotting, periscope detection, mine detection, precision target tracking and discrimination, limited volume-search, high-bandwidth missile uplink, and terminal illumination of targets while the C band radar provides long range volume search and long-range target tracking capability. Both the The X band and C band radars can provide simultaneous sector search, environmental mapping, counter-fire/counter-battery tracking, missile tracking, electronic warfare, clutter detection, and in-flight missile guidance and communication. Each X band FMG 300 aperture has a 4-meter square antenna with 10,560 transmit and receive (T/R) modules which use gallium nitride complementary metal-oxide semiconductors (CMOS) on a diamond substrate. The C band FMG 400 antennas are significantly larger at 9 square meters and each use 17,680 full-duplex radio integrated circuit transmit and receive (T/R) modules. Each radar antenna features +/- 60° azimuth and +/- 60° degree beam-steering capability giving the system combined 360° azimuth and -2° to + 70°elevation coverage around the warship. Both radar systems employ wide-band digital receiver/exciter (DREX) units and feature digital beam-forming (DBF) capability, space-time adaptive processing (STAP), and multiple-input multiple-output (MIMO) waveform generation techniques. ECCM capabilities of the dual band radar system include frequency-modulated continuous-wave (FMCW) operating modes, ultra-low sidelobes, high processing gain, pulse-to-pulse frequency agility and ultra wide-band frequency hopping, staggered pulse repetition frequency (PRF) switching, randomized burst transmissions, and automatic jammer detection and tracking. The system has am instrumented range of 500 kilometers in air search modes and 80 kilometers in surface search modes and is capable of tracking up to 1,500 simultaneous air and surface targets.

The EOS 400 Staring Infrared Search & Track System: The SDI EOS 400 Staring Infrared Search & Track System is a distributed multi-aperture sensor system which consists of four identical dual field-of-view, electronically stabilized mercury cadmium telluride (HgCdTe) starring focal plane array (FPA) imaging infrared (IIR) sensor units placed in a mast atop the ship's superstructure which provides combined 360°azimuth and -20° to +75° elevation situational awareness infrared search and track (SAIRST) capability against surface vessel, cruise missile, ballistic missile, and aircraft targets to supplement the active search and track capability of the ship's dual band radar system. The 4096 × 4096 pixel (16 MPA) HgCdTe sensor used by each sensor head operates in the MWIR (3–5 µm) band and features a 95 x 95 degree field of view. The image processing features of the EOS 400 system include automatic target recognition (ATR) using an on-board threat library, passive ranging algorithms, multi-target adaptive tracking, and clutter rejection techniques. The video feed from the sensor units can be stitched together and displayed on operator consoles in the ship's bridge and CIC to act as a navigational aid and to provide close in situational awareness for the ship's crew.

FLG 200 Radar & Electro-Optical Fire Control System: For surface and gunfire control the ship is equipped with an SDI FLG 200 combined radar and electro-optical fire control director mounted forward of the superstructure. The FLG 200 contains both a Ku-band (15.5 - 17.5 GHz) solid state radar and an electro-optical suite containing a thermal imager, television camera, and laser rangefinder which is intended to track both surface targets and subsonic and supersonic sea-skimming missiles in close proximity to the vessel and provides sector search capability, missile launch detection and tracking, and own ship gun fire projectile tracking and splash point detection. The Ku-band monopulse radar employs a solid-state Cassegrain antenna connected to a digital receiver and signal processor and transmits with a peak power of 1.5 kW and has a maximum instrumented range of 36 kilometers. The radar is designed with a high level of ECCM features including extremely low sidelobes, high instantaneous bandwidth, and high frequency agility. The electro-optical suite consists of a 1280 x 1024 pixel Midwave IR (3–5 µm) thermal imager with 0.92° to 30.0°horizontal field-of-view and 30x continous optical zoom, 1920 x 1080 pixel CCD daylight television camera with 64x continuous optical zoom, and an Nd:YAG OPO-shifted 1.54 μm eye-safe laser rangefinder with 50m to 40 km range and <1 meter accuracy. The electro-optical system features automatic tracking of up to four simultaneous targets, automatic sector surveillance, simultaneous TV and IR tracking and sensor fusion, recording capability, and integral GPS interferometer system (GPSIS) for far target location (FTL) capability using the system's laser rangefinder to provide 10-digit grid geo-location of surface targets accurate to within 60 meters at ranges up to 40 kilometers. both radar and electro-optical systems are enclosed in a low-RCS triaxially stabilized mounting capable of elevating from -20 to +120° at a rate of 160 °/s and training a full 360° at a rate of 140 °/s.

RMS 230 Hull-Mounted Sonar: For short range detection of submarines and other undersea objects the Centaur class is equipped with an SDI Underwater Systems RMS 230 hull-mounted sonar which provides full 360° detection of submarines, incoming torpedoes, and undersea obstacles around the vessel using a retractable cylindrical transducer unit mounted in the ship's port catamaran hull.The RMS 230 is a mid-frequency sonar which operates from 3.5 to 6.1 kHz in active mode and 2 to 7.1 kHz in passive mode and consists of the hull mounted omnidirectional transducer unit, transceiver Unit 384 separate transmitting and 384 separate receiving channels channels, and shipboard processor cabinet and operating console with color TV display. Active pulse modes supported by the sonar include continuous wave (CW), linear frequency modulated (LFM), hyperbolic frequency modulated (HFM), and combination waveforms with a pulse length of up to 4 seconds. Supported transmission modes include full 360° omindirectional or sector transmissions with 11.5°, 30°, 60°, or 120° azimuth sectors and up to 60° vertical sectors. The sonar also supports bi-static and multi-static operation using the ship's towed sonar, helicopter dipping sonars, and helicopter, ship, and aircraft deployed sonobuoys. The sonar can be used at speeds up to 40 knots and has a maximum detection range against submarine targets of around 20 km.

VTS 240 High-Speed Towed Sonar: For longer range detection of submarines the Centaur class is equipped with an SDI Underwater Systems VTS 240 sonar. The VTS 240 is a lightweight, high speed, combined active/passive variable depth sonar system designed by SDI Underwater Systems for use on small, high speed vessels such as corvettes or fast attack craft. The VTS 240 consists of a high-powered low-frequency active sonar contained in a variable-depth towed body with 15 m to 300 m operating depth and a directional passive towed array along with a ship mounted winch and handling system, transmit Power amplifier, and sonar operator console. The active transmitter operates in the 1.2 to 1.6 khz frequency range with the passive towed array having continuous 100 hz to 2.0 khz detection capability. The system also supports bi-static and multi-static operation with the ship's hull mounted sonar, helicopter dipping sonar, and helicopter, ship, and aircraft deployed sonobuoys. The twin-line transmitter and receive arrays of the SVDS-240 can be towed at speeds of up to 30 knots and provides over-the-horizon detection of submarine size targets out to a range of around 60 km.


Electronic Warfare & Countermeasures:
FMB 300 Electronic Support Measures System: The ship's primary electronic warfare system is the SDI FMB 300 shipboard tactical ESM suite which provides radar warning and combat direction finding against hostile emitters. The FMB 300 employs a split ESM antenna array on either side of the ship's mast with two domes each containing ten multi-arm spiral antennas providing instantaneous 360° detection of radar signals in the 0.5 to 40 GHz range. The system's receivers employ amplitude monopulse direction finding and intra-pulse signal measurement which provides the system with <2° RMS direction finding accuracy and <2 MHz RMS frequency accuracy and has the ability to track up to 500 emitters simultaneously. The system can also perform emitter distance estimation based on pulse amplitude which can be used to fire interceptor missiles at emitting anti-ship missiles and aircraft. Signals received by the ESM system are compared to an onboard threat library which can store up to 20,000 emitter characteristics.

LWG 620 Naval Laser Warning System: For detecting laser sources including laser range finders, laser target designators, and laser beamriding missiles the ship's FMB 300 ESM system is augmented by an SDI LWG 620 Naval Laser Warning System. The LWG 620 consists of a central controller connected four sensor heads, two on each side of the superstructure, providing 360° around the vessel. Each individual sensor head features 110° azimuth and +/- , 70° elevation coverage and is capable of detecting laser range finders laser target designator emissions in the 0.5 μm - 1.65 μm range and laser beamriders in the 0.8 μm - 1.1 μm range.

SDI Sea Guardian Surface Ship Torpedo Countermeasures System: The ship is fitted with the SDI Sea Guardian Surface Ship Torpedo Countermeasure System which combines various soft-kill and hard-kill torpedo countermeasure systems. The Sea Guardian system consists of a towed array sonar designed specifically for torpedo detection, a towed acoustic decoy with a a single-drum winch, an interface to the ship's trainable decoy launchers, and a processing cabinet with two display consoles, and and four 4-round anti-torpedo torpedo launchers on either side of the ship. The towed array sonar used by the system is a combined active and passive array sonar optimized to detect the high frequency sound signature of torpedo screws and active sonar homing heads. The towed array is supported by two vibration isolated modules (VIMs) located on either side of the sonar with the array being connected on one end to the ship using a fiber-optic tow cable and connected on the other end to the towed decoy with an array tow cable. The towed decoy array is designed to emit simulated ship noise such as propulsor and engine noise to lure a passive-sonar homing torpedo to the decoy instead of the ship. The towed decoy can also receive sonar pings from the active homing head of a torpedo and amplifies and returns the "pings" to the torpedo, presenting a larger false target to the torpedo. The hardkill component of the Sea Guardian system comprises a series of four box launchers on either side of the vessel which each contain six SDI S2s Barracuda anti-torpedo torpedoes in individual all-up rounds (AUR) which contain the Barracuda torpedo and a self-contained compressed gas launch system. The Barracuda torpedo is 21 cm in diameter, 2.0 meters in length, weighs 110 kilograms, and contains a 20 kilogram aluminized PBX explosive warhead. The guidance and fusing system of the Barracuda is designed to explode it in front of the oncoming torpedo and create a pressure wave which crushes the nose section of the oncoming torpedo. The Barracuda has a maximum firing range of 10 kilometers and is propelled by an advanced stored chemical energy propulsion system (ADSCEPS) which can propel the Barracuda at speeds up to 60 knots at depths up to 1,000 meters. Although designed as an anti-torpedo the Barracuda can also be used to engage midget submarines, naval mines, and unmanned or autonomous underwater vehicles.

ZTKG 130 Trainable Decoy Launching System (TDLS): The ZTKG 130 Trainable Decoy Launching System (TDLS) is a trainable decoy launcher which can launch a variety of decoys designed to decoy away anti-ship missile and torpedo threats. The ZTKG system onboard the ship consists of a single 12-round trainable countermeasures launcher mounted above the superstructure which controlled by a central command console inside the ship. The 12-round launcher employs a rotating platform with 12 separate 130mm barrels which can each be individually trained in elevation. The ZTKG is designed to use SDI designed 130 mm decoys including the AM5 dual chaff/IR seduction decoy, AM79 Buzzard active missile decoy, and AM7 Lamprey acoustic decoy.

AM5 dual chaff/IR seduction decoy: The primary chaff seduction round employed by the TDLS is the AM5 dual chaff/IR seduction decoy which is capable of defeating dual-seeker missiles equipped with both IR/EO and radar seekers. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.

AM79 Buzzard active missile decoy: For decoying away radar-guided anti-ship missiles the TDLS can deploy the AM79 Buzzard active missile decoy, an expendable electronic-warfare rotary-wing drone which is designed to seduce RF guided anti-ship missiles by simulating the radar return of a large surface vessel. The buzzard features a cylindrical shaped fuselage 130 mm in diameter and 0.9 meters tall with both top and bottom mounted 1.8 meter diameter three-bladed counter-rotating coaxial rotors powered by two brushless DC motors. The rotors unfold from the body of the decoy after launch and fly the decoy into a pre-programmed flight path away from the ship where the decoy then hovers in place while emitting electronic warfare signals uses its fuselage mounted Digital Radio Frequency Memory (DRFM) jammers which are designed to seduce oncoming anti-ship missiles into targeting the decoy and not the host vessel. The decoy is powered by a thermal battery mounted in the center of the fuselage which gives the decoy approximately 60 minutes of flight endurance after launch.

AM7 Lamprey acoustic decoy: The TDLS can also launch the AM7 Lamprey, a 130mm diameter, expendable acoustic decoy designed to counter torpedo threats. After a rocket-powered launch into ocean the Lamprey is programmed to hover vertically using a pressure-controlled motor driving a small, shrouded propeller in the tail of the decoy. The Lamprey is designed to hover at a pre-selected depth from 10-300 meters where it listens for torpedo transmissions. Active acoustic transmissions are detected and analyzed resulting in decoy selectivity and generation of the appropriate deception signal for transmission including target signature and target self noise. If no torpedo transmissions are detected the decoy is programmed to emit warship propulsor and engine noise to lure in passive homing torpedoes. Power for the motor and electronics of the Lamprey is provided by a thermal battery. The Lamprey is programmed to hover and emit noise until the battery dies where the decoy then sinks and all software onboard is erased.


Signature Reduction:
the Centaur class features extensive radar and infrared signature reduction to reduce the ship's detectability to radar and infrared sensors. The hull and superstructure feature a faceted shape with an enclosed mast and sensors suite designed to eliminate corner reflectors and reduce the ship's detectability by radar systems. The composite superstructure of the vessel is fitted with SDI's S-RAM, a type of ballistic grade structural radar absorbing material consisting of 2 cm thick panels made from multiple layers of M5 fibers fibers containing a lossy filler backed by a carbon fiber laminate acting as a reflector. The panels are designed to survive extreme weather exposure and ballistic damage and provides an average -20 dB reflectivity across the 2-40 GHz frequency range (L through Ka bands). The rest of the hull is painted in a radar absorbing paint coating 1 to 5 millimeters thick consisting of lossy dielectric material embedded in a polymer resin which provides -20 dB reflectivity across the 9 -13 GHz range (X band). The infrared signature from the ship's engines is suppressed using an infrared signature suppression system built into the exhaust uptakes. The system consists of a film cooled stainless steel outer duct surrounding a conductively and film cooled stainless steel centerbody and a film cooled stainless steel diffuser which blocks any line of sight view of the heated metal surfaces and reduces uptake metal temperatures to less than 25°C above ambient using ambient air draw into the uptake through a multi-lobed ejector nozzle at the base of the diffuser. The diffuser also contains multiple rings of atomizing nozzles which inject a a fine mist of seawater into the exhaust stream, cooling the exhaust stream to a plume temperature of under 150°C. Seawater injection is controlled by an on board signature management system which interfaces with the ship's propulsion machinery control system and controls the flow of water to the diffuser as a function of engine power.


Passive Protection & Damage Control:
The Centaur class features passive protection in the form of composite armor panels made from M5 ballistic fiber laminated into cured thermoplastic panels which provide ballistic impact and spall protection to the superstructure and vital areas of the ship. The ship's two quadruple RBS 95 missile launchers and the ship's 8.8 cm gun magazine are also encased with welded Ti-6211 titanium alloy plates 30 to 50 mm thick backed by a spall liner consisting of M5 ballistic fibers embedded into an epoxy resin matrix. The ship's blast hardened bulkheads are designed to deform plastically and maintain watertight integrity in the event of an explosion from a bomb or missile warhead inside the ship and feature double-spaced plate construction with an internal fragment resistant membrane designed to stop fragments from penetrating further into the ship. The automatic opening/closing watertight doors in the bulkheads likewise feature a blast hardened membranes structure design with approximately 10 times the blast force resistance of a conventional watertight door.

Damage control is assisted by an SDI Marine Systems developed Automated Ship Control System (ASCS). The ASCS is controlled by a centralized computer which amongst other functions provides real-time damage information to the crew through a graphical display located in the ship's damage control center. Additionally both the ship's bridge and CIC also also fitted with displays connected to the ASCS. The ACSC is designed to run automatically where after the ASCS detects damage to a compartment it will immediately isolate it and activate appropriate damage control measures. Alternatively the ASCS can be set to manual mode where the operator will have to specify the damage control measures after the system detects ship damage. The ASCS also controls and monitors the ship's engines and machinery and will alert engineers on watch duty through their assigned tablet computer when an engineering issue or machinery failure is detected and requires attention. This remove the need for time based maintenance, the system will simply alert the crew when a component or system requires maintenance. Each compartment and each piece of machinery on the ship are monitored using SDI's Two Wire Automatic Remote Sensing Evaluation System (TWARSES) which includes both visible CCD and infrared cameras located in each ship compartment. After damage is detected in a compartment the ASCS can respond in a variety of ways including isolating the damaged compartment by closing the electrically actuated watertight doors around the compartment. If the IR camera detects a fire the system will activate the compartment's overhead sprinklers and can also pump the compartment with aqueous film-forming foam , high velocity fog, and/or carbon dioxide agents if necessary. After the fire is extinguished water and firefighter agents are removed using a bilge draining pump installed in each compartment. The ASCS will also reroute ventilation, electrical power, and water around the damaged area and activate additional pumps, generators and other devices if necessary. If the compartment has been breached and is in danger of flooding the system will flood the compartment with foam which rapidly solidifies and restores reserve buoyancy. This system however is only used as an absolute last resort as it renders the compartment unusable. The ASCS also controls the ship's CBRN protection system by passing air from the ventilation intakes through containment filters before it enters the ship. Air in the ship is maintained at 5.0 millibars above local atmospheric pressure to provide a positive pressure and prevent contaminated air from entering into the ship through a breach in the hull.


Armament:
8.8 cm SK L/78 naval gun: The 8.8 cm SK L/78 naval gun is a fully automated dual purpose naval gun turret system intended for use on small displacement. Developed from an anti-aircraft field gun the 8.8 cm SK L/78 employs a water cooled barrel with a replaceable loose liner and a vertical-sliding breech block which opens downward under the force of recoil. The gun is connected to an automated ammunition supply system containing 80 rounds stored in a carousel beneath the turret. Loading can be achieved at any elevation and the gun has a maximum sustained rate of fire of 120 rounds per minute. The gun fires 88×855R mm single piece ammunition weighing 20.5 kilograms including a 9.4 kilogram projectile. Muzzle velocity is 1,000 m/s and the gun has a maximum range against surface targets of 19,800 meters. The complete gun mount weighs 7,900 kg without ammunition and the capable of training +/- 165° on either side of the ships centerline at a rate of 60°/s and elevating from -15° to +85 degrees at a rate of 60°/s. A shipboard fire control support system is used for control of the gun which plans fire support missions, determines firing solutions and shell trajectories, selects ammunition, and determines the best ship course for executing fire support missions.

S70 Vertical Launch System: The Centaur class is fitted with a total of 48 S70 vertical launch cells divided into six 8-cell modules located on the bow. The S70 is a cold-launch system which uses missiles encased in individual concentric launch cells as modular all-up rounds (AURs) each containing the missile, concentric launch tube, launch tube electronics, and missile ejection system. The S70 8-cell central modules contain 8 launch cells in a 4x2 arrangement with the launch cells inclined at a 10 degree angle towards the ships centerline to prevent missiles with malfunctioning rocket motors from crashing back onto the deck after launch. Each launch cell is capable of accommodating either a single launch tube which can contains missiles with a maximum length of 7.0 meters, diameter of 0.6 meters, and a weight of 2,500 kg. The missiles are ejected from each launch tube using a steam generator system which uses a small solid-propellant gas generator which exhausts through cooling water into the base of each launch cell, creating expanding high pressure steam which then forces the missile out of the launch tube. Safety and passive protection features of each VLS module include concentric anti-fragmentation shields placed around each launch cell tube to prevent in-cell missile fratricide and a deluge system which can flood each 4 or 8 cell module in the event of a missile catching fire in the launch tube. Launch tubes are connected to the launch cells through shock collar that is designed to absorb acceleration loads from an underwater detonation near the ship. The individual missile cells are connected to the ship's weapon control system via redundant port, central, and starboard fiber-optic Ethernet lines which transmits launch commands to the individual missiles and allows for missile status information before launch to be sent back to the weapon control system.

40 cm Torpedo Launch System : For close-in anti-submarine the Centaur is equipped with two twin 40 cm Torpedo Launch Systems, one on each side of the hull for launching SDI F3s Viperfish anti-submarine torpedoes. Each Torpedo Launch System consists of twin fixed shock mounted 40 centimeter torpedo launch tubes, an air charging system, a 12 cell torpedo magazine, and a launcher control station which is connected to the ships' Sea Lance Undersea Combat System. Each F3S Viperfish torpedo is 40 cm diameter, 2.85 meters long lightweight anti-submarine torpedo powered by advanced stored chemical energy propulsion system (ADSCEPS) driven pumpjet propulsor. The torpedo has a maximum speed of 60 knots with a range of 15 km at 60 knots or 25 km at a lower speed of 40 knots. The F3S torpedo is equipped with a fully digital electronically steered 2D phased array active/passive sonar seeker combined with fiber-optic wire guidance. The torpedo is equipped with a 60 kilogram shaped charge warhead designed to penetrate the hulls of large double-hulled submarines.
Last edited by The Technocratic Syndicalists on Fri Jul 24, 2026 8:09 pm, edited 51 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Wed Jun 30, 2021 5:23 pm

Image


Atlas Class

Basic Information:
  • Role: Mine countermeasures vessel
  • Displacement: 1,700 tonnes
  • Complement: 40
  • Length: 80.0 m
  • Beam: 13.0 m
  • Draft: 4.0 m
Propulsion:
  • 2x AMG 16V 23/28 M186 diesel engines, 4,800 kW each
  • 4x AMG 12V 13/15 M24 diesel generators, 750 kWe each
  • 2x 600 kW electric motors
  • 2x 350 kW bow thrusters
  • 2x shafts, 5 bladed controllable pitch propellers

Performance:
  • Top speed: 20 knots
  • Range: 8,000 nmi (14,800 km) at 15 knots
Sensors & Processing Systems:
  • SDI FMG 610 Air & Surface Search Radar
  • SDI Integrated Bridge and Navigation System
  • SDI FLG 200 Radar & Electro-Optical Fire Control System
  • SDI EOS 200 Electro-Optical Surveillance System
  • SDI RMS 150 Hull-Mounted Minehunting Sonar
  • SDI VTS 660 Variable-Depth Minehunting Sonar

Electronic Warfare & Countermeasures:
  • SDI FMB 300 Electronic Support Measures System
  • SDI LWG 620 Naval Laser Warning System
  • 2x SDI TKG 130 130mm countermeasure launchers

Underwater vehicles:
  • 2x SDI Anglerfish autonomous underwater vehicles (AUV)
  • 2x SDI Manta Remotely operated mine neutralization vehicles

Armament:
  • 1x SDI 5.5 cm SK L/78 naval gun
  • 2x 8mm MG-45E machine guns


Overview:
The Atlas is a class of stealth mine countermeasures vessel designed by SDI Shipbuilding Industries. Larger and faster than traditional minesweepers and mine countermeasures vessels the Atlas class can operate in both oceans and coastal waters and features a helicopter deck along with a large mission bay in the stern which can accommodate multiple smaller boats, AUVs/UUVs, and USVs. The Atlas also has a secondary role as an offshore patrol vessel (OPV).


Propulsion
AMG 16V 23/28 M186
  • Type: Marine diesel engine
  • Length: 4,550 mm
  • Width: 1,940 mm
  • Height: 2,930 mm
  • Dry Weight: 20,560 kg
  • Type: 4 stroke
  • Arrangement: 16V
  • Cylinder bore: 230 mm
  • Piston stroke: 280 mm
  • Displacement: 186.1 l
  • Speed: 1,250 rpm
  • Aspiration: sequential turbocharging
  • Rotation: Counterclockwise flywheel
  • Specific fuel consumption: 210 g/kW-hr
  • Output: 4,800 kW
  • Fuel system: Modular common rail (MCRS)

AMG 12V 13/15 M24
  • Type: Marine diesel generator
  • Length: 4,680 mm
  • Width: 2,290 mm
  • Height: 2,340 mm
  • Dry Weight: 7,880 kg
  • Type: 4 stroke
  • Arrangement: 12V
  • Cylinder bore: 130 mm
  • Piston stroke: 150 mm
  • Displacement: 23.9l
  • Speed: 1,800 rpm
  • Aspiration: sequential turbocharging
  • Rotation: Counterclockwise flywheel
  • Specific fuel consumption: 190 g/kW-hr
  • Output: 750 kWe
  • Generator: 4 pole three-phase synchronous generator
  • Fuel system: Modular common rail (MCRS)
[/list]The Atlas class is powered by twin 4.8 MW AMG 16V 23/28 M186 non-magnetic marine diesel engines connected through flexible couplings to twin planetary main reduction gear units which drive two shafts fitted with 2.75 meter diameter controllable pitch propellers. Electrical power is provided by four AMG 12V 13/15 M24 non-magnetic marine generator sets which each provide 750 kWe of 600VAC power. For stationkeeping and low-speed operations the ship uses twin 600 kW non-magnetic light load propulsion motors (LLPMs) to drive the main propeller shafts along with twin 350 kW bow thrusters for precision maneuvering capability.


Sensors & Processing Systems:
FMG 610 Air & Surface Search Radar:For aircraft and surface vessel detection the Atlas class is equipped with an SDI FMG 610 air & surface search radar mounted atop the ship's mast. The FMG 610 is an X band (9.2-9.5 GHz) 2-dimensional solid-state radar system which provides simultaneous air and surface target detection, helicopter guidance, and small/low-RCS target detection at close and medium ranges. The radar has an instrumented range of 180 kilometers with a range resolution of 12 meters and is capable of detecting helicopters and propeller and fixed wing aircraft at ranges up to 30 kilometers and altitudes up to 2,000 meters.

FLG 200 Radar & Electro-Optical Fire Control System: For surface and gunfire control the ship is equipped with an SDI FLG 200 combined radar and electro-optical fire control director mounted atop the superstructure. The FLG 200 contains both a Ku-band (15.5 - 17.5 GHz) solid state radar and an electro-optical suite containing a thermal imager, television camera, and laser rangefinder which is intended to track both surface targets and subsonic and supersonic sea-skimming missiles in close proximity to the vessel and provides sector search capability, missile launch detection and tracking, and own ship gun fire projectile tracking and splash point detection. The Ku-band monopulse radar employs a solid-state Cassegrain antenna connected to a digital receiver and signal processor and transmits with a peak power of 1.5 kW and has a maximum instrumented range of 36 kilometers. The radar is designed with a high level of ECCM features including extremely low sidelobes, high instantaneous bandwidth, and high frequency agility. The electro-optical suite consists of a 1280 x 1024 pixel Midwave IR (3–5 µm) thermal imager with 0.92° to 30.0°horizontal field-of-view and 30x continous optical zoom, 1920 x 1080 pixel CCD daylight television camera with 64x continuous optical zoom, and an Nd:YAG OPO-shifted 1.54 μm eye-safe laser rangefinder with 50m to 40 km range and <1 meter accuracy. The electro-optical system features automatic tracking of up to four simultaneous targets, automatic sector surveillance, simultaneous TV and IR tracking and sensor fusion, recording capability, and integral GPS interferometer system (GPSIS) for far target location (FTL) capability using the system's laser rangefinder to provide 10-digit grid geo-location of surface targets accurate to within 60 meters at ranges up to 40 kilometers. both radar and electro-optical systems are enclosed in a low-RCS triaxially stabilized mounting capable of elevating from -20 to +120° at a rate of 160 °/s and training a full 360° at a rate of 140 °/s.

RMS 150 Hull-Mounted Minehunting Sonar: The SDI Underwater Systems RMS 150 is a retractable hull-mounted triple frequency broadband sonar array designed for minehunting, mine avoidance, and seabed mapping. The complete RMS 150 system consist of both horizontal and vertical sonar antennas, hoisting unit, hydraulic control unit, twin power supply units, a stabilization unit, sonar cabinet, and one or more multi function consoles (MFCs). The sonar's twin arrays operate in three frequency ranges including low frequency (LF), high frequency (HF), and very high frequency (VHF) to provide simultaneous detection and classification of moored and bottom mines in high-clutter environments. Low frequency (100 kHz center frequency, 24 kHz bandwidth) detection with up to 90°horizontal coverage and user selectable 3°, 6°, or 12° vertical beam width is used for long range detection of bottom mines in mud, sand and gravel bottoms, echo detection and depth classification, and volume search for long range 3D detection of mines for mine avoidance. High frequency (200 kHz center frequency, 48 kHz bandwidth) with up to 60° horizontal coverage and 18° vertical beam width is used for medium range detection of bottom mines in mud, sand and gravel bottoms, echo classification of bottom mines, and shadow classification of bottom mines on gravel and rock sea floors. Very high frequency (400 kHz center frequency, 48 kHz bandwidth) is used for short range detection of bottom mines on gravel and rock sea floors and for high resolution echo & shadow classification of bottom mines. Both high frequency and very high frequency sonar can also be used in side-looking mode for route surveys. The sonar can be used at speeds up to 10 knots and retracts into the hull when not in use.

VTS 660 Variable-Depth Minehunting Sonar: The SDI Underwater Systems VTS 660 is a shipboard variable-depth sonar consisting of search and classify sonars integrated into a hydrodynamic towed body which are designed to to detect, classify, and localize stealthy bottom and moored mines in deep-water at safe stand-off ranges of over a kilometer. The complete VTS 660 system consists of the towed body, winch and tow cable, shipboard sonar cabinet, shipboard power supply and distribution unit, and one or more multi function consoles (MFCs). The sonar operates in the LF and VLF frequencies (30-100 Khz) for mine detection and HF and VHF frequencies (300-500 Khz) for mine classification and can operate in multiple operating modes including VLF or LF search and moored mine classification, VLF or LF search and ground mine classification, dual VLF/LF search, and VLF or LF route survey. The towed body is connected to a winch on the ship using an armored fiber-optic cable 300 meters long and can be towed behind the ship at speeds up to 20 knots.


Electronic Warfare & Countermeasures:
FMB 300 Electronic Support Measures System: The ship's primary electronic warfare system is the SDI FMB 300 shipboard tactical ESM suite which provides radar warning and combat direction finding against hostile emitters. The FMB 300 employs a split ESM antenna array on either side of the ship's mast with two domes each containing ten multi-arm spiral antennas providing instantaneous 360° detection of radar signals in the 0.5 to 40 GHz range. The system's receivers employ amplitude monopulse direction finding and intra-pulse signal measurement which provides the system with <2° RMS direction finding accuracy and <2 MHz RMS frequency accuracy and has the ability to track up to 500 emitters simultaneously. The system can also perform emitter distance estimation based on pulse amplitude. Signals received by the ESM system are compared to an onboard threat library which can store up to 20,000 emitter characteristics.

LWG 620 Naval Laser Warning System: For detecting laser sources including laser range finders, laser target designators, and laser beamriding missiles the ship's FMB 300 ESM system is augmented by an LWG 620 Naval Laser Warning System. The LWG 620 consists of a central controller connected four sensor heads, two on each side of the superstructure, providing 360° around the vessel. Each individual sensor head features 110° azimuth and +/- , 70° elevation coverage and is capable of detecting laser range finders laser target designator emissions in the 0.5 μm - 1.65 μm range and laser beamriders in the 0.8 μm - 1.1 μm range.

TKG 130 Decoy Launchers: For self protection against anti-ship missiles the ship is equipped with twin SDI TKG 130 decoy launchers for 130mm chaff and flare countermeasures. One launcher is placed angled outwards on each side of the superstructure and provides forward and side coverage around the vessel. Each launcher has 12 tubes which are aligned in pairs at 10°, 40°, 60°and 135°angles relative to vertical which can be fired individually or in pairs either automatically by the ship's ESM system or manually using a large touchscreen display in the ship's bridge. The launchers are designed to use SDI's AM5 dual chaff/IR seduction decoy is designed to seduce infrared, rada, dual infrared/radar seeker anti-ship missiles. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.


Armament:
SDI 5.5 cm SK L/78 naval gun: For close in defense against surface, airborne, and shore-based targets the Atlas class is equipped with an SDI 5.5 cm SK L/78 naval gun system. The 5.5 cm SK L/78 is an air-cooled, recoil operated automatic cannon which fires 54 ×450R mm ammunition at a rate of 220 rounds per minute. The 5.5 cm SK L/78 gun is housed in a triaxial stabilized low-RCS gunhouse constructed from fiberglass and is capable of traversing a full 360° at a speed of 57 °/sec and is capable of elevating from -10° to +77° at a rate of 44°/sec. The gun includes an on-mount muzzle velocity radar and is designed to fire 2.4 kg programmable air-burst munition (PABM) projectiles at a muzzle velocity of 1,035 m/s out to a maximum firing range of 17 kilometers. The 55 mm PABM round contains 0.46 kg of HMX based polymer bonded explosive (PBX) surrounded by over 8,000 tungsten balls 3mm in diameter and features a multi-mode programmable fuze with six operating modes; proximity, gated proximity, gated proximity with impact priority, timed airburst, impact, and impact plus delay modes. The gun is fitted with a 120 round magazine with another 40 rounds in dual hoists. Ammunition comes to the gunhouse via the hoist where it is loaded into twin 20-round cassettes mounted on a rail behind the gun. Another 840 rounds of 55 mm of ammunition are stored in a magazine beneath the gunhouse giving the gun a total ammunition stowage of 1,000 rounds. Total weight of the 5.5 cm SK L/78 gun is 7,000 kg empty and 14,000 kg with a full load of ammunition
Last edited by The Technocratic Syndicalists on Wed Sep 15, 2021 2:55 pm, edited 30 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Fri Jul 09, 2021 5:54 pm

Image

Monarch Class

Basic Information:
  • Role: Vehicle Cargo Ship
  • Displacement: 671,000 tonnes (full load)
  • Complement: 50
  • Length: 300 m
  • Beam: 36 m
  • Draft: 11.5 m
Propulsion:
  • 4x AMG 20V 45/60 diesel engines, 26.0 MW each
  • 4x AMG 20V 17/21 M95 diesel generators, 2.9 MWe each
  • 2x shafts, 5-bladed controllable pitch propellers

Performance:
  • Top Speed: 33.5 knots
  • Range: 26,000 km @ 33 knots
Sensors:
  • SDI Integrated Bridge and Navigation System

Capacity:
  • 36,500 m2 cargo area, up to 1,000 wheeled or tracked military vehicle


Overview:


Propulsion
AMG 18V 45/60
  • Type: Marine diesel engine
  • Length: 18,750 mm
  • Width: 5,400 mm
  • Height: 7,250 mm
  • Dry Weight: 396,000 kg
  • Type: 4 stroke
  • Arrangement: 20V
  • Cylinder bore: 450 mm
  • Piston stroke: 600 mm
  • Displacement: 2.060 l
  • Speed: 600 rpm
  • Aspiration: Exhaust turbocharger
  • Rotation: Counterclockwise flywheel
  • Specific fuel consumption: 175 g/kW-hr
  • Output: 26,000 kW
  • Fuel system: Modular common rail (MCRS)

The ship is powered by twin AMG 20V 45/60 diesel engines which drive twin propellor shafts with 5-bladed controllable pitch propellers through a pair of double input-single output reduction gear units. The AMG 20V 45/60 engine is an 20 cylinder, 4-stroke medium speed turbocharged marine diesel engine with a 45 cm bore, a 60 cm stroke, ad a total displacement of 2,060 L . The engine has a dry mass of 265 tonnes and provides 21,600 kW of power at its maximum rated speed of 500 RPM. The 20V 45/60 is designed for minimal specific fuel consumption and NOx emissions and features an electronic common rail injection system, a high efficiency constant pressure A axial-flow turbocharger, variable injection timing (VIT) system, and water cooling system with separate high and low temperature cooling water loops. The four 20V 45/60 engines are connected with
hydraulically actuated clutches in pairs to twin AMG twin input-single output reduction gear units with primary and secondary power take-off (PTO) and a combined power take-off/ power take-in (PTO/PTI) connected to a variable speed electric motor/alternator connected to the main switchboard which in PTO mode acts as a shaft alternator and in PTI mode acts as an electric motor for slow steaming. Each reduction gear units drives a propeller shaft with a 5-bladed controllable pitch propeller with hydraulically actuated blade pitch
Last edited by The Technocratic Syndicalists on Mon Jun 29, 2026 4:50 pm, edited 9 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Fri Jul 30, 2021 5:08 pm

Image


CB2030

Basic Information:
  • Role: Combat boat
  • Displacement: 57 tonnes
  • Complement: 8 + 10
  • Length: 24.1 m
  • Beam: 5.2 m
  • Draft: 1.1 m
Propulsion:
  • 2x AMG 16V 13/15 M36 diesel engines, 1,600 kW each
  • 2x waterjets
Performance:
  • Top speed: 45 knots
  • Range: 750 nmi (1,400 km) at 25 knots
Sensors & Processing Systems:
  • SDI FMG 100 X band Surveillance Radar
  • SDI FMG 970 Surface Search & Navigation Radar

Electronic Warfare & Countermeasures:
  • SRS 300 Electronic Support Measures System
  • 2x SDI SKLS-12 130mm countermeasure launchers

Armament:
  • 1x SDI GWS120 twin-barreled 120 mm mortar
  • 1x SDI Scanfire RWS, 1x 8mm MG45E machine gun


Overview:
The SDI CB2030 is a coastal combat vessel optimized for the naval gunfire support mission in littoral and archipelagic environments. The CB2030 is purpose-built to deliver organic, responsive indirect fire support to amphibious landing forces, riverine units, and coastal defense formations operating within contested near-shore waters.


Design & Construction:
The CB2030 hull form is characterized by a sharp entry, high deadrise amidships, and a broad, flat stern section with integrated waterjet tunnels. The hull employs a hard-chine, deep-V planing form with a variable deadrise angle transitioning from approximately 22° at the bow to 12° at the transom. Twin spray rails and a single longitudinal strake per side manage spray and improve dynamic stability at high speed. The transom is designed with integrated waterjet intake tunnels and a retractable bow ramp. The primary hull structure is fabricated from 5083-H321 marine-grade aluminum alloy, used for its superior strength-to-weight ratio, proven corrosion resistance in saltwater environments. The hull plating thickness ranges from 10 mm in high-stress areas (keel, bow sections, engine foundations) to 6 mm in upper-hull side plating, with internal framing provided by extruded 6082-T6 aluminum alloy sections on 400 mm transverse frame spacing. The superstructure above the main deck is constructed from a carbon-fiber-reinforced polymer (CFRP) composite sandwich structure with a PVC foam core. This construction achieves approximately 40% weight savings compared to an equivalent aluminum structure while providing superior radar-absorbing characteristics that contribute to the vessel’s reduced radar cross-section. The composite superstructure is bonded and mechanically fastened to an aluminum coaming at the main deck level, with the joint designed to accommodate differential thermal expansion between the two materials. Critical structural reinforcement is provided at the GWS120 turret ring foundation, which transfers the weapon system’s 4,200 kg static weight and dynamic firing loads into the hull girder through a dedicated ring stiffener and web frame arrangement. The turret foundation is designed to withstand a maximum recoil force of 180 kN per barrel and a combined lateral training torque of 25 kNm without permanent deformation.

The CB2030 incorporates a comprehensive signature reduction philosophy across the radar, infrared, acoustic, and visual spectrum. Topside surfaces are designed with inclined facets at angles of 10–15° from vertical to deflect incident radar energy away from the illuminating source. All external deck fittings, stanchions, and hardware are either enclosed within the composite superstructure or designed with radar-transparent covers. The CFRP superstructure panels incorporate a frequency-selective radar-absorbing material (RAM) layer tuned to common threat radar bands (8–12 GHz), achieving a minimum 10 dB reduction in specular return compared to bare aluminum. The composite radar cross-section is less than 50 m², a substantial reduction for a vessel of its displacement class. For damage control the CB2030 incorporates a zoned damage control philosophy with three principal watertight subdivision zones: the forward zone (bow ramp compartment, bosun’s stores, and chain locker), the midships zone (CIC, accommodation, magazine, turret trunk), and the aft zone (engine room, generator room, steering gear). The vessel is designed to remain afloat and maintain propulsion with any single zone fully flooded. Fixed fire-suppression systems include a seawater fire main with hydrants in each zone, a Halon total-flooding system in the engine room and generator room, and a water-mist system in the magazine and CIC spaces. Portable fire extinguishers and emergency escape breathing devices are distributed throughout the vessel. The magazine is protected by a dedicated blast-venting system and thermal monitoring, with provisions for emergency magazine flooding via a dedicated seawater injection system operable from the bridge.

The crew accommodation is located in the midships zone, comprising a combined wardroom/officers’ cabin for the two assigned officers, a six-berth enlisted quarters, and a ten-berth supplementary quarters for embarked personnel. The accommodation spaces are designed for 48 hour habitability, with individual berths, personal stowage, forced ventilation, and climate control. A combined galley and mess area accommodates meal preparation and communal dining for the full complement, and a single head with shower facility serves the crew. The CIC accommodates four operator consoles: the tactical coordinator/commanding officer station, the weapon system operator station, the radar/sensor operator station, and the communications operator station.


Propulsion
AMG 16V 13/15 M36
  • Type: Marine diesel engine
  • Length: 3,105 mm
  • Width: 1,295 mm
  • Height: 1,390 mm
  • Dry Weight: 4,000 kg
  • Type: 4 stroke
  • Arrangement: 16V
  • Cylinder bore: 135 mm
  • Piston stroke: 156 mm
  • Displacement: 35.7 l
  • Speed: 2,450 rpm
  • Aspiration: sequential turbocharging
  • Rotation: Counterclockwise flywheel
  • Specific fuel consumption: 210 g/kW-hr
  • Output: 1,600 kW
  • Fuel system: Modular common rail (MCRS)
The CB2030 employs a twin-engine, twin-waterjet propulsion setup optimized for high sprint speed, rapid acceleration, and superior maneuverability in confined waters. The propulsion system is designed around marinized high-speed diesel engines coupled to advanced mixed-flow waterjet units through reduction gearboxes with integral power take-off provisions for ship’s services. The primary propulsion power is provided by two AMG 16V 13/15 M36 high-speed marine diesel engines, each delivering a maximum continuous rating (MCR) of 1,600 kW (2,185 bhp) at 2,450 rpm. Each engine is resiliently mounted on a welded aluminum engine foundation through a four-point anti-vibration mounting system designed to attenuate both structure-borne noise and shock loads up to 6g. The engine compartment is located amidships-to-aft, with the engines arranged in a side-by-side configuration on the centerline-offset foundations, separated by a narrow maintenance access passage. Infrared signature management of the exhaust is achieved through a water-cooled exhaust mixing system that entrains ambient air and seawater mist into the diesel exhaust stream before discharge through low-profile outlets along the hull sides at the waterline. Engine compartment ventilation air is ducted through acoustic baffles and exhausted through signature-managed outlets rather than conventional funnel stacks.

Each main engine drives a mixed-flow waterjet unit through a marine reduction gearbox with a 1.75:1 ratio. The waterjets are specifically designed for high-speed military craft and incorporate advanced impeller hydrodynamics with computational fluid dynamics (CFD) optimized blade profiles. The waterjet intakes are flush-mounted in the hull bottom with no appendages extending below the baseline, enabling operations in water depths as shallow as 2.5 meters at reduced speed. Independently steerable jet nozzles provide differential thrust vectoring for tactical maneuvering at high speed without rudder appendage drag. Hydraulically actuated reversing buckets enable crash-stop deceleration from 40 knots to rest in less than three vessel lengths, critical for shoot-and-scoot tactics. The waterjets also eliminate conventional propeller cavitation and shaft-line noise at high speed, reducing the vessels acoustic signature.

The ship’s electrical power is generated by two 100 kW diesel generator sets, each driven by a dedicated auxiliary diesel engine located in a separate generator room aft of the main engine compartment. The generators provide 440V/60Hz three-phase AC power to a split-bus distribution system with automatic bus-tie and load-shedding capability. One generator is sufficient to support all ship’s services and combat systems in a normal operating condition, with the second unit providing redundancy and peak-load capacity during high-demand evolutions such as simultaneous radar transmission, weapon system operation, and high-speed maneuvering. A 24V DC distribution system, fed from static converters and a battery bank, provides backup power for critical navigation, communication, and fire control functions.


Sensors & Processing Systems:
FMG 100 Air & Surface Search Radar:Each CB2030 is equipped with an SDI FMG 100 surveillance radar, an X band (8-10 GHz), digital stacked beam 3D air-surveillance radar which provides three-dimensional, 360° simultaneous air surveillance, surface search, and fire control support functionality within a single rotating antenna assembly The radar employs a fully digital active electronically scanned array (AESA) antenna with a total of approximately 1,500 air-cooled GaN-on-diamond Tx/Rx elements each with integral digitizers and a common digital beamformer. The antenna can be scanned electronically ±60° in both azimuth and elevation from the array boresight. Full 360° azimuth coverage is achieved through mechanical rotation of the turret, with the radar performing a complete hemispheric search scan every 2 seconds during normal operation and a focused sector scan with a revisit rate of 0.5 seconds when cued by external sensors or directed by the fire control system. The radar can simultaneously form up to four independent tracking beams while maintaining search operations. The radar has an instrumented range of 75 kilometers and can detect a 1 m2 RCS target at 40 kilometers and a 0.01 m² RCS target at 15 kilometers in search mode. Track capacity is up to 100 simultaneous tracks with 10 simultaneous precision fire-control quality tracks. The radar’s signal processing architecture is built around a ruggedized, liquid-cooled multi-core digital signal processor delivering 50 TFLOPS of sustained throughput. This processing capacity supports real-time adaptive beamforming, space-time adaptive processing (STAP) for ground clutter suppression during on-the-move operations, and the AI/ML-based automatic target classification engine. The classification engine uses micro-Doppler signature analysis and high range resolution (HRR) profiling to distinguish between threat categories including differentiating small UAS from birds, decoys from actual threats, and manned from unmanned aircraft without requiring external database updates. The FMG 100 radar incorporates a comprehensive electronic counter-countermeasures (ECCM) suite designed to maintain operational effectiveness in dense electronic warfare environments. Key features include wideband instantaneous frequency agility across 2.2 GHz of bandwidth, pulse-to-pulse frequency hopping with over 4,000 agility channels, ultra-low antenna sidelobes (-45 dB peak sidelobe level), sidelobe blanking and cancellation using dedicated auxiliary antennas, and an intelligent power management system that minimizes emissions to the lowest level consistent with the current tactical situation to reduce susceptibility to anti-radiation missile threats. Further active ECCM features of the radar include sidelobe cancellation (SLC), pulse/pulse and burst/burst frequency agility, random PRF switching, and low power frequency modulated continuous wave (FMCW) modes for low probability of intercept/detect (LPD/LPI) operation. An L-band (1 to 2 GHz) Identification Friend or Foe (IFF) antenna is also included in the radar to allow for interrogation of air vehicles, which is also capable of displaying track information on up to 10 prioritized targets on the radar operator's display. The radar provides critical support to the GWS120 fire control system by providing accurate target position data for counter-battery and surface engagement modes. Additionally, the radar’s air surveillance capability provides early warning of inbound air threats, including anti-ship missiles, enabling timely deployment of the decoy system and evasive maneuvering. The radar output is fully integrated with the ship’s combat management system and can contribute track data to joint tactical networks

SDI FMG 970 Surface Search & Navigation Radar: A commercial-grade IMO-compliant SDI FMG 970 X-band navigation radar is installed on a dedicated mast position below the surveillance radar antenna. The navigation radar provides conventional surface navigation, collision avoidance (ARPA), chart overlay, and harbor/coastal piloting functionality. The navigation radar operates independently of the surveillance radar and provides a backup surface search capability in the event of surveillance radar failure or during emissions-controlled (EMCON) operations.


Electronic Warfare & Countermeasures:
FMB 300 Electronic Support Measures System: The ship's primary electronic warfare system is the SDI FMB 300 shipboard tactical ESM suite which provides radar warning and combat direction finding against hostile emitters. The FMB 300 employs a split ESM antenna array on either side of the ship's mast with two domes each containing ten multi-arm spiral antennas providing instantaneous 360° detection of radar signals in the 0.5 to 40 GHz range. The system's receivers employ amplitude monopulse direction finding and intra-pulse signal measurement which provides the system with <2° RMS direction finding accuracy and <2 MHz RMS frequency accuracy and has the ability to track up to 500 emitters simultaneously. The system can also perform emitter distance estimation based on pulse amplitude. Signals received by the ESM system are compared to an onboard threat library which can store up to 20,000 emitter characteristics.

LWG 620 Naval Laser Warning System: For detecting laser sources including laser range finders, laser target designators, and laser beamriding missiles the ship's FMB 300 ESM system is augmented by an SDI LWG 620 Naval Laser Warning System. The LWG 620 consists of a central controller connected four sensor heads, two on each side of the superstructure, providing 360° around the vessel. Each individual sensor head features 110° azimuth and +/- , 70° elevation coverage and is capable of detecting laser range finders laser target designator emissions in the 0.5 μm - 1.65 μm range and laser beamriders in the 0.8 μm - 1.1 μm range.

TKG 130 Decoy Launchers: For self protection against anti-ship missiles the ship is equipped with twin SDI TKG 130 decoy launchers for 130mm chaff and flare countermeasures. One launcher is placed angled outwards on each side of the superstructure and provides forward and side coverage around the vessel. Each launcher has 12 tubes which are aligned in pairs at 10°, 40°, 60°and 135°angles relative to vertical which can be fired individually or in pairs either automatically by the ship's ESM system or manually using a large touchscreen display in the ship's bridge. The launchers are designed to use SDI's AM5 dual chaff/IR seduction decoy is designed to seduce infrared, radar, dual infrared/radar seeker anti-ship missiles. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.


Armament:
GWS120
  • Type: Automatic Mortar
  • Caliber: 120 mm
  • Barrel Length: 3,000 mm (L/25)
  • Traverse: 360°continuous
  • Traverse rate: 60°/sec
  • Elevation: -3° to +85°
  • Elevation rate: 40°/sec
  • Rate of fire:: 24 rounds/min
  • Above-deck turret weight: 4,200 kg
  • Below-deck system weight: 2,800 kg
  • Stabilization: Two-axis gyro, ±15° roll, ±8° pitch compensation
The primary armament of the CB2030 is SDI's GWS120 automatic mortar system, a double barreled, breach loading, smoothbore mortar system housed in an unmanned turret at the front of the vessel. The weapon fires standard smoothbore 12 cm mortar projectiles modified with a short stub case which acts to seal the breach during firing. Each barrel is 25 calibers (3 meters) long and features an electro-deposited hard chrome plating along its entire length to reduce wear. Each barrel is contained in an independently recoiling hydro-pneumatic sleeve which allows both barrels to be fired independently. Each tube employs a semi-automatic breech mechanism with a vertically sliding wedge breech mechanism. Positive obturation is provided by small stub case attached to the base of each projectile which is automatically ejected after firing. Each breech mechanism includes an integral pulsed neodymium: ytterbium aluminum garnet (Nd:YAG) laser which is used to ignite the propellent attached to each projectile. After firing a 50-50 EGW (ethylene-glycol water) antifreeze mixture is sprayed into the chamber to extinguish residual propellant embers, clean the laser window, wet the breech seal, and to prevent ammunition cook-off by cooling the walls of the chamber.

The GWS120 mortar system includes a autoloader system with three fully automated carousel style projectile magazines. Two magazines each containing 24 fuzed projectiles with attached propellant charges are towed horizontally in closed-loop conveyors are are located inside the turret bustle with an additional magazine containing 32 fuzed projectiles with attached propellant charges stowed vertically in the hull underneath the turret. When a specific projectile is selected for a firing mission one of the bustle magazines is rotated so that the correct projectile moves to the center of the magazine where it can be exacted by a shuttle which grips the base of the projectile and extracts it from the magazine. The shuttle then moves the projectile to the center of the bustle between the two magazines where the projectile is transferred onto one of two robotic loading arms (one for each barrel). The shuttle includes an inductive fuze setter mechanism which automatically programs the projectile fuze as the projectile is transferred from the magazine to the robotic loading arm. While the projectile is on the robotic loading arm the human loader is responsible for setting the correct propellant charge increment. The robotic loading arm then rotates to align with the elevation of the gun tube where a pneumatically driven flick rammer then rams the projectile into the breech to be fired. Once the bustle ammunition supply is exhausted the weapon will feed from hull magazine which includes an additional projectile shuttle which extracts projectiles from the hull magazine and then rotates them to along with the angle of the turret before the projectile is transferred onto one of the robotic loading arms. The autoloader mechanism allows for a firing rate of up to 24 rounds per minute at any turret elevation or traverse angle with minimal physical intervention by the crew.

The GWS120 fire control system is a fully digitized solution integrating the weapon’s organic sensors with the ship’s combat management system and external data links. The system computes ballistic solutions using a real-time six-degree-of-freedom trajectory model that accounts for vessel motion (roll, pitch, heave, heading), wind speed and direction, air temperature and pressure, barrel wear, and muzzle velocity measurements from an onboard Doppler radar. Target designation can be received from multiple sources including the ship’s own surveillance radar, embarked forward observers via secure tactical radio, external fire coordination networks, and manual input by the weapon operator. The fire control system supports indirect fire with computed ballistic solutions at ranges from 500 m to maximum range; direct fire using a coaxial electro-optical/infrared sight for engagement of visible surface targets at ranges up to 2 km, MRSI mode, and coordinated fire mode, in which the CB2030’s fire control system synchronizes with other vessels to deliver massed fires on a single target. The GWS120 fire control system supports a Multiple Rounds Simultaneous Impact (MRSI) mode, which exploits the system’s high rate of fire and ability to rapidly change barrel elevation between shots to launch multiple rounds on different ballistic trajectories timed to arrive at the target simultaneously. The dual-barrel configuration enables the system to deliver up to eight rounds (four per barrel) on target within a two-second window. The MRSI firing sequence is computed entirely within the digital fire control system, which calculates the required series of elevation angles and precise firing times for each barrel. The operator need only designate the target coordinates, select the MRSI mode, and authorize the engagement. The system will then autonomously execute the firing sequence, adjust for real time vessel motion via the stabilization system, and apply corrections from the muzzle velocity radar to each subsequent round.

Scanfire RWS: The CB2030 is fitted with an SDI Scanfire remotely operated weapon station on the superstructure roof, providing close-range self-defense and surface engagement capability. The Scanfire weighs 140 kg and and includes an electro-optical sensor suite with a daylight CCD camera, uncooled 640 x 480 pixel LWIR (long wave infrared) infrared imager, and eye-safe Nd:YAG laser rangefinder along with an MG 45E machine gun and an ammunition box containing 1,000 rounds of 8x57 mm ammunition. The Scanfire features dual-axis gyro-stabilization and 360° traverse at 90 °/s and -20° to +70° elevation at 60°/s using brushless DC servomotors. In addition to the MG 45E the Scanfire can mount other machine guns from 7.62 mm to 12.7 mm caliber or 40mm automatic grenade launchers. Ammunition capacity is 1,000 rounds for 7.62mm machine guns, 500 rounds for 12.7 mm machine guns, and 60 rounds for 40mm automatic grenade launchers. The RWS is operated from a dedicated console within the combat information center (CIC) and can also be controlled from the bridge station. The system’s electro-optical sensor suite provides an independent surveillance and target identification capability complementary to the ship’s radar. The RWS is intended primarily for self-defense against fast inshore attack craft, engagement of small surface targets of opportunity, and suppressive fire during close quarters transit through contested waterways.
Last edited by The Technocratic Syndicalists on Thu Jun 04, 2026 8:47 am, edited 7 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Sun Aug 15, 2021 3:59 pm

Image


Siegfried Class

Basic Information:
  • Type: Guided missile cruiser
  • Displacement: 25,700 tonnes
  • Complement: 300
  • Length: 255 m
  • Beam: 37 m
  • Draft: 8.5 m

Propulsion:
  • 2x SDI6000 gas turbines, 45 MW each
  • 2x AMG 20V 32/44 M708 diesel engines, 12.0 MW each
  • 6x AMG 9L 32/44 M319 diesel generators, 5.2 MW each
  • 1x retractable bow-mounted azimuth thruster
  • 4x shafts, 4x waterjet thrusters

Performance:
  • Top Speed: 35 knots
  • Range:19,000 km at 20 knots
Sensors and Processing Systems:
  • SDI Typhoon Combat System
  • SDI FMG 300 X band Multi-Function Radar (MFR)
  • SDI FMG 600 S band Volume-Search Radar (VSR)
  • SDI Integrated Bridge and Navigation System
  • SDI EOS 400 Staring Infrared Search & Track System
  • SDI FLG 200 Radar & Electro-Optical Fire Control Director
  • SDI Sea Lance Undersea Combat System
  • SDI RMS 800 Hull-mounted mid-frequency sonar
  • SDI RMS 810 Hull-mounted high-frequency sonar
  • SDI VTS 830 Variable-depth sonar

Electronic Warfare and Countermeasures:
  • SDI FMS 1800 Electronic Warfare System
  • SDI LWG 310 Naval Laser Warning System
  • SDI ZTKG 130 Trainable Decoy Launching System (TDLS)
  • SDI Sea Guardian Surface Ship Torpedo Countermeasure System

Armament:
  • 256x S70 Modular Launch System cells
  • 2x 40mm Medium-Caliber Gun System (MCGS) turrets
  • 2x triple 400 mm Surface Vessel Torpedo Tube (SVTT) launchers
  • 2x 20.3 cm SK L/60 Naval Guns

Aircraft Carried:
Last edited by The Technocratic Syndicalists on Wed Sep 15, 2021 2:56 pm, edited 1 time in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Sat Apr 01, 2023 6:35 pm

Image

LCA 16

Basic Information:
  • Type: Landing craft
  • Displacement: 17.5 t
  • Complement: 2+35
  • Length: 16.0 m
  • Beam: 4.2 m
  • Draft: 0.7 m

Propulsion:
  • 2x AMG 8V 13/15 M16 diesel engines, 850 kW each
  • 2x shafts, 2x waterjets

Performance:
  • Top Speed: 45 knots light, 35 knots fully loaded
  • Range: 400 km at 35 knots
Sensors:
  • SDI FMG 830 X band navigation radar
Armament:

  • 2x MG 45E machine guns


Overview:
The LCA 16 is a high speed landing craft and coastal troop transport designed by SDI Marine Systems. The LCA 16 is designed for high speed marine landing operations in littoral and coastal waters and can carry up to 35 soldiers with their equipment or up to 8 tonnes of payload inside a covered troop compartment and is powered by twin waterjets allowing the craft to reach speeds of up to 40 knots. The LCA 16 are primarily used with SDI Marine System's Fervent class landing platform docks are are fitted with a quick release hoisting mechanism which enables the vessels to be hoisted using the davit's of the Fervent class LPD.


Design & Construction:
The LCA 16 features a chined mono v-hull construction constructed from welded aluminum-magnesium alloy which is divided longitudinally into five watertight compartments. The vessels low loaded draft of under 1 meter is designed to allow operations on shallow landing beaches and in river and estuary environments. The deckhouse superstructure is located atop of the engine room and is constructed from fiberglass and graphite reinforced polymer (GRP) composite to reduce the boats center of gravity and is attached to the aluminum hull with bolts and a mounted system which allows the entire deckhouse to be removed from the hull to access the engines. Forward of the deckhouse is the cargo hold/passenger compartment which is covered with a fiberglass/GRP weather shelter and fitted with 35 folding and shock absorbing seats along with a a toilet and shower connected to a freshwater system. A hydraulically operated bow ramp and two hatches at the front of the vessel are designed to allow fast loading/unloading of the cargo and personnel. Both the deckhouse and cargo hold are equipped with ballistic protection in form of armor panels contracted from cross-plied M5 ballistic fibers laminated into a flexible thermoplastic resin which provide protection against 7.62 ammunition and shell splinters. Both the deckhouse and cargo compartment also feature CBRN overpressure and air filtration systems.


Propulsion
AMG 8V 13/15 M16
  • Type:Diesel engine
  • Length: 1,570 mm
  • Width: 1,270 mm
  • Height: 1,210 mm
  • Dry Weight: 1,750 kg
  • Type: 4 stroke
  • Arrangement: 8, V, 90°
  • Cylinder bore: 130 mm
  • Piston stroke: 150 mm
  • Displacement: 16.4 l
  • Speed: 2,300 rpm
  • Aspiration: sequential turbocharging
  • Rotation: Counterclockwise flywheel
  • Specific fuel consumption: 190 g/kW-hr
  • Output: 850 kW
  • Fuel system: Modular common rail (MCRS)
The LCA 16 is powered by twin AMG 8V 13/15 M16 diesel engines which drive two SDI Marine Systems SS45 waterjet thrusters through AZF 660 gear reduction units. The AMG 8V 13/15 M16 is a 4-stroke V8 fuel-injected turbocharged marine diesel engine with a 13 centimeter bore, 15 centimeter stroke, and 16.4 liter displacement and has a maximum mechanical power output of 850 kW at its maximum rated speed of 2,300 rpm. The engine employs sequential turbocharging with twin water-cooled turbochargers with an engine coolant temperature-controlled intercooler. The engines drive two SDI Marine Systems SS45 axial-flow thrust-vectoring and reversing waterjet propulsors which give the vessel a maximum speed of 45 knots unloaded and 35 knots fully loaded. The vessel normally carries 2,000 liters of diesel fuel onboard which provides for a cruising range of over 200 nautical miles at full load. The thrust-vectoring and reversing capability of the waterjet thrusters gives the vessel excellent maneuverability and allows the boat to be stopped within one boat length from full ahead. Control of the waterjet propulsion system is via an SDI Marine Systems drive-by-wire electronic propulsion control system which provides electronic control of both the diesel engines and waterjet thrusters to provide highly responsive interceptor steering along with auto positioning, auto heading, and anchor point capability through an interface to the vessel's GPS and gyrocompass navigation systems. Auxiliary electric power is provided by a 10.0 kw diesel generator unit which provides 230V, 50Hz AC power the the vessel's electric system.
Last edited by The Technocratic Syndicalists on Sun Apr 02, 2023 11:15 am, edited 2 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Tue Apr 04, 2023 7:15 pm

Image

Onager class

Basic Information:
  • Type: Tank landing ship
  • Displacement: 7,200 t (full load)
  • Complement: 18 crew + 40 additional personnel + 390 troops
  • Length: 130 m
  • Beam: 19.5 m
  • Draft: 2.5-4.0 m
Propulsion:
  • 2x AMG 16V 17/19 M70 diesel engines, 3.5 MW each
  • 2x shafts, 2x controllable pitch ducted propellers
  • 2x 300 kW bow thrusters

Performance:
  • Top speed : 18 knots
  • Range: 17,000 km at 15 knots
Sensors & Processing Systems::
  • SDI FMG 830 X band navigation radar
  • SDI Integrated Bridge and Navigation System
Electronic Warfare & Countermeasures:
  • SDI FMB 300 Electronic Support Measures System
  • SDI LWG 620 Naval Laser Warning System
  • 2x SDI TKG 130 130mm countermeasure launchers

Cargo Capacity:
Armament:
  • 1x 5.5 cm SK L/78 naval gun
  • 2x 8mm MG-45E machine guns
Boats & landing craft carried:


Overview:
The Onager class is a class of tank landing ship (LST) designed by SDI Marine Systems. The LST 130 is a large, multipurpose roll-on/roll-off (ro-ro) landing ship designed designed to land tanks, vehicles, and supplies onto beaches or wharfs.


Design & Construction:
The Onager class vessels have a length of 130 meters, maximum beam of 19.5 meters, and a draft of 2.5 meters forward and 4.0 meters aft. The ship's displace 7,200 tones at full load with a payload carrying capacity of 1,200 tonnes on both enclosed and open decks. The ships features a double hull construction made from welded St 92 (900 MPa yield strength) high-strength structural shipbuilding steel divided into 17 longitudinal watertight compartments. The ship features roll-on/roll-off (ro-ro) capability and is equipped with both bow and stern doors and ramps along with an internal ramp that leads to the upper vehicle deck. The bow and stern ramps are rated at up to 80 tonnes capable with the internal ramp connecting the tank and vehicle decks rated at 40 tonnes. The main tank deck has an area of 1,100 square meters and can carry up to 18 PzKpfw 151 main battle tanks or up to 34 AKpfw 903 reconnaissance vehicles or KfZ 310 all-terrain tracked carriers while the open upper vehicle deck has a parking area of 700 square meters can accommodate an additional 10 AKpfw 903 or KfZ 310 vehicles. The upper vehicle deck also carries four davits on the vehicle deck for LCA 16 landing craft. The large superstructure is located at the aft of the vessel and carried berths for 18 crew along with berths for up to 40 additional personnel. Rear of the superstructure is a helicopter landing pad which can accommodate a single TH 90 or other medium lift helicopter.


Propulsion:
SDI 16V 17/19 M70
  • Type:Diesel engine
  • Length: 3.480 m
  • Width: 1.465 m
  • Height: 2.445 m
  • Dry Weight: 9,600 kg
  • Type: 4 stroke
  • Arrangement: 16V
  • Cylinder bore: 170 mm
  • Piston stroke: 190 mm
  • Displacement: 70.0 l
  • Speed: 2100 rpm
  • Aspiration: sequential turbocharging
  • Rotation: Counterclockwise flywheel
  • Specific fuel consumption: 210 g/kW-hr
  • Output: 3,500 kW
  • Fuel system: Modular common rail (MCRS)
The Onager is powered by a total of two AMG 16V 17/19 M86 diesel engines driving two ducted controllable pitch propellers through twin engine mounted KF 1100 gear reduction units. The AMG 16V 17/19 M86 is a 4-stroke V16 fuel-injected turbocharged marine diesel engine with a 17 centimeter bore, 19 centimeter stroke, and 70.0 liter displacement and has a maximum mechanical power output of 3,500 kW at its maximum rated speed of 2,100 rpm. The engine employs sequential turbocharging with twin water-cooled turbochargers with an engine coolant temperature-controlled intercooler. The diesel engines are coupled to two engine mounted gear reduction units which drive two four bladed controllable pitch propellers surrounded by high efficiency nozzles. The diesel engines give the vessel a top speed of 18 knots with a cruising range of over 9,000 nautical miles at a speed of 14 knots. Electrical power is provided by three 600 kWe AMG 12V 13/115 diesel generators which each provide 230 VAC/750 kVA/50 Hz to the ship's zonal AC electrical system.


Electronic Warfare & Countermeasures:
FMB 300 Electronic Support Measures System: The ship's primary electronic warfare system is the SDI FMB 300 shipboard tactical ESM suite which provides radar warning and combat direction finding against hostile emitters. The FMB 300 employs a split ESM antenna array on either side of the ship's mast with two domes each containing ten multi-arm spiral antennas providing instantaneous 360° detection of radar signals in the 0.5 to 40 GHz range. The system's receivers employ amplitude monopulse direction finding and intra-pulse signal measurement which provides the system with <2° RMS direction finding accuracy and <2 MHz RMS frequency accuracy and has the ability to track up to 500 emitters simultaneously. The system can also perform emitter distance estimation based on pulse amplitude. Signals received by the ESM system are compared to an onboard threat library which can store up to 20,000 emitter characteristics.

LWG 620 Naval Laser Warning System: For detecting laser sources including laser range finders, laser target designators, and laser beamriding missiles the ship's FMB 300 ESM system is augmented by an LWG 620 Naval Laser Warning System. The LWG 620 consists of a central controller connected four sensor heads, two on each side of the superstructure, providing 360° around the vessel. Each individual sensor head features 110° azimuth and +/- , 70° elevation coverage and is capable of detecting laser range finders laser target designator emissions in the 0.5 μm - 1.65 μm range and laser beamriders in the 0.8 μm - 1.1 μm range.

TKG 130 Decoy Launchers: For self protection against anti-ship missiles the ship is equipped with twin SDI TKG 130 decoy launchers for 130mm chaff and flare countermeasures. One launcher is placed angled outwards on each side of the superstructure and provides forward and side coverage around the vessel. Each launcher has 12 tubes which are aligned in pairs at 10°, 40°, 60°and 135°angles relative to vertical which can be fired individually or in pairs either automatically by the ship's ESM system or manually using a large touchscreen display in the ship's bridge. The launchers are designed to use SDI's AM5 dual chaff/IR seduction decoy is designed to seduce infrared, rada, dual infrared/radar seeker anti-ship missiles. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.


Signature Reduction:
The Onager class features extensive radar and infrared signature reduction to reduce the ship's detectability and vulnerability to anti-ship missile threats. The hull and superstructure feature a faceted shape which is designed to eliminate corner reflectors and reduce the ship's detectability by radar systems. The forward and side superstructure of the vessel is fitted with SDI's S-RAM, a type of ballistic grade structural radar absorbing material consisting of 2 cm thick panels made from multiple layers of M5 fibers fibers containing a lossy filler backed by a carbon fiber laminate acting as a reflector. The panels are designed to survive extreme weather exposure and ballistic damage and provides an average -20 dB reflectivity across the 2-40 GHz frequency range (L through Ka bands). The rest of the hull and superstructure is painted in a radar absorbing paint coating 1 to 5 millimeters thick consisting of lossy dielectric material embedded in a polymer resin which provides -20 dB reflectivity across the 9 -13 GHz range (X band). The infrared signature from the ship's engines is suppressed using an infrared signature suppression system built into the exhaust uptakes. The system consists of a film cooled stainless steel outer duct surrounding a conductively and film cooled stainless steel centerbody and a film cooled stainless steel diffuser which blocks any line of sight view of the heated metal surfaces and reduces uptake metal temperatures to less than 25°C above ambient using ambient air draw into the uptake through a multi-lobed ejector nozzle at the base of the diffuser. The diffuser also contains multiple rings of atomizing nozzles which inject a a fine mist of seawater into the exhaust stream, cooling the exhaust stream to a plume temperature of under 150°C. Seawater injection is controlled by an on board signature management system which interfaces with the ship's propulsion machinery control system and controls the flow of water as a function of the engine power.

The magnetic signature of the vessel is reduced by SDI's High Temperature Superconducting Degaussing System (HTSDS) which is designed to reduce the vessel's magnetic signature. The superconducting system provides an over 95% reduction in the ship's magnetic signature with a total weight 80% less than a conventional copper cable based system singicnalty reducing the vulnerability the ship to magnetic mine threats. The degaussing system components include a control unit, power modules, junction boxes, cryo coolers, accumulation tanks, high temperature degaussing cable assemblies, and cryogenic cold gas lines used to cool the degaussing cable assemblies. The system uses three separate loops of independently controlled degaussing coils arranged in three axes which are designed to counteract the ship's magnetic signature in the vertical, longitudinal and athwartship planes. Each coil loop is connected to an independent power module connected to the ship's zonal DC power distribution system which energizes the coil with up to 3,000 Amps of current at voltages of up to 138 kV. The cable assemblies consists of a hollow bismuth strontium calcium copper oxide (BSCCO) high temperature superconducting cable wrapped around a hollow support tube and supported by a flexible cyrostat consisting of a layer of inner corrugated stainless steel tubing, a layer of multi layer insulation (MLI), a polymer support layer, a vacuum space, an outer layer of corrugated stainless steel tubing, and an outer cable sheathing. The cooling loop for each cable includes a cryogenic refrigerator, a seawater heat exchanger, and a circulation pump which pumps gaseous helium through the cryostat and hollow support tube to maintains cable temperature at 55° K. The entire HTSDS is controlled from a central degaussing control unit (DCU) which receives magnetic field data either from both a shipboard triaxial magnetic probe system and from a magnetic geophysical model which takes data from the ship's navigation system and automatically calculates the required current for each degaussing coil to cancel out the ship's magnetic signature.


Passive Protection & Damage Control:
The Onager class features passive armor protection in the form of several dozen tonnes of composite armor panels made from M5 ballistic fiber laminated into cured thermoplastic panels which provide ballistic impact and spall protection to the superstructure and vital areas of the ship. The ship's blast hardened bulkheads are designed to deform plastically and maintain watertight integrity in the event of an explosion from a bomb or missile warhead inside the ship and feature double-spaced plate construction with an internal fragment resistant membrane designed to stop fragments from penetrating further into the ship. The automatic opening/closing watertight doors in the bulkheads likewise feature a blast hardened membranes structure design with approximately 10 times the blast force resistance of a conventional watertight door.

Damage control is assisted by an SDI Marine Systems developed Automated Ship Control System (ASCS). The ASCS is controlled by a centralized computer which amongst other functions provides real-time damage information to the crew through a graphical display located in the ship's damage control center. Additionally both the ship's bridge and CIC also also fitted with displays connected to the ASCS. The ACSC is designed to run automatically where after the ASCS detects damage to a compartment it will immediately isolate it and activate appropriate damage control measures. Alternatively the ASCS can be set to manual mode where the operator will have to specify the damage control measures after the system detects ship damage. The ASCS also controls and monitors the ship's engines and machinery and will alert engineers on watch duty through their assigned tablet computer when an engineering issue or machinery failure is detected and requires attention. This remove the need for time based maintenance, the system will simply alert the crew when a component or system requires maintenance. Each compartment and each piece of machinery on the ship are monitored using SDI's Two Wire Automatic Remote Sensing Evaluation System (TWARSES) which includes both visible CCD and infrared cameras located in each ship compartment. After damage is detected in a compartment the ASCS can respond in a variety of ways including isolating the damaged compartment by closing the electrically actuated watertight doors around the compartment. If the IR camera detects a fire the system will activate the compartment's overhead sprinklers and can also pump the compartment with aqueous film-forming foam , high velocity fog, and/or carbon dioxide agents if necessary. After the fire is extinguished water and firefighter agents are removed using a bilge draining pump installed in each compartment. The ASCS will also reroute ventilation, electrical power, and water around the damaged area and activate additional pumps, generators and other devices if necessary. If the compartment has been breached and is in danger of flooding the system will flood the compartment with foam which rapidly solidifies and restores reserve buoyancy. This system however is only used as an absolute last resort as it renders the compartment unusable. The ASCS also controls the ship's CBRN protection system by passing air from the ventilation intakes through containment filters before it enters the ship. Air in the ship is maintained at 5.0 millibars above local atmospheric pressure to provide a positive pressure and prevent contaminated air from entering into the ship through a breach in the hull.


Armament:
SDI 5.5 cm SK L/78 naval gun: For close in defense against surface, airborne, and shore-based targets the Onager class is equipped with an SDI 5.5 cm SK L/78 naval gun system. The 5.5 cm SK L/78 is an air-cooled, recoil operated automatic cannon which fires 54 ×450R mm ammunition at a rate of 220 rounds per minute. The 5.5 cm SK L/78 gun is housed in a triaxial stabilized low-RCS gunhouse constructed from fiberglass and is capable of traversing a full 360° at a speed of 57 °/sec and is capable of elevating from -10° to +77° at a rate of 44°/sec. The gun includes an on-mount muzzle velocity radar and is designed to fire 2.4 kg programmable air-burst munition (PABM) projectiles at a muzzle velocity of 1,035 m/s out to a maximum firing range of 17 kilometers. The 55 mm PABM round contains 0.46 kg of HMX based polymer bonded explosive (PBX) surrounded by over 8,000 tungsten balls 3mm in diameter and features a multi-mode programmable fuze with six operating modes; proximity, gated proximity, gated proximity with impact priority, timed airburst, impact, and impact plus delay modes. The gun is fitted with a 120 round magazine with another 40 rounds in dual hoists. Ammunition comes to the gunhouse via the hoist where it is loaded into twin 20-round cassettes mounted on a rail behind the gun. Another 840 rounds of 55 mm of ammunition are stored in a magazine beneath the gunhouse giving the gun a total ammunition stowage of 1,000 rounds. Total weight of the 5.5 cm SK L/78 gun is 7,000 kg empty and 14,000 kg with a full load of ammunition
Last edited by The Technocratic Syndicalists on Sat Apr 15, 2023 6:40 pm, edited 5 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Fri Apr 07, 2023 8:06 pm

Image

Basilisk Class

Basic Information:
  • Role: Surface Effect Ship Carrier
  • Displacement: 55,000 t
  • Complement: 400 crew + 600 air wing
  • Length: 275 m
  • Beam: 87.5 m
  • Draft: 3.5 m (on cushion), 11.5 m (off-cushion)
Propulsion:
  • 8x SDI/AEG AGR1500 nuclear gas turbine generators, 150 MWe each
  • 8x AEG high temperature superconducting (HTS) AC Motors, 100 MW each
  • 8x SDI SS325 Waterjet thrusters,100 MW each

Performance:
  • Top Speed: 100 knots
  • Range: unlimited
Sensors:
  • SDI Typhoon Combat System
  • SDI FMG 300 X band Multi-Function Radar (MFR)
  • SDI SDI FMG 400 C band Volume Search Radar (VSR)
  • SDI Integrated Bridge and Navigation System
  • SDI EOS 400 Staring Infrared Search & Track System
  • SDI FMG 460 Naval Precision Approach Radar
  • SDI Electro-Optical Landing System
  • SDI Electro-Optical Aircraft Tracking System

Countermeasures:
  • SDI FMS 1800 Electronic Warfare System
  • SDI LWG 620 Naval Laser Warning System
  • SDI ZTKG 130 Trainable Decoy Launching System (TDLS)
  • SDI Surface Ship Torpedo Countermeasure (SSTC) System
Armament:
Aircraft Carried:
  • Up to 50 aircraft and helicopters
    Typical Air Wing:
    Aviation Facilities
    • 4x elevators
    • below deck aircraft hangar


Overview:
The Basilisk class is a class of high speed nuclear powered surface effect aircraft carriers designed by SDI Marine Systems. The Basilisk is designed to complement SDI's larger nuclear powered Inflictor class carriers by providing a high speed aircraft carrier that can operate as the centerpiece of a high-speed task force escorted by surface-effect combatants,


Design & Construction:
The Basilisk class vessels have a length of 275 meters, beam of 87.5 meters, and a full load displacement of approximately 55,000 tonnes. The hull is constructed primarily from welded Ti-5111 (Ti-5Al-1Sn-1Zr-1V-0.8Mo) marine grade titanium alloy, used for it's superior strength-to-weight ratio compared to conventional shipbuilding steels and aluminum alloys and it's excellent corrosion performance being essentially immune to seawater corrosion, eliminating the need for the extensive cathodic protection systems, anti-corrosion coatings, and periodic inspections. The ship employs twin longitudinally framed sidehulls connected by a transverse cross-structure supporting the hangar deck, flight deck, and superstructure. The hull has an angular, faceted shape designed to minimize both aero-hydrodynamic drag and radar cross section and includes both hard chines and spray rails to to minimize wave spray at high speeds. The sidehulls are watertight, longitudinally framed structures extending the full length of the ship and houses the reactor compartments, waterjet propulsor rooms, lift-fan machinery spaces, magazine spaces, and aviation fuel storage. Full keel-length fences are integral with the lower sidehulls. The wet deck spanning between the sidehulls forms the cushion ceiling and the structural floor of the hangar deck and is the most heavily loaded panel structure in the ship, designed to withstand combined cushion pressure, wave slam impacts, and the distributed loads of aircraft, ordnance, and support equipment in the hangar above. Wet-deck panel thicknesses range from 10 mm in protected areas to 20 mm in the forward slam-critical zone, with longitudinal T-stiffeners at 180 mm spacing and transverse web frames at 700 mm spacing.

The hull is divided into approximately 1,400 watertight compartments below the hangar deck by a system of transversely mounted hock resistant, blast hardened bulkheads intended to maintain structural integrity in the event of a large internal explosion inside the vessel, mounted at 10.0 meter spacing and longitudinal bulkheads within each sidehull. The compartmentation provides three compartment damage stability compliance to naval vessel survivability standards. The magazine and reactor spaces are protected by armored box structures using titanium plate of increased thickness (40 to 50 mm) backed by Kevlar spall liners. The flight deck is a Ti-5111 plate-and-stiffener structure designed for the dynamic landing loads of all embarked aircraft types amplified by the on-cushion motion environment. Non skid coatings are applied directly to the titanium flight deck surface. Jet-blast deflectors are installed behind each EMALS catapult shuttle. The ship's hangar is 130 by 21 meters with a height of 6.0 meters and is designed to hold up to 50 aircraft and helicopters. Access from the hangar to the 245 by 36 meter flight deck is via four 25 by 15 meter elevators each with a lifting capacity of 90 tonnes. To support aviation operations the ship is designed to carry up to 4,000 tonnes (5 million liters) of aviation jet fuel and 2,500 tonnes of aviation ordinance stored inside four below-deck magazines with a mechanized weapon handling system which moves ordinance between the magazines, hangar, weapons preparation area, and flight deck.


Propulsion
AGT1500 Nuclear Gas Turbine
  • Type:Nuclear gas-turbine
  • Length: 9.6 m
  • Width: 3.5 m
  • Height: 4.25 m
  • Weight: 265,000 kg
  • Compressor: 5 stage LPC, 5 stage HPC
  • Compression ratio: 3.2:1
  • Core: Right circular cylinder
  • Moderator: Nuclear-grade graphite (IG-110)
  • Turbine: 2 stage HPT, 2 stage LPT
  • Thermal efficiency: 36.5%
  • Output: 150,000 kWe @ 3,600 RPM
  • Fuel: TRISO-coated HEU UCO,97% U235 (HEU)
The Basilisk class carrier features a turbo-electric integrated electric propulsion (IEP) system with a total of eight AEG AGT1500 nuclear gas turbine generators producing electricity which powers superconducting motors driving the ships waterjet thrusters and lift fans and providing electrical power to the ship's zonal MVDC electrical system. The eight reactor modules are distributed four per sidehull, positioned below the waterline within heavily shielded compartments in the lower levels of each sidehull. For servicing the containment vessel and all internal components are removed as a single unit through a dedicated hull access opening and a refueled/refurbished module is installed in its place. The reactor spaces are separated from habitable compartments by dedicated void spaces that serve as both additional radiation-attenuation zones and damage-control barriers. Crew members do not enter the reactor compartments during operation, all monitoring and control is performed remotely from the reactor control center. Each AGT1500 is a helium-cooled, TRISO-fueled, graphite-moderated reactors operating at 1,040°C outlet temperature in a closed Brayton cycle with recuperation and intercooling. Fuel is TRISIO coated UCO fuel particles dispersed in graphite fuel elements. Each module produces 100 MW of shaft power from a free-power turbine which drives an HTS generator directly at 3,600 rpm. The reactor core is a right circular cylinder approximately 1.2 m in diameter and 1.0 m in active length constructed from hexagonal fuel elements with seven axial cooling channels each. The core is surrounded by a beryllium radial reflector containing rotating control drums with boron carbide sectors. The beryllium radial reflector assembly contains 12 rotating control drums, each consisting of a beryllium cylinder with a 120° sector replaced by stainless-steel tubes filled with B₄C absorber material. The drums rotate through 180° to transition from full absorption (absorber facing core) to full reflection (beryllium facing core). The control drums are driven by electric actuators mounted on the pressure-vessel dome through splined quill shafts. The reactor operates with helium coolant at an outlet temperature of 1,040°C and a system pressure of 10.5 MPa. Core thermal power is approximately 435 MWth per reactor, yielding 150 MW of output shaft power at an overall cycle efficiency of approximately 38%. The reactor incorporates multiple layers of safety: the TRISIO fuel particles themselves provide the primary fission-product containment barrier within each microscopic fuel kernel which incorporates incorporate a five-layer coating system: porous carbon buffer, inner pyrolytic carbon (IPyC), silicon carbide (SiC), outer pyrolytic carbon (OPyC), and an additional zirconium carbide (ZrC) overcoat that provides enhanced fission-product retention at temperatures up to 1,800°C. The helium coolant is inert and non-corrosive eliminating coolant-fuel chemical interactions, the graphite moderator has an enormous thermal inertia and a strongly negative temperature coefficient of reactivity, providing inherent passive shutdown capability, and the entire primary system is enclosed within a thick-walled Inconel 718 containment vessel with provisions for positive metal-to-metal shaft sealing in the event of sinking. Each AGT1500 employs a closed Brayton cycle power conversion system with recuperation and one stage of intercooling, using helium as the working fluid. The turbomachinery/heat-exchanger module integrates the high-pressure and low-pressure compressors, gas-generator turbine, free-power turbine, recuperator, precooler, and intercooler into a single compact package within the containment vessel. Heat rejection from the precoolers and intercoolers is to an intermediate closed-loop freshwater system, which in turn rejects heat to seawater through titanium plate-frame heat exchangers. Emergency decay-heat removal is provided by a passive natural-circulation cooling system that requires no external power, transferring heat to ambient air through dedicated heat exchangers. The free-power turbine drives an output shaft through an internal epicyclic reduction gear, providing 150 MW of mechanical shaft power at 3,600 rpm which drives an integral 150 MW HTS synchronous generator. The generator employs a rotating-field architecture with REBCO (Rare-Earth Barium Copper Oxide) HTS field coils cooled to approximately 40 K by Gifford-McMahon cryocoolers. The stator uses conventional liquid-cooled copper windings at room temperature. The HTS field winding produces magnetic flux densities of 5 T in the air gap, enabling a machine of approximately 3.0 m diameter and 3.5 m length to produce 150 MW at 3,600 rpm with a weight of approximately 30 tonnes. The AC power from the eight HTS turbogenerators is converted to to 6000 VDC with an active-front-end (AFE) power conversion module (PCMs) that rectifies the generator’s 3-phase AC output to ±6 kVDC for the MVDC bus. The AFE employs silicon-carbide (SiC) MOSFET switching devices operating at 20 kHz, providing near-unity power factor, low harmonic distortion (≤1% THD), and active fault-current limiting. Each AFE is rated for 150 MW continuous throughput with 99.5% conversion efficiency. The 6000 VDC power is then routed to both port and starboard DC buses which in turn supply power to 22 independent zones (one for each watertight compartment) which each include one DC/DC PCM per bus (two each per zone) which converts the 6000 VDC to 750-800 VDC or 650 VDC to supply DC loads in each zone. Both DC/DC PCMs in each zone also supply one or more DC/AC PCMs with 750-800 VDC which then converts the 750-800 VDC to 450 VAC at 60 Hz for AC loads. All electrical loads in each zone are connected to both port and starboard bus ensuring continued operation if either port or starboard bus becomes inoperable.

The propulsion system consists of eight large bore multi-stage pumpjet propulsors, four per sidehull stacked in a 2x2 configuration. Each propulsor is a three stage design with an inducer, a mixed flow main impeller, and an axial booster. The inducer is a low speed, large diameter axial flow inducer providing sufficient suction side head rise to suppress cavitation at the entry to the first main impeller across the full speed envelope (0–100 knots). The inducer operates at a rotational speed approximately 0.40× that of the main impellers, driven at reduced speed through a concentric epicyclic reduction within the pumpjet housing. The inducer blading is cast Ti-6Al-4V with swept leading edges optimized for minimum tip-vortex cavitation. The mixed-flow impeller operates at the primary rotational speed providing the majority of the head rise. The mixed-flow geometry achieves a balance between the high head rise of a centrifugal impeller and the high flow coefficient of an axial stage, optimized for the operating point at 100 knots. The impeller is a monolithic casting in Ti-6Al-4V with hot-isostatic-pressed (HIP) post-processing for maximum fatigue life. An axial flow booster stage downstream of the main impeller provides the final increment of head rise needed to achieve the required nozzle exit velocity at 100 knots. At lower ship speeds the booster is effectively unloaded by the variable-geometry inlet’s scheduling of flow rate versus pump speed. The booster is a 3-stage stator-rotor arrangement with Ti-6Al-4V blading. Each pair of pumpjets (inboard/outboard) in each sidehull is fed from a single semi-flush seawater inlet with a continuous-member variable-geometry ramp roof. The ramp-roof position is modulated by a hydraulic actuator as a function of ship speed, pump speed, and sea state, scheduling the inlet throat area to maintain optimal pressure recovery and cavitation margin across the full operating envelope. At low speeds, the inlet is wide open to maximize suction head; at high speeds, the ramp closes progressively to match the inlet area to the reduced volumetric flow demand at higher system pressure. Full keel-length sidehull fences, combined with inlet side plates, prevent cushion air ingestion (broaching) into the pumpjet inlets. An active broach detection system using differential pressure sensors at the inlet lips provides input to the propulsion control system, which limits HTS motor speed to prevent pumpjet overspeed events under broaching conditions.

Eight 100 MW HTS motors drive the eight waterjet pumpjets, being directly coupled to the main impeller/booster shaft. Each superconducting motor is a three phase, six pole synchronous air-core AC motor with a brushless exciter which has a rated speed of 600 RPM at its design voltage of 7,200 VAC with a full-load efficiency of 97.5%. The rotor employs yttrium-barium copper-oxide (YBCO) high temperature superconducting ceramic conductors and is cryogenically cooled to 77 degrees K using gaseous helium from cryocooler module containing single Stage GM cryocoolers located at the non-drive shaft end of the motor which feeds helium gas into the rotor through a rotating seal at the back end of the motor. The rotor housing is further enclosed in a vacuum-sealed cryostat to maintain cryogenic temperatures inside the rotor. The stator coils of the motor are made from copper Litz conductor and are cooled using a liquid dielectric coolant. Each motor with its integral cryocooler weighs approximately 10.0 tonnes compared to approximately 80 tonnes for a conventional motor of equivalent power. The motors are driven by a SiC MOSFET variable-frequency drive (VFD) drawing power from the ±6 kVDC MVDC bus. The VFD provides fully variable speed from 0 to 600 rpm with torque-mode and speed-mode control, enabling the propulsion control system to command any thrust level from zero to maximum in any combination across the eight pumpjets for maneuvering, thrust vectoring, and differential-thrust heading control. The 800 MW of installed power provides a sustained maximum on-cushion speed exceeding 100 knots at a displacement of 48,000 LT (two-thirds fuel/stores condition). At full-load displacement of 55,000 LT in sea-state 3, maximum sustained speed is approximately 90 knots. Emergency stopping from 100 knots is achieved within 1,000 meters through combined thrust reversal on the four outboard pumpjets, idling of inboard pumpjets, and partial stern-seal retraction.

Sixteen variable-geometry centrifugal lift fans, eight per sidehull, provide the pressurized air to sustain the air cushion. Each fan has a 3.5 diameter rotor with titanium-alloy impellers, double axial inlets, and variable inlet guide vanes for ride control modulation. Sixteen HTS motors drive the variable-geometry centrifugal lift fans. Each motor is rated at 12.5 MW at 1,200 RPM, providing a total installed lift power of 200 MW. The lift-fan motors are smaller versions of the propulsion motors, each weighing approximately 1.75 tonnes. Each fan incorporates two independent ride-control mechanisms including variable inlet guide vanes (IGVs) and variable rotational speed. The IGVs modulate inlet swirl to change the fan’s pressure-flow characteristic at constant speed, providing rapid response for high-frequency ride-control commands. Variable speed, controlled by the HTS motor’s VFD, provides broader-range modulation for changing sea states and ship operating modes. The combination provides approximately 40 dB of heave acceleration attenuation across the 0.1–5.0 Hz frequency band critical for crew comfort and flight-deck motion limits. The 16 fans are organized into four groups per sidehull with two forward fans supplying the bow seal, three center fans supplying the cushion plenum, two aft fans supplying the stern seal, and one fan serving as a dedicated ride-control modulator with its output split between cushion and stern-seal ducting via a high-speed transfer valve. This arrangement provides per-zone pressure control for pitch, heave, and roll attenuation. Ride-control vent valves in the cushion-distribution ducting provide supplementary pressure relief for high-sea-state operation, dumping excess cushion air overboard through flush-mounted ports in the wet deck. The vent valves are hydraulically actuated butterfly-type valves. The ship employs an active Ride Control System (RCS) that integrates the sixteen variable-geometry fans, cushion vent valves, and stern-seal transfer valves with a comprehensive sensor suite including inertial measurement units, wave-profiling LIDAR, and cushion-pressure transducers. The predictive MPC algorithm anticipates wave encounters and pre-positions fan and valve states to minimize heave, pitch, and roll accelerations Without ride control, the SEC-N’s flight-deck motions at 80+ knots in sea-state 5 would exceed the limits for safe aircraft operations. With the RCS active, flight-deck vertical accelerations are maintained below 0.3 g RMS at the landing spotting positions and below 0.15 g RMS at the catapult launch positions.


Sensors & Processing Systems:
FMG 300/400 Multi-Function Radar (MFR) The SDI FMG 300/400 dual band radar system includes the ships FMG 300 X band Multi-Function Radar (MFR) and FMG 400 C band Volume-Search Radar (VSR). Each radar system consist of four phased-array antennas and associated receiver/exciter (REX) cabinets above deck in the superstructure and a signal and data processor (SDP) system mounted below-decks inside the hull. Both arrays share a central controller and and a common array power system (CAPS) with power conversion units (PCUs) and power distribution units (PDUs) for each radar antenna. Both arrays are cooled using a closed loop, phase change based common array cooling system (CACS). The X band radar system features a larger operating bandwidth and better low-altitude performance and provides surface search, radar navigation, gun-fire targeting and splash spotting, periscope detection, mine detection, precision target tracking and discrimination, limited volume-search, high-bandwidth missile uplink, and terminal illumination of targets while the C band radar provides long range volume search and long-range target tracking capability. Both the The X band and C band radars can provide simultaneous sector search, environmental mapping, counter-fire/counter-battery tracking, missile tracking, electronic warfare, clutter detection, and in-flight missile guidance and communication. Each X band FMG 300 aperture has a 4-meter square antenna with 10,560 transmit and receive (T/R) modules which use gallium nitride complementary metal-oxide semiconductors (CMOS) on a diamond substrate. The C band FMG 400 antennas are significantly larger at 9 square meters and each use 17,680 full-duplex radio integrated circuit transmit and receive (T/R) modules. Each radar antenna features +/- 60° azimuth and +/- 60° degree beam-steering capability giving the system combined 360° azimuth and -2° to + 70°elevation coverage around the warship. Both radar systems employ wide-band digital receiver/exciter (DREX) units and feature digital beam-forming (DBF) capability, space-time adaptive processing (STAP), and multiple-input multiple-output (MIMO) waveform generation techniques. ECCM capabilities of the dual band radar system include frequency-modulated continuous-wave (FMCW) operating modes, ultra-low sidelobes, high processing gain, pulse-to-pulse frequency agility and ultra wide-band frequency hopping, staggered pulse repetition frequency (PRF) switching, randomized burst transmissions, and automatic jammer detection and tracking. The system has am instrumented range of 500 kilometers in air search modes and 80 kilometers in surface search modes and is capable of tracking up to 1,500 simultaneous air and surface targets.

The EOS 400 Staring Infrared Search & Track System:The SDI EOS 400 Staring Infrared Search & Track System is a distributed multi-aperture sensor system which consists of four identical dual field-of-view, electronically stabilized mercury cadmium telluride (HgCdTe) starring focal plane array (FPA) imaging infrared (IIR) sensor units placed in a mast atop the ship's superstructure which provides combined 360°azimuth and -20° to +75° elevation situational awareness infrared search and track (SAIRST) capability against surface vessel, cruise missile, ballistic missile, and aircraft targets to supplement the active search and track capability of the ship's dual band radar system. The 4096 × 4096 pixel (16 MPA) HgCdTe sensor used by each sensor head operates in the MWIR (3–5 µm) band and features a 95 x 95 degree field of view. The image processing features of the EOS 400 system include automatic target recognition (ATR) using an on-board threat library, passive ranging algorithms, multi-target adaptive tracking, and clutter rejection techniques. The video feed from the sensor units can be stitched together and displayed on operator consoles in the ship's bridge and CIC to act as a navigational aid and to provide close in situational awareness for the ship's crew.

SDI FMG 460 Naval Precision Approach Radar:For safely landing aircraft in night, low visibility, and adverse weather conditions the ship is equipped with two SDI FMG 460 naval precision approach radars which provide final approach and deck landing guidance for aircraft trying to land on the ship. The FMG 460 the system inboard the ship is intended primarily to permit low or zero visibility shipborne rolling vertical landings (SRVLs) by the STOVL aircraft in the carriers' flight wing, increasing the landing payload capacity of the aircraft. The ship has two FMG 460 radar antenna units, one in a sponson on the port side of the hull near the aft edge of the flight deck and another in the rear island which allows controlling of up to two aircraft simultaneously in a leapfrog pattern as they approach the carrier. Each radar antenna unit consists of an X band doppler radar with a coherent solid state transceiver utilizing frequency agile monopulse tracking for enhanced clutter rejection and rain and weather attenuation. Each radar is mounted on a triaxially stabilized gimbal to compensate for ship motition and is capable of scanning +/-20° in azimuth and 0°-8° in elevation with a maximum radar tracking range of 22 kilometers. The radar sets are controlled using two consoles located in the aft air control island which each contain a precision approach radar display (PAR) and an air search display connected to the warship's dual band radar system. The PAR display features an azimuth vs elevation display indicating the aircraft position with respect to the designed touchdown point, horizon sea level and flight deck centerline with aircraft offset error in azimuth and elevation displayed to within +/- 5° in azimuth and +/- 100 meters in elevation from the centerline of the desired glidepath with automatic correction of parallax error between the radar set location and aircraft landing path. The air search display receives data from the ship's dual band air search radar and from the ship's navigation system and features a range-azimuth display which indicates the radar tracks of aircraft around the ship waiting to land. The radar system can operate in two modes, an automatic mode which provides a fully automatic, hands off landing and a manual mode where the radar controller tracks the landing aircraft on the PAR display and relays continuous updates to the pilot on his azimuth and glideslope angle via a secure VHF voice channel.

SDI Electro-Optical Landing System: SDI's Electro-Optical Landing System is designed to provide electro-optical monitoring capability of aircraft landing aboard the carrier. the system consists of a 2-axis stabilized glide path camera located on the aft island and a 2-axis stabilized center line camera located at the stern of the ship. The system also includes two SDI EOS 200 2-axis stabilized electro-optical tracking systems, one on each island, each with 360° azimuth and -35 to +85° elevation coverage which provide general purpose electro-optical surveillance capability around the ship.

SDI Electro-Optical Aircraft Tracking System: SDI's Electro-Optical Aircraft Tracking System is a sensor system which is designed to provide continuous tracking of aircraft locations and orientations on the flight deck and inside the hangar and aids in the automation of flight deck operations by supplying flight deck personnel with a digital aircraft spotting board with real-time information on the position and status of each aircraft on the ship. The Carrier Aircraft Tracking System is fully automated and employs a 3D camera tracking system with a a total of 40 1920 x 1080 pixel InGaAs (indium gallium arsenide) visible/SWIR (0.4 - 1.7 µm) cameras with a 60 fps frame rate which have their feeds combined with digitized video enhancement and machine vision algorithms to provide position tracking of each carrier aircraft on the ship. 12 of the cameras are mounted in a fixed panoramic mount on the starboard side of the aft island and another 12 mounted on a fixed panoramic mount on the starboard side of the forward island with feeds from the 24 cameras stitched together to provide a real-time panoramic video feed of the entire flight deck. Another 16 cameras are mounted in the hangar, 8 in each hangar bay, with feeds from each set of 8 cameras stitched together to provide a real-time panoramic video feed of each hangar bay. Parallax between the cameras on the forward and aft island is used to determine the position of objects on the flight deck with additional position accuracy provided by machine vision algorithms which pinpoint individual features on the objects on the flight deck and hangar in relation to fixed landmarks on the flight and hangar decks. Individual pixels in each fixed frame are referenced to fixed padeyes and deck lights on the flight and hangar decks which are then used to triangulate the position of the object being tracked. The cameras track the six orientation parameters (X, Y, and Z coordinates, along with yaw, pitch and roll) of each aircraft with <0.5 meter position accuracy and continuously update the system computer generated digital aircraft spotting board at a rate of sixty frames per second. The system storage capability includes digital storage of "interesting events" which includes launch and recovery events with the ability to filter events by tail number and by aircraft type. The CATS is also used to provide FOD detection, fouled deck detection, and ordnance inspection


Electronic Warfare & Countermeasures:
FMS 1800 Advanced Integrated Electronic Warfare System (AIEWS): The primary electromagnetic countermeasure system ship is the FMS 1800 Advanced Integrated Electronic Warfare System, a comprehensive offensive and defensive electronic warfare (EW), electronic support measures (ESM), and electronic intelligence (ELINT) suite which combines passive radar warning receivers and phased array jammers for long range, over-the-horizon detection, identification, and targeting of threat emitters as well as automatic employment on-board RF countermeasures and support of passive over-the-horizon targeting capability for the ship's weapon systems. The passive radar warning system of the FMS 1800 consists of multiple single-quadrant, high-gain linear interferometer arrays smoothly blended into the superstructure of the vessel connected to a set of digital receivers and pulse processors inside the ship's superstructure which provide for 360° spherical broadband, all aspect detection, identification, and direction-finding of radar emissions with the capability for precise emitter location and threat identification capability against low probability of intercept waveforms and with additional over-the-horizon direction finding capability of MF, HF, VHF, and UHF band signals. The offensive electronic warfare capability of FMS 1800 system includes multiple low, mid, and high band electronically scanned gallium nitride (GaN) based Digital Radio Frequency Memory (DRFM) jammers blended into the superstructure which provide for the jamming of hostile RF sensors. The FMS 1800 is a fully cognitive and adaptive system; by using radar emission data collected from the FMS 1800s radar warning the DRFM jammers can automatically adapt in real time to unknown waveform characteristics, dynamically synthesize countermeasures, and jam the waveform accordingly.

LWG 310 Naval Laser Warning System: For detecting laser sources including laser range finders, laser target designators, and laser beamriding missiles the ship's electronic warfare system is augmented by an SDI LWG 310 Naval Laser Warning System. The vessel's LWG 310 installation consists of a central controller connected eight sensor heads, four on each side of the superstructure, providing combined 360° coverage around the vessel. Each individual sensor head features 110° azimuth and +/- , 70° elevation coverage and is capable of detecting up to eight simultaneous laser range finders laser target designator emissions in the 0.5 μm - 1.65 μm range and laser beamriders in the 0.8 μm - 1.1 μm range.

SDI Sea Guardian Surface Ship Torpedo Countermeasures System: For defense against submarine launched torpedoes the Fervent class is fitted with the SDI Sea Guardian Surface Ship Torpedo Countermeasure System which combines various soft-kill and hard-kill torpedo countermeasure systems. The Sea Guardian system consists of a towed array sonar designed specifically for torpedo detection, a towed acoustic decoy with a a single-drum winch, an interface to the ship's trainable decoy launchers, and a processing cabinet with two display consoles, and and four 4-round anti-torpedo torpedo launchers on either side of the ship. The towed array sonar used by the system is a combined active and passive array sonar optimized to detect the high frequency sound signature of torpedo screws and active sonar homing heads. The towed array is supported by two vibration isolated modules (VIMs) located on either side of the sonar with the array being connected on one end to the ship using a fiber-optic tow cable and connected on the other end to the towed decoy with an array tow cable. The towed decoy array is designed to emit simulated ship noise such as propulsor and engine noise to lure a passive-sonar homing torpedo to the decoy instead of the ship. The towed decoy can also receive sonar pings from the active homing head of a torpedo and amplifies and returns the "pings" to the torpedo, presenting a larger false target to the torpedo. The hardkill component of the Sea Guardian system comprises a series of four box launchers on either side of the vessel which each contain six SDI S2s Barracuda anti-torpedo torpedoes in individual all-up rounds (AUR) which contain the Barracuda torpedo and a self-contained compressed gas launch system. The Barracuda torpedo is 21 cm in diameter, 2.0 meters in length, weighs 110 kilograms, and contains a 20 kilogram aluminized PBX explosive warhead. The guidance and fusing system of the Barracuda is designed to explode it in front of the oncoming torpedo and create a pressure wave which crushes the nose section of the oncoming torpedo. The Barracuda has a maximum firing range of 10 kilometers and is propelled by an advanced stored chemical energy propulsion system (ADSCEPS) which can propel the Barracuda at speeds up to 60 knots at depths up to 1,000 meters. Although designed as an anti-torpedo the Barracuda can also be used to engage midget submarines, naval mines, and unmanned or autonomous underwater vehicles.

ZTKG 130 Trainable Decoy Launching System (TDLS): The ZTKG 130 Trainable Decoy Launching System (TDLS) is an aimable decoy launcher which can launch a variety of decoys designed to decoy away anti-ship missile and torpedo threats. The ZTKG 130 system consists of multiple 12-round trainable countermeasures launchers controlled by a central command console inside the ship. Each 12-round launcher employs a rotating platform with 12 separate 130mm barrels which can each be individually trained in elevation. The ship is fitted with four decoy launching systems, two on either side of the ship used for acoustic torpedo decoys (24 total) and another two launcher on each side used for chaff/flare rounds and missile seduction decoys (24 total).

AM5 dual chaff/IR seduction decoy: The primary chaff seduction round employed by the TDLS is the AM5 dual chaff/IR seduction decoy which is capable of defeating dual-seeker missiles equipped with both IR/EO and radar seekers. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.

AM79 Buzzard active missile decoy: For decoying away radar-guided anti-ship missiles the TDLS can deploy the AM79 Buzzard active missile decoy, an expendable electronic-warfare rotary-wing drone which is designed to seduce RF guided anti-ship missiles by simulating the radar return of a large surface vessel. The buzzard features a cylindrical shaped fuselage 130 mm in diameter and 0.9 meters tall with both top and bottom mounted 1.8 meter diameter three-bladed counter-rotating coaxial rotors powered by two brushless DC motors. The rotors unfold from the body of the decoy after launch and fly the decoy into a pre-programmed flight path away from the ship where the decoy then hovers in place while emitting electronic warfare signals uses its fuselage mounted Digital Radio Frequency Memory (DRFM) jammers which are designed to seduce oncoming anti-ship missiles into targeting the decoy and not the host vessel. The decoy is powered by a thermal battery mounted in the center of the fuselage which gives the decoy approximately 60 minutes of flight endurance after launch.

AM7 Lamprey acoustic decoy: The TDLS can also launch the AM7 Lamprey, a 130mm diameter, expendable acoustic decoy designed to counter torpedo threats. After a rocket-powered launch into ocean the Lamprey is programmed to hover vertically using a pressure-controlled motor driving a small, shrouded propeller in the tail of the decoy. The Lamprey is designed to hover at a pre-selected depth from 10-300 meters where it listens for torpedo transmissions. Active acoustic transmissions are detected and analyzed resulting in decoy selectivity and generation of the appropriate deception signal for transmission including target signature and target self noise. If no torpedo transmissions are detected the decoy is programmed to emit warship propulsor and engine noise to lure in passive homing torpedoes. Power for the motor and electronics of the Lamprey is provided by a thermal battery. The Lamprey is programmed to hover and emit noise until the battery dies where the decoy then sinks and all software onboard is erased.


Signature Reduction:
The Basilisk class features extensive radar and infrared signature reduction to reduce the ship's detectability and vulnerability to anti-ship missile threats. The superstructure features a faceted shape with an enclosed mast and sensors suite designed to eliminate corner reflectors and reduce the ship's detectability by radar systems. To firther reduce it's radar cross section the faces of the superstructure are fitted with SDI's S-RAM, a type of ballistic grade structural radar absorbing material consisting of 2 cm thick panels made from multiple layers of M5 fibers fibers containing a lossy filler backed by a carbon fiber laminate acting as a reflector. The panels are designed to survive extreme weather exposure and ballistic damage and provides an average -20 dB reflectivity across the 2-40 GHz frequency range (L through Ka bands). The rest of the hull and superstructure is painted in a radar absorbing paint coating 1 to 5 millimeters thick consisting of lossy dielectric material embedded in a polymer resin which provides -20 dB reflectivity across the 9 -13 GHz range (X band). The infrared signature from the ship's engines is suppressed using an infrared signature suppression system built into the exhaust uptakes on each island. The system consists of a film cooled stainless steel outer duct surrounding a conductively and film cooled stainless steel centerbody and a film cooled stainless steel diffuser which blocks any line of sight view of the heated metal surfaces and reduces uptake metal temperatures to less than 25°C above ambient using ambient air draw into the uptake through a multi-lobed ejector nozzle at the base of the diffuser. The diffuser also contains multiple rings of atomizing nozzles which inject a a fine mist of seawater into the exhaust stream, cooling the exhaust stream to a plume temperature of under 150°C. Seawater injection is controlled by an on board signature management system which interfaces with the ship's propulsion machinery control system and controls the flow of water as a function of engine power.

[box]Passive Protection & Damage Control:
[spoiler=More Information]The Basilisk class features passive armor protection in the form of several hundred tonnes of composite armor panels made from M5 ballistic fiber laminated into cured thermoplastic panels which provide ballistic impact and spall protection to the superstructure and vital areas of the ship. The ship's blast hardened bulkheads are designed to deform plastically and maintain watertight integrity in the event of an explosion from a bomb or missile warhead inside the ship and feature double-spaced plate construction with an internal fragment resistant membrane designed to stop fragments from penetrating further into the ship. The automatic opening/closing watertight doors in the bulkheads likewise feature a blast hardened membranes structure design with approximately 10 times the blast force resistance of a conventional watertight door.

Damage control on the Basilisk class is largely automated due in parts to SDI Naval Systems developed Automated Ship Control System (ASCS). The ASCS is controlled by a centralized computer which amongst other functions provides real-time damage information to the crew through a graphical display located in the ship's damage control center. Additionally both the ship's bridge and CIC also also fitted with displays connected to the ASCS. The ACSC is designed to run automatically where after the ASCS detects damage to a compartment it will immediately isolate it and activate appropriate damage control measures. Alternatively the ASCS can be set to manual mode where the operator will have to specify the damage control measures after the system detects ship damage. The ASCS also controls and monitors the ship's engines and machinery and will alert engineers on watch duty through their assigned tablet computer when an engineering issue or machinery failure is detected and requires attention. This remove the need for time based maintenance, the system will simply alert the crew when a component or system requires maintenance. Each compartment and each piece of machinery on the ship are monitored using SDI's Two Wire Automatic Remote Sensing Evaluation System (TWARSES) which includes both visible CCD and infrared cameras located in each ship compartment. After damage is detected in a compartment the ASCS can respond in a variety of ways including isolating the damaged compartment by closing the electrically actuated watertight doors around the compartment. If the IR camera detects a fire the system will activate the compartment's overhead sprinklers and can also pump the compartment with aqueous film-forming foam (AFFF), high velocity fog, and/or carbon dioxide agents if necessary. After the fire is extinguished water and firefighter agents are removed using a bilge draining pump installed in each compartment. The ASCS will also reroute ventilation, electrical power, and water around the damaged area and activate additional pumps, generators and other devices if necessary. If the compartment has been breached and is in danger of flooding the system will flood the compartment with foam which rapidly solidifies and restores reserve buoyancy. This system however is only used as an absolute last resort as it renders the compartment unusable. The ASCS also controls the ship's CBRN protection system by passing air from the ventilation intakes through containment filters before it enters the ship. Air in the ship is maintained at 5.0 millibar above local atmospheric pressure to provide a positive pressure and prevent contaminated air from entering into the ship through a breach in the hull.

In addition to the ASCS system the ship's flight deck features its own separate aqueous film-forming foam (AFFF) washdown system to combat fires on the flight deck. The flight deck is divided into 12 firefighting zones with several hundred flush-deck and deck-edge nozzles mounted in the flight deck capable of delivering up to 4,000 liters of AFFF solution to each firefighting zone. Each of the carrier's two aircraft elevators also contains four nozzles capable of spraying up to 75 liters per minute of AFFF solution onto each elevator. The deck washdown system for each firefighting zone is activated manually through operator panels located in the primary flight control tower and the navigation bridge. The flight deck also contains 12 AFFF hose stations which also contain portable PKP and CO2 fire extinguishers.


Armament:
[box]Armament:
[spoiler=More Information]
S70 Vertical Launch System The Basilisk class ship is fitted with 32 total S70 vertical launch cells located in four 8-cell modules mounted in port and starboard sponsons. The S70 is a cold-launch system which uses missiles encased in individual concentric launch cells as modular all-up rounds (AURs) each containing the missile, concentric launch tube, launch tube electronics, and missile ejection system. The launch cells are inclined at a 10 degree angle towards the ships centerline to prevent missiles with malfunctioning rocket motors from crashing back onto the deck after launch. Each launch cell is capable of accommodating either a single launch tube which can contain a missiles with a maximum length of 7.0 meters, diameter of 0.6 meters, and a weight of 2,500 kg. The missiles are ejected from each launch tube using a steam generator system which uses a small solid-propellant gas generator which exhausts through cooling water into the base of each launch cell, creating expanding high pressure steam which then forces the missile out of the launch tube. Safety and passive protection features of each VLS module include concentric anti-fragmentation shields placed around each launch cell tube to prevent in-cell missile fratricide and a deluge system which can flood each 8 cell module in the event of a missile catching fire in the launch tube. Launch tubes are connected to the launch cells through shock collar that is designed to absorb acceleration loads from an underwater detonation near the ship. The individual missile cells are connected to the ship's weapon control system via redundant port, central, and starboard fiber-optic Ethernet lines which transmits launch commands to the individual missiles and allows for missile status information before launch to be sent back to the weapon control system.
Last edited by The Technocratic Syndicalists on Fri Jul 24, 2026 8:15 pm, edited 12 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Sun Jul 02, 2023 12:33 pm

Image

Erebus Class

Basic Information:
  • Type: Ballistic missile submarine
  • Displacement: 19,200 t surfaced, 24,500 t submerged
  • Complement: 130
  • Length: 171.0 m
  • Beam: 13.5 m
  • Draft: 10.8 m
Installed Power:
  • 1x SDI PWR 55 pressurized water reactor (PWR), 220 MWt
  • 1x AMG 16V 17/19 M64 diesel generator, 2,000 kWe each
Propulsion:
  • 1x 45 MW high-temperature superconducting (HTS) propulsion motor
  • 4x retractable auxiliary maneuvering thrusters, 625 kW each

Performance:
  • Speed:
    • Surfaced: 18 knots
    • Submerged (silent): 24 knots
    • Submerged (max): 30 knots
  • Diving depth:
    • Test: 600 m
    • Maximum: 1,000 m
  • Range: crew endurance (120 days supplies)
Sensors & Processing Systems:
  • SDI Submarine Tactical Combat System
  • SDI RMS 120 Conformal Acoustic Velocity Sonar (CAVES) Integrated Bow Array
  • SDI RMS 260 Conformal Acoustic Velocity Sonar (CAVES) Wide Aperture Flank Array
  • SDI SS 660 Fiber-optic thin-line towed-array sonar
  • SDI SS 670 Fiber-optic fat-line towed-array sonar
  • SDI FMG 600 Ultra-high frequency phased array antenna system
  • SDI EOS 770 Submarine Laser Communications receiver
  • SDI UKS-90 Multifunction towed communications buoy
  • SDI FMG 180 X band phased array surface search/navigation radar
  • SDI OKS 300 Multispectral photonics mast system
  • SDI Strategic Navigation System

Electronic Warfare & Countermeasures:
  • SDI FLG 130 Tactical ESM System
  • SDI RMS 350 acoustic interception and countermeasures system
  • SDI RMS 100 Own-noise monitoring system
  • SDI Sea Wraith electromagnetic signature suppression system
  • 10 cm internal countermeasure launchers
  • 21 cm external countermeasure launchers

Armament & Payload:
  • 4x 60 cm torpedo tubes, 25x H8s Dragonfish torpedoes or RBS 86 anti-submarine missiles
  • 24x RBS 118 submarine-launched ballistic missiles
  • 1x sail-mounted VLS module, 38x RBS 91 missiles


Overview:
The Erebus class SSGN is an advanced ballistic missile submarine designed by SDI Naval Systems. The Erebus is a derivate of SDI's Hydra class cruise missile submarine and features the same propulsion and sensor systems with a stretched hull with additional launch tubes designed to accommodate 24 RBS 118 submarine launched ballistic missiles.


Design & Construction:
The Erebus features a double hull design with an inner steel pressure hull and an outer composite light hull. The 12 meter diameter pressure hull is constructed from five modular hull sections (weapons module, habitability module, missile module, engine room module, and auxiliary machine room module) which are welded together to form the final pressure hull. The large internal decks in each hull module are fabricated and inserted into the hull as individual modular isolated deck sections onto cushioned and vibration isolated supports before the separate hull modules are welded together. The pressure hull of the Erebus class is constructed from St 150 steel, a martensitic precipitation hardened low-carbon steel with a minimum yield strength of 150 kgf/mm2 . The individual pressure hull sections are formed using double vacuum melted (vacuum induction melted followed by vacuum arc remelting) St 150 steel which is forged into a cylindrical shape and then precision ground to tolerance. The pressure hull sections are then welded together under an argon atmosphere using gas shielded flux cored arc welding (FCAW-G) machines attached to servo-controlled laser guided robotic welding units. Additional forged St 150 longitudinal bulkheads are also welded inside the St 150 pressure hull to divide the hull into ten separate watertight components. The St 150 pressure hull gives the submarine a calculated crush depth of approximately 1,500 meters with a maximum safe operational depth of 1,000 meters.

The outer light hull of the submarine along with the pumpjet propulsor, machinery room supports, dive planes, rudders, sonar array fairings, and sail of the Hydra class are all constructed from a graphite and fiber reinforced epoxy composite formed using Vacuum Assisted Resin Transfer Molding (VARTM) processes. As opposed to traditional metal construction the use of composites saves significant amounts of weight as well as having lower manufacturing and maintenance costs. The outer light hull of the Erebus features a trapezoidal cross section with prominent bow and nose chines to deflect active sonar waves and consist of a 2mm thick vacuum assisted resin transfer molded shell 13.5 meters wide and 12 meters tall formed using carbon and S-2 glass fibers wound transversely using automated fiber placement (AFP) into an vinyl-ester resin epoxy matrix. The composite structure has the advantage of being acoustically transparent, has no magnetic signature, and has excellent vibration dampening properties.


Propulsion:
Reactor: Each Erebus class submarine is powered by a single SDI PWR 55 pressurized water reactor with a maximum power output of 220 megawatts of thermal energy. The PWR 55 is an advanced natural circulation based reactor which can operate at a signification fraction of its maximum power output (80 plus percent) without relying on reactor cooling pumps. Four small single-speed circulation pumps are employed in the primary coolant loop which are only used at high speeds in forced circulation mode. The fuel used in the reactor is 15% zirconium and 85% highly enriched uranium (HEU) enriched to 97% U235 and the reactor is expected to be capable of operating for 40 years without requiring a refueling. The S10S uses two cooling loops and includes two steam generators within its reactor core which provide high pressure, high temperature steam used to drive a single steam turbine. The steam turbine direct drives a single high temperature superconducting (HTS) AC generator which outputs a total of 55,000 kW of electric power which provides power to the ship's propulsion motor and other electrical systems. The entire PWR 55 reactor compartment is 12.5 m in diameter, 13 m long, and weighs 2,500 metric tons.

Motor & Pumjet: The Erebus class submarine is powered by a single shrouded pumpjet propulsor. The pumpjet propulsor employs a carbon/epoxy and glass/epoxy composite shroud and contains a rotor with eleven highly swept and skewed back nickel-aluminum bronze alloy blades and stator employing nine carbon fiber/epoxy blades which are molded into the composite shroud. Power is transmitted to the rotor using a carbon fiber reinforced plastic (CRFP) drive shaft connecting the rotor to the electric propulsion motor located inside the submarine's pressure hull. The motor used to drive the pumpjet is an SDI designed 45 MW three phase, six pole synchronous air-core AC superconducting motor. The rotor employs yttrium-barium copper-oxide (YBCO) high temperature superconducting ceramic conductors and is cryogenically cooled to 77 degrees K using gaseous helium from cryocooler module containing single stage GM cryocoolers located at the non-drive shaft end of the motor which feeds helium gas into the rotor through a rotating seal at the back end of the motor. The rotor housing is further enclosed in a vacuum-sealed cryostat to maintain cryogenic temperatures inside the rotor. The stator coils of the motor are made from copper Litz conductor and are cooled using a liquid dielectric coolant. The motor employs a variable-frequency drive (VFD) with three separate 2,400 VAC three-phase power modules per drive which allows for efficient motor operation from 6 up to 400 rpm.


Stealth
Designed to operate autonomously against the most capable submarine and surface threats the Hydra features a variety of stealth systems designed to drastically reduce the detectability of the Submarine to both acoustic and electromagnetic sensor systems. The acoustic signature of the Hydra is monitored in real time by the RMS 100 own-noise monitoring system (ONMS) which employs a series of self noise hydrophones (SNHs) mounted outside of the pressure along with hull and machinery mounted accelerators connected to a centralized processing system and a display/interface inside the submarine. The ONMS monitors both acoustic noise and vibration inside the submarine for radiated noise self-estimation and source localization as well as machinery and hull health monitoring. The OMNS can detect propulsor cavitation, flow induced structural resonation, and any odd noises emanating from the machinery or propulsion plants or due to loose objects inside of the submarine.

The SEA WRAITH electromagnetic Signature Suppression System is an active signature control system fitted to the Erebus is designed to self-detect and reduce the submarine's magnetic and electrical signature. Included in the SEA WRAITH system is a fully distributed closed-loop degaussing (CLDG) system which provides real time measurement and cancellation of the submarine's magnetic signature. The CLDG system is built into the steel pressure hull and comprises a set of magnetic field sensors and degaussing coils wrapped around each compartment connected to bulkhead mounted power units which continuously monitor the vessel's magnetic signature and adjusts the degaussing coils as necessary to eliminate any magnetic signatures in real-time. The degaussing coils are arranged in three axes around the outside of the pressure hull in sections each carrying a submersible magnetometer array employing eight miniature fluxgate sensors positioned equally around the circumference of the pressure hull. The magnetic signature of the submarine is measured by the magnetometer arrays and modeled computationally using a centralized Degaussing Control Unit (DCU) which controls a series of amplifiers which then apply the appropriate degaussing currents to each coil section. The magnetometer array is capable of measuring nanoTesla variations in the submarine's magnetic field, allowing minute variations in the submarine's magnetic signature due to depth or heading changes to be corrected for in real time. Each coil section (one for each watertight compartment) is powered by a convection cooled Bi-Polar Amplifier Unit (BPAU) with an embedded microprocessor controller attached to the aft bulkhead inside the compartment and supplies DC power to the coil section using transformer that receives AC power from the ship's generators. The separate coil sections and BPAUs are interconnected, allowing the system to adapt to the failure of one or more BPAU units. The SEA WRAITH system additionally comprises a series of Underwater Electric Potential/Extremely Low Frequency Electric fields (UEP/ELFE) sensors distributed around the submarine's hull which are designed to measure the corrosion currents produced by the submarine's pressure hull and other metal parts in contact with seawater. The electric field measurements from the UEP/ELFE sensors are used to adjust the current through the Impressed Current Cathodic Protection (ICCP), itself used to suppress galvanic corrosion in the submarines metallic components which are exposed to seawater. The ICCP system consists of mixed metal oxide coated titanium anodes supplied with DC current from the submarine along with zinc reference electrodes which create an external current designed to counter-act the electrochemical action of galvanic corrosion. This current creates both UEP and Corrosion Related Magnetic (CRM) signatures which are monitored in real time using the UEP/ELFE sensors which forms a closed feedback loop with the ICCP system, the current through the ICCP anode continuity being adjusted in real time to minimize the vessel's electrical signature.

Both the inner pressure hull and outer light hull of the Erebus class submarine is fully coated in sound absorbing, pressure resistant anechoic tiles which are intended to reduce the submarine's acoustic signature. Each of the several ten thousand rectangular shaped tiles coating the hull is approximately 50 by 50 centimeters on each side and 10 centimeters thick and are constructed from multiple layers of viscoelastic polyurethane rubber embedded with inflated air filled polystyrene micro and macroscopic spheres of different diameters. The inner layer of tiled bonding to the outside of the submarine's pressure hill are optimized to absorb the frequencies of the submarine's own rotating machinery and vary in size and shape based on their location on the hull. The outer layer of tiles on the submarine's light hull are instead designed to absorb specific active medium and high frequency sonars including those used by active torpedo homing sonars and active ship and submarine ASW sonars with macroscopic cavities within which are sized to provide absorption of low frequency waves from towed low-frequency active towed sonars. The sail of the submarine as well as the dive planes and rear control surfaces additionally features a spray-on anechoic coating with microscopic voids designed to attenuate active sonar signals from medium and high frequency active sonar sources.

In addition to active acoustic coatings the Erebus features both passive and active vibration control of all machinery components to minimize the radiated acoustic energy from propulsion and machinery vibrations. The pumpjet propulsor of the Erebus contains a resonance changer (RC) which electromagnetically dampens dynamic vibrations caused by forces from the spinning impeller blades acting on the submarine's hull. The resonance changer (RC) system is connected to the hydrodynamic thrust bearing in the submarine's tail cone attached to the inner stator of the motor/propulsor unit. The resonance changer (RC) uses active magnetic dampers which exert an axial force on the thrust bearing to actively cancel out vibrations in the bearing. A series of Hall sensors are placed around the hydrodynamic thrust bearing which measure the axial forces in the shaft. A series of stationary axially magnetized permanent magnets placed around the bearing are then energized to exert a Lorentz force exactly opposite to the force detected by the Hall sensors, canceling out the axial force in the shaft. A virtually identical electromagnetic resonance changer (RC) system is also used on the submarine's turbogenerators and backup diesel generators which both use electrodynamics thrust bearings which the RC dampening system is connected to. To prevent vibrations from being transmitted from the rotating machinery to the hull the various machinery onboard the Erebus including the reactor, turbines, diesel engines, pumps, etc is connected to the hull using a two-stage hybrid passive/active vibration isolation system which serves to both support the weight of the machinery and prevent vibrations from the machine from being transmitted to the hull. The two-stage passive vibration system consists of two sets of hydraulic dampeners and a heavy intermediate mass in between, the hydraulic dampeners each tuned to one of the major resonant frequencies of vibration generated by the machinery. This passive system however is only effective across a small range operating speeds and is thus supplemented by an active vibration dampening system which employs a series of piezoelectric actuators and voice-coil linear motors along with the hydraulic dampeners. For control of the active vibration isolation system a series of accelerators is mounted along the supports which measure the vibration of the machinery in all three dimensions. The actuators and linear motors are then used to generate counter-acting forces to cancel out the vibrations generated by machinery in real time. Although not as reliable as the passive system this allows vibrations to be suppressed across the entire operating range of the machinery and is more effective at suppressing low-frequency vibrations. The hybrid system thus uses the passive actuators to support the weight of the machinery and to act as a fail safe in case of active system failure.


Sensors & Processing Systems:
RMS 120 CAVES Integrated Bow Array: The primary undersea sensing system of the Erebus class SSGN is the SDI Underwater Systems RMS 120 Conformal Acoustic Velocity Sonar (CAVES) bow array which combines medium (0.3 to 12 kHz) and high frequency (36 to 72 KHz) transducers and low-frequency passive hydrophones in an array mounted conformally to the bow of the submarine. The curved array allows +/-120° horizontal and +/-30 ° vertical detection and transmission of sonar signals and replaces the spherical passive/active bow array and high frequency chin arrays used by previous generation submarines. The Bow array has multiple functions which including active detection and tracking of undersea contacts, mine detection and avoidance and under-ice navigation capability, and long ranged passive detection and tracking of both surface and subsurface contacts. The 11,880 individual TR 660 transducer elements that comprise the dual-frequency active/passive transducer array of the RMS 120 use SDI's proprietary piezolectric single crystal composite (SCC) architecture which consists of lead magnesium niobate-lead titanate solid solution (PMN-PT) single crystal piezoelectric rods embedded into an active polymer matrix to form a flexible 3-dimensional composite. The SCC architecture, which SDI Naval Systems developed specifically for use in high-performance sonar arrays, combines the extremely high piezoelectric and dielectric performance of single-crystal transducers with the water-like acoustic impedance, broader bandwidth, and flexibility of piezoelectric polymers. To shield the TR 660 transducer elements from vibrations each transducer element is self-contained within an individual vibration isolation module machined from a block of beryllium-copper alloy which is designed to isolate the transducer element from 99.5% or more of external vibrations. Located underneath and above the medium/high frequency transducer array is a low-frequency passive hydrophone array containing 290 SDI Naval Systems designed DT 585 wide band, omni-directional hydrophones. To compensate for cavitation effects on the face of the transducer and hydrophone elements at flank speeds each vibration-isolated TR 660 transducer and DT 585 hydrophone contains a 3-axis piezoelectric accelerometer attached to the back of the diaphragm which inputs the acceleration and velocity of the element to the driver amplifiers to actively cancel out the vibration of the element in real time. To eliminate the deleterious effect of self-noise on the CAVES array the entire array is attached to a an active noise-canceling composite layer connects the CAVES array to the hull of the submarine and consists of two layers of thin film polyvinylidine fluoride (PVF2) polymer transducers separated by a neoprene acoustic insulator layer connected to the submarine's hydrodynamic hull with a 25 mm thick layer of versathane adhesive. The detected acoustic signals from both the outer and inner PVF2 transducers are fed into an electronic control circuit which subtracts the signal of the inner sensor from the signal of the outer sensor to effectively cancel out the noise emanating from the array itself and from the submarine, allowing the primary TR 660 transducer and DT 585 hydrophone array to listen solely to sound external to the submarine. Medium/high frequency acoustic signals emitted by the CAVES transducer array are formed using a space-time adaptive processing (STAP) algorithm designed to enable adaptive beamforming capability to enable the array to create a virtual 3-dimensional image of sonar contacts in order to accurately separate targets from decoys and from clutter present in littoral waters while also minimizing sidelobes (LPI/LPD), and enable adaptive angle estimation to more accurately determine target depth, bearing and speed.

RMS 260 CAVES Wide Aperture Flank Arrayr: The SDI Underwater Systems RMS 260 Conformal Acoustic Velocity Sonar (CAVES) Wide Aperture Flank Array consists of two sets of three arrays mounted along either side of the submarine's hull (6 arrays total) which provides three-dimensional passive detection and ranging capability using Time Difference of Arrival (TDOA) techniques with each individual array to generate passive range, bearing, and speed estimates for a given target. The CAVES flank array requires an initial detection from either one of the towed arrays or the CAVES bow array to initiate the CAVES flank array detection processing. Once the flank array has been steered onto a target using the bearing provided by the towed or bowl array it will then attempt to detect and classify the contact. Each of the six flank arrays contains 640 SDI Underwater Systems designed DT 606 fiber laser hydrophones each consisting of multiple sub-millimeter thick silicon wafers attached together along with an erbium doped distributed feedback (DFB) fiber laser bonded into a beam-forming groove etched using potassium hydroxide (KOH) onto the upper silicon waver of the assembly. The DFB laser acts as a strain sensor and consists of an erbium doped fiber-optic core delimited by two fiber bragg gratings which outputs an infra-red laser with a wavelength which is adjustable between 1520 nm and 1560 nm. Strain on the hydrophone due to acoustic pressure causes the pitch of the bragg gratings to change which then alters the wavelength of the laser, the difference in wavelength being detected and converted into a strain measurement. The complete multiplexed array consists of 64 DFB lasers tuned to different wavelengths arranged linearly along a single fiber-optic cable and pumped by a single 1480 nm laser. Outputs from each laser are the carried back along the same fiber cable where the beam is split into its constituent wavelength and the intensity of each wavelength component measured by a series of photodectors connected to an interferometer which converts the wavelength fluctuations into an electrical signal representing the detected noise. The 64 lasers of each array are multiplexed with time and ten different laser wavelengths used which allows all 640 hydrophones in the array to be interlinked through two separate optical fiber cables which are both connected to the array's digital signal processing equipment inside the submarine. The complete fiber laser hydrophone array is sandwiched between two sheets of glass- fiber epoxy which provides structural rigidity for the array and protects it from external damage. The rigid array is in turn attached to an active noise-canceling composite layer consisting of thin film polyvinylidine fluoride (PVF2) separated by a neoprene acoustic insulator layer (virtually identical to the layer attached to the bow array) which is turn attached to the outer hydrodynamic hull of the submarine using 25 mm of versathane adhesive.

SS 660/670 Towed Array Sonars: the Erebus class SSGN is equipped with two towed arrays; the SS 660 thin-line towed array and the SS 670 thick-line towed array. The SS 660 consist of a fiber optic hydrophone array approximately 300 meters long and 76mm in diameter which is towed 1,800 meters behind the submarine. The SS 660 comprises a total of 96 fiber-optic hydrophones which use low-reflectivity fiber Bragg grating interferometers as well as internal stops to suppress buckling of the hydrophone mandrel from water pressure up to the array's designed operating depth. The fiber-optic hydrophones consist of a plastic mandrel wrapped with fiber-optic cables surrounded by a kevlar strengthened polypropylene hydrogel filled jacket. The individual hydrophones are passively multiplexed in both time and in wavelength to allow hundreds of channels to be carried over on just four fiber-optic cables. A Vibration Isolation Module (VIM) connects the hydrophone array to the tow cable and is designed to isolate the hydrophone array from axial vibrations and platform noise. The SS 670 fat-line towed sonar array is 89mm in diameter, 70 meters long, and is towed by a cable 300 meters long. The SS 670 has 480 acoustic channels (192 VHF channels, 192 UHF channels, and 96 EFH channels in an aperture center nested array). The SS 670 also features an array stiffness adjustment system using an electromagnetically driven ferrofluid inside the towing cable which is designed to keep the towing cable straight and stable at submarine flank speeds. To remove the effects of vibrational self-noise at high towing speeds both the SS 660 and SS 670 arrays feature an integral non-acoustic noise cancelling system which forms an adaptive interference reference end-fire beam with adaptive sidelobe canceling outside of the target frequency of interest while the array is being towed. The receives signal is used to samples the distortion in signal caused by vibrational interference, allowing the signal processing system to subtract the measured vibration from the received acoustic waves in the frequency of interest.

OKS 300 Multispectral Photonics Mast System: The OKS 300 Multispectral Photonics Mast System is a non hull-penetrating periscope system compositing two multispectral photonics mast containing visible light, infrared, and various ESM sensors. Each photonics mast can be extended up to 4 meters above the sail and feature a stabilized sensor head with provide 360 ° azimuth and -5° to +60° elevation coverage. The retractable mast features two mechanical stabilization systems; a course stabilization system which keeps the mast vertical under the influence of surface currents and a fine dual-axis stabilization system which stabilizes the line-of-sight to the target in pitch and yaw, roll being stabilized electronically. The head of the photonics mast is encased in a Low-RCS composite shroud with additional RAM coatings to minimize it's detectability to radar and contains a 1920 x 1080 pixel CCD color TV camera, third generation 1280 x 720 pixel MWIR (3–5 µm) uncooled mercury cadmium telluride (HgCdTe) thermal imager, a 1280 x 1024 pixel Indium gallium arsenide (InGas) SWIR (1–1.6 µm) imager, a 4320 x 2432 pixel Complementary metal–oxide–semiconductor (CMOS) color Low light level television (LLTV) camera, and an eye-safe 2.1 μm holmium laser rangefinder. Signals from the masts sensors are transmitted through fiber-optic data lines to the submarine's control center where the sensor feeds are processes and displayed on liquid-crystal displays in the command center. The BVS-3 processor system employs a multispectral image fusion system which combines the feed from the various mast-mounted electro-optical sensors and fuses the together, removing field of view (FOV) and spatial resolution differences between the different cameras and to correct bore-sighting inaccuracies. The fused data stream is output as a standard NTSC signal and is fed to the MDC consoles on the submarine's CIC for viewing by the crew. The top of the photonics mast also includes a frequency-selective enclosure which contains a GPS receiver as well as various antennas for the submerine's ESM system.

FMG 180 phased array surface search/navigation radar: The FMG 180 radar is a lightweight, compact X band (10 Mhz) active electronically scanned array (AESA) submarine radar designed to provide surface navigation capability, situational awareness, and surveillance of surface vessels, helicopters, and low flying aircraft. The FMG 180 radar is mounted to a electrically driven raise/rotate mast assembly which retracts into the sail when not in use. The FMG 180 features a horizontally polarized end fed slotted line array which is steered electronically in elevation (+/- 60° scan angle) and mechanically in azimuth with a rotation rate of 60 RPM. The FMG 180 has a low power output and low probability of intercept (LPI) capability and can track up to 100 targets simultaneously out to a maximum instrumented range of 60 kilometer and can detect low RCS targets in cluttered environments in all weather conditions. The FMG 180 operates with Electronic Chart Display and Information System (ECDIS) and Voyage Management System (VMS) for navigation as well as a 20-target Automatic Radar Plotting Aid (ARPA) capability for collision avoidance. Control and signal processing for the FMG 180 is via twin Electronic Modular Enclosures (EMEs) integrated into the Submarine's SDI Submarine Tactical Combat System.


Control & Communications:
SDI Sea Serpent Submarine Tactical Combat System:The SDI Sea Serpent Submarine Tactical Combat System is an advanced open-architecture combat system responsible for controlling all weapon and sensor subsystems of the Hydra class SSGN to include detecting, identification, and tracking threats and the settings and control of torpedo and missile weapons and mines. The main components of the Sea Serpent are split into acoustic/sensor and weapons control subsystems which includes the SS 670 Fiber-optic high-frequency thin-line tactical towed-array, SS 670 Low frequency fat-line towed sonar, RMS 120 Large Aperture Conformal Array, RMS 260 Conformal Acoustic Velocity Sonar Wide Aperture Array, OKS 300 Multispectral Photonics Mast System, FLG 130 Tactical ESM System, FMG 180 X band phased array surface search/navigation radar, Multifunction Display Consoles (MDC), Tactical Situation Plotter, Weapon Launch System (WLS), Attack Weapons Control System (AWCS) the Multi-Array Signal Conditioner (MASC), and SPCC10D signal processing computers. The Attack Weapons Control System (AWCS) consists of a launch interface with the submarine's complement of missiles and displays the current readiness of each missile, missions planning and engagement information, and monitors the launch sequence of each missile along with with position and control of the missile silo doors and missile payload module subsystems. The Sea Serpent combat system functions are run on the SPCC10D signal-board computer, a ruggedized, shock hardened and conduction cooled computer which employs a 10nm gallium nitride (GaN) on silicon architecture, 48 core (384 thread) superscalar symmetric multiprocessor with a 4.0 GHz clock rate, embedded discrete 768 Single precision GFLOPS GPU, 64 GB of DDR5 DRAM and is used to process and fuze data from the various acoustic sensor systems of the submarine. The SPPC10D computers are packaged into Electronic Modular Enclosures (EMEs) which each include their own power, shock, vibration, electromagnetic protection, and water cooling systems. Each EME is a self-contained server and carries 235 cabinets containing the SPPC10D single-board computers. The EMEs which run the BSY-3 software are interconnected to the rest of the sensors and electrical systems through fiber-optic cables and uses voice-over IP for internal communications between computer systems. Sensor data processed by the SPCC10D computers is displayed on SDI designed Multifunction Display Consoles (MDCs), a ruggedized, modular workstation system using dual stacked 60 cm color LCD displays with 1920 x 1200 Widescreen Ultra Extended Graphics Array (WUXGA) resolution with an additional two 25 cm 1024 x 600 resolution multi-touch touchscreen displays mounted side-by-side underneath the two LCD displays. The MDC includes twin trackballs or joysticks along with a keyboard for data input and MIL-STD key switches for arming and launching weapons. Other MDC features include 100BASE-FX fiber-optic ethernet and a quad core 8M Cache, 2.40 GHz integrated console computer with 4 GB of GDDR5 SDRAM and a 60 GB solid state drive. A total of twenty MDC displays are contained in the submarine's Combat Information Center (CIC) and are used for ship control, sonar control, photonics and navigation control, communications control, electronic warfare, special operations mission planning, and control of targeting and weapons launching. An additional sixteen MDC displays are located in the submarine's maneuvering room and auxiliary electronics deck for control of the submarine's various power generation, steering, and propulsive systems.

EOS 770 Submarine Laser Communications Receiver: The sail of the Erebus class submarine contains an SDI EOS 770 Submarine Laser Communications System (SLCS) receiver designed to receive data from SDI Space System's designed Sealink submarine laser communications (SLC) satellites in geosynchronous orbit. The receiver is mounted in the sail and contains of am optical telescope with a dynamically tunable cadmium sulfide birefringent filter with a +/- 60° field of view tuned to receive optical signals in the 430-530 nm wavelengths. Cesium vapor inside the birefringent filter absorbs the photons at the specific wavelength of the laser and re-emits them at near infrared wavelengths which are then converted into voltages using a large InGaAs photodetector array. The use of blue-green lasers allows satellite communicate with the submarine at depths of up to 100 meters even through polar ice caps without extending any antenna past the surface. In addition to being unjammable the blue-green laser communications system has a data transfer rate several hundred times greater than legacy VLF/ELF systems traditionally used to communicate with submerged submarines.

UKS 900 Multifunction Towed Communications Buoy: For communications while submerged the Erebus is equipped with an UKS 900 communications buoy deployed from the submarine's composite sail. The UKS 900 buoy features a wingless, lifting body design constructed from a glass fiber reinforced epoxy composite and is connected to the host submarine using an underwater fiber-optical tether six kilometers long which alloys the buoy to be towed behind the submarine at speeds of up to 30 knots at depths of up to 200 meters. The UKS 900 carries a multi-function mast antenna with a directionally stabilized phased array antenna which can be extended above the surface and which carries VLF, LF, and MF and receivers, HF, VHF, and UHF satellite transceivers, Automatic identification system (AIS) receivers, CIFF-SD Centralized IFF Interrogation System, and and a GPS spatial temporal antijam receiver (G-STAR) with differential GPS capability.

RMS 360 Underwater Telephone: The RMS 360 is a mid-frequency active (MFA) sonar based communications system consisting of a control station, receiver-transmitter, and sail mounted transducer array which can transmit voice, audio and low speed telegraph data in the 1.5 to 3.1 kHz and 8.3 to 11.1 kHz to and from surface ships, coastal-based shore stations, or other submarines.

SDI SirenLink Communications Buoy System: Using it's 10 cm submerged signal ejectors the Erebus class submarine is capable of launching SDI's SirenLink series of communications buoys which provide 1 way and 2-way acoustic and RF communication. The SirenLink buoys include the SirenLink 1WRF (1-way RF), SirenLink 2WRF (2-way RF), and SirenLink 2WA (2 way acoustic) buoys. All buoys are 10 cm in diameter and 1 meter in length with a mass of ~6 kg and are launched from within the submarine using the forward and aft 10 cm submerged signal ejectors (SSEs). The SirenLink 1WRF is an expandable one way communications buoy which is designed to transmit a prerecorded message from the submarine. The buoy also carries an emergency position-indicating radiobeacon (EPIRB) which can be used to transmit distress signals. Following SSE ejection the buoy ascends to the surface and then deploys an inflatable floatation device to remain on the surface while transmitting the prerecorded message using a UHF band satellite link. Alternatively the buoy can be set to a delayed release, rising to a parking depth of 20 meters where the buoy can hover for up to an hour before ascending to the surface. Following transmission the buoy then automatically scuttles itself to prevent retrieval. SirenLink 1WRF buoys can be deployed at depths up to 1,000 meters at speeds up to 20 knots. The SirenLink 2WRF is a fiber optic-tethered expendable buoy which is designed to provide two-way UHF SATCOM communications using a 20 kilometer long fiber optic cable between the buoy and submarine. Following SSE ejection the buoy splits into a towed and surfacing section where a high strength fiber optical fiber tether unspools from the rear of the surfacing section as it ascends to the surface. When the buoy reaches the surface the forward inflatable floatation and wings are then released, keeping in on the surface while the UHF antenna then establishes a communications link between the submarine and an orbiting satellite, sending a pre-set message to alert the base station that the submarine wishes to begin transmission. SirenLink 2WRF buoys have a maximum endurance of 6 hours and can be deployed at depths up to 600 meters at speeds up to 10 knots. The SirenLink 2WA is a two-way acoustic gateway which allows data to be acoustically transmitted from the submarine and then relayed via satellite and vice versa. Following ejection the buoy floats to the surface (with an optional delayed release) and broaches the surface, deploying its floatation device and establishing satellite connection with its UHF SATCOM antenna, sending a pre-set message to alert the base station as with the SirenLink 2WRF buoy. As this happens the buoy also deploys its low frequency acoustic transducer to the preset depth set as a function of local thermal layers and acoustic propagation characteristics which then establishes an acoustic communications link with the submarine through its RMS 360 underwater telephone. The SirenLink 2WA buoy can be deployed at depths up to 1,000 meters at speeds up to 20 knots and can maintain communications with the submarine at distances of up to 90 kilometers depending on local acoustic propagation characteristics. The buoy has a maximum endurance of three days and contains a thermal battery enabling two hours of satellite transmission time and one hour of full-power acoustic transmission time.

SDI Strategic Navigation System: The navigation system of the Erebus class consists of an SDI Strategic Navigation System, a type of gravity aided inertial navigation system (GAINS) which combines an SDI TNS 110 strategic grade 6 axis inertial measurement unit with a gravimeter and three gradiometer sensors which uses gravity field measurements correlated with gravity map data to produce absolute position references to correct IMU drift without reliance on GPS. The strategic grade TNS 110 IMU employs a 35 centimeter diameter spherical gimbal system with twin nested spherical gimbals which provides complete vibrational and thermal isolation to the system's inertial sensors. The inner sphere in the gimbal contains three interferometric fiber-optic gyros (IFOGs) and three micromachined quartz electromagnetic accelerometers mounted flush with the sphere's surface which is itself nested inside a second spherical shell separated by a small, uniform gap in turn contained inside a third sphere separated by a similar gap. The gimbal set employs a continuously rotating autocompensation mechanization (CRAM) actuated with brushless DC motors and fiber optic slip rings which along with the inter-sphere gaps provides conduction control and convection isolation to the inertial sensors with <0.05 °C temperature variation across the inner sphere surface during operation. The TNS 110 further decouples the earth's angular rotation rate using latitude-dependent small amplitude harmonics corrections which decouples earth rate rotation and the rotation rate of the gyros. The TNS 110 IMU provides <0.00002°/√hr gyro angle random walk and < 0.00001 °/hr bias stability performance and provides < 0.01 ° RMS roll & pitch accuracy and 1 NM/720h position drift rate per hour navigation performance.

The gravity sensor used with the system to augment the TNS 110 IMU consists of a gravimeter which measures gravity anomalies relative to a nominal earth model and three gradiometers which measures gravity gradient changes in three dimensions. The gravimeter consists of an accelerometer used to determine the gravitational force at sea level by measuring the gravitational acceleration at the submarine's depth and applying corrections for the Eötvös effect, submarine depth below mean sea level, and accelerations from the submarine's current depth change rate which is then subtracted from the earth gravitational model gravity to generate a gravity anomaly value. The gravity gradiometers each consists of an array of four accelerometers mounted at 90° intervals to a rotating wheel to provide measurements of gravity gradients along the baselines of accelerometer pairs, three accelerometer wheels of which are orthogonally mounted to generate inputs for a full nine element (3x3) gradient tensor measurement. The passive navigation algorithm used with the system t combines inertial measurement unit and gravity sensor data which is processed by a Kalman filter to generate IMU error estimates used to correct the IMU sensor. The algorithm uses gravimeter and gravity gradiometer measurements to determine the submarine's position on a stored gravity field anomaly maps, providing an absolute position reference which is used to correct the drift of the IMU. The system can also detect the gravity field variations caused by local terrain, allowing the submarine to generate surrounding terrain estimates which are continuously updated based on Kalman filter IMU position error estimate, providing the navigation system with terrain following and terrain avoidance modes for navigation along the sea floor.


Electronic Warfare & Countermeasures:

FLG 130 Tactical Electronic Support Measures System:The Sail of the Erebus class SSGN carries the FLG 130 Tactical Electronic Support Measures (ESM) System which provides automatic detection, classification, localization, and identification of emissions from both radar and communications systems to provide situation awareness for the submarine and intelligence-gathering capability in support of surface battle groups. The FLG 130 system additionally includes passive bistatic radar detection and tracking ability and an Integrated Vulnerability Management (IVM) system designed to provide real-time counter-detection vulnerability assessment of submarine electromagnetic emissions. The receivers of the FLG 130 are integrated into the OKS 300 photonic mast system and include a 2 to 2,000 MHz HF/VHF/UHF omnidirectional Ultra Wideband (UWB) biconical radio direction finding (RDF) antenna, 0.5 to 18 GHz fast-scanning superheterodyne radar warning receivers, 0.2 to 40 GHz omnidirectional Generic Area Limitation Environment (GALE) SIGINT antenna, and a 0.05-3 GHz Communications Acquisition Direction Finding (CADF) antenna encased in a frequency-selective low RCS omnidirectional radome. Each antenna is capable of simultaneously receiving over 500 signals and measuring frequency, modulation, PRF, pulse width, amplitude and scan interval, and direction and of arrival with 2 degrees rms direction finding accuracy. The passive radar capability of the FLG 130 radiofrequency (RF) uses energy emitted by FM radio stations, analog and digital televisions transmitters, and other broadband communications signals which are scattered off targets and collected by the BLQ-13's omnidirctional antennas. Scattered waves collected by the FLG 130 are compared using Digital Beam Forming (DBF) techniques to the signal directly emanating from the emitters which is then used to accurately determine the location and velocity of the target in three-dimensions. The passive radar capability of the FLG 130 allows up to 100 simultaneous targets including ships, aircraft, missiles, and vehicles to be passively detected and tracked at ranges up to 300 kilometers 360 degrees in azimuth and 60 degrees in elevation with +/-1,000 meters of location accuracy and +/2 meters per second of velocity accuracy for each target. The Integrated Vulnerability Management (IVM) system is built into the FLG 130 and consists of software algorithms designed to assess the counterdetection vulnerability of the submarine based on the current signal environment and antenna exposure parameters. The threat assessment capability of the IVM is designed to determine potential local counter-detection threats which are stored in an onboard threat library. Information from the IVM is displayed using an integrated graphical user interface (GUI) onto one of the BSY-3 terminals located in the CIC to a system operator who can then quickly view and analyze threat capabilities.

RMS 350 Acoustic interception and countermeasures system: For countering torpedo threats the Erebus class SSGN is equipped with the RMS 350 Acoustic interception and countermeasures system which comprises a series of passive receivers and signal processing systems designed to detect, identify, and track threat torpedoes and sonar emissions and cue appropriate countermeasures. The RMS 350 employs a total of ten sparsely populated volumetric array (SPVA) sensors distributed across the outer hydrodynamic hull and sail of the Hydra which combined provide 360 degree coverage around the submarine. Each SPVA consists of eighteen polyvinylidene fluoride (PVDF) polymer piezoelectric transducer elements embedded into a polyurethane matrix which has the same acoustic impedance as seawater. The SPVA array is controlled through fiber-optic telemetry an provides both radius-of-curvature estimation and multipath ranging of torpedo threats with fractional degree angular accuracy while also providing broadband and narrowband detection and identification of threat sonar emissions in real time. Threat information from the SPVA sensors is input into the control subsystem of the RMS 350 which has launch management capability for the submarine's external and internal countermeasure launchers and will atomically deploy appropriate countermeasures once an oncoming threat has been detected and identified.

Countermeasures tubes: For launching carious countermeasures the Erebus class SSGN is fitted with both 10 cm internal and 21 cm external countermeasure launchers. The 10 cm internal launchers, which also function as submerged signal ejectors (SSEs), look and function like miniature torpedo tubes and are used to launch mobile acoustic countermeasures along with bathythermographs and expendable communications buoys. The submarine carries two signal ejectors, one in the torpedo room and another located aft in the engineering spaces. The 10 cm SSE's are used to launch the SDI AM6 acoustic torpedo decoy, a fully programmable mobile acoustic jammer equipped with a high powered acoustic noise generator employing piezolectric single crystal composite (SCC) full-duplex transducers designed to barrage oncoming torpedoes with acoustic noise across the torpedo seeker's entire operating frequency. The AM6 features an embedded single board computer and a threat torpedo classifier designed to detect, identify, and prioritize incoming torpedo threats by comparing their acoustic signature and emissions data against a pre-programmed library of pulse repetition rate (PRR) and wavelength information of common torpedo threats. PRR and wavelength formation for friendly torpedoes and anti-torpedo torpedoes is also included in the database to prevent the decoy from inadvertent jamming a weapon launched by the host submarine. Against torpedoes using active sonar homing the AM6 will attempt to actively cancel out their signals by taking the incident sonar pulse, inverting it, and re-transmitting it electronically using its single crystal composite (SCC) transducer back to the oncoming torpedo. Should no active sonar pings be detected, indicating a passive sonar homing torpedo, the AM6 will instead emit simulated submarine noise such as propulsion and engine noise to lure the passive torpedo towards the decoy. The decoy's full-duplex transducer also functions as an underwater acoustic datalink to allow multiple AM6 decoys to communicate tactical information between themselves and the host submarine in order to share and prioritize targets. Propulsion is via an electric motor driving a shrouded propeller in the tail of the decoy which allows it hover at a pre-selected depth set prior to launch. Power for the propulsion and electrical system is by a lithium anode (LAN) thermal battery which gives the decoy an endurance of 10 minutes before it scuttles to the seafloor.

In additional to the internal 10 cm launchers the Erebus carries two sets of twelve 21 cm external countermeasures located in the bow and in the tail. Each external countermeasure launcher (ECL) comprises a self-contained pneumatic launcher with an electrical firing circuit. When the launcher is fired the gas generator system releases high pressure gases which act on a metal ram plate to force the countermeasure out of the launcher. The metal ram plate also acts as a watertight seal, preventing gases from escaping into the ocean. A series of bleed valves in the walls of the launcher are then opened to let the gasses slowly drain from the launcher. The external 21cm launchers are used to launch the AM40 Mobile acoustic decoy, an active mobile decoy designed to simulate the signature and movement of the submarine. The AM40 is 21 cm in diameter, 2.0 meters long, weighs 60 kilograms, has an operational depth of 3-1,000 meters, and is powered by an electric motor driving a shrouded shrouded pumpjet at the rear of the decoy which can propel the decoy at speeds up to 25 knots. A 3500 Wh magnesium/silver chloride seawater-activated battery pack provides power for the motor and electrical systems and gives the EMAD a maximum endurance of 1 hour at 25 knots or 15 hours at 4 knots. The AM40 features body mounted hydrophones and single crystal composite (SCC) transducers as well as a towed array containing additional hydrophones and SCC transducers which provide both passive and active signature simulation capability. In passive mode the decoy uses it traducers to emit simulating noise matching the acoustic signature of the submarine in a broad-frequency range across a wide variety of speeds and operating conditions which are pre-programmed before launch. The AM40 can also function actively where it receives sonar pings and then amplifies them a before using an echo repeater to retransmit them back to the source. An additional retraceable magnetic antenna is mounted in the tail of the decoy and is designed to alloy the decoy simulate the magnetic signatures of the host submarine.

The 21 cm external launchers are also capable of launching the SDI Underwater Systems S2s Barracuda anti-torpedo torpedo, a miniature torpedo designed to intercept and destroy oncoming torpedoes. The Barracuda is 21 xm in diameter, 2.0 meters in length, weighs 110 kilograms, and contains a 20 kilogram aluminized PBX explosive warhead triggered by a lightweight, compact micro-electro-mechanical systems (MEMS) fuse with both contact, acoustic, and water pressure sensors. The guidance and fusing system of the Barracuda is designed to explode it in front of the oncoming torpedo, creating a blast wave which crushes the nose section of the oncoming torpedo. The Barracuda has a maximum range of 10 kilometers and is powered by a stored chemical energy propulsion system (SCEMPS) which sprays sulfur hexafluoride gas from a small tank over a block of solid lithium which generates enormous quantities of heat to generate steam for a closed cycle rankine engine which drives a waterjet propulsor which can propel the Barracuda at speeds up to 60 knots at depths up to 1,000 meters. Although designed as an anti-torpedo the Barracuda can also be used to engage other submarines, naval mines, and unmanned/autonomous underwater vehicles.


Armament:

Torpedo tubes: The Erebus class SSBN carries a total of four 60 cm torpedo tubes which can be used to launch torpedoes, missiles, mines, and various remotely operated or autonomous underwater vehicles. The four torpedo tubes are connected to a torpedo room which can store up to 25 60 cm diameter weapons. Reloading of all tubes is fully automated via a series of electromechanical winches and overhead cranes along with linear motor rammer attached to each torpedo tube which results in a reload time between torpedo salvos of around five to six minutes. Each of the four 60 cm torpedo tubes is equipped with a superconducting electromagnetic firing system designed do have virtually noiseless operation in comparison to traditional compressed air or water ram systems. The system consists of the 60 cm launch tube, an impulse tank with a magnetohydrodynamic pump contained in a cryogenic dewar, and a supply tube with an open seawater interface containing silver chloride seawater electrodes. The MHD pump is made from Niobium-titanium (NbTi) superconducting electromagnets cooled to 10 degrees kelvin using liquid helium and serves to produce a magnetic field which interacts with the electric field created by the seawater electrodes. This interaction creates a lorentz force which forces the seawater from the supply tube into the launch tube, forcing the torpedo out of the tube. The only moving parts in the system are the muzzle and breech doors of the torpedo tubes and the associated vents and drains, no parts of the system move during firing which makes the process largely noiseless.

Missile Tubes: The Erebus class submarine is designed to carry a total of to 24 RBS 118 submarine-launched ballistic missiles in a set of launch tubes aft of the sail. The complete missile system includes the 24 launch tubes missile launch monitoring and control subsystem, and the loading equipment used to load the missiles into each launch tube. Each launch tube is 2.3 meters in diameter and 13.5 meters deep and consists of the launch tube, hydraulically operated hatch covers, pneumatic system, steam supply system, access hatches, and electrical and pneumatic connectors. The launch tubes are constructed from St 150 steel and form an integral part of the submarine pressure hull. At the top of the launch tube is a hydraulically actuated St 150 steel hatch cover which seals the missile tube. A locking system is also installed in the hatch covers which prevents them from being opened simultaneously with the access hatches inside the launch tubes. The launch tube is fitted with two sets of electrical connectors which break during missile launch which power the missile's guidance system and feed it trajectory information before launch. Each launch tube also has four access hatches which provide access to the missile equipment section and other parts of the missile for inspection and maintenance. Each launch tube is also equipped with a total of 11 sensors that monitor temperature, humidity, moisture quantity and pressure inside each launch tube connected to a thermal conditioning system which maintains the temperature, humidity, and pressure inside each launch tube within specified limits. An emergency water cooling subsystem is also included in each launch tube which can immediately flood the launch tube with fire if the sensors inside the launch tube detect a fire. Missile ejection from each launch tube is by a steam generator system which uses a solid-propellant gas generator which exhausts through cooling water into the base of each launch tube, creating expanding high pressure steam which then forces the missile out of the launch tube and towards the surface.
Last edited by The Technocratic Syndicalists on Tue Jul 04, 2023 5:10 am, edited 4 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Thu May 21, 2026 10:48 am

Image

Thresher Class

Basic Information:
  • Type: Midget submarine
  • Displacement: 42 t surfaced, 48 t submerged
  • Complement: 2 crew + 16 combat swimmers
  • Length: 17.2 m
  • Beam: 2.6 m
  • Draft: 2.6 m
Installed Power:
  • 6x Lithium-Polymer (LiPo) battery modules, 600 kWh total installed capacity
Propulsion:
  • 1x 90 kW shrouded propulsor
  • 4x 5 kW auxiliary maneuvering thrusters
Performance:
  • Speed:
    • Transit: 5 knots
    • Sprint: 10 knots
  • Diving depth:
    • Operating: 300 m
    • Tes: 375 m
  • Range: 200 km @ 5 knots


Overview:
The Thresher class is an one-atmosphere, dry-environment mini-submarine designed by SDI Naval Systems. The is to sixteen combat divers and two crew, enabling single-sortie, platoon-strength insertions and extractions in denied maritime environments. The features include submarine-launch compatibility with SDI Hydra class attack submarines, extended operational range and endurance through advanced Lithium-Polymer batteries, an integrated lock-in/lock-out chamber for fully submerged swimmer operations, and a comprehensive sensor suite for covert navigation in contested littoral waters.


Design & Construction:
The Thresher is built from six modules arranged longitudinally from bow to stern including the forward sensor module, pilot compartment, forward troop compartment, Lock-In/Lock-Out (LI/LO) chamber, aft troop compartment, and aft propulsion module. The forward sensor module section houses the integrated sonar transducer arrays, including the forward-looking obstacle-avoidance and navigation sonar and the hull-mounted side-looking sonar arrays along with the the retractable bow planes and bow plane hydraulic actuators. A streamlined fiberglass sonar dome encloses the forward array to minimize flow noise and protect transducer elements. This section also contains the forward trim tanks and the bow thruster assembly used for low speed maneuvering. The bow thruster assemblies are mounted in the outer hull structure flanking the bow dome, with through-hull power and control cabling passing through sealed penetrations in the pressure hull. Immediately aft of the forward sensor bay, the pilot compartment accommodates two operators in ergonomic, shock-mitigated seating positions. The compartment features a digital helm console with multi-function displays presenting integrated navigation, sonar imagery, environmental monitoring, and vehicle systems status. Control inputs for steering, depth, speed, and ballast are exercised through a digital fly-by-wire system with redundant dual-channel control paths and a direct hydraulic control backup mode. The troop compartment is split into forward and aft compartments located on either end of the central Lock-In/Lock-Out (LI/LO) chamber. Both troop compartments are configured to seat eight combat swimmers in two rows of four along the port and starboard hull sides. Seating consists of energy-absorbing, fold-down bench seats with four-point harness restraints designed to protect personnel during underwater maneuvering and potential shock events. The compartment provides stowage for individual combat equipment, weapons, demolitions, communications gear, and mission-specific payloads in overhead racks and under seat lockers. Environmental conditions are maintained at one atmosphere pressure with a controlled temperature range of 20 to 25°C, humidity control, and CO2 scrubbing. Low-signature LED lighting is provided with red-light and blackout modes for pre-mission preparation. Positioned between the troop compartments, the LI/LO chamber is a separate pressure compartment accessible from the troop compartments through a set of pressure-rated hatches. A ventral hatch in the chamber floor provides egress to the sea. The LI/LO chamber is sized to cycle four combat swimmers with full mission equipment per evolution, enabling a full sixteen-member platoon to lock out in four cycles. Although the maximum lock-out depth is operationally limited to 30 meters by diver physiology and equipment constraints, the chamber itself is rated to the full hull design pressure, ensuring structural integrity regardless of the vehicle’s depth at the time of chamber operations. The aft section houses the main propulsion motor, motor controller and power electronics, aft trim and ballast tanks, the stern planes and rudder actuators, and the aft thruster assembly. The main propulsion shaft passes through a mechanical seal to the external single-screw propulsor. The Lithium-Polymer battery modules are distributed in keel-mounted pods beneath the pressure hull, maintaining a low center of gravity for stability and keeping the battery mass outside the manned compartments for crew safety.

The Thresher vehicle construction employs a double-hull architecture consisting of a primary titanium alloy inner pressure hull enclosed within a streamlined composite outer light hull. The double hull configuration meets the vehicle's 300 meter operating depth requirement while simultaneously optimizing hydrodynamic performance, accommodating external equipment and ballast systems while minimizing the vehicle’s acoustic and magnetic signatures. The inner pressure hull is fabricated from Ti-6Al-4V titanium alloy, used for its combination of specific strength, corrosion resistance in seawater, non-magnetic properties, and fatigue performance under cyclic pressure loading. The pressure hull is a cylindrical shell with hemispherical end caps and a truncated conical section tapering to the propulsion shaft penetration. The cylindrical parallel mid-body has an internal diameter of 2.4 meters, providing adequate internal volume for the pilot compartment, troop compartment, and central LI/LO chamber. The hull is constructed from rolled and formed Ti-6Al-4V plate sections joined by electron-beam welding and gas-tungsten-arc welding. Electron-beam welding is employed for the primary longitudinal and circumferential seams of the cylindrical shell, producing deep-penetration, narrow-width welds with minimal heat-affected zone (HAZ) distortion and superior fatigue properties. GTAW is used for secondary structural joints, penetration fittings, and field-repairable connections. Pressure hull penetrations are minimized to reduce potential leak paths and stress concentrations. Each hull penetration, including the the propulsion shaft, mast housings, through-hull fittings, electrical hull connectors, and the LI/LO ventral hatch, is fitted with a forged titanium reinforcement ring that is electron-beam welded to the pressure hull shell. Internal framing consists of ring stiffeners spaced at approximately 30 cm intervals along the cylindrical shell, machined from Ti-6Al-4V bar stock and continuously welded to the inner surface of the hull plate. The ring stiffeners resist shell buckling and distribute localized loads (equipment mounts, cradle attachment points) into the hull shell. Longitudinal stringers are provided in areas of concentrated loading, particularly at the keel where the external battery pods are attached, and at the dorsal cradle interface points where the full weight of the vehicle is reacted during host-submarine carriage. Three main transverse pressure-rated bulkheads divide the interior into the pilot compartment, the troop compartments, and the LI/LO chamber, each capable of independent isolation in the event of flooding.

Enclosing the titanium pressure vessel is a streamlined outer light hull fabricated from glass-fiber-reinforced polymer (GFRP) composite laminate over a syntactic foam core. The outer hull protects the pressure vessel, external piping, and instrumentation from mechanical damage during handling, transport, cradle operations, and incidental contact with the seabed or underwater structures. The syntactic foam core provides positive buoyancy that partially offsets the weight of the titanium pressure hull, contributing to the overall weight-buoyancy balance. The outer hull lines follow a modified Myring profile, minimizing form drag while maintaining adequate internal volume. The bow section is faired into a smooth ogive with an integrated sonar-transparent fiberglass dome. The stern tapers to a truncated cone enclosing the propulsor shroud. the annular space between the inner pressure hull and the outer light hull houses equipment that does not require a pressurized environment, including the main ballast tanks, variable ballast trim tanks, high-pressure air flasks, hydraulic systems, the keel-mounted battery pod support structure, external piping runs, and cabling. the inner surface of the outer hull and the outer surface of the pressure hull are lined with viscoelastic damping tiles that absorb and dissipate waterborne acoustic energy, reducing both the vehicle’s radiated noise signature and its target strength against active sonar. The composite outer hull material itself provides inherent acoustic transparency at low frequencies, avoiding the strong shell-resonance returns associated with a metallic outer hull. The GFRP composite outer hull is also entirely non-magnetic, contributing zero magnetic signature. Combined with the non-magnetic titanium pressure hull, this eliminates the dominant hull-related contributions to the vehicle’s magnetic signature. The outer hull is constructed in modular sections that are bolted and sealed to longitudinal and circumferential flange joints. The modular construction permits removal of individual hull sections for access to inter-hull equipment during maintenance without disturbing the pressure hull. All outer hull joints incorporate O-ring seals to prevent free-flooding of the inter-hull space during normal operations. Hull-mounted equipment on the exterior of the outer hull includes the side-looking sonar transducer arrays faired into the mid-body hull sides) the forward and aft thruster housings with flush-mounted grilles, sacrificial zinc anodes for cathodic protection of any exposed metallic fittings, and retractable navigation lighting (for surface transit only).


Propulsion:
The Thresher employs a modular Lithium-Polymer (LiPo) battery system as its energy source. The battery system is organized into six independent modules housed in three pairs of external keel-mounted pods beneath the main pressure hull. Each module is a self-contained unit with its own battery management system (BMS), liquid glycol cooling loop thermal management system, cell-level voltage and temperature monitoring, and automatic fault isolation capability. The six-module architecture provides graceful degradation capability, the loss of any single module reduces total energy by approximately 17% while permitting the vehicle to continue operations on the remaining five modules. In a worst-case double-failure scenario, four modules provide sufficient energy for a reduced-speed return transit. Total installed battery capacity is approximately 600 kWh (100 kWh per module). At a transit speed of 5 knots, the propulsion system has a theoretical endurance of 20 to 24 hours and a corresponding transit range exceeding 100 nautical miles. The battery pods themselves are external to the manned pressure hull, separated by the structural keel and pressure-rated bulkheads. each of the six battery modules can be electrically disconnected from the main bus within milliseconds by pyrotechnic disconnects, removing a faulted module from the circuit before thermal propagation can occur. Each individual cell is instrumented for voltage, temperature, and impedance. The BMS continuously compares measured parameters against safe operating envelopes and initiates automatic cell disconnection upon detection of anomalous behavior. Active liquid cooling maintains cell temperatures within the optimal 20–35°C window. In the event of a cooling system failure, a passive thermal management system consisting of phase-change material wrapping individual cell group provide a secondary thermal buffer. Each battery pod incorporates a pressure-relief system that vents thermal-runaway gases directly to the sea, preventing gas accumulation. Vent paths are designed to prevent seawater ingress during normal operations. Pod interiors are flooded with inert nitrogen gas upon detection of confirmed thermal runaway, displacing oxygen and suppressing any combustion.

Main propulsion is provided by a permanent-magnet synchronous motor rated at approximately 90 kW continuous output directly driving a single-screw shrouded propulsor. The PMSM is driven by a variable-frequency drive (VFD) motor controller that converts the DC battery bus voltage to three-phase AC at the frequency and voltage required for the commanded speed. The VFD employs silicon-carbide (SiC) MOSFET power semiconductors. Power distribution from the battery modules to the propulsion motor, thrusters, and hotel loads is managed through a main DC bus operating at a nominal 350 VDC. The bus is divided into two independent port and starboard half-buses, each fed by three battery modules, with a normally-closed bus-tie that can be opened to isolate a faulted half-bus while maintaining power to critical loads from the remaining three modules. Automatic bus management software continuously monitors load distribution, battery state-of-charge, and fault conditions, performing real-time load shedding of non-essential systems (e.g., air conditioning, non-essential lighting) to extend endurance in degraded-power scenarios. The propulsor is a seven-blade, low-noise shrouded design optimized for the vehicles operating speed range. The shroud is a Kort-type accelerating nozzle that improves thrust efficiency at low speeds by approximately 15–20% compared to an open propeller of equivalent diameter, and reduces tip-vortex cavitation inception speed by constraining the blade-tip flow field. The shroud improves thrust efficiency at low speeds and reduces tip-vortex cavitation, which is both an acoustic signature concern and a visual detection risk in shallow water. Blade geometry is computationally optimized using computational fluid dynamics (CFD) to minimize tonal noise signatures at the primary operating speeds of 5–8 knots. The assembly is constructed from CuAl10Ni5Fe4 nickel-aluminum-bronze alloy, used for its combination of cavitation-erosion resistance, seawater corrosion resistance, and non-magnetic properties. The shroud is fabricated from GFRP composite. Four transverse thrusters (two forward, two aft) provide low-speed maneuvering capability for station-keeping, precise positioning during lock-out operations, and close-quarters navigation in confined waters. Two thrusters are mounted in the forward hull section (one port, one starboard) and two in the aft section, providing independent control of surge, sway, and yaw at zero or near-zero forward speed. Each thruster is an electrically driven, direct-current brushless motor driving a fixed-pitch impeller within a tunnel molded into the outer hull. Thruster tunnels are fitted with acoustically damped grilles at both the intake and discharge openings to reduce flow noise during operation. Each thruster is rated at approximately 5 kW continuous (7.5 kW peak) and produces approximately 200 N of static thrust. Thruster control is fully integrated into the digital fly-by-wire helm system, with an automatic station-keeping mode that uses inputs from the INS, DVL, and fathometer to maintain position without continuous pilot input.

The Thresher employs an X-stern appendage arrangement consisting of four X-stern planes, mounted at 90° intervals around the aft end of the outer hull immediately forward of the propulsor shroud which provide depth and pitch control during transit. Each plane is an all-moving hydrofoil with a symmetric cross-section, a span of 0.6 meters measured from the hull surface, and a chord of 0.5 meters. The stern planes are actuated by independent electro-hydraulic servo actuators, each capable of deflecting its plane through a range of ±30° from the neutral position at a rate of 10 °/s. The planes are commanded collectively for depth changes and trim control, or differentially for roll correction. The stern plane actuators receive commands from the digital fly-by-wire system, which implements an automatic depth-keeping mode holding commanded depth to within ±0.5 meters at transit speeds above 3 knots. An automatic heading-hold mode maintains commanded heading to within ±1 degree at transit speeds above 3 knots. A heading-rate (rate-of-turn) mode is also available for controlled turns. All four stern control surfaces are driven by a centralized electro-hydraulic power unit (HPU) located in the aft engineering compartment. The HPU consists of two independent, redundant hydraulic pumps each driven by a brushless DC electric motor, a shared accumulator bank, and dedicated servo valves for each control surface. Under normal operations, one pump provides system pressure while the second is on standby; in the event of a pump failure, the standby pump activates automatically within 0.5 seconds. System hydraulic pressure is 210 bar. The hydraulic fluid is a non-flammable, environmentally acceptable ester-based synthetic hydraulic fluid. In the event of a complete hydraulic system failure, a manual backup mode allows the pilot to command each stern control surface through a direct mechanical linkage operating a hand-pump hydraulic circuit providing degraded control authority for emergency surfacing. Two retractable bow planes are mounted on the forward outer hull, one port and one starboard, which provide supplementary depth and pitch control, particularly at low speeds where the stern planes have reduced effectiveness due to lower flow velocity over their surfaces. The bow planes retract flush into recesses in the outer hull when not in use, reducing drag during high-speed transit. Retraction and deployment is accomplished by electrically driven screw actuators. Plane deflection is controlled by dedicated electro-hydraulic servo actuators fed from the same HPU as the stern surfaces, with the same redundancy provisions. In the retracted position, flush-mounted fairings maintain the hydrodynamic continuity of the outer hull surface.

The main ballast tank system consists of four main ballast tanks located in the inter-hull space between the titanium pressure hull and the GFRP outer hull. The four tanks are arranged as two forward and two aft pairs (a port and starboard tank in each pair), providing both longitudinal and lateral buoyancy symmetry. Each main ballast tank is a free-flooding void space bounded on the top and sides by the inner surface of the outer hull, on the forward and aft ends by purpose-built GFRP baffles, and on the onboard surface by the outer surface of the pressure hull. Flooding and venting are controlled through hydraulically actuated Kingston valves at the tank bottoms and vent valves at the tank tops. To submerge, the vent valves are opened and the flood valves opened, admitting seawater and venting displaced air. To surface, high-pressure (HP) air from onboard storage flasks is blown into the MBTs, expelling water through the flood valves and restoring positive buoyancy. The total MBT volume is approximately 7.5 cubic meters, providing sufficient buoyancy change to transition the vehicle between the fully surfaced condition (positive buoyancy for surface transit, cradle operations, and maintenance) and the submerged neutrally buoyant condition. The HP air system consists of eight titanium air flasks rated at 250 bar, stored in the inter hull space along the keel, with a total stored air volume sufficient for three complete MBT blow-and-refill cycles—providing two emergency blow reserves after the initial dive. An LP (low-pressure) blower supplements the HP system for routine surfacing when air conservation is not critical. Fine buoyancy and trim control is achieved through a variable water ballast system that adjusts the vehicle’s weight and longitudinal center of gravity without requiring changes to the MBT state. A forward trim tank and an aft trim tank, both located inside the pressure hull, allow controlled transfer of water between the two tanks to adjust the vehicle’s longitudinal trim (fore-and-aft angle). A reversible, variable-speed electric trim pump transfers water between the tanks at a rate of approximately 50 liters per minute. The total trim tank capacity is approximately 400 liters (200 liters forward, 200 liters aft). Automatic trim control software monitors the vehicle’s pitch angle and adjusts trim pump operation to maintain commanded trim within ±0.5°. A centrally located compensating tank also allows the vehicle to adjust its overall buoyancy to achieve precise neutral buoyancy at any operating depth, accounting for seawater density variations (temperature, salinity) and changes in vehicle weight during the mission (e.g., swimmer lock-out, stores consumption, HP air usage). The compensating tank has a capacity of approximately 300 liters and is filled or drained by a variable-speed compensating pump drawing from or discharging to the sea. Fine buoyancy control to within approximately ±5 kg is achieved through precise pump metering. In addition to the water-based compensating system, a small mercury trim system is reserved for final precision fore-and-aft balancing during slow-speed operations where even minor trim angles affect depth-keeping accuracy. Emergency depth control provisions include a rapid MBT blow system capable of achieving positive buoyancy from any depth within 30 seconds using dedicated emergency HP air manifolds and a drop-keel emergency ballast release consisting of approximately 500 kg of expendable lead ballast secured to the underside of the keel structure by pyrotechnic releases. Upon command the ballast is jettisoned, immediately reducing the vehicle’s weight and initiating ascent; and emergency stern-plane full-rise, where the digital control system automatically commands full-rise on both stern planes upon activation of the emergency ascent switch, establishing a positive ascent rate regardless of speed or trim condition.


Signature Reduction:
Designed to operate in contested maritime environments, the Thresher features extensive acoustic, magnetic, and visual signature features for operations in heavily monitored littoral waters where adversary coastal defense sensor networks, ASW patrol craft, and mine warfare systems may be present. Acoustic signature reduction measures applied to the vehicle the use of a permanent-magnet synchronous propulsion motor with inherently low noise characteristics (no commutator, no brushes, no gear reduction), a shrouded propulsor designed to suppress blade-rate tonal signatures and tip-vortex cavitation, vibration-isolated mounting of all rotating machinery on resilient mounts, acoustic enclosure panels around the propulsion motor and power electronics, anechoic coatings applied to external hull surfaces to reduce target strength against active sonar, and flow-noise optimization of all external hull appendages. The hull is constructed from non-magnetic materials, minimizing the vehicle’s magnetic signature against magnetic anomaly detection sensors. Ferromagnetic components that cannot be eliminated are degaussed during construction and periodically during maintenance. A passive degaussing system using strategically placed permanent magnets compensates for residual magnetic fields. The hull exterior is coated in a low-reflectivity, dark-gray anti-fouling paint scheme optimized for low visual contrast in the blue-green water column typical of littoral operating areas. The shrouded propulsor design minimizes propeller wake and bubble entrainment. Operating depth is maintained at a minimum of 10 to 15 meters during transit to prevent visual detection from surface observation or airborne surveillance.


Sensors & Processing Systems:
Sonar: The Thresher incorporates a comprehensive sonar suite designed for covert navigation, obstacle avoidance, mine detection, and environmental awareness in the shallow-water littoral environments. The primary navigation and obstacle-avoidance sensor is a high-frequency forward-looking sonar housed within the fiberglass bow dome. The FLS operates in the 100–200 kHz frequency band and provides a real-time, high-resolution acoustic image of the water column and seabed ahead of the vehicle out to a maximum detection range of approximately 500 to 800 meters. The FLS is capable of detecting moored and bottom mines, submerged obstacles, underwater structures, and other vessels. The system provides both plan-view (horizontal) and profile-view (vertical) display modes. An automatic obstacle-detection and collision-avoidance algorithm provides audible and visual alerts when a hazard is detected within a configurable safety zone, typically set at 100 to 200 meters during transit. Side-looking sonar arrays on the port and starboard outer hull surfaces provide lateral environmental awareness and mine-detection capability. Operating in the 300 to 500 kHz range, the SLS generates high-resolution acoustic imagery of the seabed and water column to each side, with a swath width of approximately 100 to 200 meters per side depending on water conditions. The side looking arrays extends the mine-detection envelope beyond the FLS’s forward cone, and it provides a seabed-mapping capability that supports terrain-referenced navigation and post-mission intelligence reporting. A hull-mounted fathometer provides continuous depth-under-keel measurement for safe navigation in shallow and variable-depth littoral waters. The system is integrated with the navigation computer to provide automatic depth alerts when clearance falls below configurable thresholds.

Photonic Mast: For surface observation the Thresher is equipped with SDI's OKS 150S ultra-low profile search mast, a multifunction non-hull penetrating optronic mast which integrates optronic sensors and electronic warfare in a low-profile package designed to minimize visual, infrared and radar signature. The photonic mast is the Manta's primary means of above-water situational awareness, enabling visual identification of surface contacts, collection of SIGINT/COMINT data, and confirmation of targeting data before engagement or reporting. The retractable mast is actively 3-axis gyro stabilized with image roll stabilization and features 360°azimuth and 10° to +55°elevation capability and houses three optical sensors: a Visible/SWIR (visSWIR) dual band color camera module operating in the visible (0.4-0.7 μm) and SWIR ( 0.9-1.7 μm) spectral range with 3840 x 2160 pixel resolution and continuously variable 32° x 18° to 1.6° x 0.9°field of view, a third generation staring mid-wave infrared (MWIR) thermal imager with 640 x 480 pixel resolution and continuously variable 12° x 9° to 2° x 1.5° field of view, and a 10 km range eye safe Nd:Yag laser rangefinder module. The top of the mast also includes a universal antenna interface for integral EW/ESM and direction and dual L1/L2 band GPS antennas.

Communication Mast: The Thresher features a second retractable mast, housed in a separate fairing next to the photonic mast, which provides the vehicle with external long-range communications capability. This mast incorporates VLF/LF receive (10 kHz to 170k Hz), MF/HF Transceiver (2 MHz to 30 MHz), VHF LOS transceiver (30 MHz to 174 MHz), VHF/UHF LOS transceiver (225 MHz to 400 MHz), VHF/UHF SATCOM transceiver (240 MHz to 400MHz), IFF Transponder, and L1/L2 GPS receive antennas which are all integrated into a low profile hydrodynamic fairing. The mast is capable of simultaneous transmission and reception for all functions with spatial coverage allowing communication from low angle, line of sight surface assets to high and low angle satellite assets.

Navigation System: The Thresher navigation suite consists of an SDI TNS 200 fiber-optic gyro inertial measurement unit coupled with a Doppler velocity log (DVL) for bottom-tracking. The SDI TNS 200 fiber-optic gyro inertial measurement unit (IMU) inputs 6-axis guidance and control information to the tactical computer cluster and consists of a strapdown unit with 3 fiber-optic gyros and 3 MEMS quartz accelerometers with <0.1°/hr bias and <0.008°/√hr random angle walk performance. The INS provides continuous dead-reckoning navigation without external emissions. INS drift is periodically corrected by GPS fixes obtained via the photonic mast and by DVL-aided terrain-referenced navigation when operating near the seabed. The navigation computer integrates all sensor inputs into a unified digital chart display on the pilot’s multi-function screens, presenting a real-time tactical picture of the vehicle’s position relative to charted features, the host submarine, mission waypoints, and the objective area.


Crew Compartment:
The Thresher life support system is designed to maintain a breathable one-atmosphere environment for up to 18 personnel across a mission durations of 36+ hours, with an emergency reserve extending to 72 hours at reduced activity levels. The atmosphere management system includes hhigh-pressure gaseous O2 storage cylinders with metered release maintaining ppO2 between 0.20 and 0.22 atm. Backup chemical oxygen generation system (chlorate candles) for emergency use. A lithium hydroxide (LiOH) canister scrubber system maintaining CO2 below 0.5% (5,000 ppm). Canisters pre-loaded for planned duration plus 100% reserve margin.
Trace contaminant control: activated-charcoal filtration removing VOCs, carbon monoxide, and hydrogen. Temperature and humidity control consists of closed-loop chilled-water air conditioning maintaining 18–24°C and 40–60% relative humidity. The troop compartment features energy-absorbing seating for all sixteen operators, stowage for personal weapons and equipment, potable water dispensers, individual hydration systems, and basic ration stowage. Lighting is provided by dimmable LED panels with selectable white, red, and blue-green modes. Sound-powered telephone handsets at each seating position provide intra-vehicle communication. A compact head facility is located adjacent to the LI/LO chamber.

The LI/LO chamber is a cylindrical pressure compartment integral to the titanium pressure hull, with an internal diameter of 1.8 meters and an internal length of 2.4 meters. It is accessed from the troop compartments through a set of inward-opening pressure hatch rated to the vehicle’s full 375nmeter design depth. The ventral hatch is a hydraulically actuated, outward-opening door measuring 1.2 meters by 0.9 meters, providing sufficient clear opening for a fully equipped combat swimmer. The ventral hatch and its reinforcement ring are among the most heavily engineered components of the pressure hull, incorporating a double-seal arrangement with inter-seal leak detection and a mechanical lock-bar system that positively prevents inadvertent opening under external hydrostatic pressure. The chamber is equipped with internal handholds, non-skid surfacing, a diver communication system (through-water acoustic comms and hardwired intercom), internal and external lighting (red/blue-green selectable), a depth gauge, and emergency breathing-air supply stations. A set of small observation windows in the forward pressure hatch allows the troop compartment crew to visually monitor chamber operations. The LI/LO chamber cycles four swimmers per evolution, requiring four complete cycles for a full platoon. The nominal cycle time per group is approximately 8–10 minutes. Total platoon lock-out time is approximately 35–40 minutes. During lock-out operations, the vehicle maintains station-keeping using its four transverse thrusters, bow planes, and compensating/trim systems, with the main propulsor secured to minimize flow disturbance around the ventral hatch. The LI/LO chamber incorporates multiple safety interlocks. The forward hatch and ventral hatch are mechanically interlocked so that only one can be open at any time. An emergency drain pump evacuates the flooded chamber in under 90 seconds. emergency breathing air is supplied from dedicated high-pressure cylinders, and all chamber operations can be controlled from either inside the chamber or from a control panel in the forward troop compartment.
Last edited by The Technocratic Syndicalists on Wed Aug 26, 2026 9:44 am, edited 3 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Thu Jun 25, 2026 7:17 pm

Image

Aurora Class

Basic Information:
  • Role: Surface Effect Ship Ferry
  • Displacement: 24,000 t
  • Complement: 200 crew + 2,500 pax
  • Length: 270 m
  • Beam: 60.0 m
  • Draft: 3.0 m (on cushion), 6.5 m (off-cushion)
Propulsion:
  • 8x SDI GT8000 marine gas turbines, 80 MW each
  • 8× Variable-geometry centrifugal lift fans
  • 8x SDI SS300 waterjets

Performance:
  • Top Speed: 80 knots
  • Cruise Speed: 75 knots
  • Range: 1,500 nm @ 75 knots


Overview:
The Aurora is a high-speed surface-effect-ship car/passenger ferry. Designed for sustained service speeds of 75 knots in Sea State 4 and sprint speeds of 80 knots, the Aurora can carry 1,250 passenger cars or equivalent mix of cars and commercial trucks together with 2,500 passengers on routes of up to 1,500 nautical miles.


Design & Construction:
The Aurora lass vessels have a length of 265 meters, beam of 58.0 meters, and a full load displacement of 24,000 tonnes. The hull is a twin sidehull SES with full length side hulls, a bridging cross structure, and flat wet deck. The sidehulls are slender, low aspect ratio wave piercing hulls which transmit cushion pressure to the water surface via seal contact, contain the air cushion laterally, and provide hullborne flotation when the cushion is deflated. The sidehull bow is a deeply raked wave piercing design with a fine entry angle to minimize pitch motion when transiting steep wave fronts. The inboard face is vertical and forms the lateral cushion containment face while the outboard face flares outward from a near vertical waterline segment to provide reserve buoyancy in heel and to accommodate the sidehull machinery. Aft the sidehulls terminate in transom sterns housing the waterjet steering nozzles with a fine stern wedge to control trim moment and reduce stern wake interference with the cushion.The air cushion is bounded laterally by the twin sidehulls and fore and aft by flexible elastomeric seals. The bow seal is a multi-finger bag and finger lobed configuration with a primary inflated bag that forms the seal envelope and multiple individual planing fingers that contact the water surface. The stern seal is a two-loop planing flap hinged at the wet deck and tensioned by internal cushion pressure against an external tensioning structure. Both seals are fabricated from a multi-ply elastomer reinforced with woven aramid and high modulus polyethylene fibers with a chlorosulphonated polyethylene wear surface for abrasion resistance and chemical stability. Service life is approximately 8,000 operating hours for the bow fingers, with planned replacement during scheduled drydock. The wet deck is a stiffened plate structure spanning the 30 meter gap between the side hulls, forming the cushion ceiling and the structural floor of the lowest cargo deck. The wet deck spanning between the sidehulls supports the vehicle decks above and withstands the cushion pressure and wave-slam loads below. Full keel-length fences reduce cushion venting and waterjet inlet air ingestion. The Aurora hull is constructed primarily from LASCOR ( LASer-welded corrugated CORe) sandwich panels formed using 1,650 MPa strength maraging stainless steel (Fe-14.5Cr-6.5Ni-0.8Ti-0.75Mo) combining the high specific strength of 18Ni aerospace maraging steels with chromium content sufficient to provide seawater corrosion resistance comparable to Type 316 stainless steel while retaining full weldability without preheat or post weld heat treatment in section thicknesses necessary for marine primary hull structures. The LASCOR sandwich panels consisting of a corrugated metal sheet core sandwiched between two flat outer face sheets, reducing structural weight by 15% to 30% when compared to conventionally stiffened or fabricated structures. The passenger superstructure above the vehicle decks is constructed from CFRP and glass/epoxy composite sandwich panels on a steel subframe, saving approximately 1,200 mt compared to a steel superstructure. The composite construction also provides superior thermal insulation and acoustic damping. The superstructure is divided into four passenger decks plus the bridge/navigation deck. The composite superstructure is protected with an intumescent passive fire protection coating consisting of mineral fiber reinforced ceramic. Machinery spaces are protected by both a high pressure water mist system and a backup nitrogen inert gas system, and the vehicle decks employ a deluge system with flow rate 10 L/min per m² and a forced ventilation system that can rapidly clear tghe vehicle deck of fuel vapor. Compartmentation is configured around A60 transverse bulkheads at 35 meter intervals enclosing seven main fire zones.


Propulsion
GT8000 Gas Turbine
  • Type:Aeroderivative gas-turbine
  • Length: 8.7 m
  • Width: 3.6 m
  • Height: 4.5 m
  • Weight: 11,500 kg
  • Compressor: 5 stage LPC, 10 stage HPC
  • Compression ratio: 30:1
  • Combustor: annular combustor
  • Turbine: 2 stage HPT, 5 stage LPT, 6 stage PT
  • Thermal efficiency: 45%
  • Specific fuel consumption: 170 g/kW-hr
  • Output: 80,000 kW
  • Fuel: F-76, F-44, DFM, LNG
The Aurora main propulsion plant consists of eight SDI GT8000 dual-fuel marine gas turbines, four in each sidehull in a 2x2 configuration, with each gas turbine mechanically coupled through an epicyclic reduction gear and composite drive shaft to a two stage axial flow waterjet thruster. Each GT8000 module occupies an isolated compartment within the sidehull and immediately adjacent wet deck, fully bounded laterally by A60 bulkheads and by A30 decks above. Each module contain an SDI GT8000 gas turbine with its inlet, exhaust, and acoustic enclosure, one heat recovery steam generator (HRSG) with associated steam piping, one dual stage epicyclic reduction gear, and local module control and instrumentation system. Each GT8000 is rated at 80 MW at a thermal efficiency of approximately 45%. The GT8000 features a marinized intake plenum with three stage moisture separation and demisting and a fully dual-fuel combustion system optimized for natural gas and capable of operation on marine gas oil as a contingency. Each GT8000 is mounted on a vibration isolated within an acoustic enclosure rated for 78 dBA at 1 meter exterior. The intake system draws from the upper deck overhead and incorporates a chevron staged moisture separator with electrically heated demisting elements for cold weather operation. Exhaust is ducted vertically through the HRSG to exhaust ducts which vent out directed through the transom. The Aurora class operates on liquefied natural gas (LNG) as its primary fuel, with marine gas oil (MGO) carried as a backup for emergency operation. LNG is stored at -162°C in four Type-C bilobe cryogenic pressure vessels, two bow and two stern, each of approximately 500 m³ usable capacity for a total of approximately 1,000 tonnes of LNG. The fuel gas conditioning system is distributed across all eight machinery modules with a centralized vaporizer/heater bank and comprises a low-pressure pump within each tank delivering saturated LNG at 5 bar to the main vaporizer, a glycol-water heated shell and tube vaporizer/superheater raising the gas to 45°C at 8 bar, a master pressure control valve, and a final filter and gas chromatograph monitoring system. From the conditioning skid gas is distributed to the eight turbines through a double walled stainless steel header with continuous inert nitrogen annulus monitoring. Gas pressure at each turbine fuel manifold is regulated to 5.5 bar. Boil off gas is consumed by the gas turbines and never vented to atmosphere in normal operation. During port stays or hull-borne operation, BOG is consumed by a small dual fuel auxiliary engine driving an emergency generator. Tank pressure is allowed to rise to 4.2 bar gauge during extended idleness before any reliquefication or venting is required, providing approximately 80 hours of boiloff accumulation capacity. Bunkering is performed through dedicated ship-shore connections on both port and starboard sides amidships, allowing the vessel to bunker from either pier or from a bunker vessel alongside. The connections comply use a dry disconnect cryogenic coupling with both vapor return and inert purge connections. The full bunkering operation, including pre cool, transfer, and post cool, takes approximately 60 minutes at a transfer rate of 800 m³/hr per arm with two arms in parallel.

Each GT8000 power turbine output at 3,600 rpm is connected via a torsionally tuned flexible elastomeric coupling to a two stage epicyclic reduction gear which drives each waterjet thruster at 600 rpm through a composite drive shaft. The primary reduction is a compound planetary arrangement with two stages consisting of a 2:1 first-stage star epicyclic followed by a 3.33:1 second stage planetary reduction. The first stage uses a fixed annulus and rotating planet carrier as input with the output taken from the sun gear; the second stage uses a fixed annulus, rotating planet carrier as output to the waterjet, and a rotating sun gear input. This split stage approach reduces peak tooth loads and allows the high-speed first stage gears to be lighter and smaller while the heavy second-stage absorbs the bulk of the torque amplification. All gear teeth are case-carburized and ground to DIN 5 accuracy. Gear bodies are forged 18CrNiMo7-6 and supported by hydrodynamic journal bearings on the carriers and tilting pad thrust bearings on the high speed pinions. The lift fan turbines drive the lift fans through a single-stage star epicyclic gear unit with a 3:1 ratio. The composite drive shaft connecting the primary reduction gear output to the waterjet impellers is a filament-wound CFRP tube of 850 mm outer diameter, 18 mm wall thickness, and 12 m length, with titanium-alloy end fittings bonded and pinned to the composite tube. The eight waterjets are three stage designs with an inducer, a mixed-flow main impeller, and an axial booster. Each is sized for an inlet flow of approximately 400 m³/s at 600 rpm impeller speed, producing a jet velocity of 60 m/s at design point and a static thrust of approximately 1,200 kN at 80 knots ship speed. The inducer is a low-speed, large-diameter axial-flow inducer providing sufficient suction side head rise to suppress cavitation at the entry to the first main impeller across the full speed envelope (0 to 80 knots). The inducer operates at a rotational speed approximately half that of the main impellers, driven at reduced speed through a concentric epicyclic reduction within the pumpjet housing. The inducer blading is cast Ti-6Al-4V with swept leading edges optimized for minimum tip vortex cavitation. The mixed flow impeller operates at the primary rotational speed providing the majority of the head rise. The mixed flow geometry achieves a balance between the high head rise of a centrifugal impeller and the high flow coefficient of an axial stage, optimized for the operating point at 80 knots. The impeller is a monolithic casting in Ti-6Al-4V with hot-isostatic-pressed (HIP) post-processing for maximum fatigue life. An axial-flow booster stage downstream of the main impeller provides the final increment of head rise needed to achieve the required nozzle exit velocity at 80 knots. At lower ship speeds the booster is effectively unloaded by the variable geometry inlet’s scheduling of flow rate versus pump speed. The booster is a 3-stage stator-rotor arrangement with Ti-6Al-4V blading. Each pair of pumpjets (inboard/outboard) in each sidehull is fed from a single semi flush seawater inlet with a continuous-member variable geometry ramp roof. The ramp roof position is modulated by a hydraulic actuator as a function of ship speed, pump speed, and sea state, scheduling the inlet throat area to maintain optimal pressure recovery and cavitation margin across the full operating envelope. At low speeds, the inlet is wide open to maximize suction head; at high speeds, the ramp closes progressively to match the inlet area to the reduced volumetric flow demand at higher system pressure. Full keel-length sidehull fences, combined with inlet side plates, prevent cushion air ingestion (broaching) into the pumpjet inlets. An active broach detection system using differential-pressure sensors at the inlet lips provides input to the propulsion control system, which limits HTS motor speed to prevent pumpjet overspeed events under broaching conditions. A hydraulically deployable reversing bucket diverts the jet forward for astern thrust and braking. The bucket is configured to direct the reversed flow in a downward outward direction to avoid recirculation into the next downstream inlet.

The Aurora lift fans and main electrical generators are powered by steam turbines fed from exhaust heat recovery boilers that recover waste heat from the eight gas turbine exhausts. Eight heat recovery steam generators (one per gas turbine, four per side) supply superheated steam through a common ring header to two large marine steam turbines, one located in each sidehull forward machinery compartment. Each steam turbine drives four rotating diffuser lift fans in tandem on a common composite shaft plus one permanent magnet electrical generator connected through a clutched separate reduction gearbox at the outboard end of the fan drive shaft. Eight HRSGs are installed, one per gas turbine, each mounted directly in the gas turbine exhaust stack. Each HRSG is a natural circulation two pressure once through unit which contains a high pressure superheater (steam exit 530°C, 110 bar), high pressure evaporator, high pressure economizer, intermediate pressure superheater (steam exit 320°C, 24 bar), intermediate-pressure evaporator/economizer, and low-pressure economizer/feedwater heater. The four HRSGs in each side hull are cross connected through a common HP steam ring header and LP steam ring header, allowing each steam turbines to draw flow from any subset of the four Each of the two steam turbines is a two cylinder condensing marine steam turbine rated at 72 MW continuous with high pressure and low pressure cylinders on a common output shaft with an integrated moisture separator/reheater between the cylinders. The steam turbines are dual fuel tolerant on the steam side and can be operated with reduced or interrupted steam flow without overspeed or thermal shock damage. Steam condensate is returned from each steam turbine's condenser (seawater-cooled, dual-tube-plate construction with titanium tubes for corrosion resistance) through a two-pump chain (condensate extraction pump and boiler feed pump per side) to the two closed-loop feedwater systems supplying the eight HRSGs. Feedwater treatment is through two-stage demineralization with polishing ion exchange resulting in feedwater conductivity below 0.15 µS/cm at the HRSG inlet. Total feedwater/steam inventory is approximately 130 tonnes across both loops.Each steam-turbine output shaft(at 3,600 rpm drives a two stage epicyclic reduction gear with 3:1 reduction ratio producing 1,200 rpm at the input to the integrated fan and generator drive shaft. Each of the two steam turbine driven train includes four lift fans followed by a clutched permanent magnet generator on a common composite drive shaft. The drive shafts use a CFRP tube of 480 mm outer diameter and 25 mm wall thickness with a torsionally tuned elastomeric coupling between the gearbox output and the fan input to isolate fa -induced pulsation from the gearbox. All composite shafts use a quasi-isotropic stacking sequence in the central portion of the tube, transitioning to a ±15° angle-ply at the metallic end fittings to maximize torque transfer at the bond line. Bond lines use a structural epoxy adhesive co-cured with the laminate supplemented by tapered titanium pins through both the tube and the end fitting for failsafe redundancy. Each fan consists of 3.0 meter diameter rotor with titanium-alloy impellers, double axial inlets, and variable inlet guide vanes for ride control modulation. Each fan is a single-stage radial-tipped centrifugal compressor with a vaned diffuser. Actuated geometry elements include variable inlet guide vanes that pre-swirl the inlet flow, controlling work input and shifting the fan characteristic curve laterally,)variable diffuser vanes that control the diffuser passage area, adjusting the pressure-recovery characteristic and stall margin; and a variable inlet bell-mouth area set by a circumferential iris ring that reduces inlet area at low flow to maintain inlet velocity and prevent inlet recirculation. At zero ship speed with cushion deflated the fan is at minimum speed and minimum geometry (inlet partially closed, IGVs at maximum positive incidence, diffuser vanes at restricted area) to provide a small flow at very high pressure ratio, initiating cushion inflation. As the cushion fills and pressure rises toward design value, geometry opens progressively and the fan tracks the cushion inflow demand. At hump speed (20 knots), seal-water interaction is at its maximum and air leakage from beneath the seals is highest, the fan runs at maximum flow with geometry fully open. Beyond hump speed as the vessel accelerates onto the cushion and seal contact stabilizes leakage decreases and the fan progressively closes its geometry. At design cruise speed the fan operates at moderate flow and high pressure ratio, with the active ride control system superimposing high-frequency, small-amplitude flow modulation on the baseline operating point to actively manage cushion pressure ripple in seaway.

The Active Ride Control System (ARCS) is a closed-loop control system that fuses measurements from forward looking LiDAR, inertial measurement units, and pneumatic cushion pressure and seal position sensors to derive optimal control commands for six effector categories. Control law execution runs at 200 Hz on a quad redundant computing system with three-out-of-four voting at the output stage. The forward looking wave-profiling LiDAR is a pair of solid state LiDAR systems mounted on the bridge wings approximately 35 m above the design waterline, providing a forward-scanning beam pattern that maps the three dimensional wave field over a sector extending approximately 30° to either side of the bow and from 100 m to 1,200 m range ahead of the vessel. The LiDAR unit use a 1,550 nm wavelength solid-state laser with a pulse energy of 50 µJ at a repetition rate of 200 kHz, yielding a scan refresh rate of 5 Hz across the full forward sector. Range resolution is 30 cm and angular resolution is 0.05°, sufficient to resolve individual wave crests at 1 km range under all design sea states. Two LiDAR units are installed, one each on the port and starboard bridge wings, providing both a wider field of view through field overlap in the bow region and full redundancy against the failure of either unit. Both heads are climate-controlled in a pressurized enclosure with a sapphire window heated to prevent icing and fitted with a hydrophobic surface treatment. A high pressure freshwater wash system removes salt deposits at 20 minute intervals. Raw LiDAR returns are processed in three stages. First a clutter rejection filter removes returns from precipitation, fog, and sea spray based on multi-pulse statistical analysis. Second a wave-surface reconstruction algorithm fits a continuous water-surface elevation field to the cleaned point cloud using a constrained spline representation. Third a wave propagation model advances the reconstructed surface forward in time using a deep-water linear wave dispersion relation to predict the surface profile at the vessel position as a function of forward time. The ARCS commands a total of six groups of actuators. The cushion pressure modulator consists of eight high-bandwidth bleed valves, one per machinery module, that vent excess cushion air to atmosphere on command. Each valve is a butterfly and-pinion design driven by a servo-hydraulic actuator. Symmetric venting reduces cushion lift, differential venting (port vs starboard) reduces lift on one side preferentially providing roll-axis control. The fore seal geometry is actuated by twelve hydraulic jacks distributed across the bow seal width. Coordinated extension changes the effective cushion length and trim while selective extension at port or starboard adjusts roll trim. T-foils mounted forward beneath each sidehull provide hydrodynamic vertical force in response to changes in foil angle of attack. Each T-foil has a 4.0 m span and 1.2 m chord with hydraulically actuated trailing-edge flaps providing ±15° flap deflection for high-frequency heave and pitch damping. Stern flaps integrated into the transom across the full beam, provide low frequency trim adjustment and contribute to wave-making resistance reduction at intermediate speeds. Waterjet steering nozzles are commanded for both course control and yaw damping . The ARCS adds small-amplitude differential nozzle motion to the autopilot command to cancel wave induced yaw moments. Lift fan flow modulation, achieved by simultaneous coordinated motion of the VIGV and diffuser vanes across all eight fans, provides a high authority command on cushion pressure baseline. The ARCS uses fan modulation to manage the long term cushion pressure trim while the cushion vent valves manage high frequency excursions.

The Aurora uses an integrated Medium Voltage Direct Current (MVDC) electrical distribution architecture at a 3 kV main bus voltage. Distribution is divided into four longitudinal electrical zones with each zone containing its own zone electrical distribution center(ZEDC), local battery energy storage, and emergency diesel generator backup interface. Primary generation is supplied by two permanent magnet synchronous generators, one at the outboard end of each integrated fan drive shaft. One of the two PM generators is engaged at any time under normal operation while the other is disconnected and on standby. Each generator alone is sized to supply the entire ship service electrical load with margin. Each of the three electrical zones incorporates a Battery Energy Storage System (BESS) integrated at the ZEDC level. The BESS provides generator changeover ride through, buffering the 1.5 second active-to-standby transfer without interruption of vital loads, maneuvering peak shaving (absorbing the short-duration high-current demands of bow thrusters, waterjet reversing, and ride control transients), shore power interface, and emergency vital load supply (providing 60 minutes of vital load electrical power in the event of complete generator failure, sufficient for emergency plant restart or for controlled passenger evacuation). Two emergency diesel generators rated at 4 MWe each, fueled from marine gas oil from an 80 tonne reserve tank, are located in the emergency generator compartments in each sidehull. The emergency generators are sized to supply full vital electrical load in the event of complete failure of both PM generators and total BESS depletion, giving approximately 48 hours of full load emergency operation on the reserve fuel tank. Emergency generator startup and load transfer is fully automatic. Shore power interface at each embarkation terminal permits the vessel's electrical loads to be supplied from shore during passenger and vehicle turnaround, minimizing in-port air emissions and reducing wear on the shipboard generators. Standard high voltage shore power interface is at 6.6 kV / 60 Hz and supports up to 12 MW shore power draw, sufficient for the vessel's full in-port hotel load including HVAC, lighting, and vehicle deck ventilation.


Vehicle Decks & Cargo Handling:
The Aurora carries vehicles on three full width decks above the cushion plenum and below the passenger superstructure. From bottom to top the vehicle decks consist of the Commercial Vehicle Deck, Main Car Deck, and Upper Car Deck. The Commercial Vehicle Deck floor is integral with the wet deck structure and lies approximately 9.6 m above the cushion borne waterline while the UVD lies 16.2 m above the waterline. All vehicle decks are sealed against fluid leakage and drain to dedicated holding tanks that are emptied in port. The Commercial Vehicle Deck ( 7,200 m²) is the main commercial deck, sized to accommodate the full range of vehicles (maximum vehicle height 4.2 m, length 18.75 m, weight 44 tonnes) and has ~160 truck/coach spaces (13.5 m lane) with a clear height 5.0 m, accessed directly from the bow ramp, accommodating heavy goods vehicles up to 44 mt GVW, touring coaches, caravans, and motorhomes. Hazardous-cargo vehicles are accommodated in designated ventilated zones. The Main Car Deck ( 6,800 m) has ~700 car spaces with a clear height 3.0 m and is accessed directly from the stern ramp and accommodates standard cars, SUVs, and vans with an automated car parking guidance system. The Upper Car Deck (5,500 m²) has ~550 car spaces with a clear height of 3.0 m and accessed via internal ramps from Deck 3, accommodating cars and light commercial vehicles up to 3.5 mt GVW. Total vehicle deck area is 28,600 m² with a net parking area of 19,800 m. Total capacity is 1,250 cars + 160 trucks/coaches, or equivalent mixtures. Total lane meters is approximately 3,400. All vehicle decks are equipped with fixed fire detection loops, drencher systems, and powered exhaust ventilation. Lashing eyes are on a 1.0 m grid for securing in on cushion operation. Vehicle access is provided by hydraulically actuated bow and stern ramps. The bow ramp is a single-leaf, three-tier folding ramp 25 meters wide rated for 44-mt GVW, capable of mating with shore facilities at deck heights from 2.5 m to 9.5 m above quay level. The stern ramp is an identical mirrored unit. Target turnaround time is 60 minutes for all vehicles off, fuel/stores, all vehicles on at a dedicated berth with dual-level linkspan. The turnaround time combined with the 70 knot cruise speed enables up to two round trips per day on routes up to 500 nm. Both ramps fold upward into the bow and stern doors and are hydraulically locked in the closed position during transit, contributing to the bow and stern watertight envelope. All vehicles on all decks are secured during transit by deck mounted wheel chock systems. The chock system uses recessed retractable chock blocks mounted in deck-embedded sockets at 1.0 m x 1.0 m grid spacing, chocks deploy automatically once a vehicle is parked in position. Heavy commercial vehicles on the CVD are additionally lashed with conventional chain lashings to deck-mounted D-rings. The active ride control system limits transverse and longitudinal accelerations on the vehicle decks to less than 0.15 g and 0.25 g respectively under all design conditions, well within the static-friction limits of typical road tires on the deck surface. Vehicle deck ventilation is sized for 20 air changes per hour in normal operation and 30 air changes per hour in fire/fume condition. Air is supplied via overhead manifolds running the length of each deck and extracted at the deck edges and through the ramp bays. Carbon monoxide and combustible gas detectors at 60 locations per deck monitor air quality and automatically increase ventilation rate if thresholds are exceeded.


Passenger Accommodations:
The Aurora's passenger accommodations occupy four full passenger decks (Decks five through eight) plus partial upper deck spaces totaling approximately 22,000 m² of enclosed passenger area. The accommodations are structured around two service tiers. Open seating sold as the base fare comprises 1,400 reclining seats in airline style wide-body aircraft configuration across two seating cabins with overhead luggage bins, personal entertainment screens, USB/AC power at every seat, and panoramic windows, with forward and aft economy lounges with bar service. Suites comprise 400 private cabins with two to four berths sold at a substantial fare uplift and used both for premium day fares on long routes and overnight trips where applicable. Cabin in order of pricing include standard (two berths), family (four berths), and executive suites. The standard two berth suite (200 total) occupies 17.5 m² and includes a full size bed or two single beds, a private bathroom with shower, a writing desk and lounge chair, dedicated storage, individually controlled climate, and a fixed sea-view window or for inboard cabins, a high resolution display reproducing a Realtime external view. Family suites of 25.0 m² (145 total) accommodate four guests with a separate sleeping area for children and increased storage. The Executive Suites (60 total) include a separate living area, full-size double bed, and concierge call system. Public spaces include three sit-down restaurants of differing service levels including a 220 seat main restaurant on Deck 6 offering rotating regional cuisine appropriate to the route, a 90-seat premium restaurant on Deck 7 with a dedicated kitchen and curated wine list, and a 320 seat self-service food court on Deck 5 offering five separate counter cuisines. Four bars are distributed across the public decks including a 110 seat forward observation bar on Deck 8 with a full width glazed bow and live view of the wave-profiling LiDAR scan superimposed on the forward seascape. Lounges on Decks 6 and 7 provide flexible-use seating for approximately 800 guests across multiple zones, with quiet areas, work areas equipped with high-speed satellite communication, and family-friendly spaces with relaxed acoustic standards. A two- screen cinema on Deck 6 offers 180 seats across two halls showing current-release films on a per-passage rotation. A retail arcade on Deck 5 includes duty-free spirits and tobacco (for international routes), branded fashion, electronics, and curated regional products. The retail arcade on Deck 5 spans 1,400 m² and includes 14 individual store units operated by concessionaires. The arcade is laid out around a central atrium that extends two decks vertically, allowing daylight (via roof skylight) to penetrate to the lower passenger deck and providing a generous spatial experience uncommon in ferry interiors. Adjacent to the arcade, a 600 m² interactive entertainment zone offers virtual-reality experiences, classic and contemporary arcade games. A dedicated 580 m² children's center on Deck 6 provides supervised activity space for children. Adjacent to the center is a 110 m² nursing and infant care room. Lifts and stairs connect the children's facilities to the family suite block on Deck 7. A 380 m² wellness center on Deck 7 includes a 90 m² fitness facility with cardiovascular and strength equipment, four single occupancy spa treatment rooms, a sauna, and a small relaxation lounge. A 110 m² medical clinic on Deck 6, staffed by a qualified physician and two nurses on every voyage provides primary care and emergency stabilization.

Total HVAC cooling load at design ambient (32°C dry bulb, 26°C wet bulb) is approximately 12 MWth, served by four electrically driven centrifugal chiller plants distributed across the ship for redundancy and cooling path length minimization. Each chiller provides 3.5 MW thermal with R-1234ze refrigerant and seawater cooled condensers. Air handling units serve discrete zones within each passenger deck with variable air volume terminal control providing individual room or zone setpoints. Indoor air quality is enhanced through MERV-15 filtration of all supply air and continuous CO₂ monitoring with demand-controlled outside air make up. Heating is provided primarily by waste heat from the Rankine condensate circuit with electrical resistance back up. Fresh water is generated entirely on board by two reverse osmosis seawater desalination units of 120 t/day capacity each, supplemented by 480 t of stored fresh water for peak demand and emergencies. Total fresh water demand at full passenger and crew complement is approximately 220 t/day. Sewage is collected via vacuum drainage into two membrane bioreactor treatment plants of 150 t/day capacity and discharged outside port limits. Greywater is treated to a lower standard and may also be discharged at sea per regulations. Solid waste is sorted, compacted, and stored for offload at terminals. Beyond the structural fire protection life safety features include a high pressure water mist system in all machinery, galley, and laundry spaces, automatic sprinklers in all accommodation spaces, an addressable smoke and heat detection system with over 8,000 detector points and a public-address and general alarm system. Lifesaving appliances include 16 fully enclosed Marine Evacuation System chutes (eight per side) deploying onto a total of 32 motor-powered survival craft of 100 person capacity each, providing 100% evacuation capacity per side. Total lifesaving capacity is 3,200 persons (140% of design complement).
Last edited by The Technocratic Syndicalists on Wed Aug 26, 2026 10:29 am, edited 5 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Fri Jun 26, 2026 12:05 pm

Image


Shadowfin Class

Basic Information:
  • Role: Landing Craft
  • Displacement: 62.5 tonnes
  • Complement: 4 + 36
  • Length: 21.5 m
  • Beam: 7.5 m
  • Draft: 0.5 m (on cushion)
Propulsion:
  • 2x SDI GT500 naval gas turbines, 5,600 kW each
  • 2x SDI SS75 waterjets
Performance:
  • Top speed: 90 knots
  • Range: 600 nmi (1,000 km) @ 50 knots
Sensors & Processing Systems:
  • SDI FMG 100 X band Surveillance Radar
  • SDI FMG 970 Surface Search & Navigation Radar

Electronic Warfare & Countermeasures:
  • SRS 300 Electronic Support Measures System
  • 2x SDI SKLS-12 130mm countermeasure launchers

Armament:
  • 1x SDI Scanfire RWS


Overview:
The SDI Marine Systems Shadowfin is an advanced high speed surface effect landing craft designed for littoral commando operations in harsh arctic conditions. The is designed to transport a minimum of 14.0 tonnes of payload including embarked commandos and light vehicles at speeds of up tp 90 knots, with a range exceeding 600 nautical miles at reduced service speed under full-load conditions. The vessel is fully prepared for future warfighting, integrating features such as drones, embedded sensors, low signatures, high load carrying capacity, and rapid all-weather response capabilities, whether manned or fully unmanned. The craft operates with a crew of 3 and offers a load carrying capacity of up to 14 tonnes, accommodating vehicles, drones, missile systems, and remote controlled weapons systems. It can deploy up to 36 fully equipped troops to remote beaches at speeds ranging from 45 to 90 knots, depending on loading and weather conditions. Advanced situation awareness and communications systems are also integrated.


Design & Construction:
The Shadowfin employs a catamaran hull form with two slender, hard-chine sidehulls connected by a wet deck that encloses the pressurized air cushion. The sidehulls are asymmetric in section, with the inner faces optimised for cushion pressure containment and the outer faces shaped for wave-piercing performance and radar cross-section (RCS) reduction. The hull geometry features extensive use of inclined flat panels arranged at compound angles to deflect radar energy away from threat emitters. The bow is designed with an integrated ramp recess, forming a full-beam bow door and ramp assembly that permits roll-on/roll-off loading of light vehicles and rapid personnel embarkation and debarkation. The ramp is hydraulically actuated and is configured to interface with unprepared beaches at gradients up to 12.5%. The primary hull structure is fabricated largely from advanced composite materials including carbon fiber and glass fiber hybrid reinforced vinyl ester resin using vacuum-assisted resin transfer moulding (VARTM). The structural arrangement employs a combination of single skin construction with top hat stiffeners in lightly loaded areas and sandwich construction with closed-cell structural foam cores in the side hull shells, wet deck, and superstructure panels. Critical load paths including the bow ramp hinge zone, waterjet intake tunnels, and engine mounting foundations incorporate localized Ti-6Al-$v titanium alloy metallic inserts bonded and bolted into the composite structure. The superstructure is a continuation of the composite hull, constructed as an integral part of the main structure rather than a separate module, eliminating structural discontinuities that could compromise signature performance or fatigue life. All external surfaces are finished with a multi-layer radar-absorbent coating system that further attenuates reflected radar energy. The vehicle deck extends from the bow ramp to approximately two-thirds of the vessel’s length, providing a clear deck area of approximately 28 m² with a minimum overhead clearance of 2.0 m. The deck is reinforced with longitudinal and transverse stiffeners designed to accept concentrated wheel and track loads from light vehicles. Recessed lashing points are distributed across the deck on a 0.5 m grid to secure vehicles and stores. The bow ramp is fabricated as a composite/metallic hybrid structure, incorporating a steel wear surface on the beach contact face with a composite backing structure for weight efficiency. The ramp is actuated by twin hydraulic rams with a deployment time of less than 15 seconds. In the stowed position, the ramp forms a watertight closure sealed by an inflatable rubber gasket system, maintaining hull integrity at all speeds including maximum cushion-borne operation.


Propulsion
SDI500
  • Type: Marine diesel engine
  • Length: 1,520 mm
  • Diameter: 870 mm
  • Dry Weight: 500 kg
  • Compressor: 5 stage axial + 1 stage centrifugal HPC
  • Compression ratio: 18:1
  • Combustor: annular combustor
  • Turbine: 2 stage HPT, 2 stage LPT
  • Thermal efficiency: 45%
  • Specific fuel consumption: 200 g/kW-hr
  • Output: 5,600 kW
  • Fuel: Marine diesel, kerosene
The Shadowfin is powered by two advanced SDI GT500 recuperated gas turbines, each with a maximum continuous power rating of 5,600 kW (7,500 PS). The recuperated cycle incorporates a compact plate-fin heat exchanger that transfers exhaust gas enthalpy to the compressor discharge air before it enters the combustion chamber. Each gas turbine is mounted on a resilient cradle within a dedicated engine enclosure in the aft machinery space, isolated from the hull structure by a multi-stage vibration isolation system to minimize structure-borne noise transmission. The enclosures are lined with multi-layer acoustic absorption material and are ventilated through signature-attenuated intake and exhaust ducting. Power from each gas turbine is transmitted through a combining reduction gearbox to the corresponding waterjet unit. The gearbox incorporates a power take-off for the lift fan drive and an integrated clutch mechanism that permits the gas turbine to be disconnected from the waterjet for loiter operations under electric drive. The gearbox ratio is optimized for the peak efficiency point of the waterjet at the design top speed, with the gas turbine operating through its variable power turbine nozzle geometry to maintain efficiency across its entire speed range. The GT500 is an aeroderivative gas turbine and consists of a single spool gas generator core coupled to a free power turbine providing power output to the gearbox. A multi-stage intake filtration system is fitted upstream of the compressor entry, comprising a first-stage inertial separator for removal of large water droplets and salt spray, a second-stage coalescing filter for fine moisture and salt aerosol, and a third-stage barrier filter for particulate removal. The filtration system is designed for the extreme salt-laden air environment encountered at high speed in the littoral zone, where the vessel’s own bow wave and cushion spray generate a dense salt aerosol cloud around the air intakes. The compressor is a combined axial-centrifugal design consisting of five axial stages followed by a single centrifugal stage, delivering an OPR of approximately 18:1. The axial stages employ three-dimensional aerodynamic blade profiling with controlled-diffusion aerofoils to maximise stage loading while maintaining stall margin across the operating envelope. The centrifugal stage provides the final pressure rise and delivers air to the annular diffuser feeding the combustion system. All compressor aerofoils feature a multi-layer erosion and corrosion-resistant coating system, comprising a metallic bond coat and a ceramic top coat, to protect against salt-induced hot corrosion and erosion from ingested particulate. Compressor wash ports are provided for periodic on-line and off-line freshwater compressor washing to remove salt deposits and restore performance. The annular combustion chamber is a single-annular design with advanced fuel injection nozzles providing lean premixed combustion to minimize NOx emissions and pattern factor at the turbine inlet. The combustor liner is constructed from advanced nickel-based superalloy sheet with thermal barrier coating (TBC) and employs multi-hole effusion cooling to manage liner temperatures while minimizing cooling air consumption. The design combustor exit temperature at maximum power is 1,400°C. The high-pressure (HP) turbine is a two-stage axial design with single-crystal nickel superalloy blades incorporating internal cooling passages and film cooling holes. The HP turbine drives the compressor through a concentric shaft at speeds up to approximately 16,000 RPM. A two stage power turbine extracts the remaining energy from the gas path and drives the output shaft through the reduction gearbox. The SDI500 integrated a recuperator that recovers thermal energy from the turbine exhaust and transfers it to the compressor discharge air before it enters the combustion chamber. The recuperator employs a compact primary surface plate-fin heat exchanger construction, fabricated from high-temperature stainless steel alloy using vacuum brazing. The plate-fin geometry provides a high surface-area-to-volume ratio, enabling the recuperator to achieve a thermal effectiveness of 85–88%. The recuperator is installed in the exhaust flow path between the power turbine exit and the exhaust duct. The hot side exhaust gas enters the recuperator at approximately 550°C and exits at approximately 250°C, with the recovered enthalpy transferred to the cold-side compressor discharge air. This reduced exhaust gas temperature has the additional benefit of significantly lowering the infrared signature of the exhaust plume, The FADEC incorporates a dedicated recuperator thermal management algorithm that modulates the exhaust gas bypass valve to control the rate of thermal loading on the recuperator core, preventing thermal shock and fatigue cracking of the brazed joints. A motorized bypass damper on the exhaust side allows a proportion of the exhaust gas to bypass the recuperator entirely during transient acceleration events, with the bypass fraction progressively reduced as the recuperator reaches thermal equilibrium. Power from each gas turbine is transmitted through a high-performance marine reduction gearbox to the corresponding waterjet shaft. The reduction gear unit is a two stage helical gear train providing a reduction ratio of approximately 4.5:1, reducing the power turbine output speed of approximately 6,500 RPM to the waterjet input speed of approximately 1,450 RPM at the design point. The gearbox is rated for 5,600 kW of continuous power transmission with a service factor of 1.25, providing margin for transient overloads during maneuvering and sea state impacts. The gearbox casing is fabricated from high-strength aluminum with the gear teeth manufactured from case-carburized alloy steel to aerospace standards. The gear tooth profiles are designed with profile and lead modifications optimized for the specific load spectrum of the SES JCC mission profile, minimizing contact stress and gear mesh noise across the operating range. Each RGB incorporates a bevel-gear power take-off (PTO) on the input side of the gear train, providing a mechanical drive to the corresponding lift fan. The PTO is rated for continuous transmission of 450 kW and is equipped with an overrunning clutch that allows the lift fan to be driven by its dedicated electric motor when the gas turbine is shut down or disconnected. A multi-plate wet clutch is installed in the shaft line between the RGB output and the waterjet input coupling that permits the gas turbine and gearbox to be disconnected from the waterjet shaft for low-speed electric drive operationsand enables controlled engagement during the transition from electric stealth drive to gas turbine power. The clutch is hydraulically actuated with electronically modulated engagement pressure, allowing the IPMS to manage the torque ramp-up during clutch engagement and prevent shock loading of the waterjet impeller and shaft line.

Propulsive thrust is generated by two advanced SDI SS75 two-stage axial-flow waterjet units mounted in tunnels at the transom of each side-hull. Each waterjet assembly is installed in a dedicated intake tunnel molded into the aft section of each side hull. The intake is a flush design with a hydrodynamically profiled intake lip located on the hull bottom forward of the transom. The intake geometry incorporates a boundary layer diverter that diverts the low-energy boundary layer flow developing on the hull bottom away from the intake, preventing the ingestion of low-momentum fluid that would degrade pump performance and promote cavitation. Each waterjet unit is a two-stage axial-flow pump comprising a first-stage inducer/booster impeller, an interstage stator row, and a second-stage main impeller, followed by a discharge stator and contracting nozzle. The first-stage impeller is a four-bladed axial inducer with moderate blade sweep and controlled leading-edge geometry, designed to operate with a high suction specific speed and to suppress cavitation at the intake. The inducer provides approximately 35–40% of the total pressure rise and raisesg the static pressure at the entry to the second stage above the cavitation threshold, ensuring that the main impeller operates in a fully wetted flow regime regardless of the intake pressure deficit at high vessel speed. The first-stage blades are fabricated from forged Ti-6Al-4V alloy with superfinished leading edges to delay cavitation inception. A row of seven fixed stator vanes between the first and second stages removes the swirl imparted by the inducer and redirects the flow axially into the second-stage impeller at the optimal incidence angle. The stator vanes are manufactured from cast nickel-aluminum bronze with hydrodynamically profiled sections designed to minimize wake thickness and turbulence at the second-stage entry plane, reducing interaction noise and vibration. The second-stage main impeller is a six-bladed axial design providing the remaining 60–65% of the total pressure rise. The blade geometry employs three-dimensional hydrodynamic profiling with blade lean and sweep optimized to manage the pressure distribution on the blade surfaces and suppress sheet and tip vortex cavitation across the operating range. The main impeller is machined from a single Ti-6Al-4V alloy forging. A discharge stator row of nine vanes downstream of the main impeller removes the residual swirl from the pump discharge flow and converts swirl kinetic energy into static pressure, maximizing the energy available for jet acceleration. Each waterjet discharge nozzle is equipped with a steerable deflector ring providing ±30° of horizontal thrust deflection. The deflector is hydraulically actuated by dual redundant electro-hydraulic actuators, with a maximum steering rate of 30 °/s providing the agility necessary for high-speed evasive maneuvering. Differential steering between the port and starboard waterjets provides yaw control and augments the rudder-like effect of the deflectors. Reversing thrust is provided by hydraulically actuated clamshell-type reversing buckets that deploy into the jet stream aft of the nozzle exit.

For low-speed transit, harbor maneuvering, and covert approach operations, the Shadowfin is equipped with an auxiliary electric propulsion capability. Two permanent magnet electric motors, each rated at 200 kW, are integrated into the waterjet shaft lines downstream of the gearbox clutch, enabling electric only propulsion at speeds up to approximately 10 knots. Power is drawn from the vessel’s electrical generation system, which may operate from the gas turbine generators or from a dedicated battery bank for short-duration silent running. Each PMSM is rated at 200 kW continuous power output at a maximum speed of 800 RPM, with a peak overload capability of 275 kW for 30 seconds to support transient maneuvering loads. The motors employ a neodymium-iron-boron (NdFeB) permanent magnet rotor with a surface-mounted magnet configuration and a laminated silicon-steel stator with distributed windings. The motor frame is fabricated from non magnetic stainless steel to avoid contributing to the vessel’s magnetic signature, and the entire motor assembly is enclosed in a sealed, water cooled housing that provides both thermal management and acoustic isolation from the shaft line. The PMSMs are powered by two variable-frequency drives, each employing silicon carbide (SiC) MOSFET power switching devices. Each VFD converts the 700 V VDC bus voltage to the variable-frequency, variable-voltage three-phase AC supply required by the PMSM, with the output frequency and voltage continuously modulated by the propulsion control system to deliver the commanded shaft speed and torque. The energy source for the electric drive is a lithium-ion battery energy storage system that provides the stored electrical energy necessary for extended silent operations without any gas turbine or diesel generator running. The battery employs lithium iron phosphate (LiFePO₄) cell chemistry with a 280 kWh total capacity and a 700 VDC nominal voltage. The battery system is distributed across four identical battery modules, two located in each side hull in compartments below the vehicle deck level. Each module is independently fused and isolated by pyrotechnic disconnectors that can sever the module from the DC bus in the event of a cell level fault. The modules are housed in air tight, thermally insulated enclosures with forced-air ventilation and gas detection sensors that provide early warning of cell venting before thermal runaway conditions develop. Each module enclosure is fitted with an independent halon fire suppression system and a gas-tight exhaust duct routed to the hull exterior for venting of combustion products in a worst-case thermal event.

The air cushion is formed between the two rigid side-hulls and is bounded at the bow and stern by flexible skirt-seal assemblies. Unlike a conventional hovercraft, where the entire vessel weight is supported on the air cushion, the SES retains its sidehulls in contact with the water surface, providing hydrodynamic stability and directional control. The cushion supports approximately 80 to 85% of the vessel’s displacement when operating in the on-cushion mode, reducing the waterplane area and hence the wave making resistance. Cushion air is supplied by two variable-geometry centrifugal lift fans, each driven through a mechanical power take-off from the main gas turbine gearbox and supplemented by dedicated electric motor drives for low speed and loiter operations. The variable geometry is achieved through adjustable inlet guide vanes and a translating diffuser section, permitting precise control of cushion pressure and flow rate across the full operating envelope from idle to maximum speed. Each lift fan is rated at approximately 400 kW at maximum output and is designed to provide full cushion pressure with a single fan operating. Fan speed and guide vane position are commanded by the ride control system computer, enabling dynamic modulation of cushion pressure to actively control heave, pitch, and roll motions. The bow seal is a compliant finger-type skirt assembly fabricated from reinforced neoprene-coated nylon fabric, designed to accommodate terrain following during beaching operations and to deflect debris. The seal fingers are individually replaceable and are arranged in primary and secondary rows to provide redundancy and to manage the pressure differential at the bow cushion boundary. The stern seal employs a single-lobe bag configuration that is partially retractable to manage the cushion air escape path and to optimize propulsive efficiency across the speed range. The stern seal geometry interacts directly with the waterjet intake flow field and has been designed in conjunction with the waterjet manufacturer to minimize intake distortion and cavitation risk at high speeds. The air cushion provides the SES JCC with a unique beaching capability that distinguishes it from conventional displacement landing craft. As the vessel approaches the beach, the cushion pressure lifts the bow onto the beach gradient, distributing the vessel’s weight over a large area and minimizing ground pressure. The bow effectively rides up the beach slope on the air cushion, with the side-hull keels and bow ramp contact surface managing the remaining ground reaction forces. Retraction from the beach is achieved by increasing cushion pressure in the forward zone while engaging reverse thrust on the waterjets, enabling the vessel to slide off the beach surface without the need for kedge anchors or external assistance. This capability permits rapid insertion and extraction cycles with turnaround times of less than five minutes, significantly enhancing the tempo of amphibious operations. The beaching system is designed to operate on sand, gravel, and firm mud substrates at beach gradients between 3% and 12.5%. The Shadowfin incorporates an advanced closed-loop active ride control system (ARCS) that reduces vertical accelerations by 40 to 60% relative to the uncontrolled response. The ARCS integrates forward-looking LiDAR wave-scanning sensors as the principal feedforward input to the control algorithm. Two scanning LiDAR units are mounted on the forward superstructure, providing a three-dimensional surface profile of the sea ahead of the vessel out to a range of approximately 250 to 300 meters. This preview allows the ride control computer to anticipate incoming wave encounters and pre-position the cushion pressure, interceptor, and trim tab actuators before the disturbance arrives at the hull. The LiDAR data is fused with conventional motion reference unit (MRU) measurements—providing real-time heave, pitch, roll, and yaw rates and with GPS/INS data to generate a complete picture of the vessel’s dynamic state and the incoming seaway. The sensor fusion algorithm operates at a minimum update rate of 100 Hz to provide the control bandwidth necessary for the short wave-encounter periods experienced at high speed. The ARCS commands the variable-geometry lift fans adjust guide vane and diffuser positions to modulate cushion pressure differentially between forward and aft cushion zones to control heave and pitch. High-speed butterfly valves in the cushion plenum also selectively vent air to manage transient pressure spikes caused by wave impacts on the wet deck while retractable blade-type interceptors at the transom of each side-hull generate a local pressure field on the hull bottom to control pitch and roll at high speed. Adjustable trim tabs on the side-hull transoms provide low-frequency pitch and roll trim correction. The control law is a model-predictive controller (MPC) that uses the LiDAR preview data to solve an optimization problem at each time step, balancing motion reduction against actuator rate limits, cushion pressure constraints, and structural load limits.

Electrical power is generated by two shaft-driven generators coupled to the main gas turbine gearboxes, each rated at 250 kW at 440 V AC, 60 Hz. A dedicated 150 kW diesel generator set is provided as a harbor and emergency supply, and a lithium-ion battery bank with a usable capacity of approximately 200 kWh provides uninterruptible power to critical systems and enables the silent electric propulsion mode. The electrical distribution system employs a zonal architecture with two independent main switchboards each serving defined zones of the vessel. Critical loads including navigation, communications, ride control, EW, and the fire and bilge pumping systems are dual-fed from both switchboards with automatic bus transfer. The distribution system is designed for survivability, with cable routes segregated to port and starboard and protected by fire-resistant barriers. A dedicated high-power 600 VDC bus supplies the tethered UAS power system, the electric propulsion motors, and the battery charging system, managed by a power management computer that balances generation, storage, and demand across all operating modes.


Sensors & Processing Systems:
SDI FMG 970 Surface Search & Navigation Radar: A commercial-grade IMO-compliant SDI FMG 970 X-band navigation radar is installed on a dedicated mast position below the surveillance radar antenna. The navigation radar provides conventional surface navigation, collision avoidance (ARPA), chart overlay, and harbor/coastal piloting functionality. The navigation radar operates independently of the surveillance radar and provides a backup surface search capability in the event of surveillance radar failure or during emissions-controlled (EMCON) operations.


Electronic Warfare & Countermeasures:
FMB 300 Electronic Support Measures System: The ship's primary electronic warfare system is the SDI FMB 300 shipboard tactical ESM suite which provides radar warning and combat direction finding against hostile emitters. The FMB 300 employs a split ESM antenna array on either side of the ship's mast with two domes each containing ten multi-arm spiral antennas providing instantaneous 360° detection of radar signals in the 0.5 to 40 GHz range. The system's receivers employ amplitude monopulse direction finding and intra-pulse signal measurement which provides the system with <2° RMS direction finding accuracy and <2 MHz RMS frequency accuracy and has the ability to track up to 500 emitters simultaneously. The system can also perform emitter distance estimation based on pulse amplitude. Signals received by the ESM system are compared to an onboard threat library which can store up to 20,000 emitter characteristics.

LWG 620 Naval Laser Warning System: For detecting laser sources including laser range finders, laser target designators, and laser beamriding missiles the ship's FMB 300 ESM system is augmented by an SDI LWG 620 Naval Laser Warning System. The LWG 620 consists of a central controller connected four sensor heads, two on each side of the superstructure, providing 360° around the vessel. Each individual sensor head features 110° azimuth and +/- , 70° elevation coverage and is capable of detecting laser range finders laser target designator emissions in the 0.5 μm - 1.65 μm range and laser beamriders in the 0.8 μm - 1.1 μm range.

TKG 130 Decoy Launchers: For self protection against anti-ship missiles the ship is equipped with twin SDI TKG 130 decoy launchers for 130mm chaff and flare countermeasures. One launcher is placed angled outwards on each side of the superstructure and provides forward and side coverage around the vessel. Each launcher has 12 tubes which are aligned in pairs at 10°, 40°, 60°and 135°angles relative to vertical which can be fired individually or in pairs either automatically by the ship's ESM system or manually using a large touchscreen display in the ship's bridge. The launchers are designed to use SDI's AM5 dual chaff/IR seduction decoy is designed to seduce infrared, radar, dual infrared/radar seeker anti-ship missiles. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.


Signature Reduction:
The Shadowfin class features extensive radar and infrared signature reduction to reduce the ship's detectability to radar and infrared sensors. The hull and superstructure employ a faceted geometry in which all external surfaces are arranged as flat or single-curvature panels inclined at compound angles to deflect incident radar energy away from the threat emitter rather than returning it as a specular reflection. The superstructure has no right-angle junctions in any plane visible from the waterline, and all external fittings including antenna mounts, navigation lights, cleats, and the RWS housing are either flush-mounted or housed within radar-transparent fairings. The advanced composite hull incorporates a conductive radar-absorbent material (RAM) layer within the composite laminate stack-up to prevent radar energy from penetrating the hull and reflecting from internal metallic components. The radar-absorbent material (RAM) layer is SDI's S-RAM, a type of ballistic grade structural radar absorbing material made from multiple layers of M5 fibers fibers containing a lossy filler backed by a carbon fiber laminate acting as a reflector providing an average -20 dB reflectivity across the 2-40 GHz frequency range (L through Ka bands). The hull is also painted in a radar absorbing paint coating 1 to 5 millimeters thick consisting of lossy dielectric material embedded in a polymer resin which provides -20 dB reflectivity across the 9 -13 GHz range (X band). The exhaust system incorporates a multi-stage signature suppression system comprising an exhaust gas venturi ejector that entrains ambient air to dilute and cool the exhaust plume, a louvred exhaust outlet that directs the reduced-temperature exhaust upward and aft into the vessel’s turbulent wake, and a water-spray injection system that can be activated to further quench the exhaust temperature during high-threat transits.The hull and superstructure external surfaces are further treated with a low-emissivity thermal coating that reduces the surface’s thermal contrast against the background sea and sky clutter. The HVAC system exhausts are routed through heat exchangers cooled by seawater to minimize thermal leakage from accommodation spaces. The vessel is finished in a disruption-pattern camouflage scheme optimized for the littoral operating environment, employing a multi-tone grey palette that breaks up the vessel’s visual outline against both open-water and coastal backdrops. The camouflage pattern is designed using computational signature modelling to minimize visual detection range under a range of lighting and atmospheric conditions. All reflective surfaces including glass, metal fittings, sensor apertures are treated with anti-reflection coatings or are recessed behind non-reflective surrounds. Airborne acoustic signature is managed through the use of acoustic enclosures around the gas turbines and lift fans, signature-attenuated intake and exhaust silencers, and resilient mounting of all rotating machinery. The lift fan variable geometry system is designed to avoid blade passing frequency tones that could be exploited by acoustic detection systems. Underwater radiated noise is addressed through vibration isolation of the main machinery from the hull structure, the use of the composite hull material, and the design of the waterjet intake and impeller to minimize cavitation at service speeds. The predominantly composite hull structure also inherently provides a very low magnetic signature compared to steel vessels. The remaining ferromagnetic components including the gas turbine casings, gearbox housings, and waterjet assemblies are degaussed during construction and are monitored by an onboard magnetic signature monitoring system. Where practical non-ferromagnetic alternatives are used for structural fittings and deck hardware to further reduce the vessel’s magnetic footprint.


Armament:
Last edited by The Technocratic Syndicalists on Fri Jun 26, 2026 12:06 pm, edited 1 time in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Fri Jun 26, 2026 8:08 pm

hImage

Triton Class

Basic Information:
  • Role: Surface Effect Sealift Ship
  • Displacement: 25,000 t
  • Complement: 20 + 80
  • Length: 285 m
  • Beam: 60.0 m
  • Draft: 3.0 m (on cushion), 7.0 m (off-cushion)
Propulsion:
  • 8x AEG AGT9000 nuclear gas turbine propulsion engines, 90 MW each
  • 2x AEG AGT9000 nuclear gas turbine lift engines, 90 MW each
  • 8x Variable-geometry lift fans
  • 8x SDI SS325 Waterjets

Performance:
  • Top Speed: 90 knots
  • Range: unlimited


Overview:
The Triton class is high speed strategic sealift ship designed by SDI Marine Systems. Designed for high speed srategic sealift the Triton class has a large reconfigurable meter cargo bay with a capacity of 10,000 tonnes of cargo and can deliver equipment directly into shallow expeditionary ports unsuited to conventional fast sealift ships. With its modular weapon and missile magazine cargo provisions it can also convert between sealift, fast logistics, vertical launch ammunition transfer, and surface combatant escort missions through without modification of the ship. With its 90 knot speed it is too fast to be effectively shadowed by any current surface combatant or nuclear submarine and enables the rapid transit and deployment of conventional forces, equipment and supplies in support of maneuver and sustainment operations.


Design & Construction:
The Triton class vessels have a length of 285 meters, beam of 60.0 meters, and a full load displacement of approximately 25,000 tonnes. The hull is a twin sidehull SES with full length side hulls, bridging cross structure, and flat wet deck. The sidehulls are slender, low aspect ratio wave piercing hulls which provide a rigid mounting platform for the waterjets, transmit cushion pressure to the water surface via seal contact, contain the air cushion laterally, and provide hull borne flotation when the cushion is deflated. The sidehull bow is a deeply raked wave piercing design with a fine entry angle to minimize pitch motion when transiting steep wave fronts. Aft the sidehulls terminate in transom sterns housing the waterjet nozzles with a fine stern wedge to control trim moment and reduce stern wake interference with the cushion. The air cushion is bounded laterally by the twin sidehulls and fore and aft by flexible elastomeric seals. The bow seal is a multi-finger bag and finger lobed configuration with a primary inflated bag that forms the seal envelope and multiple individual planing fingers that contact the water surface. The stern seal is a twin loop planing flap hinged at the wet deck and tensioned by internal cushion pressure against an external tensioning structure. Both seals are fabricated from a multi-ply elastomer reinforced with woven aramid and high modulus polyethylene fibers with a chlorosulphonated polyethylene wear surface for abrasion resistance and chemical stability. Service life is approximately 8,000 operating hours for the bow fingers, with planned replacement during scheduled drydock. The wet deck is a stiffened-plate structure spanning the 30 meter gap between the side hulls, forming the cushion ceiling and the structural floor of the lowest cargo deck. The wet deck spanning between the sidehulls supports the vehicle decks above and withstands the cushion pressure and wave-slam loads below. Full keel-length fences reduce cushion venting and waterjet inlet air ingestion. Three internal cargo decks are supported by the cross structure between the side hulls. Each deck is designed for a distributed load of 5 tonnes/m² to accommodate main battle tanks at 75.0 mt on their tracks and has a clear height of 6.0 meters on the main vehicle deck and 5.0 meters on the upper decks. The ship provides provides approximately 32,500 m² of vehicle stowage area across four internal cargo decks with a maximum cargo weight of 10,000 tonnes.

The Triton primary structure is constructed almost entirely of Ti-5111 (Ti-5Al-1Sn-1Zr-1V-0.8Mo) titanium alloy providing high specific yield strength, complete immunity to seawater galvanic corrosion, non magnetic signature, excellent fatigue performance, and adequate weldability with proven marine fabrication procedures. The Titanium construction eliminates ay required anti-corrosive coatings as the alloy is effectively passive in seawater across all normal operating temperatures while no galvanic isolation is required between the primary hull and dissimilar material fittings (composite decking, stainless steel deck fittings, etc). The Triton primary hull is constructed with conventional stiffened plate construction with face plates, longitudinal stringers, and transverse frames using Ti-5111 throughout. Typical plating thicknesses on the Triton primary hull are: outer bottom and sidehull outer face 22–26 mm; wet deck (cushion top plating) 18–22 mm, interior decks and bulkheads 8–12 mm, superstructure exterior 6–10 mm. All primary joints are full penetration gas-tungsten-arc-welded using ERTi-5 filler wire with argon or argon/helium inert shielding on both sides of the joint. Post weld stress relief is applied at 550°C for critical girder intersections. Non destructive inspection is by dye penetrant and radiographic examination at 100% of primary joints. The hull is built as nine modular construction modules of 1,300 to 2,200 tonnes each joined at eight transverse construction joints. Intermodular joints use full penetration butt welds with backing strips. Modular construction enables parallel building at multiple shipyards and supports modular replacement during major repair. Selective ballistic hardening is applied to compartments and structures whose loss would compromise vessel safety, propulsion, or primary mission capability. Hardening is achieved by local plate thickening and by addition of an external Ti-6Al-4V armor panes. Hardened compartments include the ten reactor module compartments, the bridge and combat-information center, the VLS magazine spaces, fore and aft seal control machinery rooms, the emergency generator compartments, and the battery energy storage compartments. With its titanium primary structure the Triton eliminates the external intumescent fire coating that composite or aluminum construction would require while retaining better fire performance than steel superstructure.


Propulsion:
The Triton propulsion plant consists of ten SDI AGT9000 nuclear gas turbine powerplant modules. Eight of the ten modules are dedicated propulsion modules arranged in two 2×2 stack configurations in the aft compartments of the two sidehulls which each drive a three-stage axial-flow waterjet through an epicyclic reduction gear and composite drive shaft. The remaining two modules are dedicated lift and electrical modules located one per sidehull in the forward machinery compartment that each drive four variable geometry lift fans arranged in tandem along a common drive shaft together with a large permanent magnet electrical generator coupled at the forward end of the fan train through a controllable clutch. Each AGT9000 nuclear gas turbine module is a fully self-contained nuclear powerplant including reactor, primary coolant loop, power conversion assembly (compressors, turbines, recuperator, intercooler, precooler), shielding, containment, control instrumentation, and emergency cooling. The modules are identical and physically interchangeable, enabling either field-level replacement or in-place refueling. The AGT9000 reactor is a gas cooled, graphite-moderated reactor with highly enriched TRISO fuel elements. The fuel is HEU TRISO coated fuel particles, with fuel kernels of 93.0 wt% enriched uranium oxycarbide (UCO) of approximately 425 µm diameter, surrounded successively by a porous buffer layer (95 µm carbon), an inner pyrolytic-carbon layer (40 µm), a silicon-carbide layer (35 µm, the principal fission-product barrier), and an outer pyrolytic-carbon layer (40 µm). Final coated particle diameter is approximately 855 µm. The coated particles are dispersed in a graphite matrix and formed into hexagonal fuel compacts, with seven axial coolant channels providing a 20% void fraction. The fuel elements are bundled in a right-cylindrical core of approximately 2.5 m diameter and 3.0 m height, containing approximately 12,000 fuel elements with a total uranium loading of approximately 6,500 kg of HEU. The core is surrounded by a beryllium radial reflector containing twelve rotating control drums, each consisting of a beryllium cylinder with a 120° sector of boron carbide absorber. Drum rotation between 0° (B₄C facing core, maximum negative reactivity) and 180° (B₄C facing outward, maximum positive reactivity) provides the primary reactivity control. The drums are driven by sealed electromagnetic actuators with redundant fail-safe gravity-driven shutdown to the fully-inserted position on loss of electrical power. The internal radiation shield comprises a 200 mm tungsten gamma shield surrounding the lateral and top reflector, and a separately cooled plug shield *tortuous-flow tungsten / beryllium oxide / boron carbide composite) at the core inlet/outlet that allows the helium coolant to enter and leave the reactor without creating a radiation streaming path. The external shielding, located outside the containment vessel, comprises depleted-uranium gamma shielding (180 mm), borated polyethylene neutron shielding (220 mm), and a water-filled annulus (300 mm) that doubles as the intermediate-loop cooling water reservoir. The power conversion system uses a closed-Brayton-cycle architecture. Helium enters the low-pressure compressor at 540°C and 5.0 MPa absolute pressure, is compressed in a single-stage axial compressor to 7.6 MPa with discharge temperature 380°C; passes through the intercooler, a printed-circuit heat exchanger transferring heat to the intermediate cooling water loop, and is cooled to 95°C, enters the high-pressure compressor and is compressed to 15.2 MPa at 285°C, passes through the recuperator and is heated to 740°C by the turbine exhaust, enters the reactor where it absorbs 215 MWth of fission heat and exits at 1040°C, expands through the high-pressure gas generator turbine driving both compressors, exiting at 845°C and 8. MPa, expands through the low-pressure turbine driving the output shaft, exiting at 740°C and 5.1 MPa, passes through the recuperator and is cooled to 415°C; passes through the seawater precooler that returns the working fluid back to compressor inlet temperature. The reactor primary power control is by helium inventory variation rather than direct reactivity control. Increasing primary loop inventory increases mass flow, increases heat transport from the core, and reduces core outlet temperature where the automatic temperature controller compensates by withdrawing reactivity from the control drums to maintain outlet temperature. Decreasing helium inventory has the reverse effect. The inventory control approach permits very rapid power maneuvering with full power excursion from idle in approximately 90 seconds and full shutdown in 30 seconds without thermally stressing the core or large reactivity manipulations of the drums.

Each power turbine output at 3,600 rpm is connected via a torsionally tuned flexible elastomeric coupling to a two stage epicyclic reduction gear which drives each waterjet thruster at 600 rpm through a composite drive shaft. The primary reduction is a compound planetary arrangement with two stages consisting of a 2:1 first-stage star epicyclic followed by a 3.33:1 second stage planetary reduction. The first stage uses a fixed annulus and rotating planet carrier as input with the output taken from the sun gear; the second stage uses a fixed annulus, rotating planet carrier as output to the waterjet, and a rotating sun gear input. This split stage approach reduces peak tooth loads and allows the high-speed first stage gears to be lighter and smaller while the heavy second-stage absorbs the bulk of the torque amplification. All gear teeth are case-carburized and ground to DIN 5 accuracy. Gear bodies are forged 18CrNiMo7-6 and supported by hydrodynamic journal bearings on the carriers and tilting pad thrust bearings on the high speed pinions. The lift fan turbines drive the lift fans through a single-stage star epicyclic gear unit with a 3:1 ratio. The composite drive shaft connecting the primary reduction gear output to the waterjet impellers is a filament-wound CFRP tube of 850 mm outer diameter, 18 mm wall thickness, and 12 m length, with titanium-alloy end fittings bonded and pinned to the composite tube. The eight waterjets are three stage designs with an inducer, a mixed-flow main impeller, and an axial booster. Each is sized for an inlet flow of approximately 400 m³/s at 600 rpm impeller speed, producing a jet velocity of 60 m/s at design point and a static thrust of approximately 1,300 kN at 90 knots ship speed. The inducer is a low-speed, large-diameter axial-flow inducer providing sufficient suction side head rise to suppress cavitation at the entry to the first main impeller across the full speed envelope (0 to 80 knots). The inducer operates at a rotational speed approximately half that of the main impellers, driven at reduced speed through a concentric epicyclic reduction within the pumpjet housing. The inducer blading is cast Ti-6Al-4V with swept leading edges optimized for minimum tip vortex cavitation. The mixed flow impeller operates at the primary rotational speed providing the majority of the head rise. The mixed flow geometry achieves a balance between the high head rise of a centrifugal impeller and the high flow coefficient of an axial stage, optimized for the operating point at 80 knots. The impeller is a monolithic casting in Ti-6Al-4V with hot-isostatic-pressed (HIP) post-processing for maximum fatigue life. An axial-flow booster stage downstream of the main impeller provides the final increment of head rise needed to achieve the required nozzle exit velocity at 90 knots. At lower ship speeds the booster is effectively unloaded by the variable geometry inlet’s scheduling of flow rate versus pump speed. The booster is a 3-stage stator-rotor arrangement with Ti-6Al-4V blading. Each pair of pumpjets (inboard/outboard) in each sidehull is fed from a single semi flush seawater inlet with a continuous-member variable geometry ramp roof. The ramp roof position is modulated by a hydraulic actuator as a function of ship speed, pump speed, and sea state, scheduling the inlet throat area to maintain optimal pressure recovery and cavitation margin across the full operating envelope. At low speeds, the inlet is wide open to maximize suction head; at high speeds, the ramp closes progressively to match the inlet area to the reduced volumetric flow demand at higher system pressure. Full keel-length sidehull fences, combined with inlet side plates, prevent cushion air ingestion into the pumpjet inlets. An active broach detection system using differential-pressure sensors at the inlet lips provides input to the propulsion control system, which limits HTS motor speed to prevent pumpjet overspeed events under broaching conditions. A hydraulically deployable reversing bucket diverts the jet forward for astern thrust and braking. The bucket is configured to direct the reversed flow in a downward outward direction to avoid recirculation into the next downstream inlet.

Each lift and electrical module's free power turbine output shaft at 3,600 rpm drives a two stage epicyclic reduction gear with 3:1 reduction to 1,200 rpm feeding a common shaft that drives four variable geometry centrifugal lift fan and a terminal permanent magnet generator. Each fan train comprises from aft to forward the AGT9000 module, the two stage epicyclic reduction gear (3:1 reduction, output shaft 1,200 rpm), four rotating centrifugal lift fans in tandem along the common shaft (each fan fed by two inlet ducts, one from each side of the shaft and discharging downward alternately into the seal manifold or the cushion plenum), a controllable hydraulic clutch, and a large permanent magnet electrical generator. The lift fan drive shafts use a CFRP tube of 480 mm outer diameter and 25 mm wall thickness with a torsionally tuned elastomeric coupling between the gearbox output and the fan input to isolate fam induced pulsation from the gearbox. All composite shafts use a quasi-isotropic stacking sequence in the central portion of the tube, transitioning to a ±15° angle-ply at the metallic end fittings to maximize torque transfer at the bond line. Bond lines use a structural epoxy adhesive co-cured with the laminate supplemented by tapered titanium pins through both the tube and the end fitting for failsafe redundancy. Each fan consists of 3.0 meter diameter rotor with titanium-alloy impellers, double axial inlets, and variable inlet guide vanes for ride control modulation. Each fan is a single stage radial-tipped centrifugal compressor with a vaned diffuser. Actuated geometry elements include variable inlet guide vanes that pre-swirl the inlet flow, controlling work input and shifting the fan characteristic curve laterally,)variable diffuser vanes that control the diffuser passage area, adjusting the pressure-recovery characteristic and stall margin; and a variable inlet bell-mouth area set by a circumferential iris ring that reduces inlet area at low flow to maintain inlet velocity and prevent inlet recirculation. At zero ship speed with cushion deflated the fan is at minimum speed and minimum geometry (inlet partially closed, IGVs at maximum positive incidence, diffuser vanes at restricted area) to provide a small flow at very high pressure ratio, initiating cushion inflation. As the cushion fills and pressure rises toward design value, geometry opens progressively and the fan tracks the cushion inflow demand. At hump speed (20 knots), seal-water interaction is at its maximum and air leakage from beneath the seals is highest, the fan runs at maximum flow with geometry fully open. Beyond hump speed as the vessel accelerates onto the cushion and seal contact stabilizes leakage decreases and the fan progressively closes its geometry. At design cruise speed the fan operates at moderate flow and high pressure ratio, with the active ride control system superimposing high-frequency, small-amplitude flow modulation on the baseline operating point to actively manage cushion pressure ripple in seaway.

The Active Ride Control System (ARCS) is a closed-loop control system that fuses measurements from forward looking LiDAR, inertial measurement units, and pneumatic cushion pressure and seal position sensors to derive optimal control commands for six effector categories. Control law execution runs at 200 Hz on a quad redundant computing system with three-out-of-four voting at the output stage. The forward looking wave-profiling LiDAR is a pair of solid state LiDAR systems mounted on the bridge wings approximately 35 m above the design waterline, providing a forward-scanning beam pattern that maps the three dimensional wave field over a sector extending approximately 30° to either side of the bow and from 100 m to 1,200 m range ahead of the vessel. The LiDAR unit use a 1,550 nm wavelength solid-state laser with a pulse energy of 50 µJ at a repetition rate of 200 kHz, yielding a scan refresh rate of 5 Hz across the full forward sector. Range resolution is 30 cm and angular resolution is 0.05°, sufficient to resolve individual wave crests at 1 km range under all design sea states. Two LiDAR units are installed, one each on the port and starboard bridge wings, providing both a wider field of view through field overlap in the bow region and full redundancy against the failure of either unit. Both heads are climate-controlled in a pressurized enclosure with a sapphire window heated to prevent icing and fitted with a hydrophobic surface treatment. A high-pressure freshwater wash system removes salt deposits at 20 minute intervals. Raw LiDAR returns are processed in three stages. First a clutter rejection filter removes returns from precipitation, fog, and sea spray based on multi-pulse statistical analysis. Second a wave-surface reconstruction algorithm fits a continuous water-surface elevation field to the cleaned point cloud using a constrained spline representation. Third a wave propagation model advances the reconstructed surface forward in time using a deep-water linear wave dispersion relation to predict the surface profile at the vessel position as a function of forward time. The ARCS commands a total of six groups of actuators. The cushion pressure modulator consists of eight high-bandwidth bleed valves, one per machinery module, that vent excess cushion air to atmosphere on command. Each valve is a butterfly and-pinion design driven by a servo-hydraulic actuator. Symmetric venting reduces cushion lift, differential venting (port vs starboard) reduces lift on one side preferentially providing roll-axis control. The fore seal geometry is actuated by twelve hydraulic jacks distributed across the bow seal width. Coordinated extension changes the effective cushion length and trim while selective extension at port or starboard adjusts roll trim. T-foils mounted forward beneath each sidehull provide hydrodynamic vertical force in response to changes in foil angle of attack. Each T-foil has a 4.0 m span and 1.2 m chord with hydraulically actuated trailing-edge flaps providing ±15° flap deflection for high-frequency heave and pitch damping. Stern flaps integrated into the transom across the full beam, provide low-frequency trim adjustment and contribute to wave-making resistance reduction at intermediate speeds. Waterjet steering nozzles are commanded for both course control and yaw damping . The ARCS adds small-amplitude differential nozzle motion to the autopilot command to cancel wave induced yaw moments. Lift fan flow modulation, achieved by simultaneous coordinated motion of the VIGV and diffuser vanes across all eight fans, provides a high authority command on cushion pressure baseline. The ARCS uses fan modulation to manage the long-term cushion pressure trim while the cushion vent valves manage high-frequency excursions. A "tactical" operating mode relaxes passenger comfort performance criteria in favor of preserving cushion pressure margin against severe wave events and integrates the LiDAR wave profile data with the navigation system to provide automated speed adjustment for sea state induced limitations. In tactical mode the system will accept higher vertical accelerations on the cargo deck (consistent with cargo lashing limits) in order to maintain higher transit speeds.

The Triton uses a zonal Medium Voltage Direct Current (MVDC) electrical distribution architecture. The distribution voltage is 6kV DC on the main ring bus with local zone conversion to 1 kV DC for major loads, 800 V DC for medium loads, and 400 V AC (three-phase, 60 Hz) synthesized locally for legacy AC loads. The al -DC main distribution eliminates the frequency synchronization, phase matching, and reactive power management burden of conventional AC shipboard distribution and allows simpler paralleling of dissimilar sources including generators, batteries, and shore power. Each electrical zone contains its own zone electrical distribution center (EDC) which contains an MVDC bus tie switch to the ring bus, local BESS with bidirectional converter, MVDC-to-1kV converter for major zone loads, MVDC-to-800V converter for medium loads, MVDC-to-400V-AC inverter for legacy AC loads, shore power interface (when applicable), and comprehensive digital control and protection systems with fiber-optic communication to adjacent zones and to the ship's main integrated platform management system. All primary power semiconductors are silicon-carbide (SiC) MOSFETs in modular power blocks for high efficiency at MVDC operating conditions. Zone segregation is enforced by physical separation with each zone is separated from adjacent zones by at least one dedicated bulkhead, by cable routing (main and alternate cable runs are routed through separate cable tracts on opposite sides of the ship), and by control-authority segregation (each zone's control system operates autonomously and can be commanded by the central platform management but is not dependent on it). The resulting distribution architecture is designed to sustain any single zone loss (from battle damage, fire, or flooding) with automatic load re-prioritization across surviving zones and no interruption of critical loads (propulsion control, ride control, navigation, weapons, damage control communications). Zones are cross connected through the main 6kV DC ring bus but each zone is capable of independent operation on its own generator(via cross zone cabling, battery, and emergency diesel resources for indefinite periods. Primary electrical generation is provided by two large permanent-magnet (PM) synchronous generators each driven by one AGT9000 module through the controllable clutch at the forward end of the fan train. The PM generators are radial flux NdFeB permanent magnet synchronous machines rated at 10 MW continuous and 12 MW overload each, generating 6.6 kV variable frequency three phase AC power converted by an active front end rectifier to 6 kV MVDC. The PM machines feed the active rectifier directly with sinusoidal output across the full speed range, allowing the lift fan common shaft to operate at variable speed matching cushion pressure demand without generator side speed regulation. The lift engine modules can therefore vary their operating point continuously to optimize total plant efficiency across the full operating envelope without imposing constant speed constraints on the electrical generation subsystem. The Triton also carries two dedicated emergency diesel generators rated at 5 MW each, sized to provide vital electrical load and emergency cooling load in the event of total reactor plant shutdown. The emergency generators use marine gas oil from a 200 tonne reserve fuel tank providing approximately 300 hours of full load emergency operation.


Vehicle Decks & Cargo Handling:
The Triton carries military cargo on three full width decks above the cushion plenum: the Lower Vehicle Deck (LVD), Main Vehicle Deck (MVD), and Upper Vehicle Deck (UVD). Vertical clearances are 2.8 m on the LVD (general cargo, light vehicles, HMMWVs), 5,2 m on the MVD (heavy military vehicles including MBTs and helicopters, oversize trailered loads), and 2.8 m on the UVD (general cargo, palletised stores). Total vehicle deck area is 32,500 m² of which approximately 24,000 m² is net cargo area. Access ramps and doors include two stern ramps for all vehicle cargo, four side ramps for smaller vehicles, and two bow ramps proving over-the-beach vehicle delivery capability. The stern ramps are 28 m long, 14 m wide hydraulically operated ramps that provides the primary cargo access. The ramps are rated for 120 mt axle loads and can be deployed to quayside, lighterage, or a pierside causeway in approximately 5 minutes. The ramp connects to the main vehicle deck with internal ramps connecting the other decks. The side ramp, 22 m long and 8.0 m wide and provide simultaneous loading/unloading capability and connects directly to the UVD. These ramp are rated for 50 mt axle load (most wheeled vehicles and containers). Two 6.0 meter wide hbow ramps designed for tracked vehicles to 75 tonnes enables over-the-beach operations at approximately 1.8 m minimum trim cushion borne draft, supporting drive off of tracked and wheeled vehicles onto a beach without an intermediate causeway.

An overhead container handling system is installed across the main cargo bay comprising two transverse extending jib cranes (one forward, one aft) and ten overhead positioning carriages on five longitudinal tracks. The cranes are 75 tonne capacity (sufficient for any standard military or commercial container fully loaded) and reach to port or starboard for ship-to-shore or ship-to-ship transfer. The carriages riding on the longitudinal tracks beneath the upper vehicle deck position containers anywhere within the cargo bay. The container handling system permits the Triton to operate as a fast container vessel without physical reconfiguration, the same cargo bay accommodates 480 FEU equivalent (forty foot containers), 980 TEU equivalent (twenty foot containers), or any mixed loadout including ro/ro vehicles in the lower decks and containers in the upper deck. All cargo including vehicles and containers alike are secured by deck-mounted lashing fittings on a 0.5 m × 0.5 m grid throughout the cargo decks. The grid spacing is dense enough to accommodate the lashing requirements of military deployable vehicle. Container twist lock fittings are integrated into the same deck grid through removable adapter sockets. Deck loading capacity is 25 tonnes per square meter on the MVD and 15 tonnes per square meter on the LVD and UVD. A stern cargo elevator, 12 m × 10 m platform area with a 75 tonne capacity provides vertical access between the MVD and the upper-deck helicopter pad. The elevator brings cargo to the upper deck for helicopter pick-up, receives cargo from helicopter landings for stowage on the MVD, and in the elevator's lowered position provides crane-access to the MVD for offloading by shoreside or floating cranes. The elevator is a hydraulically-driven counterweighted scissor-lift, with full safety interlocks and manual fail-safe descent capability. The upper deck includes a Class 1 helicopter landing area of 28 m × 28 m. The pad is constructed of high-traction non-skid deck plate with integral grounded static-discharge connections. Aviation fuel capacity is 30 tonnes stored in dedicated double walled fuel tanks with separate transfer system isolated from all other fuel and lubrication systems. The pad is equipped with NVG compatible lighting, glide-slope indicators, and an automated landing-aid system. There is no hangar as the Triton's helicopter capability is for transfer operations only and not embarked helicopter operations.

The vehicle decks include hardpoint provisions for carrying up to twelve 64 cell SDI S70 cargo magazines. Each VLS magazine is approximately 7 m × 5 m × 8 m in dimensions and 95 tonnes loaded. The hardpoints are arranged on the MVD in two rows of six with deck reinforcement provided in the form of deck plate doubles and integral hard mounting points. Each hardpoint includes power, cooling, fire suppression, and command data interfaces. When VLS modules are embarked the upper deck lightweight fairing doors above each magazine open to provide unobstructed missile launch trajectories. The fairing doors are exterior covers indistinguishable in normal closed configuration from the surrounding upper-deck plating, providing meaningful operational ambiguity to whether VLS is embarked. With twelve magazines total missile inventory is 768 missiles. The VLS magazines when embarked are slaved through external command data links to either an accompanying surface combatant which provides target detection, identification, weapon target pairing, and launch authority or to a self contained combat system container loaded as additional cargo which provides limited organic engagement capability. The Triton itself does not carry any radars or fire control systems supporting offensive missile employment.
Last edited by The Technocratic Syndicalists on Thu Aug 27, 2026 3:59 pm, edited 6 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Wed Jul 08, 2026 1:43 pm

Image


Prowler Class Corvette

Basic Information:
  • Role: Missile corvette
  • Displacement: 1,200 tonnes
  • Crew: 40
  • Length: 70.5 m
  • Beam: 20.5 m
  • Draft: 1.0 m (cushion), 3.5 m (off cushion)
Propulsion:
  • 4x SDI2500 gas turbine propulsion engines, 25 MW each
  • 2x SDI500 gas turbine lift engines, 5.6 MW each
  • 4x AMG 12V 17/19 M57 diesel generators, 1,500 kWe each
  • 2x 3.5 MW electric motors
  • 2x SDI SS150 waterjets, 50 MW each

Performance:
  • Top speed: 80 knots (cushion), 25 knots (off cushion)
  • Range:
      2,500 km at 80 knots
      5,000 km at 60 knots
      10,000 km at 20 knots
Sensors:
  • SDI FMG 400 C Band Multi-function Radar
  • SDI Integrated Bridge and Navigation System
  • SDI FLG 200 Radar & Electro-Optical Fire Control System
  • SDI EOS 200 Electro-Optical Surveillance System
  • SDI RMS 230 Hull-Mounted Sonar
  • SDI VTS 980 High-Speed Towed Sonar

Electronic Warfare and Countermeasures:
  • SDI FMB 300 Electronic Support Measures System
  • SDI LWG 310 Naval Laser Warning System:
  • SDI ZTKG 130 Trainable Decoy Launching System (TDLS)
  • SDI Sea Guardian Surface Ship Torpedo Countermeasure System

Armament:


Overview:
The Prowler is a class of high speed stealth missile corvettes designed by SDI Shipbuilding Systems. The Prowler class is intended to act as a high speed patrol boat for operations around and littoral waters and combined extremely high speed and low radar cross section with anti-surface and anti-submarine sensor and weapon systems.


Design & Construction:
The Prowler class has an overall length of 70.5 meters, maximum beam of 20.5 meters, and a full load displacement of 1,200 tonnes. The Prowler class is a type of surface effect ship (SES) or sidewall hovercraft Two semi displacement sidehulls of high length-to-beam ratio form the lateral cushion boundaries while flexible bow and stern seals enclose the cushion fore and aft. The sidehulls remain partially immersed in all operating conditions and provide directional stability, longitudinal strength, propulsor housings, and the principal hydrodynamic lift in off-cushion mode. The ships can can operate either in on-cushion mode for cruising at high speeds or can operate in off-cushion mode like a conventional catamaran for operating at low speeds. In both modes the wide beam of the ship results in excellent stability characteristics relative to a conventional monohull and is designed to safely operate in up to sea state 6 (9 meter wave height) and in hurricane conditions. The hull has an angular, faceted shape designed to minimize both aero-hydrodynamic drag and radar cross section and includes both hard chines and spray rails to to minimize wave spray at high speeds. Each sidehull is a watertight, longitudinally framed structure extending the full length of the ship. The interior walls of each sidehull are flat to accommodate the planing seal operating envelope. Full keel length fences are integral with the lower sidehull to reduce cushion venting and waterjet inlet air ingestion. The wet deck spans between the sidehulls and forms the upper boundary of the cushion volume. It is a flat panel stiffened structure designed to withstand the slam pressures associated with wave impacts during on cushion operation. The wet deck between the catamaran side hulls includes a complete double bottom, ensuring penetrations of the wet deck will not result in flooding of any operational space. The transverse structure bridging the sidehulls at the main deck level and above carries the global bending and torsional loads.

The hull, superstructure, primary deckhouse, and most internal structural elements are composite, fabricated principally by vacuum-assisted resin transfer molding (VARTM) and controlled atmospheric pressure resin infusion (CAPRI). The composite layups are tailored zonally to combine cost-effective glass-fiber-reinforced plastic (GFRP) for the bulk of the structure with carbon-fiber-reinforced plastic (CFRP) where high stiffness-to-weight is required and where signature management benefits from electrically conductive surfaces. The hull is formed as a series of large, co-cured panel assemblies joined together. he sidehull bottom plating is constructed from quadriaxial (0°, +45°, 90°, and -45°) E-glass fiber reinforced vinyl ester constructed with controlled atmospheric pressure resin infusion with a solid laminate core, designed for impact and ice abrasion performance. Additional plies along the cushion gap waterline handle brash ice and frazil-ice slurry abrasion. Sidehull side plating and the wet deck is a honeycomb sandwich composite consisting of quadriaxial E-glass reinforced vinyl ester face sheets with a PVC foam core. The sidehull is einforced with thicker laminate stacks and pultruded carbon longitudinal stiffeners in the ice belt zone, extending from 1.5 m above the LWL down to the cushion gap height. The main deck is a honeycomb sandwich composite consisting of biaxial (± 45°) carbon fiber reinforced epoxy face sheets over a
PVC foam core. The superstructure shell is biaxial carbon fiber in a vinyl ester matrix, optimized for radar signature. A non conductive fiberglass cloth barrier layer is interleaved at all CFRP-to-metal interfaces. The external hull and superstructure surfaces incorporate tumblehome geometry with planar faceting to redirect radar returns away from threat emitter locations. The composite layup includes frequency-selective surface (FSS) layers and resistive-card radar-absorbing material (RAM) plies integral to the laminate, reducing the broadband radar cross-section of the superstructure by 15 to 20 dB relative to an equivalent metallic structure. All external fittings, sensor apertures, and access panels are designed with edge treatments and impedance-matching to preserve the low-observable profile. Major machinery foundations for the gas turbines, waterjet propulsors, lift-fan drive trains, and diesel generators are fabricated from Ti-5111 plate and forging with bolted connections to facilitate machinery removal and replacement. Vibration isolation mounts are incorporated at all major machinery interfaces.

The air cushion is designed for reduced brittleness at cold temperatures and abrasive damage from frazil ice and brash ice in the marginal ice zone. The bow skirt is as segmented finger-bag composite flexible seal used to trap the pressurized air cushion beneath the vessel, the bag acting as an inflatable shock absorber while independent fingers conform to wave shapes to minimize air leakage and maintain cushion efficiency. A composite cutwater ahead of the bow skirt is designed to deflect ice fragments away from the skirt. The skirt is constructed from chlorobutyl rubber with internal nylon reinforcement and a polyurethane outer wear layer with a glass transition temperature of –55 °C. The stern skirt is a bag type with with redundant inflation lines. Internal cushion pressurization is approximately 6.0 kPa nominal on-cushion, controlled by the ride control system. A skirt heating system consisting of electrical resistive heating elements running within the rubber laminate prevent ice accretion on the wear face and the inboard skirt geometry.


Propulsion
SDI2500 Gas Turbine
  • Type:Aeroderivative gas-turbine
  • Length: 8,300 mm
  • Width: 3,300 mm
  • Height: 3,700 mm
  • Weight: 7,500 kg
  • Compressor: 4 stage LPC, 7 stage HPC/i]
  • Compression ratio: [i]45:1
  • Combustor: annular combustor
  • Turbine: 2 stage HPT, 3 stage LPT, 4 stage PT
  • Specific fuel consumption: 190 g/kW-hr
  • Thermal efficiency: 52%
  • Output: 50,000 kW
  • Fuel: J9, marine diesel
[/list]The ship's main propulsion system uses a CODLOG (Combined Diesel-Electric Or Gas) drive system designed to provide efficient high and low speed propulsion. The high speed drive consists of four GT2500 gas turbine engines driving twin SDI SS150 two stage axial inducer waterjet thrusters through twin epicyclic reduction gear trains. The low speed drive consists of four AMG 16V 17/19 M70 diesel generators sets, each rated at 1,500 kW, provide electrical power to twin 3.5 MW permanent-magnet synchronous motors (PMSM) integrated into each waterjet reduction gear train, being clutched into the corresponding gearbox via a dedicated quill shaft input. The lift system, separate from main propulsion system, consists of four large-diameter centrifugal cushion-lift fans driven in pairs by two SDI GT500 gas turbine engines through dedicated reduction gearboxes.

The four propulsion gas turbines are SDI GT2500 intercooled-recuperated (ICR) gas turbines each rated at 25 MW continuous and 28 MW peak short duration, producing 100 MW continuous total propulsion power and approximately 112 MW peak. Each gas turbine is installed in a sound attenuating enclosure within a dedicated machinery module. The four turbines occupy four isolated compartments in the lower hull, two per side, separated by transverse watertight bulkheads. The port and starboard sides are separated by a centerline longitudinal bulkhead ensuring that a single penetrating weapon hit cannot disable more than two engines. Each turbine is mounted on a rigid titanium raft with a two stage isolation system consisting of polychloroprene compression isolators between the engine feet and the raft and conical wire rope isolators between the raft and the deck mounted hard points. The isolation is designed to deliver approximately 30 dB structure borne attenuation in the 60 to 500 Hz band. Acoustic enclosures around each engine provide a further 35 dB airborne reduction at the source. Inlet ducting for each gas turbine incorporates atwo-stage demister to remove sea-spray water droplets, a coalescing filter element for fine droplets and salt aerosol, an anti-icing duct heater to prevent ice accretion at the demister and filter faces in Arctic conditions, and acoustic baffling to attenuate compressor inlet noise emerging through the duct. Exhaust ducting runs aft from each turbine through a transition section to a single common exhaust plenum located in the aft hull. The exhaust path includes thermal expansion bellows immediately downstream of the engine to accommodate engine-to-duct relative thermal growth, an exhaust eductor section, where the hot exhaust drives a venturi pump that entrains ambient air at a ratio of approximately 4:1 (ambient:exhaust) by mass that reduces the average exhaust temperature from ~320 °C to approximately 110 °C at the discharge, a common four engine collector and a series of horizontal turning vanes to spread the discharge across a wide horizontal slot exhaust at the aft end of the superstructure, and a slight upward angling of the exhaust slot to direct the residual thermal plume above the sea surface minimizing the IR signature visible from a sea-skimming threat seeker.

Each side hull has two GT2500 gas turbines mounted in line, connected to one of the ship's two main reduction gear units with carbon-fiber-reinforced polyetheretherketone (PEEK) drive shafts which connect using flexible elastomeric couplings. Each reduction gear unit receives two GT2500 inputs at 3,600 rpm and one PMSM input at 1,800 rpm and combines them via dedicated quill shafts and overrunning clutches and then reduces them through three gear stages to the waterjet impeller shaft at 320 rpm at full power. Reduction ratio is 11.25:1 from the GT inputs. Each gearbox dissipates approximately 1.5 MW of thermal loss at full power through a dedicated lube oil cooling circuit. All gearbox inputs use overrunning sprag clutches so that a disengaged turbine or motor does not impose drag on the active power source. The clutches are arranged so that any combination of inputs can drive the waterjet. The first stage layshaft has three independent pinion engagements, one per GT and one for the PMSM, each fitted with an overrunning sprag clutch and a torque limiting fluid coupling designed to protect the gear teeth from transient torque spikes. The gear casing is a fabricated and stress relieved nodular cast iron weldment, mounted to the deck on six vibration isolated mounts. Lubrication is forced-feed from a 480 L/min main pump with redundant emergency standby. Lube oil is mineral-based. Cooling is by a plate frame heat exchanger to a closed freshwater loo which rejects heat to a seawater plate cooler. The lube system includes a 5 μm full-flow filter and a 3 μm bypass filter. The system is sized to keep oil-in temperature below 65 °C at full power in tropical seawater (32 °C), in Arctic operation lube oil temperature management is through immersion heaters in the sump to maintain oil viscosity in cold-start conditions, and the cooler bypass is used to keep oil temperature above the minimum operating range.

The SDI Marine Systems SS150 is a two-stage, 150 cm diameter waterjet propulsor rated at up to 50 MW input power and consists of a low speed axial flow inducer that provides sufficient head rise to suppress cavitation at the entry to the main impeller across the full speed range and a mixed flow impeller operating at higher rotational speed provides the primary head rise and thrust generation. The impeller is manufactured from cast Ti-6Al-4V titanium alloy for maximum cavitation erosion resistance and fatigue life. The inducer is driven at a speed ratio of approximately 0.45:1 relative to the main impeller via a concentric, co-axial epicyclic gear reduction unit. Each waterjet propulsor in each sidehull is fed from a single semi-flush seawater inlet with a variable-geometry ramp roof. The ramp-roof position is continuously modulated as a function of ship speed, pump speed, and sea state to maintain optimal inlet pressure recovery and to suppress cavitation across the full operating envelope. Inlet side plates combined with the full keel-length sidehull fences prevent cushion air ingestion that could degrade propulsor performance. An active broach detection system using differential-pressure sensors at the inlet lips closes a servo loop on propulsion engine output-shaft speed to prevent overspeed events. Each waterjet propulsor discharges through a single fixed-area nozzle, a flexible transom seal, and a hydraulically actuated steering sleeve. The steering sleeve at the discharge has a deflection authority of ±30° in the horizontal plane, providing turning moments without requiring rudders. The propulsors additionally incorporate hydraulically actuated thrust reverser buckets for deceleration and low speed maneuvering. Steering is accomplished through the use of thrust vectoring and differential thrust.

The ship's lift system consists of two sets of lift machinery, one in each side hull, along with the lift and ride control system electronics. The lift plant comprises two SDI GT500 turbines each driving a dedicated gearbox feeding two centrifugal lift fans. Each lift turbine is mounted in a dedicated machinery compartment forward of the main GT compartments on its own two stage isolation raft. The lift system uses four large-diameter, low RPM centrifugal lift fans. With fans located at the four corners of the cushion plenum the cushion pressure distribution under varying load conditions. Total lift power of 10,000 kW supports the full load displacement and provides headroom for cushion pressure increases during high speed operation where dynamic effects can locally raise demand. Loss of any one fan reduces lift airflow by approximately 25% and reduces achievable cushion-borne speed by approximately 12%. Loss of any two fans reduces airflow by 50% but the cushion can still be partially maintained at reduced pressure for damage control egress and reduced speed transit. Each fan has an outer rotor diameter of 2.4 meters and operates at 1,600 RPM with a design flow rate of 90 kg/s per fan (360 kg/s total). Each consists of a carbon fiber reinforced composite housing with a a double axial inlet, variable inlet guide vanes, airfoil-shaped carbon fiber reinforced composite radial fan blades, constant-velocity volute housings, and a single annular discharge nozzle. The lift fans employ incorporate Ti-6Al-4V titanium-alloy impellers, double axial inlets, airfoil-shaped radial blades, and constant-velocity volute housings with a single circular discharge. The variable-geometry capability is the primary means of active ride control: by modulating the IGV positions differentially across the six fans, the ride-control system can independently vary the airflow and pressure to the bow seal, cushion plenum, and stern seal to counteract wave-induced heave, pitch, and roll excitations. The lift fans draw in air through intakes located at the front of the weather deck which flows into separate port and starboard air distribution ducts. Air from the forward two lift fans supplies air to the forward seal, air from the central lift fans supplies the central air cushion, and air from the aft two lift fans supplies the aft seal. The lift system uses planning bow and stern seals constructed from glass-reinforced polymer (GRP) designed to have low drag and sustained high-speed water impact resistance. Both bow and stern seals are fully retractable to reduce drag and are pressurized 10-15% higher than the air cushion. The ships' Active Ride Control System (ARCS) integrates the variable-geometry fan drives, vent valves, and their associated servo-hydraulic actuators with a sensor suite comprising two six axis inertial measurement units, two radar altimeters, a bow mounted wave profiling LIDAR, and cushion pressure transducers. The control algorithm is a model-predictive controller (MPC) that anticipates upcoming wave encounters using the forward-looking LIDAR data and pre-positions the fan and valve states to minimize heave accelerations before the wave energy arrives at the cushion while also actuating the vent valves and fan variable inlet guide vanes to regulate the air flow and pressure through the air cushion and seals to dampen ship heave accelerations from waves and provide enhanced ride quality at high speeds. The predictive model-predictive ride-control system reduces on-cushion heave accelerations at the crew’s center of gravity to levels less than 0.1 g RMS for four hour exposures and less than 0.2 g RMS for 30 minute exposures, across the one-third-octave band from 0.1 to 5.0 Hz. ARCS operation is not required in head seas with significant wave heights up to 1.5 m.

Electrical power is provided by four AMG 12V 17/19 M70 diesel generators which each provide 1,500 kWe of 50 hz AC power. The AMG 12V 17/19 M57 is a four-stroke V12 fuel-injected turbocharged marine diesel engine with a 17 centimeter bore, 19 centimeter stroke, and 57.0 liter displacement and has a maximum mechanical power output of 1,700 kWm at 1,800 rpm. The 12V 17/19 M70 engine is used to drive a brushless three-phase four-pole synchronous AC generator which provides electrical power to the ships zonal DC electrical system. All four 1,500 kWe gensets are contained in two dedicated above waterline machinery rooms. Each generator unit is mounted on a two stage acoustic isolation raft connected to the generator unit with polychloroprene compression isolators with viscoelastic damping inserts. The raft is a titanium framed weldment with concrete ballast fill tuned to a first flexural resonance above 200 Hz to avoid coupling with combustion event excitation. The raft is connected to the ship deck with conical wire rope isolators with embedded constrained layer damping. The two stage compound isolation is designed for attenuation exceeding 50 dB at frequencies above approximately 30 Hz. All ancillary connections including fuel, oil, cooling, exhaust, and electrical cross the isolation raft on dedicated vibration decoupling assemblies including flexible hose loops, bellows, and resilient electrical cable transitions.
The AC power from the generators is converted to to 6000 VDC with power conversion modules (PCMs) attached to each generator which then supply both port and starboard DC buses which in turn supply power to 11 independent zones (one for each watertight compartment) which each include one DC/DC PCM per bus (two each per zone) which converts the 6000 VDC to 750-800 VDC or 650 VDC to supply DC loads in each zone. Both DC/DC PCMs in each zone also supply one or more DC/AC PCMs with 750-800 VDC which then converts the 750-800 VDC to 450 VAC at 50 Hz and 400 Hz for AC loads. All electrical loads in each zone are connected to both port and starboard bus ensuring continued operation if either port or starboard bus becomes inoperable. Auxiliary ship systems powered by the zonal DC grid include two 400-Hz AC powered air-conditioning (A/C) plants and two 400-Hz AC powered, centrifugal, packaged refrigeration plants (one each per side hull), an open-loop fire main system capable of 6,000 liters per minute at 900 kPa pressure, aqueous film-forming foam, high velocity fog, and carbon dioxide agent foam fire suppression systems, and closed loop 21 MPa hydraulic system capable of delivering up to 1,000 liters per minute of hydraulic oil flow to the ship's various hydraulic systems.


Sensors & Processing Systems:
FMG 400 Air & Surface Search Radar:For aircraft and surface vessel detection the Prowler class is equipped with an SDI FMG 400 C band multi-function air & surface search radar mounted inside the vessel's enclosed mast. The mast itself is a frequency-selective surface (FSS) constructed from structural foam and fiberglass, permitting the C band radar to transmit through the surface while blocking all other wavelengths. The FMG 400 consists of a GaN (Gallium Nitride) based solid state transmitter operating in the C band (5,4 to 5.9 GHz) with 32 rows of 46 digital Tx/Rx modules each and an integrated IFF antenna which is mounted to an electronically stabilized rotating platform. The radar is scanned mechanically in azimuth and can be scanned ±60° electronically in both azimuth and elevation with -0° to +70° elevation coverage and 360° azimuth coverage and selectable rotation speeds of 60, 20, or 12 RPM. The radar has has a peak power of 25 kW and an 300 km kilometer surveillance and is capable of detecting and tracking up to 1,000 simultaneous targets.

Forward-Looking Ice-Detection Radar: A dedicated millimeter-wave W-band forward-looking radar operating at 95 GHz is mounted on a stabilized platform in a heated radome forward of the bridge with a 120° forward sector coverage. The 95 GHz radar returns are highly sensitive to ice surface texture in a way that conventional X or S-band navigation radars are not, small ice features that are radar-transparent at lower frequencies produce strong, structured returns at 95 GHz.
A 30 cm aperture provides a beamwidth of approximately 0.7° at 95 GHz, providing sub-meter cross range resolution at typical tactical ice-avoidance ranges of 1 to 4 km. The compact aperture is mechanically practical for a stabilized topside installation. Wideband pulse compression at 95 GHz is used to achieve sub-meter range resolution, allowing the radar to discriminate individual ice features and pressure ridges at close range. Open water at grazing incidence returns very little energy at 95 GHz giving very high contrast between ice features and surrounding water. The W-band ice radar is the principal close-in tactical ice-avoidance sensor. The medium range sets provide longer-range ice-edge mapping (out to approximately 25 nmi) and the W-band system provides fine-grained picture in the close-in maneuvering zone. The combination, fused at the navigation display, gives the ship a layered ice picture that supports speeds up to the operational ice-rating limits in marginal ice conditions.

FLG 200 Radar & Electro-Optical Fire Control System: For surface and gunfire control the ship is equipped with an SDI FLG 200 combined radar and electro-optical fire control director mounted forward of the superstructure. The FLG 200 contains both a Ku-band (15.5 - 17.5 GHz) solid state radar and an electro-optical suite containing a thermal imager, television camera, and laser rangefinder which is intended to track both surface targets and subsonic and supersonic sea-skimming missiles in close proximity to the vessel and provides sector search capability, missile launch detection and tracking, and own ship gun fire projectile tracking and splash point detection. The Ku-band monopulse radar employs a solid-state Cassegrain antenna connected to a digital receiver and signal processor and transmits with a peak power of 1.5 kW and has a maximum instrumented range of 36 kilometers. The radar is designed with a high level of ECCM features including extremely low sidelobes, high instantaneous bandwidth, and high frequency agility. The electro-optical suite consists of a 1280 x 1024 pixel Midwave IR (3–5 µm) thermal imager with 0.92° to 30.0°horizontal field-of-view and 30x continous optical zoom, 1920 x 1080 pixel CCD daylight television camera with 64x continuous optical zoom, and an Nd:YAG OPO-shifted 1.54 μm eye-safe laser rangefinder with 50m to 40 km range and <1 meter accuracy. The electro-optical system features automatic tracking of up to four simultaneous targets, automatic sector surveillance, simultaneous TV and IR tracking and sensor fusion, recording capability, and integral GPS interferometer system (GPSIS) for far target location (FTL) capability using the system's laser rangefinder to provide 10-digit grid geo-location of surface targets accurate to within 60 meters at ranges up to 40 kilometers. both radar and electro-optical systems are enclosed in a low-RCS triaxially stabilized mounting capable of elevating from -20 to +120° at a rate of 160 °/s and training a full 360° at a rate of 140 °/s.

RMS 230 Hull-Mounted Sonar: For short range detection of submarines and other undersea objects the Prowler class is equipped with an SDI Underwater Systems RMS 230 hull-mounted sonar which provides full 360° detection of submarines, incoming torpedoes, and undersea obstacles around the vessel using a retractable cylindrical transducer unit mounted in the ship's port catamaran hull.The RMS 230 is a mid-frequency sonar which operates from 3.5 to 6.1 kHz in active mode and 2 to 7.1 kHz in passive mode and consists of the hull mounted omnidirectional transducer unit, transceiver Unit 384 separate transmitting and 384 separate receiving channels channels, and shipboard processor cabinet and operating console with color TV display. Active pulse modes supported by the sonar include continuous wave (CW), linear frequency modulated (LFM), hyperbolic frequency modulated (HFM), and combination waveforms with a pulse length of up to 4 seconds. Supported transmission modes include full 360° omindirectional or sector transmissions with 11.5°, 30°, 60°, or 120° azimuth sectors and up to 60° vertical sectors. The sonar also supports bi-static and multi-static operation using the ship's towed sonar, helicopter dipping sonars, and helicopter, ship, and aircraft deployed sonobuoys. The sonar can be used at speeds up to 40 knots and has a maximum detection range against submarine targets of around 20 km.

VTS 240 High-Speed Towed Sonar: For longer range detection of submarines the Prowler class is equipped with an SDI Underwater Systems VTS 240 sonar. The VTS 240 is a lightweight, high speed, combined active/passive variable depth sonar system designed by SDI Underwater Systems for use on small, high speed vessels such as corvettes or fast attack craft. The VTS 240 consists of a high-powered low-frequency active sonar contained in a variable-depth towed body with 15 m to 300 m operating depth and a directional passive towed array along with a ship mounted winch and handling system, transmit Power amplifier, and sonar operator console. The active transmitter operates in the 1.2 to 1.6 khz frequency range with the passive towed array having continuous 100 hz to 2.0 khz detection capability. The system also supports bi-static and multi-static operation with the ship's hull mounted sonar, helicopter dipping sonar, and helicopter, ship, and aircraft deployed sonobuoys. The twin-line transmitter and receive arrays of the SVDS-240 can be towed at speeds of up to 30 knots and provides over-the-horizon detection of submarine size targets out to a range of around 60 km.


Electronic Warfare & Countermeasures:
FMB 300 Electronic Support Measures System: The ship's primary electronic warfare system is the SDI FMB 300 shipboard tactical ESM suite which provides radar warning and combat direction finding against hostile emitters. The FMB 300 employs a split ESM antenna array on either side of the ship's mast with two domes each containing ten multi-arm spiral antennas providing instantaneous 360° detection of radar signals in the 0.5 to 40 GHz range. The system's receivers employ amplitude monopulse direction finding and intra-pulse signal measurement which provides the system with <2° RMS direction finding accuracy and <2 MHz RMS frequency accuracy and has the ability to track up to 500 emitters simultaneously. The system can also perform emitter distance estimation based on pulse amplitude which can be used to fire interceptor missiles at emitting anti-ship missiles and aircraft. Signals received by the ESM system are compared to an onboard threat library which can store up to 20,000 emitter characteristics.

LWG 620 Naval Laser Warning System: For detecting laser sources including laser range finders, laser target designators, and laser beamriding missiles the ship's FMB 300 ESM system is augmented by an SDI LWG 620 Naval Laser Warning System. The LWG 620 consists of a central controller connected four sensor heads, two on each side of the superstructure, providing 360° around the vessel. Each individual sensor head features 110° azimuth and +/- , 70° elevation coverage and is capable of detecting laser range finders laser target designator emissions in the 0.5 μm - 1.65 μm range and laser beamriders in the 0.8 μm - 1.1 μm range.

SDI Sea Guardian Surface Ship Torpedo Countermeasures System: The ship is fitted with the SDI Sea Guardian Surface Ship Torpedo Countermeasure System which combines various soft-kill and hard-kill torpedo countermeasure systems. The Sea Guardian system consists of a towed array sonar designed specifically for torpedo detection, a towed acoustic decoy with a a single-drum winch, an interface to the ship's trainable decoy launchers, and a processing cabinet with two display consoles, and and four 4-round anti-torpedo torpedo launchers on either side of the ship. The towed array sonar used by the system is a combined active and passive array sonar optimized to detect the high frequency sound signature of torpedo screws and active sonar homing heads. The towed array is supported by two vibration isolated modules (VIMs) located on either side of the sonar with the array being connected on one end to the ship using a fiber-optic tow cable and connected on the other end to the towed decoy with an array tow cable. The towed decoy array is designed to emit simulated ship noise such as propulsor and engine noise to lure a passive-sonar homing torpedo to the decoy instead of the ship. The towed decoy can also receive sonar pings from the active homing head of a torpedo and amplifies and returns the "pings" to the torpedo, presenting a larger false target to the torpedo. The hardkill component of the Sea Guardian system comprises a series of four box launchers on either side of the vessel which each contain six SDI S2s Barracuda anti-torpedo torpedoes in individual all-up rounds (AUR) which contain the Barracuda torpedo and a self-contained compressed gas launch system. The Barracuda torpedo is 21 cm in diameter, 2.0 meters in length, weighs 110 kilograms, and contains a 20 kilogram aluminized PBX explosive warhead. The guidance and fusing system of the Barracuda is designed to explode it in front of the oncoming torpedo and create a pressure wave which crushes the nose section of the oncoming torpedo. The Barracuda has a maximum firing range of 10 kilometers and is propelled by an advanced stored chemical energy propulsion system (ADSCEPS) which can propel the Barracuda at speeds up to 60 knots at depths up to 1,000 meters. Although designed as an anti-torpedo the Barracuda can also be used to engage midget submarines, naval mines, and unmanned or autonomous underwater vehicles.

ZTKG 130 Trainable Decoy Launching System (TDLS): The ZTKG 130 Trainable Decoy Launching System (TDLS) is a trainable decoy launcher which can launch a variety of decoys designed to decoy away anti-ship missile and torpedo threats. The ZTKG system onboard the ship consists of a single 12-round trainable countermeasures launcher mounted above the superstructure which controlled by a central command console inside the ship. The 12-round launcher employs a rotating platform with 12 separate 130mm barrels which can each be individually trained in elevation. The ZTKG is designed to use SDI designed 130 mm decoys including the AM5 dual chaff/IR seduction decoy, AM79 Buzzard active missile decoy, and AM7 Lamprey acoustic decoy.

AM5 dual chaff/IR seduction decoy: The primary chaff seduction round employed by the TDLS is the AM5 dual chaff/IR seduction decoy which is capable of defeating dual-seeker missiles equipped with both IR/EO and radar seekers. The AM5 releases clouds of super-rapid blooming chaff with a 10,000 m2 RCS in the X band along with a series of spectral infrared flares with full coverage in the MWIR (3-5 µm) and LWIR (8-14 µm) bands. The chaff clouds and flare submunitions of the AM5 are designed to be deployed at increasing distances and altitudes from the ship, creating a "walk-off" effect which leads the missile seeker away from the ship.

AM79 Buzzard active missile decoy: For decoying away radar-guided anti-ship missiles the TDLS can deploy the AM79 Buzzard active missile decoy, an expendable electronic-warfare rotary-wing drone which is designed to seduce RF guided anti-ship missiles by simulating the radar return of a large surface vessel. The buzzard features a cylindrical shaped fuselage 130 mm in diameter and 0.9 meters tall with both top and bottom mounted 1.8 meter diameter three-bladed counter-rotating coaxial rotors powered by two brushless DC motors. The rotors unfold from the body of the decoy after launch and fly the decoy into a pre-programmed flight path away from the ship where the decoy then hovers in place while emitting electronic warfare signals uses its fuselage mounted Digital Radio Frequency Memory (DRFM) jammers which are designed to seduce oncoming anti-ship missiles into targeting the decoy and not the host vessel. The decoy is powered by a thermal battery mounted in the center of the fuselage which gives the decoy approximately 60 minutes of flight endurance after launch.

AM7 Lamprey acoustic decoy: The TDLS can also launch the AM7 Lamprey, a 130mm diameter, expendable acoustic decoy designed to counter torpedo threats. After a rocket-powered launch into ocean the Lamprey is programmed to hover vertically using a pressure-controlled motor driving a small, shrouded propeller in the tail of the decoy. The Lamprey is designed to hover at a pre-selected depth from 10-300 meters where it listens for torpedo transmissions. Active acoustic transmissions are detected and analyzed resulting in decoy selectivity and generation of the appropriate deception signal for transmission including target signature and target self noise. If no torpedo transmissions are detected the decoy is programmed to emit warship propulsor and engine noise to lure in passive homing torpedoes. Power for the motor and electronics of the Lamprey is provided by a thermal battery. The Lamprey is programmed to hover and emit noise until the battery dies where the decoy then sinks and all software onboard is erased.


Signature Reduction:
the Prowler class features extensive radar and infrared signature reduction to reduce the ship's detectability to radar and infrared sensors. The hull and superstructure feature a faceted shape with an enclosed mast and sensors suite designed to eliminate corner reflectors and reduce the ship's detectability by radar systems. The composite superstructure of the vessel is fitted with SDI's S-RAM, a type of ballistic grade structural radar absorbing material consisting of 2 cm thick panels made from multiple layers of M5 fibers fibers containing a lossy filler backed by a carbon fiber laminate acting as a reflector. The panels are designed to survive extreme weather exposure and ballistic damage and provides an average -20 dB reflectivity across the 2-40 GHz frequency range (L through Ka bands). The rest of the hull is painted in a radar absorbing paint coating 1 to 5 millimeters thick consisting of lossy dielectric material embedded in a polymer resin which provides -20 dB reflectivity across the 9 -13 GHz range (X band). The infrared signature from the ship's engines is suppressed using an infrared signature suppression system built into the exhaust uptakes. The system consists of a film cooled stainless steel outer duct surrounding a conductively and film cooled stainless steel centerbody and a film cooled stainless steel diffuser which blocks any line of sight view of the heated metal surfaces and reduces uptake metal temperatures to less than 25°C above ambient using ambient air draw into the uptake through a multi-lobed ejector nozzle at the base of the diffuser. The diffuser also contains multiple rings of atomizing nozzles which inject a a fine mist of seawater into the exhaust stream, cooling the exhaust stream to a plume temperature of under 150°C. Seawater injection is controlled by an on board signature management system which interfaces with the ship's propulsion machinery control system and controls the flow of water to the diffuser as a function of engine power.


Passive Protection & Damage Control:
The Prowler class features passive protection in the form of composite armor panels made from M5 ballistic fiber laminated into cured thermoplastic panels which provide ballistic impact and spall protection to the superstructure and vital areas of the ship. The ship's two quadruple RBS 95 missile launchers and the ship's 8.8 cm gun magazine are also encased with welded Ti-6211 titanium alloy plates 30 to 50 mm thick backed by a spall liner consisting of M5 ballistic fibers embedded into an epoxy resin matrix. The ship's blast hardened bulkheads are designed to deform plastically and maintain watertight integrity in the event of an explosion from a bomb or missile warhead inside the ship and feature double-spaced plate construction with an internal fragment resistant membrane designed to stop fragments from penetrating further into the ship. The automatic opening/closing watertight doors in the bulkheads likewise feature a blast hardened membranes structure design with approximately 10 times the blast force resistance of a conventional watertight door.

Damage control is assisted by an SDI Marine Systems developed Automated Ship Control System (ASCS). The ASCS is controlled by a centralized computer which amongst other functions provides real-time damage information to the crew through a graphical display located in the ship's damage control center. Additionally both the ship's bridge and CIC also also fitted with displays connected to the ASCS. The ACSC is designed to run automatically where after the ASCS detects damage to a compartment it will immediately isolate it and activate appropriate damage control measures. Alternatively the ASCS can be set to manual mode where the operator will have to specify the damage control measures after the system detects ship damage. The ASCS also controls and monitors the ship's engines and machinery and will alert engineers on watch duty through their assigned tablet computer when an engineering issue or machinery failure is detected and requires attention. This remove the need for time based maintenance, the system will simply alert the crew when a component or system requires maintenance. Each compartment and each piece of machinery on the ship are monitored using SDI's Two Wire Automatic Remote Sensing Evaluation System (TWARSES) which includes both visible CCD and infrared cameras located in each ship compartment. After damage is detected in a compartment the ASCS can respond in a variety of ways including isolating the damaged compartment by closing the electrically actuated watertight doors around the compartment. If the IR camera detects a fire the system will activate the compartment's overhead sprinklers and can also pump the compartment with aqueous film-forming foam , high velocity fog, and/or carbon dioxide agents if necessary. After the fire is extinguished water and firefighter agents are removed using a bilge draining pump installed in each compartment. The ASCS will also reroute ventilation, electrical power, and water around the damaged area and activate additional pumps, generators and other devices if necessary. If the compartment has been breached and is in danger of flooding the system will flood the compartment with foam which rapidly solidifies and restores reserve buoyancy. This system however is only used as an absolute last resort as it renders the compartment unusable. The ASCS also controls the ship's CBRN protection system by passing air from the ventilation intakes through containment filters before it enters the ship. Air in the ship is maintained at 5.0 millibars above local atmospheric pressure to provide a positive pressure and prevent contaminated air from entering into the ship through a breach in the hull.


Armament:
8.8 cm SK L/78 naval gun: The 8.8 cm SK L/78 naval gun is a fully automated dual purpose naval gun turret system intended for use on small displacement. Developed from an anti-aircraft field gun the 8.8 cm SK L/78 employs a water cooled barrel with a replaceable loose liner and a vertical-sliding breech block which opens downward under the force of recoil. The gun is connected to an automated ammunition supply system containing 80 rounds stored in a carousel beneath the turret. Loading can be achieved at any elevation and the gun has a maximum sustained rate of fire of 120 rounds per minute. The gun fires 88×855R mm single piece ammunition weighing 20.5 kilograms including a 9.4 kilogram projectile. Muzzle velocity is 1,000 m/s and the gun has a maximum range against surface targets of 19,800 meters. The complete gun mount weighs 7,900 kg without ammunition and the capable of training +/- 165° on either side of the ships centerline at a rate of 60°/s and elevating from -15° to +85 degrees at a rate of 60°/s. A shipboard fire control support system is used for control of the gun which plans fire support missions, determines firing solutions and shell trajectories, selects ammunition, and determines the best ship course for executing fire support missions.

RBS 95 missiles: The primary armament of the Prowler class corvette is two retractable missile launchers on either side of the foredeck which each contain four RBS 95 hypersonic missiles contained in modified SDI S70 vertical launch system canisters. The S70 canister is a cold launch type of vertical launch system and uses a gas generator to accelerate the missile to a speed of 40 m/s, expelling it from the launch tube where the booster rocket motor is then ignited at a distance of 25 meters at a forward speed of 30 m/s, ensuring that missiles with malfunctioning motors do not crash back onto the ship even when traveling at full speed. The missile launchers retract into the hull when not in use to reduce aerodynamic drag and permit missiles to be launched in both on and off-cushion ship operational modes. Each quad launcher assembly is housed in a watertight, titanium-lined recess within the 01-level structure, covered by flush-fitting composite hatch covers that form part of the upper deck surface when closed. To prepare for launch, the hatch covers retract hydraulically and the launcher assembly elevates to the firing position on a scissors-lift mechanism, a sequence that takes approximately 15 seconds from the launch command. The launcher recesses are located port and starboard of the centerline, forward of the superstructure. The launchers are operable in all three ship modes including on-cushion, partial-cushion, and off-cushion.

S70 Vertical Launch System: The Prowler class is fitted with a total of 8 S70 vertical launch cells placed in an 8 cell module which is designed to contain a quad-pack of four SDI Rb 81 surface to air missile. The S70 is cold-launch vertical launch system which uses missiles encased in individual concentric launch cells as modular all-up rounds (AURs) each containing the missile, concentric launch tube, launch tube electronics, and missile ejection system. The S70 8-cell modules contain 8 launch cells in a 4x2 arrangement with the launch cells inclined at a 10 degree angle towards the ships centerline to prevent missiles with malfunctioning rocket motors from crashing back onto the deck after launch. The missiles are ejected from each launch tube using a steam generator system which uses a small solid-propellant gas generator which exhausts through cooling water into the base of each launch cell, creating expanding high pressure steam which then forces the missile out of the launch tube. Safety and passive protection features of each VLS module include concentric anti-fragmentation shields placed around each launch cell tube to prevent in-cell missile fratricide and a deluge system which can flood each 8 cell module in the event of a missile catching fire in the launch tube. Launch tubes are connected to the launch cells through shock collar that is designed to absorb acceleration loads from an underwater detonation near the ship. The individual missile cells are connected to the ship's weapon control system via redundant port, central, and starboard fiber-optic ethernet lines which transmits launch commands to the individual missiles and allows for missile status information before launch to be sent back to the weapon control system.

40 cm Torpedo Launch System : For close-in anti-submarine the ship is equipped with two twin 40 cm Torpedo Launch Systems, one on each side of the hull for launching SDI F3s Viperfish anti-submarine torpedoes. Each Torpedo Launch System consists of twin fixed shock mounted 40 centimeter torpedo launch tubes, an air charging system, a 12 cell torpedo magazine, and a launcher control station which is connected to the ships' Sea Lance Undersea Combat System. Each F3S Viperfish torpedo is 40 cm diameter, 2.85 meters long lightweight anti-submarine torpedo powered by advanced stored chemical energy propulsion system (ADSCEPS) driven pumpjet propulsor. The torpedo has a maximum speed of 60 knots with a range of 15 km at 60 knots or 25 km at a lower speed of 40 knots. The F3S torpedo is equipped with a fully digital electronically steered 2D phased array active/passive sonar seeker combined with fiber-optic wire guidance. The torpedo is equipped with a 60 kilogram shaped charge warhead designed to penetrate the hulls of large double-hulled submarines.
Last edited by The Technocratic Syndicalists on Thu Aug 27, 2026 5:36 am, edited 1 time in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Sat Aug 15, 2026 11:39 am

Image


Orkan Class Landing Craft

Basic Information:
  • Role: Hybrid surface effect ship/air cushion landing craft
  • Displacement: 3,000 tonnes full load
  • Crew: 10
  • Length: 85.0 m
  • Beam: 27.0 m
  • Draft: 1.2 m (cushion), 4.0 m (off cushion)
Propulsion:
  • 4x SDI2500 gas turbine propulsion engines, 25 MW each
  • 2x AMG 16V 17/21 M76 diesel lift engines, 2,500 kW each
  • 4x AMG 20V 17/21 M95 diesel generators, 3,000 kWe each
  • 2x 5.0 MW electric motors
  • 2x SDI SS150 waterjets, 50 MW each

Performance:
  • Top speed: 70 knots (cushion), 20 knots (off cushion)
  • Range:
      1,000 km at 50 knots (fully loaded)
      6,500 km at 20 knots (no payload)
Sensors:
  • SDI FMG 960 S band Surface Search & Navigation Radar
  • SDI FMG 970 X band Surface Search & Navigation Radar
  • SDI Integrated Bridge and Navigation System

Electronic Warfare and Countermeasures:
  • SDI FMB 300 Electronic Support Measures System
  • SDI LWG 310 Naval Laser Warning System:
  • SDI ZTKG 130 Trainable Decoy Launching System (TDLS)
  • SDI Sea Guardian Surface Ship Torpedo Countermeasure System

Armament:


Overview:
The Orkan class is a high speed, long range, heavy lift amphibious landing craft designed by SDI Marine System. The Orkan combines Surface Effect Ship (SES) technology with full air cushion hovercraft capability, enabling high speed waterborne transit as an SES before transforming into a hovercraft to cross surf zones and drive onto unimproved beaches before delivering its cargo. The platform’s high speed, shallow draft and low signature make it both highly survivable and capable of high volume cargo transfer in contested maritime environments. The vessel features a fully enclosed, low observable hull form with a composite superstructure optimized for minimal radar signature, comprehensive arctic operations capability to −50°C, and autonomous/semi-autonomous operation capability using SDI's TRIDENT autonomy software.


Design & Construction:
The Orkan class has an overall length of 85.0 meters, maximum beam of 27.0 meters, and a full load displacement of 3,000 tonnes with a 750 tonne payload. The hull consists of twin rigid catamaran side hulls connected by a central wet deck. Each sidehull is a watertight, longitudinally framed structure extending the full length of the ship. The interior walls of each sidehull are flat to accommodate the planing seal operating envelope. Full keel length fences are integral with the lower sidehull to reduce cushion venting and waterjet inlet air ingestion. As a conventional SES side hulls containing the central air cushion during waterborne transit, and as structural hosts for the retractable hovercraft skirt system. The side hulls are wider and deeper than a pure SES to accommodate retracted skirt storage bays. When deployed the hovercraft skirt extends outboard and beneath the side hulls, wrapping the entire hull in a continuous flexible skirt for full air-cushion hovercraft operation. The wet deck spans between the sidehulls and forms the upper boundary of the cushion volume and is a flat panel stiffened structure designed to withstand the slam pressures associated with wave impacts during on cushion operation. The wet deck between the side hulls includes a complete double bottom, ensuring penetrations of the wet deck will not result in flooding of any operational space. The transverse structure bridging the sidehulls at the main deck level and above carries the global bending and torsional loads. The hull and superstructure has an angular, faceted shape designed to minimize both aero-hydrodynamic drag and radar cross section and includes both hard chines and spray rails to to minimize wave spray at high speeds. The fully enclosed superstructure with CFRP composite construction and faceted low observable geometry accommodates four large swiveling ducted propulsor fans on structural pylons. The primary hull structure is fabricated from Ti-5111 (Ti-5Al-1Sn-1Zr-1V-0.8Mo) near-alpha titanium alloy, offering an exceptional combination of intermediate strength, high toughness, excellent weldability, seawater stress-corrosion cracking immunity, and room temperature creep resistance. The alloy’s complete immunity to seawater stress-corrosion cracking and essentially zero corrosion rate eliminates all protective coatings, cathodic protection systems, and corrosion-related through-life maintenance — a major cost and operational benefit for a vessel spending its entire life in the marine environment. The non-magnetic hull provides inherent mine countermeasure advantages. The exceptional fire resistance (titanium does not lose structural strength until temperatures far exceeding those that would collapse steel or aluminium structures) provides superior survivability. The full cryogenic ductility of Ti-5111 (maintaining toughness to liquid nitrogen temperatures) makes it inherently arctic temperature capable without the brittle fracture concerns of carbon steels. Hull construction employs conventional stiffened plate construction adapted for titanium with Ti-5111 plate cut by waterjet, formed to shape, and joined by Gas Tungsten Arc Welding (GTAW) in an inert argon shielded atmosphere. Longitudinal framing is incorporated throughout. Side hull skirt storage bays are integral structural compartments with watertight doors. Propulsor fan pylons are primary structure integrated with the superstructure. Ti-5111’s cryogenic properties eliminate all low-temperature material concerns. The bow region and waterline ice belt incorporate increased plate thickness and additional framing for PC7 ice class. The superstructure above the main hull girder is fabricated primarily from carbon fiber reinforced polymer (CFRP) sandwich panels with closed cell foam or Nomex honeycomb cores. Composite construction provides substantial weight savings compared to metallic superstructures, reducing topside weight and lowering the vessel’s vertical center of gravity, critical for stability in an SES operating on cushion. The composite panels are engineered with embedded frequency-selective surface (FSS) layers and radar-absorbing materials (RAM) to further reduce RCS. The composite superstructure also provides excellent thermal insulation, a significant benefit for arctic operations, reducing heating loads and preventing interior condensation. The pilothouse is integrated into the forward superstructure as a low profile faceted enclosure with angled windows set at inclinations to deflect radar returns. The pilothouse windows feature high strength, heated laminated glass windows with embedded deicing elements and an outer hydrophobic coating to ensure clear visibility in arctic and icing conditions.


Propulsion
SDI2500 Gas Turbine
  • Type:Aeroderivative gas-turbine
  • Length: 8,300 mm
  • Width: 3,300 mm
  • Height: 3,700 mm
  • Weight: 7,500 kg
  • Compressor: 4 stage LPC, 7 stage HPC/i]
  • Compression ratio: [i]45:1
  • Combustor: annular combustor
  • Turbine: 2 stage HPT, 3 stage LPT, 4 stage PT
  • Specific fuel consumption: 190 g/kW-hr
  • Thermal efficiency: 52%
  • Output: 25,000 kW
  • Fuel: J9, marine diesel
[/list]The ship's main propulsion system uses a CODLOG (Combined Diesel-Electric Or Gas) drive system designed to provide efficient high and low speed propulsion. The main propulsion drive consists of four GT2500 gas turbine engines arranged in two staggered in-line pairs within each side hull, each turbine driving a single large two stage axial inducer waterjet thruster through a main reduction gearbox (MRG). Each MRG also incorporates a Synchro-Self-Shifting (SSS) clutched power take-off (PTO) shaft that drives one of the four overhead hovercraft propulsor fans. A permanent magnet motor/generator is mounted directly on each waterjet output shaft in line with the pumpjet drive disconnect clutch that provides diesel-electric propulsion for off-cushion operations with electricity supplied from four diesel generator sets. The four SDI GT2500 intercooled-recuperated (ICR) gas turbines are installed as two staggered in-line pairs within each side hull, with the forward turbine of each pair offset laterally and vertically from the aft turbine to fit within the hull cross section while maintaining adequate separation for intake air flow, exhaust routing, and maintenance access. Each turbine is mounted on resilient mounts within its own acoustic enclosure. Combustion air is drawn through heated, filtered intakes in the hull sides while exhaust gases are routed through reductor-type IR suppression systems before discharge through shielded outlets at the rear of the superstructure. The staggered inline arrangement minimizes the length of the machinery space while keeping the exhaust uptakes compact and separate. The port and starboard sides are separated by a centerline longitudinal bulkhead ensuring that a single penetrating weapon hit cannot disable more than two engines. Each turbine is mounted on a rigid titanium raft with a two stage isolation system consisting of polychloroprene compression isolators between the engine feet and the raft and conical wire rope isolators between the raft and the deck mounted hard points. The isolation is designed to deliver approximately 30 dB structure borne attenuation in the 60 to 500 Hz band. Acoustic enclosures around each engine provide a further 35 dB airborne reduction at the source. Inlet ducting for each gas turbine incorporates a two-stage demister to remove seaspray water droplets, a coalescing filter element for fine droplets and salt aerosol, an anti-icing duct heater to prevent ice accretion at the demister and filter faces in Arctic conditions, and acoustic baffling to attenuate compressor inlet noise emerging through the duct. The exhaust path includes thermal expansion bellows immediately downstream of the engine to accommodate engine-to-duct relative thermal growth, an exhaust eductor section, where the hot exhaust drives a venturi pump that entrains ambient air at a ratio of approximately 4:1 (ambient:exhaust) by mass that reduces the average exhaust temperature from ~320 °C to approximately 110 °C at the discharge, a common four engine collector and a series of horizontal turning vanes to spread the discharge across a wide horizontal slot exhaust at the aft end of the superstructure, and a slight upward angling of the exhaust slot to direct the residual thermal plume above the sea surface minimizing the IR signature visible from a sea-skimming threat seeker. Each side hull has two GT2500 gas turbines mounted in line each connected to one of the ship's four main reduction gear units that provides two outputs including the primary waterjet drive output and an SSS clutched PTO output to drive a single hovercraft propulsion fan. The GT2500 gas turbine connects to the input of each MRG through carbon-fiber-reinforced polyetheretherketone (PEEK) drive shafts which connect using flexible elastomeric couplings. In each MRG the 3,600 rpm gas turbine inlet shaft RPM is reduced through three gear stages to the waterjet impeller shaft at 320 rpm at full power. Reduction ratio is 11.25:1 from the GT inputs. Each gearbox dissipates approximately 750 kW of thermal loss at full power through a dedicated lube oil cooling circuit. The first stage layshaft has an independent pinion engagement fitted with an overrunning sprag clutch and a torque limiting fluid coupling designed to protect the gear teeth from transient torque spikes. The gear casing is a fabricated and stress relieved nodular cast iron weldment, mounted to the deck on six vibration isolated mounts. Lubrication is forced-feed from a 240 L/min main pump with redundant emergency standby. Lube oil is mineral-based. Cooling is by a plate frame heat exchanger to a closed freshwater loo which rejects heat to a seawater plate cooler. The lube system includes a 5 μm full-flow filter and a 3 μm bypass filter. The system is sized to keep oil-in temperature below 65 °C at full power in tropical seawater (32 °C), in Arctic operation lube oil temperature management is through immersion heaters in the sump to maintain oil viscosity in cold start conditions, and the cooler bypass is used to keep oil temperature above the minimum operating range. Each MRG PTO output connects to a vertical carbon fiber composite shaftline that runs up through the side hull structure into the superstructure where it drives a single overhead propulsor fan through a right angle bevel gear transfer case. The PTO shaftline passes through watertight shaft seals at each deck penetration. The SSS (Synchro-Self-Shifting) clutch on the PTO output is an overrunning clutch that engages automatically when the driving shaft speed exceeds the driven shaft speed, and disengages automatically when the driven shaft overruns. The clutch engages whenever the GT2500 is running and the fan load is present and disengages automatically when the turbine is secured, allowing the fan to windmill freely. A servo lock-out feature permits the PTO to be disabled when fan operation is not desired (SES only mode). An axial flux permanent magnet (AFPM) motor/generator is mounted directly on each waterjet output shaft. Each motor is a NdFeB double-stator ironless-rotor machine rated at 3 MW continuous and 5 MW peak power.In motor mode, the four AFPM units draw power from the MVDC bus supplied by the diesel generators and drive the four waterjets for off-cushion diesel-electric propulsion at up to 20 knots. In generator mode during gas turbine operations they instead feed the MVDC bus, powering all ship systems without needing to run the diesel generators. The pumpjet disconnect clutch is closed during diesel-electric operation and open during hovercraft mode, the motor/generator can operate as a generator driven by the waterjet shaft windmilling in SES mode if desired for supplementary power. Each MRG output shaft drives a single SDI Marine Systems SS100 two stage axial inducer waterjet thruster mounted at the transom of its respective side hull. The SDI Marine Systems SS125 is a two-stage, 125 cm diameter waterjet propulsor rated at up to 25 MW of input power and consists of a low speed axial flow inducer that provides sufficient head rise to suppress cavitation at the entry to the main impeller across the full speed range and a mixed flow impeller operating at higher rotational speed provides the primary head rise and thrust generation. The impeller is manufactured from cast Ti-6Al-4V titanium alloy for maximum cavitation erosion resistance and fatigue life. The inducer is driven at a speed ratio of approximately 0.45:1 relative to the main impeller via a concentric, co-axial epicyclic gear reduction unit. Each waterjet propulsor in each sidehull is fed from a single semi-flush seawater inlet with a variable-geometry ramp roof. The ramp-roof position is continuously modulated as a function of ship speed, pump speed, and sea state to maintain optimal inlet pressure recovery and to suppress cavitation across the full operating envelope. Inlet side plates combined with the full keel-length sidehull fences prevent cushion air ingestion that could degrade propulsor performance. An active broach detection system using differential-pressure sensors at the inlet lips closes a servo loop on propulsion engine output-shaft speed to prevent overspeed events. Each waterjet propulsor discharges through a single fixed-area nozzle, a flexible transom seal, and a hydraulically actuated steering sleeve. The steering sleeve at the discharge has a deflection authority of ±30° in the horizontal plane, providing turning moments without requiring rudders. The propulsors additionally incorporate hydraulically actuated thrust reverser buckets for deceleration and low speed maneuvering. Steering is accomplished through the use of thrust vectoring and differential thrust.

The SES air cushion is formed between the twin rigid side hulls with flexible seals at the bow and stern enclosing a pressurized air cavity. At the design cushion pressure of approximately 7.5 kPa the air cushion supports approximately 65 percent of the vessel’s full load displacement with the remaining 35 percent carried by buoyancy of the immersed portions of the side hulls. This partial lift reduces wetted surface area by approximately 80 percent compared to the off-cushion condition, dramatically lowering frictional and wavemaking resistance and enabling speeds exceeding 60 knots. The cushion volume is divided into three longitudinal compartments, forward, midships, and aft , separated by flexible transverse divider curtains suspended from the wet deck. Each compartment is independently pressurized and vented, enabling differential pressure control for pitch and roll stabilization. The compartment pressures are continuously modulated by the ride control system to maintain optimal vessel attitude. Controllable ventilation louvers in the wet deck and side hull lower surfaces enable rapid pressure relief for heave damping. The bow seal employs a multi-finger flexible skirt design consisting of approximately 60 individual finger elements, each fabricated from multi-layer reinforced elastomeric composite material. The finger construction consists of an inner structural fabric layer, an elastomeric bonding matrix, and an outer wea -resistant and hydrodynamically smooth skin. Each finger is attached to a rigid header beam at the bow structure through bolted clamp bars that permit individual finger replacement without removing the entire seal assembly. The fingers are arranged in three overlapping rows (primary and secondary curtains) to provide redundancy, loss of several individual fingers does not result in catastrophic cushion air loss. The overlapping arrangement also creates a labyrinth seal effect that improves air containment efficiency. The fingers are compliant enough to conform to the sea surface and deform around passing waves, allowing waves to pass beneath the craft with minimal cushion pressure loss, while being stiff enough to resist flutter and hydrodynamic lift-off at speeds exceeding 60 knots. For arctic operations, the bow seal fingers are fabricated from a cold-rated elastomeric compound with a brittle-ductile transition temperature below −60°C and a Shore A hardness specified at −40°C to ensure adequate flexibility in extreme cold. Electric trace heating elements embedded in the finger root attachment zone and header beam prevent ice bonding between fingers and the hull structure. A hydrophobic fluoropolymer coating on the finger surfaces reduces ice adhesion. Forward of the bow seal, a retractable rigid ice deflector (a V-shaped steel structure that can be hydraulically lowered into the water) protects the flexible seal fingers during navigation in ice-covered waters by deflecting ice pieces to the sides before they contact the seal. The stern seal contains the aft boundary of the air cushion against the dynamic pressure of water flowing beneath the craft at speed. It employs a loop-and-planing-surface configuration consisting of a pressurised bag element (the loop) that maintains the seal shape and a flexible planing surface that trails aft in contact with the water. The loop is inflated from the cushion air supply to a pressure slightly above cushion pressure, maintaining its cross-sectional shape under hydrodynamic loading. The planing surface is fabricated from multi-layer reinforced elastomeric composite with a wear-resistant polyurethane or UHMWPE (ultra-high molecular weight polyethylene) skin on the water-contact face, designed to withstand continuous high-speed abrasion. The stern seal is subject to continuous water contact, abrasion, and hydrodynamic flutter and is designed as a modular, rapidly replaceable assembly: the entire stern seal can be replaced in-situ by a maintenance team in approximately 4 to 6 hours without drydocking using bolted attachment rails and quick-connect air supply fittings. Spare seal assemblies are carried aboard for field replacement during extended deployments. The stern seal is geometrically configured to minimize drag while containing the cushion with the planing surface angle optimized to balance air containment, drag, and spray generation. Arctic provisions mirror the bow seal with cold rated elastomeric compounds (−60°C transition), electric trace heating at attachment zones, and hydrophobic coatings. The retractable inflatable hovercraft skirt transforms the vessel from SES to full air-cushion hovercraft. The skirt is a continuous flexible structure that when deployed, extends outboard of and beneath the twin rigid side hulls to create a full 360° perimeter seal, converting the vessel from partial-lift SES to full-lift hovercraft capable of rising completely clear of the water and traversing over land. The skirt is fabricated from heavy-duty multi-layer reinforced elastomeric composite inner structural fabric of high-tenacity ballistic nylon weave, an elastomeric bonding matrix of neoprene rubber compound, and outer wear-resistant abrasion skin of UHMWPE. The skirt consists of an outer bag section and inner finger elements that form the ground contact seal. The skirt is divided into port and starboard halves running the full length of the hull and stored folded in a dedicated longitudinal bay within the lower outboard section of its respective side hull. Each bay is sealed by a series of hydraulically actuated watertight doors. Deployment sequence starts as the bay doors open, lift fan airflow is redirected to the skirt plenum via motorized diverter valves, the skirt inflates and unfolds under air pressure assisted by pneumatic deployment actuators and guide cables that control the unfolding sequence. For retraction the skirt is partially deflated where powered winch cables then draw the skirt back into the bays, folding it into a compact stowed configuration. All sequences are automated and can be commanded from the bridge or by the autonomy system. For arctic operations the skirt material uses a cold rated neoprene compound with brittle-ductile transition below −60°C. Skirt storage bays are heated to prevent frozen/stiffened skirt material. The full hovercraft mode enables transit over ice, frozen beaches, snow fields, and frozen marshlands. SES air cushion and hovercraft skirt pressurization is provided by four advanced variable-geometry centrifugal lift fans. Each fan is a high volume, medium pressure centrifugal unit. Each fan is fitted with a set of Variable Inlet Guide Vanes (VIGVs), a ring of adjustable vanes at the fan inlet that modulates the preswirl and effective flow area entering the impeller. By varying VIGV angle from fully open (maximum flow) to partially closed (reduced flow at higher pressure) the fan operating point is shifted along its characteristic curve without changing rotational speed, enabling rapid cushion pressure modulation for ride control, Variable angle diffuser vanes downstream of the impeller optimize pressure recovery across the operating range, maintaining high fan efficiency at off-design conditions. In addition to geometry variation, each fan is driven through a variable-ratio transmission from its dedicated diesel engine enabling coarse speed adjustment to complement the fine VIGV control. Each fan is rated at approximately 3,000 SHP input power, producing approximately 200 m³/s at the design cushion pressure of 7.5 kPa. The four fans are arranged symmetrically with two forward and two aft of the cushion midpoint to enable independent control of pressure distribution between the three cushion compartments. Air from each fan is distributed through insulated steel ducts with motorized dampers to the appropriate cushion compartment(s) with motorised diverter valves and distribution manifolds that redirect airflow between SES cushion compartments and the full hovercraft skirt plenum. The ductwork includes acoustic silencers to minimize fan noise transmission to the cargo bay and crew spaces. Each of the four lift fans is powered by a dedicated high speed marine diesel engine providing complete independence of the lift system from the main propulsion gas turbines. This separation ensures cushion pressure is maintained regardless of main propulsion status, essential during beach landing when waterjets are not driving the craft, and for maintaining on-cushion condition during cargo loading/unloading at sea. Total installed lift fan power is approximately 10,880 BHP (8,120 kW) from the four diesels. Each engine is mounted on resilient antivibration mounts within an acoustic enclosure and drives its lift fan through a mechanical transmission with a flexible coupling. The engines are arranged two in each side hull in dedicated lift fan engine rooms separated from the main propulsion machinery spaces by watertight bulkheads. Each engine room has independent ventilation, combustion air supply (with heated snow/ice separators for arctic operations), and exhaust uptakes integrated into the hull’s low-observable exhaust system. The lift system can be started and brought to full cushion pressure in approximately 60–90 seconds from cold start, or 30–45 seconds from standby (engines idling).

Four large ducted propulsor fans are mounted on structural pylons above the aft superstructure, two port and two starboard, one driven by each main GT2500 engine. Each fan is a 6.5 meter diameter eight bladed axial fan enclosed in a CFRP composite duct that improves thrust efficiency by 25–30 percent over an unshrouded propeller and provides noise attenuation and personnel protection. The fan blades are hollow CFRP composite with titanium leading edges for FOD resistance. Each fan assembly is mounted on a powered azimuth bearing allowing swivel through ±35 degrees, providing full thrust vectoring for directional control, braking, lateral translation, and yaw management in hovercraft mode. Total thrust from all four fans is sufficient to propel the fully loaded 3,000 tonne craft at 40 knots in hovercraft mode over water and 20 to 25 knots over land. Fan tip speed is designed below Mach 0.85 to avoid shock losses and excessive noise. Each fan incorporates variable pitch blades for rapid thrust modulation and reversal without changing rotational speed enabling precise speed and position control during beach approach and departure. Each fan is driven by an associated MRG PTO output shaft, starting from the SSS clutch output flange to a horizontal-to-vertical right-angle spiral bevel gear unit to a carbon fiber composite vertical shaftline to an upper 90° bevel gear unit to the fan hub with its variable pitch mechanism. The vertical shaftline is supported by two intermediate bearings with self aligning mounts. Total PTO drive train weight per fan is approximately 4,500 kg. All bevel gear units use forced lubrication with filtered synthetic oil and integrated condition monitoring (vibration, temperature, oil debris). SES to Hovercraft transition starts with vessel reducing speed to 40 to 45 knots knots as the skirt bay doors open and the PTO servo lockouts in each MRG are released. The hovercraft skirt then inflates from side hull bays as the lift fans increase output to pressurize both SES cushion and hovercraft skirt simultaneously, the vessel rising as total cushion area increases while the RCS compensates for changing dynamics. The SSS clutches engage automatically as GT2500 torque reaches PTO shafts, the fans then spinning up as both waterjets and fans propel the vessel simultaneously. When full hovercraft cushion pressure is reached. and the side hull bottoms clear the water the pumpjet disconnect clutches open and all GT power transfers to the fans via SSS PTOs, the craft now in operating in full air-cushion hovercraft at 35 to 40 knots. As the craft approaches the beach the variable-pitch fans vector for course speed control. The craft crosses the surf zone on cushion, negotiates the beach gradient (≤1:10), drives onto landing area where the ramp then deploys for cargo unload. Upon departure reverse fan thrust backs the craft off the beach where it enters the water, the pumpjet clutches engage as the inlets submerge, the hovercraft skirt retracts into the hull side bays, the SSS PTOs disengage, and the vessel returns to waterborne SES mode. The active closed loop ride control system integrates accelerometers, rate gyroscopes, VRUs, cushion pressure transducers, speed/heading data, and a forward looking wave profiling LIDAR system (1550 nm, 200–500 m look-ahead, 10 to 20 Hz) for predictive feed forward control. Ride control effectors include variable geometry lift fan VIGV modulation, cushion compartment vent louvers, active stern seal actuators, and differential waterjet/fan thrust. The LIDAR reduces peak accelerations by 30 to 50% versus feedback only control. The ride control system’s sensor suite and effector set are extended into a full six-degree-of-freedom (6-DOF) dynamic positioning system (DPS). The DPS provides highly precise station-keeping in surge, sway, heave, roll, pitch, and yaw, enabling the vessel to maintain position and attitude alongside a floating sea base or RO-RO cargo vessel in up to Sea State 4 for rolling stock vehicle transfer via the stern ramp. The DPS uses differential GNSS for absolute horizontal position (±0.1 m accuracy);, laser range/bearing tracking systems measuring distance and angle to retroreflectors on the host vessel, the wave profiling LIDAR for predictive wave encounter estimation, motion reference units (MRUs) providing real-time 6-DOF motion measurement, wind sensors for environmental feed forward, and radar and optical based relative motion sensors tracking the host vessel’s position and motion. The DPS controls thrust vectoring of the four independently controllable waterjets to provide surge, sway, and yaw forces while differential waterjet thrust provides roll moment, controls variable geometry lift fan cushion modulation to provide heave and pitch control, controls the active stern seal and interceptor blades to provide additional pitch and heave damping, and in hybrid mode the four overhead propulsor fans provide supplementary surge, sway, and yaw forces through thrust vectoring. The redundancy of the four independent waterjets and four independent fans ensures that dynamic positioning capability is maintained even with the loss of any single thruster. The DP control algorithm employs a Kalman filter based state estimator fusing all sensor inputs, with separate lo -frequency position keeping and high-frequency wave frequency motion rejection control loops. The low frequency controller commands the thrusters to maintain the desired position and heading against slowly varying environmental forces. The high-frequency controller, augmented by the LIDAR wave prediction, actively dampens wave induced motions to maintain the stern ramp interface within the allowable relative motion envelope for safe vehicle transfer. The target relative motion at the ramp interface is less than ±1.0 meter in heave and less than ±2.0 degrees in pitch and roll in Sea State 4, enabling vehicles to drive across the ramp connection at speeds up to 5 km/h. During the alongside approach the DPS transitions from transit mode to station-keeping mode at a range of approximately 50 to 100 meters from the host vessel, progressively tightening position tolerance as the craft closes.

Electrical power is provided by four AMG 20V 17/21 M95 diesel generators which each provide 3,000 kWe of 50 hz AC power. The AMG 20V 17/21 M96 is a four-stroke V20 fuel-injected turbocharged marine diesel engine with a 17 centimeter bore, 21 centimeter stroke, and 95.4 liter displacement and has a maximum mechanical power output of 3,500 kWm at 1,800 rpm. The 12V 17/19 M70 engine is used to drive a brushless three phase, four pole synchronous AC generator which provides electrical power to the ships zonal DC electrical system. All four 1,500 kWe gensets are contained in two dedicated above waterline machinery rooms. Each generator unit is mounted on a two stage acoustic isolation raft connected to the generator unit with polychloroprene compression isolators with viscoelastic damping inserts. The raft is a titanium framed weldment with concrete ballast fill tuned to a first flexural resonance above 200 Hz to avoid coupling with combustion event excitation. The raft is connected to the ship deck with conical wire rope isolators with embedded constrained layer damping. The two stage compound isolation is designed for attenuation exceeding 50 dB at frequencies above approximately 30 Hz. All ancillary connections including fuel, oil, cooling, exhaust, and electrical cross the isolation raft on dedicated vibration decoupling assemblies including flexible hose loops, bellows, and resilient electrical cable transitions. The AC power from the generators is converted to ±6000 VDC with power conversion modules (PCMs) attached to each generator which then supply both port and starboard DC buses which in turn supply power to six independent zones (one for each watertight compartment) which each include one DC/DC PCM per bus (two each per zone) which converts the ±6000 VDC to 750/800 VDC or 650 VDC to supply DC loads in each zone. Both DC/DC PCMs in each zone also supply one or more DC/AC PCMs with 750-800 VDC which then converts the 750-800 VDC to 450 VAC at 50 Hz and 400 Hz for AC loads. All electrical loads in each zone are connected to both port and starboard bus ensuring continued operation if either port or starboard bus becomes inoperable. The MVDC grid includes two independent lithium iron phosphate (LFP) battery energy storage systems one in each side hull, providing physical separation for survivability. Each BESS is rated at approximately 4 MWh of usable energy storage. The dual BESS provides peak shaving and load levelling for transient high power demands (ramp operation, dynamic positioning, ride control actuators), seamless power bridging during source transitions (diesel-to-GT mode changes), emergency backup power for critical loads (navigation, communications, autonomy systems, fire suppression) for a minimum of 30 minutes if all generators are lost, and energy recovery during regenerative braking of the pumpjets through the AFPM motor/generators. Each BESS enclosure is thermally managed by a glycol heating/cooling loop that maintains cells within the optimal 15 to 35°C temperature window regardless of ambient conditions.


Signature Reduction:
the Orkan class features extensive radar and infrared signature reduction to reduce the ship's detectability to radar and infrared sensors. The hull and superstructure feature a faceted shape with an enclosed mast and sensors suite designed to eliminate corner reflectors and reduce the ship's detectability by radar systems. The composite superstructure of the vessel is fitted with SDI's S-RAM, a type of ballistic grade structural radar absorbing material consisting of 2 cm thick panels made from multiple layers of M5 fibers fibers containing a lossy filler backed by a carbon fiber laminate acting as a reflector. The panels are designed to survive extreme weather exposure and ballistic damage and provides an average -20 dB reflectivity across the 2-40 GHz frequency range (L through Ka bands). The rest of the hull is painted in a radar absorbing paint coating 1 to 5 millimeters thick consisting of lossy dielectric material embedded in a polymer resin which provides -20 dB reflectivity across the 9 -13 GHz range (X band). The infrared signature from the ship's engines is suppressed using an infrared signature suppression system built into the exhaust uptakes. The system consists of a film cooled stainless steel outer duct surrounding a conductively and film cooled stainless steel centerbody and a film cooled stainless steel diffuser which blocks any line of sight view of the heated metal surfaces and reduces uptake metal temperatures to less than 25°C above ambient using ambient air draw into the uptake through a multi-lobed ejector nozzle at the base of the diffuser. The diffuser also contains multiple rings of atomizing nozzles which inject a a fine mist of seawater into the exhaust stream, cooling the exhaust stream to a plume temperature of under 150°C. Seawater injection is controlled by an on board signature management system which interfaces with the ship's propulsion machinery control system and controls the flow of water to the diffuser as a function of engine power.


Passive Protection & Damage Control:
The Orkan class features passive protection in the form of composite armor panels made from M5 ballistic fiber laminated into cured thermoplastic panels which provide ballistic impact and spall protection to the superstructure and vital areas of the ship. he ship's blast hardened bulkheads are designed to deform plastically and maintain watertight integrity in the event of an explosion from a bomb or missile warhead inside the ship and feature double-spaced plate construction with an internal fragment resistant membrane designed to stop fragments from penetrating further into the ship. The automatic opening/closing watertight doors in the bulkheads likewise feature a blast hardened membranes structure design with approximately 10 times the blast force resistance of a conventional watertight door. Damage control is assisted by an SDI Marine Systems developed Automated Ship Control System (ASCS). The ASCS is controlled by a centralized computer which amongst other functions provides real-time damage information to the crew through a graphical display located in the ship's damage control center. Additionally both the ship's bridge and CIC also also fitted with displays connected to the ASCS. The ACSC is designed to run automatically where after the ASCS detects damage to a compartment it will immediately isolate it and activate appropriate damage control measures. Alternatively the ASCS can be set to manual mode where the operator will have to specify the damage control measures after the system detects ship damage. The ASCS also controls and monitors the ship's engines and machinery and will alert engineers on watch duty through their assigned tablet computer when an engineering issue or machinery failure is detected and requires attention. This remove the need for time based maintenance, the system will simply alert the crew when a component or system requires maintenance. Each compartment and each piece of machinery on the ship are monitored using SDI's Two Wire Automatic Remote Sensing Evaluation System (TWARSES) which includes both visible CCD and infrared cameras located in each ship compartment. After damage is detected in a compartment the ASCS can respond in a variety of ways including isolating the damaged compartment by closing the electrically actuated watertight doors around the compartment. If the IR camera detects a fire the system will activate the compartment's overhead sprinklers and can also pump the compartment with aqueous film-forming foam , high velocity fog, and/or carbon dioxide agents if necessary. After the fire is extinguished water and firefighter agents are removed using a bilge draining pump installed in each compartment. The ASCS will also reroute ventilation, electrical power, and water around the damaged area and activate additional pumps, generators and other devices if necessary. If the compartment has been breached and is in danger of flooding the system will flood the compartment with foam which rapidly solidifies and restores reserve buoyancy. This system however is only used as an absolute last resort as it renders the compartment unusable. The ASCS also controls the ship's CBRN protection system by passing air from the ventilation intakes through containment filters before it enters the ship. Air in the ship is maintained at 5.0 millibars above local atmospheric pressure to provide a positive pressure and prevent contaminated air from entering into the ship through a breach in the hull.


Cargo Handling:
The vessel employs a fully enclosed cargo arrangement with hydraulic ramps at both bow and stern contained within the weathertight hull envelope. Total cargo area is 930 m². 68 meters long by 13.5 meters meters wide. Vehicles drive on at one end and off at the other in a single pass with the the stern ramp having an adjustable height (±2 meters) for RO-RO vessel interface and quick release connection system for at-sea vehicle and cargo transfer. The enclosed cargo bay provides complete protection of cargo and personnel from weather, sea spray, and arctic cold during transit. In arctic operations the enclosed bay can be heated to prevent cargo freezing and maintain vehicle readiness during long transits. Both ramps are hydraulically actuated, designed for vehicles up to 80 tonnes. Doors feature wear resistant anti-skid surfaces. Power for the doors is provided by redundant hydraulic cylinders with manual backup. Maximum ramp angle maintains safe traction gradients (less than 1:8). The bow ramp includes an extending lip for beach bridging. The stern ramp interfaces with RO-RO vessel vehicle decks with adjustable height features. Ramp cycle time is less than 90 seconds. For arctic operations the ramp hydraulic systems use low temperature fluid rated to −50°C with electric trace heating on all hydraulic lines and cylinders. Ramp surfaces incorporate embedded heating elements to prevent ice bonding. The enclosed cargo deck provides 820 m²)of clear, reconfigurable area reinforced for 750 tonnes distributed load and 80 tonne concentrated vehicle loads. Recessed tie down fittings are provided on the non-skid, fuel resistant deck coating.
Last edited by The Technocratic Syndicalists on Tue Aug 25, 2026 7:35 pm, edited 5 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Sun Aug 16, 2026 12:38 pm

Image


Njordr Class

Basic Information:
  • Role: Ocean Surveillance Ship
  • Displacement: 8,500 tonnes
  • Complement: 40
  • Length: 110.0 m
  • Beam: 32.0 m
  • Draft: 9.0 m
Propulsion:
  • 4x AMG 16V 26/32 M64 diesel generators, 8,000 kWe each
  • 2x AMG 12V 17/19 M64 diesel generators, 2,000 kWe each
  • 2x AEG main propulsion motors, 10 MW each
  • 2x AEG secondary propulsion motors, 5 MW each
  • 2x shafts, 2x fixed pitch propellers
Performance:
  • Top speed: 25 knots
  • Range: 2,000 km @ 20 knots
    5,500 km @ 10 knots
    17,500 km @ 5 knots
Sensors & Processing Systems:
  • SDI FMG 970 Surface Search & Navigation Radar
  • SDI VTS 900 Variable Depth Low-Frequency Active Towed Sonar

Electronic Warfare & Countermeasures:
  • SRS 300 Electronic Support Measures System
  • 2x SDI SKLS-12 130mm countermeasure launchers


Overview:
The Njordr class is an oceanographic surveillance ship designed by SDI Marine Systems. The Njordr class is equipped with an advanced towed variable depth, low frequency sonar system with both passive and active modes designed to detect and track modern ultraquiet nuclear and diesel electric submarines at extended ranges in all oceanographic environments. Beyond its primary ASW surveillance role the Njordr also supports oceanographic data collection and environmental characterization, underwater acoustic research and technology development, support to Theater ASW Commander operations, calibration of fixed undersea sensor arrays, mine warfare environmental assessment, and support to unmanned undersea vehicle (UUV) operations.


Design & Construction:
The Njordr employs a large SWATH (Small Waterplane Area Twin Hull) catamaran configuration consisting of two fully submerged torpedo-shaped lower hulls connected to an above water cross structure by hydrodynamically faired struts. The geometry minimizes the vessel's waterplane area and thus decouples the vessel from wave-induced motions, producing heave, pitch, and roll responses that are significantly lower than a comparable monohull in the same sea state. The SURTASS towed array sonar requires extremely stable towing conditions to maintain optimal acoustic performance. Excessive ship motion induces array depth excursions, flow noise from cable strumming, and bearing errors that degrade detection range. The SWATH form provides a stable acoustic platform that maintains near-optimal array geometry even in high sea states where monohull vessels would be forced to stop operations. The primary structure including the twin pontoons, connecting struts, and the lower cross structure is made from high-strength low alloy (HSLA) steel. The upper superstructure and deckhouse are constructed from 5083-H321 marine grade aluminum alloy to reduce topside weight, lower the vessel's vertical center of gravity. and improve intact and damaged stability margins. The aluminum superstructure is joined to the steel cross structure via bimetallic transition joints (explosion bonded steel-aluminum strips) to prevent galvanic corrosion at the dissimilar metal interface. The hull structural design incorporates enhanced scantlings in way of the ice belt region along the pontoon waterline from 1.0 m below to 0.5 m above the light load waterline. Ice-strengthened frames are spaced at 400 mm in the bow region and 600 mm amidships, with shell plating thickness increased to 25 mm in the ice belt. The bow sections of both pontoons feature ice knife profiles with 30° waterline entrance angles and hardened steel wear plates.The hull structure makes extensive use of Laser welded Corrugated-core Steel (LASCOR) panel technology. LASCOR panels are steel sandwich panels consisting of two flat face sheets joined to a corrugated steel core by continuous high-speed laser welding. The corrugated core serves as the structural web between the face sheets, creating a lightweight high stiffness panel that replaces conventional stiffened plate construction. The LASCOR manufacturing process uses high power fiber laser welding to join the corrugated core to the face sheets in a continuous, automated production line. The laser weld is extremely narrow with very low heat input compared to conventional arc welding, resulting in minimal heat-affected zone (HAZ) distortion, near zero residual stress in the finished panel, superior fatigue performance due to the absence of weld-toe stress concentrations, and dramatically reduced post-weld straightening and fairing work. Panels are produced in widths up to 3.0 meters and lengths up to 16 meters. A critical advantage of LASCOR panels is their superior vibro-acoustic performance compared to conventional stiffened plate construction. The continuous corrugated core acts as a distributed vibration isolation medium that impedes the transmission of structural borne noise through the hull. The corrugated core creates a tortuous transmission path for bending waves propagating through the panel as acoustic energy traveling through the structure must repeatedly change direction at each corrugation fold, and at each fold a portion of the energy is reflected and dissipated. This results in significantly higher transmission loss than a simple flat plate of equivalent mass. The double skin sandwich construction also provides an inherent mass-spring-mass vibration isolation characteristic, the two face sheets act as masses separated by the compliant corrugated (spring) core, creating a mechanical low pass filter that attenuates vibration transmission at frequencies above the panel's coincidence frequency. The external underwater hull surfaces receive an additional multilayer acoustic and hydrodynamic coating system. The base coat is a high build marine epoxy primer providing corrosion protection. Over this is applied a viscoelastic constrained layer damping treatment on all flat and gently curved hull panels consisting of a viscoelastic polymer layer bonded to a steel constraining layer. The outer coat is a silicone-based foul-release coating that minimizes hull roughness and biological fouling. The internal surfaces of the pontoons and struts in way of machinery spaces receive spray-applied viscoelastic damping compound to reduce hull shell resonance radiation.

The vessel employs an active ride control system consisting of four movable canard fins (two per strut, forward) and two stern flaps (one per pontoon, aft). These control surfaces are driven by electrohydraulic actuators by a centralized motion control computer receiving real time data from inertial measurement units (IMUs), wave height radar, and accelerometers distributed throughout the hull. The system provides active heave, pitch, and roll stabilization, further reducing residual motions by 30 to 40% beyond the passive SWATH advantage. A critical design driver for the hull is minimizing hydrodynamic flow noise. The hull form incorporates several specific flow noise countermeasures. All strut-to-pontoon and strut-to-cross-structure fillets use large-radius fairings to prevent flow separation and vortex shedding. Strut leading and trailing edges are designed with laminar flow profile optimized for the operational speed range of 3 to 8 knots during towing. All hull penetrations, sea chests, and overboard discharge ports below the waterline are flush mounted with retractable closures to eliminate flow generated turbulence. The pontoon stern sections incorporate tapered runouts with half-angles not exceeding 12° to minimize wake turbulence at the propeller inflow plane. The LASCOR panel surface finish provides a smoother hydrodynamic surface than conventional stiffened plate construction, where welded stiffener toes and frame flanges create surface discontinuities that trip turbulent boundary layer transition.


Propulsion
The Njordr employs an Integrated Electric Propulsion (IEP) architecture where all onboard power for propulsion, ship service, and mission systems is generated by a set of diesel generator sets and distributed through a Medium Voltage Direct Current (MVDC) electrical bus. The architecture provides maximum flexibility in power allocation between propulsion and ship service loads, eliminates mechanical reduction gearboxes and their associated noise and vibration, enables the prime movers (diesel engines) to be located in acoustically optimized compartments fully decoupled from the hull structure, and permits operation of the diesel generator sets at optimum fuel efficiency regardless of propulsion speed. The power generation plant consists of six diesel generator sets physically and acoustically isolated from each other for redundancy and survivability. Each diesel generator set is enclosed within a modular, lightweight composite acoustic enclosure providing a minimum of 35 dB airborne noise attenuation. These enclosures are a significant advancement over traditional steel enclosures, offering superior noise attenuation with dramatically lower weight. The enclosure panels are constructed as multi-layer composite sandwich consisting of an outer skin of glass-fiber reinforced polymer providing structural rigidity, a constrained-layer viscoelastic damping treatment bonded to the outer skin, a core layer of open-cell melamine acoustic foam with embedded mass-loaded vinyl (MLV) barrier, an air gap maintained by standoff clips, an inner skin of perforated GFRP backed by acoustic absorption fabric, and an inner face of fire-resistant ceramic fiber blanket. The composite construction reduces enclosure weight by approximately 60% compared to equivalent steel enclosures while providing 8–12 dB greater airborne noise insertion loss. Each enclosure is equipped with acoustically attenuated ventilation openings, vibration-isolated access doors, and fire detection/suppression interfaces. The T-AGOS(X) incorporates a comprehensive multi-stage exhaust silencing system for each diesel generator set, designed to achieve a minimum of 50 dB insertion loss at the exhaust outlet relative to the unsilenced engine exhaust noise level. The silencer system for each engine consists of three stages arranged in series within the exhaust gas path. The first stage is a reactive silencer that that passes the exhaust gas through a series of four chambers of alternating large and small cross section, causing acoustic reflections at each area change that cancel the pulsating pressure waves generated by the engine's cylinder firing. The chambers are tuned to target the engine's fundamental firing frequency and its first three harmonics. The second stage absorptive silencer uses parallel perforated stainless steel baffles filled with high temperature basalt wool acoustic absorption material which attenuates the broadband noise components that pass through the reactive stages. The third stage reactive silencer consists of an array of tuned quarter wave resonator side branches welded to the exhaust pipe each tuned to a specific firing-order harmonic to provide additional narrowband attenuation at these dominant tonal frequencies.Each generator set produces 6,600 VAC output which is rectified to 6,000 VDC by active front-end (AFE) rectifiers located adjacent to each generator. The AFE rectifiers use insulated gate bipolar transistor (IGBT) technology to provide clean, low harmonic DC output while simultaneously performing power factor correction and enabling regenerative braking energy recovery from the propulsion motors during deceleration. The T-AGOS(X) employs a Medium-Voltage Direct Current (MVDC) zonal electrical distribution system—a next-generation power architecture that replaces traditional AC switchboard-based distribution with a DC bus backbone and distributed power conversion. The MVDC architecture eliminates the need to synchronize AC generators, simplifying power management, enables variable speed operation of all diesel generator sets for optimized fuel efficiency and reduced noise at partial loads, provides inherently superior power quality to sensitive sonar electronics (no AC frequency/phase issues), enables seamless integration of energy storage systems, and significantly reduces the weight and volume of electrical distribution equipment. The vessel is divided into eight electrical zones, each served by redundant MVDC bus feeds from the main bus through zone level power conversion modules (PCMs). Each zone contains local power conversion modules that convert the 6,000 VDC main bus to the required local voltages including 1,000 VDC for propulsion motor drives, 450 VAC (3-phase, 60 Hz) for ship service loads via DC-to-AC inverters, 120 VAC (single-phase, 60 Hz) for lighting and convenience outlets, and 24/48 VDC for electronics and control systems. The zonal architecture provides inherent redundancy as any single zone can lose its primary bus feed and be back fed from adjacent zones through bus-tie switches. The MVDC bus itself is arranged in a ring topology with sectionalizing switches ensuring that no single cable fault can deenergize more than one zone. The MVDC architecture integrates a ship-wide battery energy storage system (BESS) consisting of two lithium iron phosphate (LiFePO4) battery banks distributed across two zones providing a total of 2,400 kWh of stored energy. The BESS provides ride-through power during generator set start/stop transients and load transfers, enables ultra-quiet all-electric operation for short periods (up to 4 hours at 3 knots) with all diesel generators secured for minimum self-noise during critical acoustic detection windows, absorbs transient loads from the CLFA active sonar transmitter without requiring additional generators online, and provides emergency backup power for essential systems. Each engine room contains a self-supporting raft structure fabricated from heavy steel plate and box section beams with a total raft mass of approximately 45 tonnes per engine room. All machinery within the engine room including the two main diesel generator sets, one auxiliary generator set, associated cooling pumps, lube oil systems, and fuel transfer equipment are rigidly bolted to the raft which is supported on the hull structure through two stages of isolation. Primary raft-to-hull mounts consists of 24 × pneumatic air-spring isolators per raft with a natural frequency of 3 to 4 Hz, tuned below lowest excitation. Secondary machine-to-raft mounts consists of metallic wire-rope or elastomeric mounts per machine with a natural frequency of 8–12 Hz. The pneumatic airspring primary mounts provide extremely low natural frequency (3–4 Hz) which ensures that isolation effectiveness begins at very low frequencies, critical for the SURTASS operating band that extends down to 1 Hz. The air springs are height-regulated through an automatic leveling system that maintains constant raft height regardless of machinery operating condition or fuel/water load changes. Each air spring incorporates an integral viscous damper to prevent excessive raft displacement during transient loads or seaway-induced accelerations.

The propulsion system employs four ultra quiet axial flux permanent magnet (AFPM) electric motors arranged in two tandem pairs. Each tandem pair consists of one primary motor rated at 10 MW and one secondary motor rated at 5 MW mounted inline on a common shaft within each pontoon. The two motors in each pair are coupled to each other and to the propeller shaft through torsionally compliant elastic couplings that provide mechanical isolation between the motor rotors and the shaft/propeller assembly. Each motor is a dual-rotor, single-stator (DRSS) axial flux employing N48SH NdFeB permanent magnets. The 10 MW motors have a diameter of 3.2 meters and a mass of 12,500 kg while the smaller 5 MW motors have a diameter of 2.4 meters and a mass of 7,200 kg. Speed range for both motors is 0 to 180 RPM. The axial-flux permanent magnet motors achieve a significantly higher torque density than radial-flux machines of equivalent power rating, enabling the motor to fit within the constrained diameter of the SWATH pontoon while delivering the required torque at low RPM for direct-drive propeller operation without a gearbox. AFPM motors have no rotor windings or brushes as the rotor consists solely of a steel disc with surface-mounted permanent magnets, eliminating a major source of electrical noise, brush friction, and maintenance burden. The dual rotor, single stator (DRSS) configuration used on the T-AGOS(X) motors achieves efficiencies exceeding 97% across the operating speed range, reducing heat rejection and improving the thermal signature and fuel efficiency of the vessel. The AFPM motors also produce extremely low levels of vibration and electromagnetic noise compared to radial flux machines as the symmetric magnetic forces in the DRSS configuration cancel axial thrust loads and radial unbalanced magnetic pull forces, eliminating the primary vibration excitation mechanisms in conventional electric motors. The elastic couplings between the motors and between the motor pair and the shaft incorporate selectable engagement/disengagement clutch elements enabling the non-operating motor in each pair to be mechanically disconnected from the shaft. This eliminates windage and bearing drag from the d-energized motor and prevents it from acting as a vibration transmission path or parasitic noise source. During towing operations only the 5 MW motors operate at partial load, minimizing the number of active electromagnetic noise sources and ensuring that motor generated vibration is at its absolute minimum during the acoustically critical surveillance mission phase. Each motor-to-motor and motor-to-shaft connection employs a high-performance torsionally compliant elastic coupling designed to provide both torsional vibration isolation and misalignment compensation. The coupling consists of a series of pre-loaded elastomeric elements arranged in a radial pattern between the driving and driven flange providing torsional compliance that isolates propeller excited torsional vibration from the motor rotors, axial compliance to accommodate thermal growth of the shaft system, angular and radial misalignment tolerance of ±0.5 degrees and ±2 mm respectively, and a torsional vibration insertion loss of >15 dB at blade-pass frequency. The coupling elements are designed to be replaceable in-situ without removing the motor or propeller, and have a design life of 20,000 operating hours before scheduled replacement. Each propeller is an 3.8 meter diameter, five bladed ultra low noise skewback propeller with a 52° skew angle and 15° aft rake, constructed from CU3 nickel-aluminum bronze (NAB) with a HVOF cermet anti fouling plus vibration damping polymer blade coating. The propeller design is derived from submarine propulsor technology, adapted for the surface ship application. The five blade count is selected to avoid coincidence between blade pass frequency harmonics and the natural frequencies of the pontoon stern structure which would amplify hull radiated noise. The extreme skew angle of distributes each blade's interaction with the non-uniform wake over a longer chore wise and circumferential extent, reducing the amplitude of unsteady blade forces compared to a conventional low skew design. The progressive 15° aft rake shifts the blade loading toward the tip, reducing root section loading and further suppressing hub vortex formation. Blade sections use cusped anti-singing trailing edges that prevent trailing-edge vortex shedding resonance at all operating speeds. Each propeller is further equipped with an integrated Hub Vortex Diffuser (HVD) attached to the propeller hub that eliminates the hub vortex that forms downstream of conventional propeller hubs. The HVD is a 650 mm long conical diffuser with a 12° included half-angle, fabricated from the same NAB alloy as the propeller and cast integrally with the hub cap. The combined acoustic benefit of the extreme skew blade geometry, anti singing trailing edges, mirror polished blade finish, and HVD produces a propeller that achieves a cavitation inception speed (CIS) exceeding 20 knots at the design draft, well above the maximum towing speed and ensuring cavitation free operation throughout the entire surveillance mission envelope.


Sensors & Processing Systems:
The primary mission payload is an SDI VTS 900 Variable Depth Low-Frequency Active Towed Sonar, an advanced long range all weather sonar surveillance system integrating passive and active acoustic sensor components optimized for detecting and tracking modern ultra-quiet submarines at operationally significant ranges. The system is designed to operate in deep water, shallow littoral waters, and under-ice environments, providing comprehensive coverage across the full spectrum of submarine threat platforms. The system incorporates high-sensitivity vector-sensor hydrophones in the towed array and an advanced AI/ML-powered signal processing system that provides enhanced autonomous detection and classification capability. The passive element is a twin-line variable depth towed array consisting of two 2,600 meter length passive towed arrays incorporating 960 hydrophone modules per line. Operating frequency is 1–2,000 Hz. Operating depth is variable from 150 to 500 meters. Line separation is ~100 meters, controlled by depressor/spreader vanes one each line. Both lines are connected to the ship with a Kevlar-reinforced fiber optic tow cable 50 mm in diameter connected to a stern mounted traction winch on the ship with a 60 tonne capacity. Deploy time is under 4 hours while recovering time is under 3 hours. The hydrophone modules employ multi-axis acoustic vector sensor (AVS) hydrophones that contains a conventional pressure-sensitive PZT-5H piezoelectric ceramic element combined with three orthogonal geophone-type particle velocity sensors that independently measure the acoustic particle velocity in the x, y, and z axes that provide a complete characterization of the acoustic field at each sensor location. A single AVS element inherently resolves the 180 degree bearing ambiguity that effects conventional single line towed arrays as the directional particle velocity components distinguish between sound arriving from port versus starboard. While the twin-line geometry already provides left-right resolution through inter-line phase comparison the AVS elements provide independent per-element ambiguity resolution that enhances robustness and enables continued unambiguous operation even if one of the twin lines is partially damaged or fouled. The AVS elements also achieve a higher signal-to-noise ratio than pressure-only sensors for spatially correlated signals in the presence of isotropic ambient noise. The tri-axial velocity measurement enables three-dimensional beamforming and bearing estimation from a single line of sensors, providing inherent elevation angle measurement capability that is not possible with pressure only arrays. This allows the system to determine the depth layer of a detected contact, critical for classification and for resolving surface duct versus convergence zone propagation paths. The towed array is deployed and recovered through a dedicated stern handling system located on the main deck at the vessel's transom. The system consists of a high-capacity traction winch , a storage drum system with capacity for the full 3,200-meter tow cable and twin line array assembly, roller fairleads and guide sheaves to manage cable routing, overboard deployment chutes with integrated cable tension monitoring, and a hydraulic array straightener to prevent kinks during deployment. The entire stern handling area is enclosed within a weatherproof hangar with roll-up doors to protect personnel and equipment during operations in heavy weather. The winch drive system uses a permanent-magnet electric motor with a low-noise planetary gear reducer, and the entire winch assembly is resiliently mounted to prevent winch generated vibration from coupling into the hull during array towing operations.The active element is a suspended vertical line array (VLA) with 18 source projectors with a 30 meter deployed length that operates at a variable, depth from 50 to 300 meters. Thevertical line array consists of 18 flextensional acoustic projectors arranged vertically and suspended below the vessel from a dedicated handling system on the starboard side. Each projector is a Class IV flextensional transducer capable of producing high-intensity, low frequency acoustic energy across the 100 to 500 Hz band. The projectors are individually driven by dedicated power amplifiers, enabling electronic beam steering of the transmitted acoustic beam in the vertical plane to optimize ensonification of the target depth layer based on oceanographic conditions. The active system operates in close coordination with the passive array, the CLFA transmits a controlled acoustic pulse, and the passive array listens for echo returns from targets in the water column. The system processor correlates transmitted and received signals using matched-filter and adaptive beamforming techniques to extract target echoes from ambient noise and reverberation. The bistatic geometry with source and receiver separated by the tow cable length provides enhanced target discrimination compared to monostatic systems. The vertical line array is deployed through a dedicated handling system on the starboard side of the vessel separate from the stern mounted towed array system. The CLFA handling system includes a hydraulic A-frame crane. a winch with 400 meters of armored electro-mechanical cable, a source array cradle with shock-absorbing tie-downs, and a power cable management system with slip rings. The separation of CLFA and towed array handling systems enables independent deployment and recovery of each system.

The sonar processing system is built around a scalable open-architecture computing infrastructure designated the Advanced Signal Processing System (ASPS). The ASPS provides rea -time processing of acoustic data from both the passive array and the active CLFA system. The ASPS incorporates a comprehensive suite of artificial intelligence and machine learning (AI/ML) algorithms designated the Acoustic Intelligence Engine (AIE) that operates as a parallel processing layer alongside the conventional signal processing chain, providing independent detection and classification outputs that are fused with conventional algorithm outputs to maximize overall system performance. The primary AI detection algorithm is a deep convolutional neural network (CNN) trained on archived acoustic data comprising millions of hours of ocean surveillance recordings. The CNN operates on spectrogram representations of beamformed acoustic data and is trained to detect the subtle, often sub-threshold spectral signatures of modern ultra-quiet submarines that fall below the detection threshold of conventional energy-based and matched-filter detectors. The DNN detector achieves a probability of detection (Pd) of 0.92 at a false alarm rate (Pfar) of 10⁻⁴ against representative quiet submarine signatures in typical oceanic noise conditions, an improvement of approximately 8–12 dB in effective processing gain over the best conventional CFAR (Constant False Alarm Rate) detection algorithms. Detected contacts are automatically classified by a multi-stage classification pipeline. The first stage uses a deep residual network trained on labeled acoustic signature libraries to classify contacts into broad categories including submarine (nuclear), submarine (diesel/AIP), surface combatant, merchant vessel, biological, and environmental. The second stage applies a specialized fine-grained classifier that attempts to identify the specific submarine class and, where sufficient signature data exists, individual hull identification. The classifier exploits DEMON (Detection of Envelope Modulation on Noise) analysis, narrowband tonal characteristics (blade-rate, machinery, and propulsion harmonics), and broadband spectral shape features. Classification confidence scores are provided to the operator, with contacts exceeding the confidence threshold automatically promoted to the track file. The AIE employs a transformer-architecture neural network for multi-contact track management and fusion. This network processes time-series sequences of bearing, frequency, and amplitude measurements from multiple simultaneous contacts and learns the temporal evolution patterns of submarine tracks (Doppler shifts, maneuver patterns, snorkeling cycles for diesel submarines, depth-layer transitions). The transformer's attention mechanism enables it to maintain context over long track histories (up to 72 hours of continuous contact data), improving track continuity through periods of intermittent detection—a common challenge with ultra-quiet targets that fade in and out of detectability as oceanographic conditions fluctuate. An AI based sensor management agent, trained through reinforcement learning on simulated ocean surveillance scenarios, continuously optimizes the SURTASS-LFA system's operating parameters in real-time. This agent adjusts array tow depth based on sound velocity profile analysis to maximize detection in the prevailing acoustic propagation conditions, selects the optimal CLFA active waveform (frequency, bandwidth, pulse duration, coding) for the current target and environment, schedules active transmission intervals to maximize detection probability while respecting marine mammal mitigation duty-cycle constraints, recommends ship course and speed adjustments to optimize array beampattern orientation relative to threat axes, and dynamically allocates processing resources between passive broadband, passive narrowband, and active echo processing based on the current tactical situation. The AIE is designed with a continual learning architecture that enables model updates in the field. New acoustic signature data collected during operations is automatically archived and can be used to retrain and update the detection and classification models via secure, encrypted model update packages transmitted from shore-based IUSS processing centers. This ensures that the AI/ML system continuously improves as new submarine signatures are collected and characterized, maintaining effectiveness against evolving threats. All model updates are cryptographically signed and validated before deployment.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

User avatar
The Technocratic Syndicalists
Minister
 
Posts: 2347
Founded: May 27, 2015
Inoffensive Centrist Democracy

Postby The Technocratic Syndicalists » Tue Aug 18, 2026 6:53 pm

Image

Borealis Class

Basic Information:
  • Role: Arctic Cargo Hovercraft
  • Mass: 1,000 t
  • Payload 300 t
  • Complement: 20 + 24
  • Length: 65 m
  • Beam: 20.0 m
  • Height 24.0 m
Propulsion:
  • 8x SDI SDI GT1500 gas turbine propulsion engines, 15 MW each
  • 4x Variable geometry lift fans
  • 4x Ducted propulsors

Performance:
  • Top Speed (smooth ice): 120 knots
  • Top Speed (water, SS3): 90 knots
  • Range:
      300 t payload: 1,200 km @ 90 knots, 1,000 km @ 120 knots
      100 t payload: 4,800 km @ 90 knots, 4,000 km @ 120 knots
  • Ferry range: 6,500 km @ 90 knots
  • Endurance: 60 days supplies
Sensors & Processing Systems:
  • SDI FMG 960 S band Surface Search & Navigation Radar
  • SDI FMG 970 X band Surface Search & Navigation Radar
  • SDI FMG 990 W band Ice Detection Radar


Overview:
The Borealis class is a class of large air cushion arctic hovercraft transport designed by SDI Marine Systems. The Borealis has a fully loaded mass of 1,000 tonnes and can transport up to 300 tonnes of cargo including military vehicles and containerized cargo over Arctic terrain at speeds up to 120 knots.


Design & Construction:
The Borealis class vehicles have a length of 65.0 meters, beam of 30.0 meters, and a height of 20.0 meters from the keep to the aft rudder fin tips. Mass fully loaded is 1,000 tonnes. The primary structure is a buoyancy raft consisting of a flat bottomed box girder measuring 60.0 m long by 28.0 m wide and 6.0 meters in height. The raft forms the hull, the cushion pressure boundary, the vehicle deck, and the reserve buoyancy volume in a single assembly. Longitudinal strength is carried by two heavy outboard side girders which also form the skirt attachment backbone, by two inboard girders at the vehicle deck edges which carry the deck loads into the side casings, and by two longitudinal bulkheads that separate the vehicle deck from the fuel tanks. Transverse frames are spaced at 1.5 meters, closing to 0.75 meters beneath the vehicle deck lanes and at the ramp reaction points. Watertight subdivision comprises 24 compartments and the vehicle survives flooding of any two adjacent compartments. Above the hull box girder the vehicle deck takes up the center 13.5 meters of the vessel and runs the full length of the hull. A ramp closes each end of the vehicle deck and serves as the watertight door for that end. Two two side casings, each 7.25 meters wide, run along each side of the vehicle deck for its full length and contain all machinery and crew accommodation spaces. Each side casing is divided longitudinally into five sections. At the forward end of each side casing the forward crew zone flanks the bow ramp and forward vestibule. The forward propulsion module is located behind the forward crew zone and contains the the forward lift fan, the forward gas turbine pair, and the forward main reduction gearbox. The midships crew zone extends lies between the two propulsion modules. Integral fuel tanks are placed in the the lower side zone. The aft propulsion module is behind the midships crew zone, and the aft service zone flanks the stern ramp.

The hull primary structure is constructed almost entirely of Ti-5111 (Ti-5Al-1Sn-1Zr-1V-0.8Mo) titanium alloy providing high specific yield strength, complete immunity to seawater galvanic corrosion, no magnetic signature, excellent fatigue performance, and adequate weldability with proven marine fabrication procedures. Ti-5111 is used for the cargo deck and bottom plating, all longitudinal and transverse bulkheads, the flotation tank shell and ice belt, the reactor trunk, the bow and side ramp primary structures with their hinges and locks, the resting pad legs and load paths. Titanium fiber metal laminate is used in select zones for its improved fatigue crack growth resistance and impact resistance. The laminate consists of alternating foils of Ti-15-3 titanium alloy and unidirectional carbon fiber polymer prepreg consolidated into panels of 5 to 15 mm thickness. Fatigue cracks that initiate in a titanium foil layer are arrested by fiber bridging in the adjacent composite layer which reduces crack growth rates by one to two orders of magnitude compared with monolithic titanium at the same stress range. The outer facesheets of the bottom plating use 8 millimeter laminate over the forward 20 meters of the raft where high speed ridge contact produces the most severe impact loading. The vehicle deck plating uses 10 millimeter laminate throughout which resists track shoe indentation from heavy tracked military and construction vehicles. The regions surrounding the bow and stern ramp openings use 15 mm laminate as crack arrest structure at the corners of the largest cutouts in the hull. The skirt attachment backbone uses 10 mm laminate om the attachment rail where cyclic skirt loads at cruise speed produce a high cycle spectrum. Crack arrest straps of 15 mm laminate are bonded and fastened into the outboard side girders at 5 meter intervals along the full length of the raft. The bottom of the hull consists of three layers. The structural layer is a titanium sandwich panel with a 120 millimeter titanium honeycomb core, a 6 millimeter lower facesheet, and a 4 millimeter upper facesheet. Over the forward 20 meters and on all landing pads the lower facesheet is replaced by a 10 millimeter titanium fiber-metal laminate. The ablative layer is 15 millimeter ultra-high-molecular-weight polyethylene sheet in mechanically fastened 2 by 2 meter panels which provides low friction against ice and absorbs minor rubble impact. The skid layer comprises four full length landing skids and six discrete landing pads. Landing skid shoes are AR500 abrasion resistant steel bolted to titanium backup structure and are treated as consumables. The ablative layer applied to the bottom plating between the skids is ultra-high-molecular-weight polyethylene (UHMWPE, UHMW) isheet in replaceable panels. Landing pad crush cores and the peripheral collision protection structure use rigid closed-cell syntactic foam. Cargo tie down inserts and ramp toe structure use 15-5PH precipitation-hardening stainless steel. The structure above the hull including the majority of the superstructure is fabricated from carbon fiber reinforced epoxy using a toughened resin system qualified for continuous service at −60 °C. CFRP composites are used for the superstructure, the pilothouse, the accommodation modules, and throughout the lift and propulsion systems including the lift fan impellers and casings, the fan and propulsor ducting, the propulsor blades, the drive shafts, and the pylon fairings. Composite attachment to the titanium hull is by bonded and bolted titanium fittings without isolation plies.

The peripheral seal is a bag and finger type skirt with a total height of 6.0 meters. The skirt consists of pressurized peripheral bag 2.4 meters high fed from the cushion plenum through valved ports and 3.6 meter high fingers attached to the bag underside. Fingers constitute 60% of the total skirt height which establishes the full speed obstacle crossing limit. The cushion is divided into four quadrants by a longitudinal keel skirt on the centerline and a midship transverse stability skirt providing pitch and roll stiffness, limiting the cushion volume lost to a single quadrant breach to 25%, and giving the ride control system four independently controllable cushion pressure zones. The bag is a hybrid aramid and ultra-high-molecular-weight polyethylene woven cloth of 2,200 g/m² coated on both faces with a polyurethane elastomer that remains flexible to −60 °C. Fingers use the same base cloth material with a polyethylene reinforced wear face on the ground contact surface. Finger tips are replaceable wear caps of polyethylene and polyurethane, mechanically attached to the skirt. All attachment hardware is titanium and all external skirt surfaces carry an icephobic fluoropolymer topcoat. Finger service life over pack ice is 250 operating hours. The vehicle carries 30 spare fingers and one spare bag section within its 60 day outfit. All skirt attachment hardware lies inboard of the hull outer surface. Bag rails, finger loops, tensioners, and inflation ports are accessible from heated longitudinal galleries that run the full length of both side casings and across the bow and stern within the raft structure. A finger is changed from inside the vehicle through a gasketed access hatch, removing all skirt maintenance from the external environment and permits skirt repair while the vehicle is on cushion at low speed. Resistive heating tapes bonded to the titanium attachment rails and to the upper bag attachment seam hold the attachment hardware above −5 °C whenever the vehicle is on cushion or on heated standby. Water ingested during over water transit would otherwise freeze within the attachment hardware, lock the skirt rigid, and cause the skirt to tear out at the next ridge contact. Following any overwater operation a purge sequence drives cushion air through the bag and finger drains at high flow while the vehicle hovers which expels free water before setdown. Each finger carries two 25 millimetre drains at its lowest point fitted with non-return flaps. Four hydraulic skirt shift actuators, one per quadrant, provide 0.5 meters of longitudinal and transverse skirt displacement. The actuators are used for static trim, for compensation of asymmetric ice accretion, and for trim optimization at speed. The bag is divided into 16 independently fed sections, so a breach of any one section is contained without depressurizing the bag. Fingers are individually attached, and the loss of up to 12 consecutive fingers can be tolerated at reduced speed.


Propulsion:
The vehicle uses a COGAG type propulsion system with eight SDI GT1500 gas turbine engines contained in four identical power modules, each power module consisting of two GT1500 turbines driving a main reduction gearbox through synchro-self-shifting clutches with each gearbox in turn driving one centrifugal lift fan and one ducted propulsor. Each GT1500 engine is a three-spool aeroderivative with a free power turbine, rated at 15.0 MW continuous at ISO conditions and 17.5 MW continuous at −30 °C ambient. With all eight engines engaged the vehicle can reach a maximum speed of 120 knots over smooth ice with excess power for sustained ice ridge avoidance maneuvering. In cruise mode one engine in each power unit is declutched and shut down while the remaining engine in each unit runs at between 60% and 85% load, allowing the vehicle to cruise efficiently at speeds up to 90 knots. The synchro self shifting clutches on each input driveshaft engage automatically on speed match and require no action beyond mode selection. A shut down engine can be restarted from its own starter generator and reengaged to the gearbox within 90 seconds with no interruption of power to the fan or the propulsor. Declutched engines are held with their power turbines stationary and their gas paths purged with warm dry air which prevents cold soak and internal ice formation. The engine inlets are located at 12 meters above baseline on the superstructure top deck, positioning them above the cushion generated snow cloud. Each inlet is a four stage system. The first stage is an inlet lip and splitter heated electrothermally to +8 °C with hot bleed air which prevents ice formation and prevents shed ice from entering the core. The second stage is an inertial particle separator with a powered scavenge blower discharging overboard aft which removes 90% of particles larger than 20 micrometers covering snow, ice crystals, sand, and gravel. The third stage is a multi stage coalescing vane salt separator with heated drains, which removes 95% of salt aerosol and all free water. The fourth stage is a barrier filter with an automatic differential pressure bypass door which provides fine filtration and prevents a blocked filter from causing a flameout. A compressor water wash system with heated demineralized water is plumbed to all eight engines. Exhaust is routed upward and aft through infrared suppressing uptakes containing a two stage film cooled ejector/suppressor. A heat recovery loop extracts up to 0.5 MWth per engine that serves cabin and cargo deck heating, fuel tank and line heating, ramp d-icing, skirt rail heating, hydraulic fluid heating, and the water plant. The loop is the primary heat source for the vehicle and reduces the auxiliary power load on station.

Four main reduction gearboxes are installed in the vehicle, one per power modules. Each accepts two inputs at 7,000 rpm through synchro-self-shifting clutches and torsional dampers. The lift fan output is a vertical shaft at 1,200 rpm rated at 10 MW. The propulsor output is an inclined pylon shaft at 650 rpm rated to 25 MW. Reduction is in two stages with a combined bevel and helical stage followed by an epicyclic stage to each output. Each gearbox is rated at 30 MW continuous and 35 MW for 30 minutes. Housings are cast and fabricated titanium with steel bearing inserts. Lubrication is by two independent pressure systems using synthetic ester oil serviceable to −60 ° with electric preheat and 30 minutes of dry run capability. Monitoring covers full-authority vibration measurement, chip detection with inline debris analysis, oil debris monitoring, and torque metering on all four shafts.The split of power between fan and propulsor is set by the fan variable geometry and the propulsor blade pitch which together determine the torque demanded at each output. Electric sump heaters and heated scavenge lines are fitted, and an automated warm-up schedule motors each gearbox at 300 rpm on a starter generator until oil temperature exceeds −20 °C. The vehicle management system inhibits full power until oil temperature exceeds +10 °C. The vertical fan drive shafts and the vertical pylon drive shafts are filament wound carbon fiber reinforced composite tubes with bonded and pinned titanium end fittings. Each ducted propulsor has a propeller diameter of 6.00 meters and a duct chord of 3.20 meters. Each propeller has six blades and runs at a design 650 rpm. Each propulsor absorbs up to 25 MW, produces 160 kN of thrust at 120 knots and 385 kN static can swivel ±35° on either side of the centerline at 15°/s and has a blade pitch range from −20° to +55° degrees with full reverse capability. Propeller blades are carbon fiber composite with titanium leading edge sheaths and electrothermal deicing mats bonded into the leading edges. The ducts are composite sandwich construction with titanium leading edges and attachment structure Ducted units are used for their low speed thrust, for the lateral force they generate when swiveled, and for their lower radiated noise relative to free propellers of equivalent thrust. Each propulsor and its duct rotate through the pylon on a titanium three row roller slew bearing. Two independent hydraulic rotary actuators, one on each hydraulic system, drive the swivel. The bearing and its seals are heated and purged with warm dry air. Blade deicing operates in four spanwise zones per blade at 25 kW per blade set sequenced through a slip ring so that ice shed from any one zone cannot produce rotor imbalance beyond design stability limits. Duct inner lips and stator vanes are also heated using the same system.

Air skirt inflation is provided by four variable geometry centrifugal lift fans, one per power modulr. Each fan is a double entry mixed flow centrifugal fan driven through a vertical composite shaft from the power module main reduction gearbox. Each fan has an impeller diameter of 4.25 meters, delivers 300 m³/s at a design pressure rise of 7.9 kPa and runs at 1,200 rpm with a design tip speed of 175 m/s. Total cushion flow is 1,200 m³/s and total lift power 12.0 MW. The impellers are carbon fiber reinforced polymer with titanium leading edge sheaths and titanium hubs. The fan casings and the diffuser ducting are CRFP honeycomb sandwich construction. The composite impellers reduce rotating mass by approximately 40% compared with metallic impellers which lowers the fan polar moment of inertia and raises the achievable bandwidth of the variable geometry system. Each fan carries two independent variable geometry controls. Variable inlet guide vanes provide ±40° of preswirl, driven by a duplex hydraulic ring actuator with electromechanical backup at a bandwidth of 3 Hz. Variable pitch impeller blades provide ±12° of pitch change about the design setting driven through a hydraulic pitch change actuator mechanism in the fan hub at a bandwidth of 2 Hz. Flow is variable between 40 and 110% of the nominal value. Over smooth first year ice at high speed the fans run at low flow with a steep pressure-flow slope which minimizes momentum drag. Over multi year ice and rubble the fans run at high flow with a flat slope which holds cushion pressure through the large transient leakage that occurs as the skirt conforms to the surface. Over open water in Sea State 3 the fans run at high flow with a moderate slope for cushion retention and reinflation through wave contact. During a ridge crossing the system commands a momentary flow surge with increased blade pitch, which maintains the cushion through the transient loss of seal. During hover and cargo operations the fans run at 40% flow which suppresses the self generated snow cloud that would otherwise obscure the vehicle sensors and the vehicles using the ramps. Lift air enters through inlets on the superstructure sides at 12 meters above baseline which places them above the recirculating snow and spray cloud generated by the cushion. Each inlet carries a coarse debris screen heated to +5 °C, an inertial snow separator consisting of a 90° duct turn with a bleed slot that dumps the heavy fraction overboard, and a heated drain sump. The separator removes approximately 85% of ingested snow mass. Fan discharge feeds the peripheral bag and the cushion through a manifold containing the four quadrant vent valves.

The vehicle has two electrical networks (E1 and E2) each operating at ±270 VDC. Each of the eight gas turbines carries a 300 kW starter generator with two diesel auxiliary power unit each with a 1,000 kWe generator. Each network is supported by a 500 kWh lithium iron phosphate battery module. Total installed generation is 4,400 kW. E1 draws from the forward port and aft starboard machinery spaces while E2 draws from the forward starboard and aft port machinery spaces. Cross-tie contactors between E1 and E2 are normally open and close only under load shed control. Because every engine carries its own generator declutching engines in cruise mode reduces the number of generators online without reducing available capacity below demand. The four running engines supply 1,200 kW, and either auxiliary power unit supplies a further 100 kW when required. The load management system enforces a 2,000 kW ceiling with prioritized load shedding. Battery buffering supplies transient demand above the running generation capacity. Each LFP battery module stores 500 kWh usable and delivers 1.2 MW for 60 seconds or 600 kW for 15 minutes. Cell configuration is 169 in series at a nominal 541 V split about a grounded midpoint. The modules are installed in dedicated fire rated, pressure relieved compartments in the side casings vented directly overboard. Liquid heating and cooling holds cell temperature between +5 °C and +35 °C, heated by the exhaust recovery loop when engines are running or by auxiliary power unit jacket water on station and by a dedicated heating circuit or shore power during cold soak. Below 0 °C cell temperature the vehicle management system inhibits charging and displays a preheat countdown. Discharge remains available to −20 °C at derated current. The batteries provide no-break power transfer between sources, including transfers occurring during clutch engagement and disengagement at machinery mode changes, provide black start capability in which either battery starts an auxiliary power unit and the auxiliary power unit and battery together start all eight main engines so that no external power is required from full cold soak, provide on station load levelling in which one auxiliary power unit runs at 85% load for approximately three hours in sixteen to recharge the batteries and then shuts down, provide silent watch capability supporting a 125 kW reduced hotel load for six hours with all engines and auxiliary units shut down, provide peak shaving of deicing and actuation transients, and provide 60 minutes of essential load after total generation loss. Electrical distribution is by solid state power controllers in remote power distribution units with arc-fault and ground-fault detection on every feeder. Secondary conversion provides 28 V direct current for avionics and controls, 115/200 V at 400 Hz for mission equipment, and 400 V at 50 Hz for galley, workshop, and shore-supplied cargo equipment. The shore power interface accepts 440 V at 60 Hz, 400 V at 50 Hz, or 540 V direct current. Two fully independent systems, designated GREEN and YELLOW, operate at 550 bar using a low temperature synthetic hydrocarbon fluid with a pour point below −60 °C. Each system is supplied by four engine driven variable displacement pumps and one electrically driven AC motorpump. Pump drives are distributed across the engines so that each system retains at least two engine driven pumps in cruise mode with the electric pumps available in all modes. Reservoirs are bootstrap pressurized and heated. Primary tubing runs are titanium. Filtration is to 3 micrometers absolute with differential pressure and particle count monitoring. Fluid is heated by the exhaust recovery loop supplemented by electric reservoir heaters and full flow operation is inhibited below −30 °C fluid temperature.


Vehicle Management & Control:
The vehicle's active closed loop ride control system alleviates vehicle motion generated by surface roughness, maintains attitude within limits, and manages cushion pressure distribution across the four quadrants. Vertical acceleration at the crew stations is kept under 0.15 g RMS at 90 knots and 0.30 g root mean square at 120 knots over 90th-percentile pack ice Peak vertical acceleration during a ridge crossing at 50 knots is 1.2 g. Cargo restraint is designed to 2.5 g. Pitch attitude is held within ±2.5° and roll attitude within ±3.0° in cruise. For control the lift fan inlet guide vanes provide ±40°of pre-swirl at 3 Hz bandwidth and control cushion flow and pressure trim. The lift fan blade pitch provides ±12° of pitch change at 2 Hz bandwidth and is the primary heave and pitch alleviation effector. Eight cushion vent valves, two per quadrant, operate at 20 Hz bandwidth and provide high frequency pressure relief. Four skirt shift actuators operate at 0.2 Hz and provide static trim. Differential propulsor thrust and blade pitch operate at 1 Hz with 15% thrust authority and provide yaw and roll coupling together with pitch trim through the offset of the thrust line above the center of gravity. Fan rotor inertia limits fan based control to approximately 2 Hz. The cushion vent valves cover the band from 2 to 20 Hz, which contains the pressure transients generated by rubble ice and small ridges at cruise speed. Two inertial measurement units (with the navigation inertial system as a third source) supply attitude, rate, and acceleration. Eight laser height sensors distributed around the periphery measure instantaneous ground clearance and skirt deflection. Sixteen pressure transducers, four per quadrant, measure cushion pressure state. Eight flow and pressure sensors measure the fan operating point. Twelve accelerometers at the crew stations, the cargo deck, and the structure provide motion criteria compliance and structural load monitoring. The controller is a triplex digital model-predictive controller with terrain preview feedforward. The preview data are supplied by the lidar and the 95 GHz radar through the combined vision system processor. At 120 knots the lidar supplies a validated surface elevation model between 0.6 and 3 seconds ahead of the vehicle and the radar extends coarse preview to 90 seconds. The controller acts on the preview before the disturbance reaches the vehicle. The ride control system has six different modes. The standard transmit applies nominal gains with low cushion flow and is optimized for reduced fuel consumption. Rough ice mode applies high cushion flow, high vent valve authority, increased damping, and reduced pitch authority limits. Water mode applies cushion retention and reinflation priority with wave contact logic. Ridge crossing mode is selected automatically by the obstacle system when the vehicle commits to crossing an obstacle between 3.0 and 5.0 meters where the mode preloads the forward quadrants, surges fan flow, commands a nose up attitude before contact, and unloads after passage. Hover mode applies 40% fan flow with attitude hold and is used for cargo operations. Degraded provides fan only control following vent valve failure and limits speed to 70 knots.


Cockpit:
The vehicle pilothouse is located at the forward end of the superstructure. The windows are heated conductive film laminates supplemented by hot air blast at the two forward pilot positions. Each of the two forward stations is fully equipped for full operation of the vehicle. The pilothouse includes two night-vision-goggle compatible 40° x 30° FOV 1,280 x 1,024 pixel super XGA resolution heads up displays for both the pilot and copilot and eight 15 by 20 cm centimeter active matrix liquid crystal displays including two primary flight displays, two navigation displays, an engine display, a system display, and two multifunction displays which can be used to display information from the vehicle's other avionics systems. Each pilot station also includes a 20 x 13 centimeter 1024 x 768 pixel XGA touchscreen electronic flight bags (EFB). An SDI Digital Map Module (DMM) with 512 GB of removable memory is included in the cockpit which features dual channel digital map capability and supports DTED (Digital Terrain Elevation Data) level 2 (~30 m resolution) and controlled image base 10 meter (CIB-10) resolution satellite imagery maps which support color moving map display capability on the cockpit's multifunction AMLCD displays. Below the pilothouse opens into the operations room which contains the mission planning, communications, and cargo management consoles. Direct external view is used for close quarters maneuvering, ramp operations, and visual confirmation with all high speed operation is conducted on the combined vision system.

The pilothouse is equipped with an SDI combined vision system which fuses a synthetic vision system with the vehicle's own forward looking sensors and presents the result on head up and head down displays at both pilot stations. The synthetic vision system renders the surface ahead from the stored terrain and bathymetry database, the current ice chart, the drift model and the navigation solution, producing a continuous perspective view aligned to the vehicle's computed position and attitude. The enhanced vision element fuses data from the 95 GHz radar and from forward looking infrared imager and low light television imagers and fuses them into one conformal scene. The 95 GHz radar supplies ridge geometry and height classification to 3.0 nautical miles. The 10 GHz navigation radar supplies the area picture and the position of open water. Two long wave infrared imagers and one mid wave infrared imager supply thermal imagery which distinguishes open leads, thin ice, and recently refrozen surfaces by their thermal signature. A low light electro-optical camera supplies visible band imagery. Six distributed aperture infrared imagers mounted around the hull perimeter supply additional close quarters imagery and cover the areas obscured from the pilothouse during ramp operations. The synthetic vision function draws on an onboard terrain database containing digital elevation models of the Arctic coastline and landmasses at 1.0 meter horizontal resolution, bathymetry, charted hazards, infrastructure, and the accumulated survey product of previous transits by the vehicle and by other vehicles. Database terrain provides the far field and the general form of the coastline with live sensor returns overwrite wherever available. Sea ice, which is absent from any database and changes hourly, is rendered entirely from live data. Satellite derived ice concentration, ice age, and ice motion products are ingested by data link and are displayed as a separate advisory layer. The fusion and integrity function registers the sensor returns against the database, resolves conflicts in favor of the sensor data, and updates the local database with the sensor-derived surface. It also computes and continuously monitors an integrity bound on the displayed picture, derived from the navigation position confidence and from the residuals between sensor returns and database terrain. When the integrity bound exceeds the display tolerance the synthetic terrain layer is removed and the system reverts to a sensor only picture with an explicit annunciation. Four presentation layers are overlaid on the fused scene. The route corridor is drawn as a pair of ground referenced lines along the commanded track. The planned path from the ride control outer loop is drawn as a ribbon showing the 90 second projection, colored by the commanded clearance margin. Obstacles exceeding 4 m in profiled height are outlined and annotated with height and range. Leads, open water and thin ice identified by radar backscatter and infrared signature are shaded. The system runs a continuous integrity monitor which compares the database rendering against live sensor returns. Any persistent discrepancy in position or elevation raises a caution, suppresses the database layer in the affected sector, and reverts to terrain referenced update.


Vehicle Decks & Cargo Handling:
The vehicle deck runs the full length of the hull on the centerline and measures 56.0 meters long, 13.5 meters wide, and 5.80 meters high beneath the overhead crane rails. Deck area is 756 m² and enclosed volume is 4,385 m³. The deck plating is 6 millimeter titanium fiber-metal laminate over the titanium deck structure. The clear height of 5.80 metres accommodates two ISO containers stacked together with 0.62 meters of clearance for stack fittings and overhead crane hooks. The deck provides 72 TEU stowage positions in nine rows of four stacked two high. Three roll-on roll-off lanes of 4.5 meters width run the full deck length, giving 168 lane meters. The deck accepts four main battle tanks or twelve tracked articulated carriers, or twenty four protected 4x4 wheeled vehicles. Deck strength is 100 kPa track pressure for tracked vehicles, 15 tonne single axle for wheeled vehicles, and 30.5 tonnes per corner casting for two high container stacks. A ramp retracting into a watertight door is fitted at each end of the cargo compartment, giving the vehicle drive-through roll-on/roll-off capability. . The bow ramp is 4.5 meters wide and 9.0 meters long when deployed while the stern ramp is 4.5 meters wide and 8.0 meters long. Both are rated at 75.0 tonne tracked vehicles with a 1.5 meter unsupported toe overhang and are constructed of titanium with fiber metal laminate skins at the hinge and toe sections. Both are two section assemblies with a hydraulically articulated toe that conforms to 12° of surface slope in any direction. Both are operated by the two hydraulic systems and deploy in 90 seconds. Ramp surfaces carry a bonded grit traction coating and are electrothermally heated before and during deployment.

The deck is fitted with a powered load handling system that moves palletized and containerized cargo within the vehicle deck. A set of powered rollers is installed flush in the deck across the full 56 meter length in three lanes. Each lane contains motorized roller trays at 1.5 meter intervals driven in groups by distributed electric drive units on the ±270 V networks. Rollers retract 40 millimeters below deck level to present a flat surface for roll-on/roll-off vehicle traffic and extend above deck level to engage the base of a container, flat rack, or pallet. Each roller position is rated at 30 tonnes.. Powered lateral transfer units at nine stations move loads between the three lanes. Restraint is by powered latches at each position, compatible with ISO container base fittings and with standard pallet rails. A set of overhead gantry cranes on rails traverses the full 56 metre deck length, carry a trolley spanning the full 13.5 meter deck width, and are each rated for a 50 tonne lifting capacity. The cranes lift and restow containers, build and break two high stacks, transfer loads between lanes, load and unload vehicles that cannot move under their own power, and handle machinery during maintenance. Both cranes operate under automatic antisway control referenced to the ride control system attitude solution which permits crane operation while the vehicle is on cushion at low speed. Two fixed control stations, one at each end of the deck, and two portable pendants provide operator control of the load handing system. Load cells at every roller position and every crane hook report cargo mass and position continuously to the vehicle management system, which maintains a real-time mass and center-of-gravity solution. The system supports three automatic functions. It sequences the discharge order so that the center of gravity remains within limits throughout an unloading operation. It redistributes cargo in transit to trim the vehicle, which supplements the skirt shift actuators and the fuel transfer system. It stages the next load to the discharging ramp during the approach, which reduces the discharge time at the objective.
Last edited by The Technocratic Syndicalists on Mon Aug 24, 2026 8:32 pm, edited 8 times in total.
SDI AG
Arcaenian Military Factbook
Task Force Atlas
International Freedom Coalition


OOC: Call me Techno for Short
IC: The Kingdom of Arcaenia

Next

Advertisement

Remove ads

Return to Global Economics and Trade

Who is online

Users browsing this forum: No registered users

Advertisement

Remove ads